- Posts: 339
- Thank you received: 134

I think not every hardware has 0x60B1:01 in the accessible PDOs and not everyone can use unsynchronized SDO to change during OP ... therefore I am high-lighing it before job is done ... I have working with 16 different brands of servodrivers based on ethercat and just one it has(nidec control techniques) ... What I know from TC3 this is solved by NC stuff computing for the each single axis ...@endian I discussed this with YangYang who attends the EtherCAT consortium meetings. AitalMAC is part of the consortium and we design I/O for EtherCAT, so we're not guessing here.
The standard already solves this problem. You don't need pos(t+1).
The 1 cycle delay is real, but it's identical for all axes. With Distributed Clocks everything executes on the same SYNC edge, synchronized to ~100ns. Every axis is "late" by the same amount, so the path shape is correct. Calculate it last week, execute it this week, the part is the same.
The CiA 402 standard provides feedforward objects exactly for this: 0x60B1 (velocity offset) and 0x60B2 (torque offset). The master can send position plus velocity feedforward so the drive can anticipate acceleration. This is the standard's solution, it just needs to be mapped in lcec.
Also, good drives interpolate internally. The servo loop runs faster than the bus cycle (Maxon runs 0.4ms internal vs 1ms bus). The drive doesn't jump between positions, it interpolates. That's what 0x60C2 configures.
If you're seeing ferror correlate with velocity in halscope, that's likely a display artifact. The ferror compares "commanded from 1 cycle ago" with "actual now", so it shows an offset proportional to velocity. It's not a real machining error.
What does your actual part surface look like? Any real deviation you can measure?
Please Log in or Create an account to join the conversation.
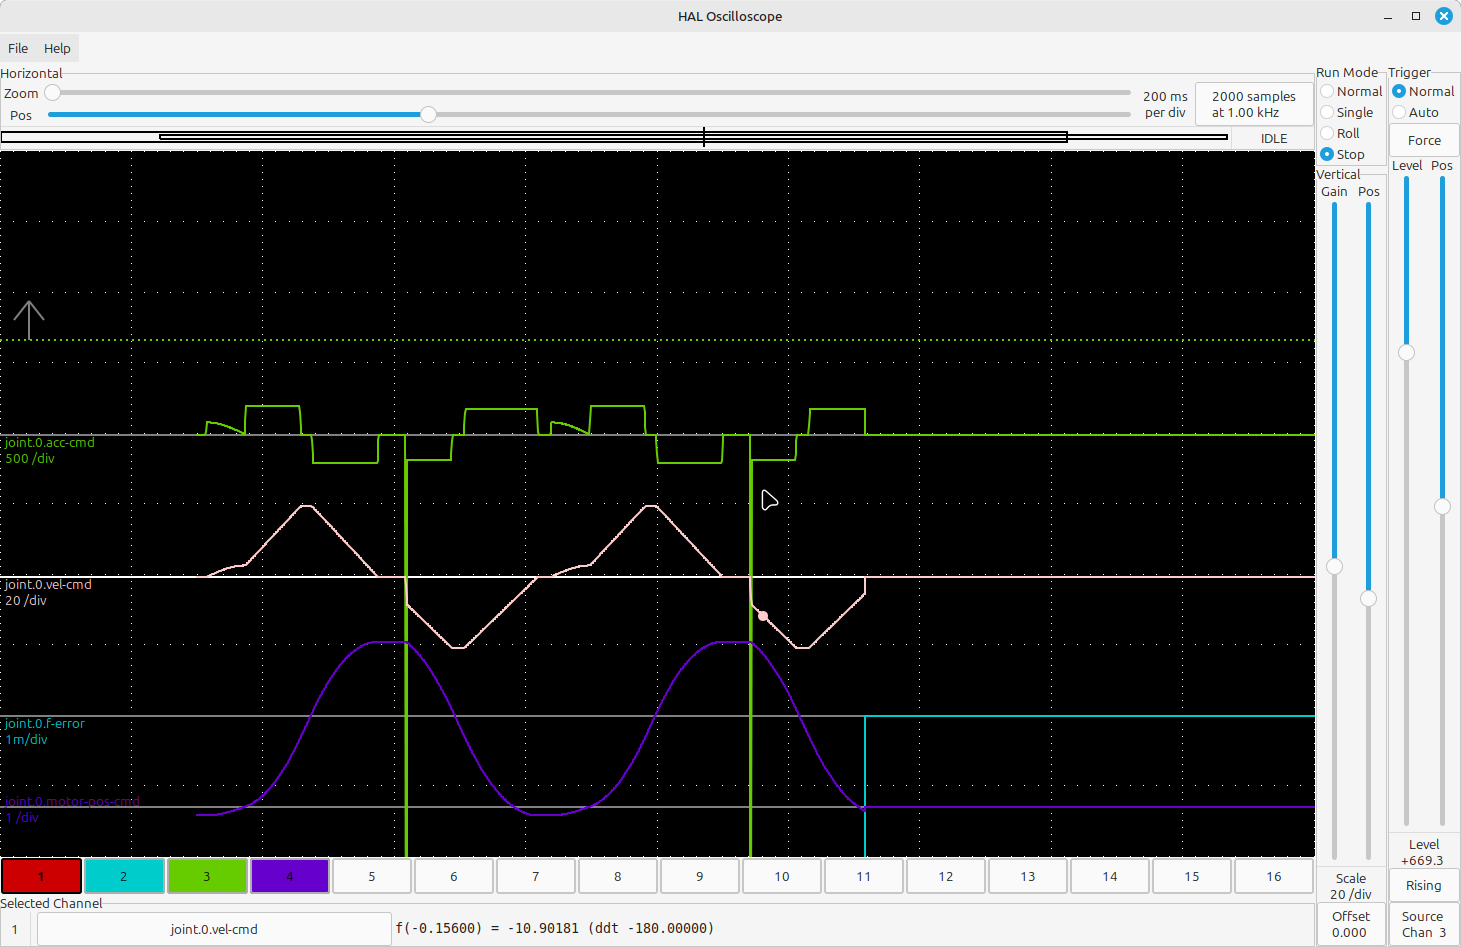
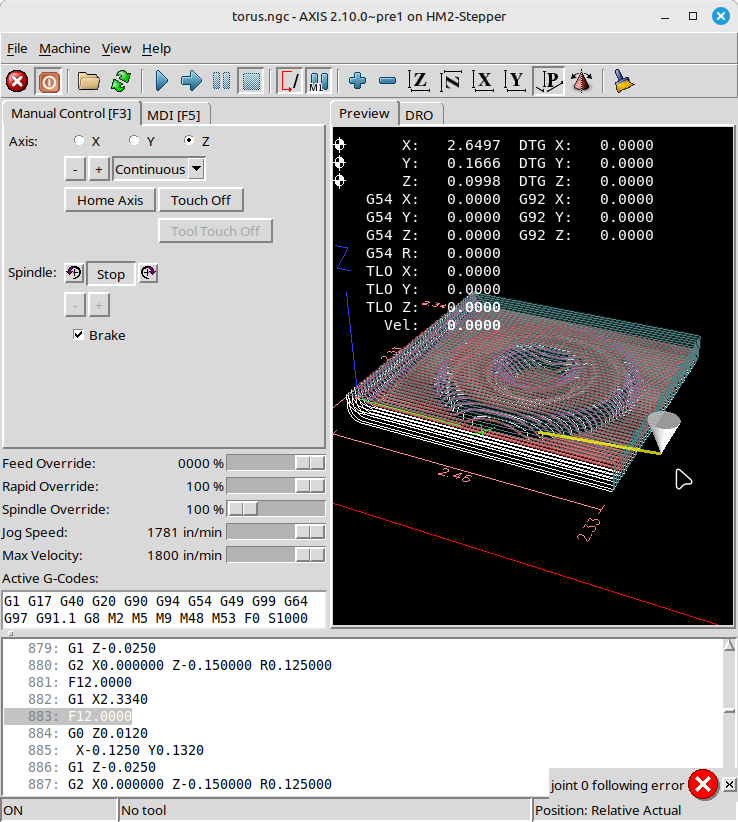
A word of caution to anyone testing the new planner on real hardware:
I would strongly recommend to NOT activate the new planner in the ini file.
I dropped my homing velocities to 20% and my real hardware setup still runs into the hard stops on homing.
Users should leave ini.planner_type = 0, home the machine and use halshow to set ini.planner_type = 1.
Please Log in or Create an account to join the conversation.

Please Log in or Create an account to join the conversation.

Please Log in or Create an account to join the conversation.

Please Log in or Create an account to join the conversation.
A word of caution to anyone testing the new planner on real hardware:
I would strongly recommend to NOT activate the new planner in the ini file.
I dropped my homing velocities to 20% and my real hardware setup still runs into the hard stops on homing.
Users should leave ini.planner_type = 0, home the machine and use halshow to set ini.planner_type = 1.
I would echo this warning for the latest master changes
1. Jerk does not seem to be limited nor acceleration:
2. Commanded position may take off on random tangents"
Please Log in or Create an account to join the conversation.


