- Posts: 350
- Thank you received: 410


The lookahead buffer stores velocities and segment data, not pre-calculated positions. Positions are computed at RT execution time through interpolation based on progress values that depend on velocity integration each cycle. The future position you want doesn't exist in a buffer waiting to be exposed.Your HAL component using
0x60B1 (velocity feedforward) can use joint.N.vel-cmd directly - is equal of FF1 of PID which already exist and its widely used to compensaty cycle delay ... this stuff is from my point of view useless for now
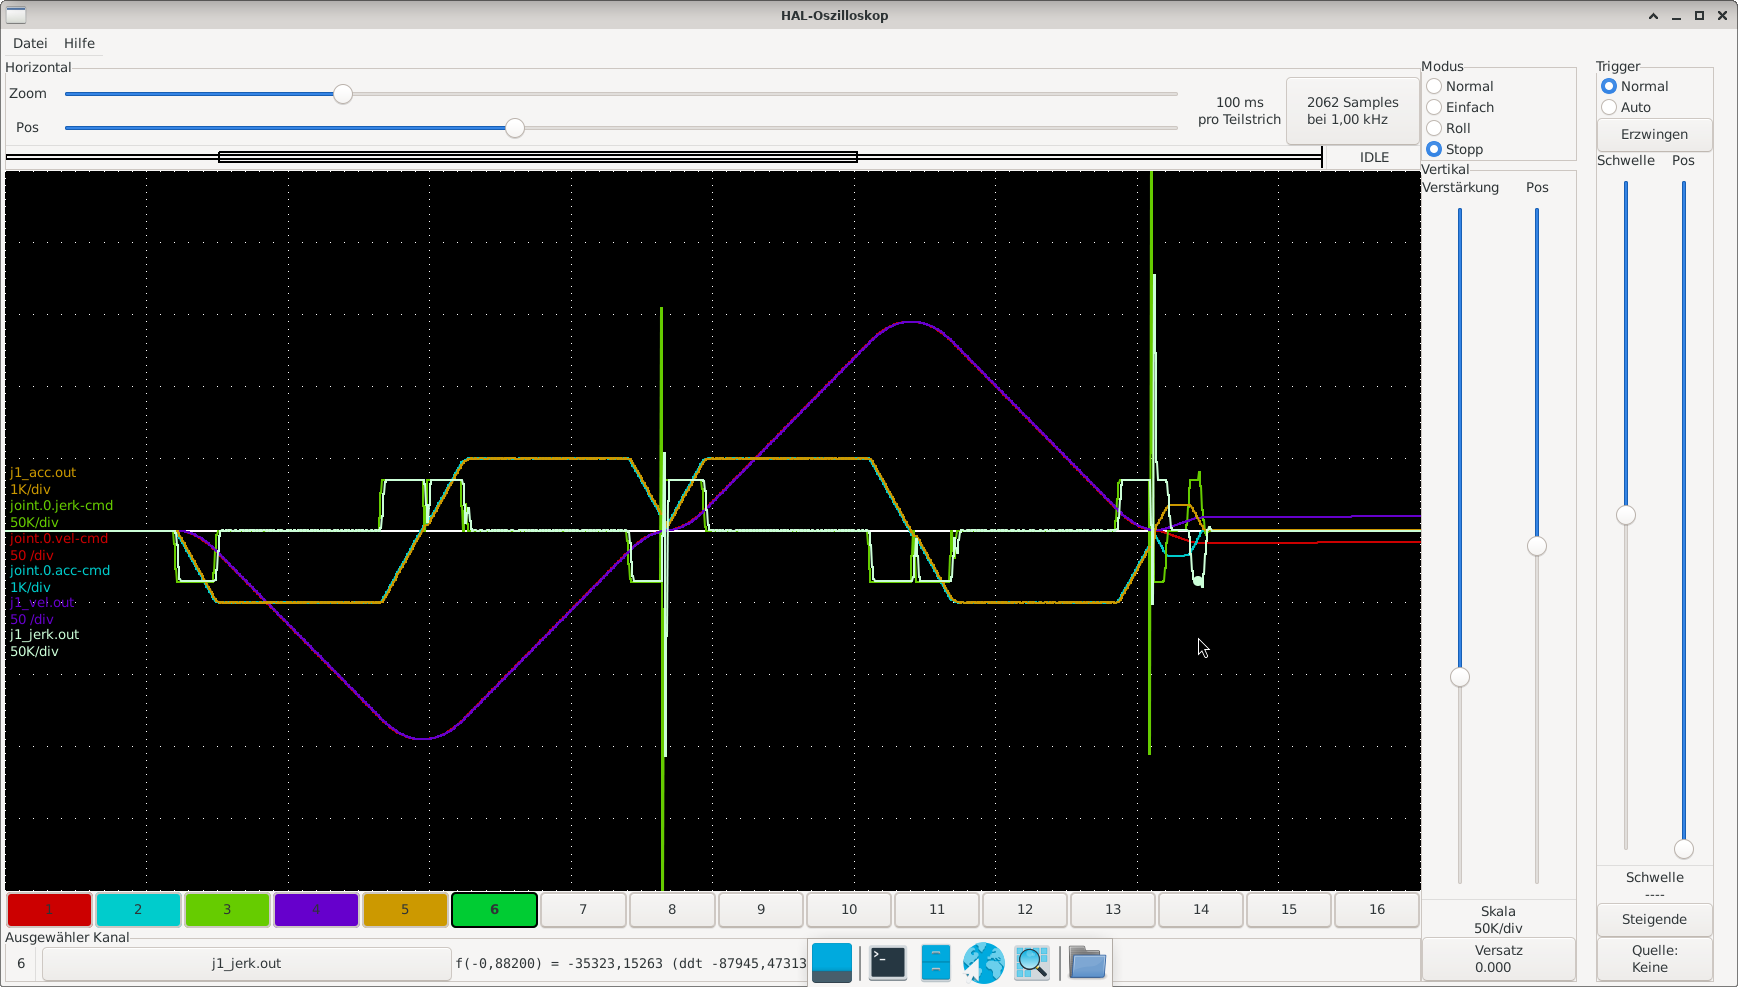
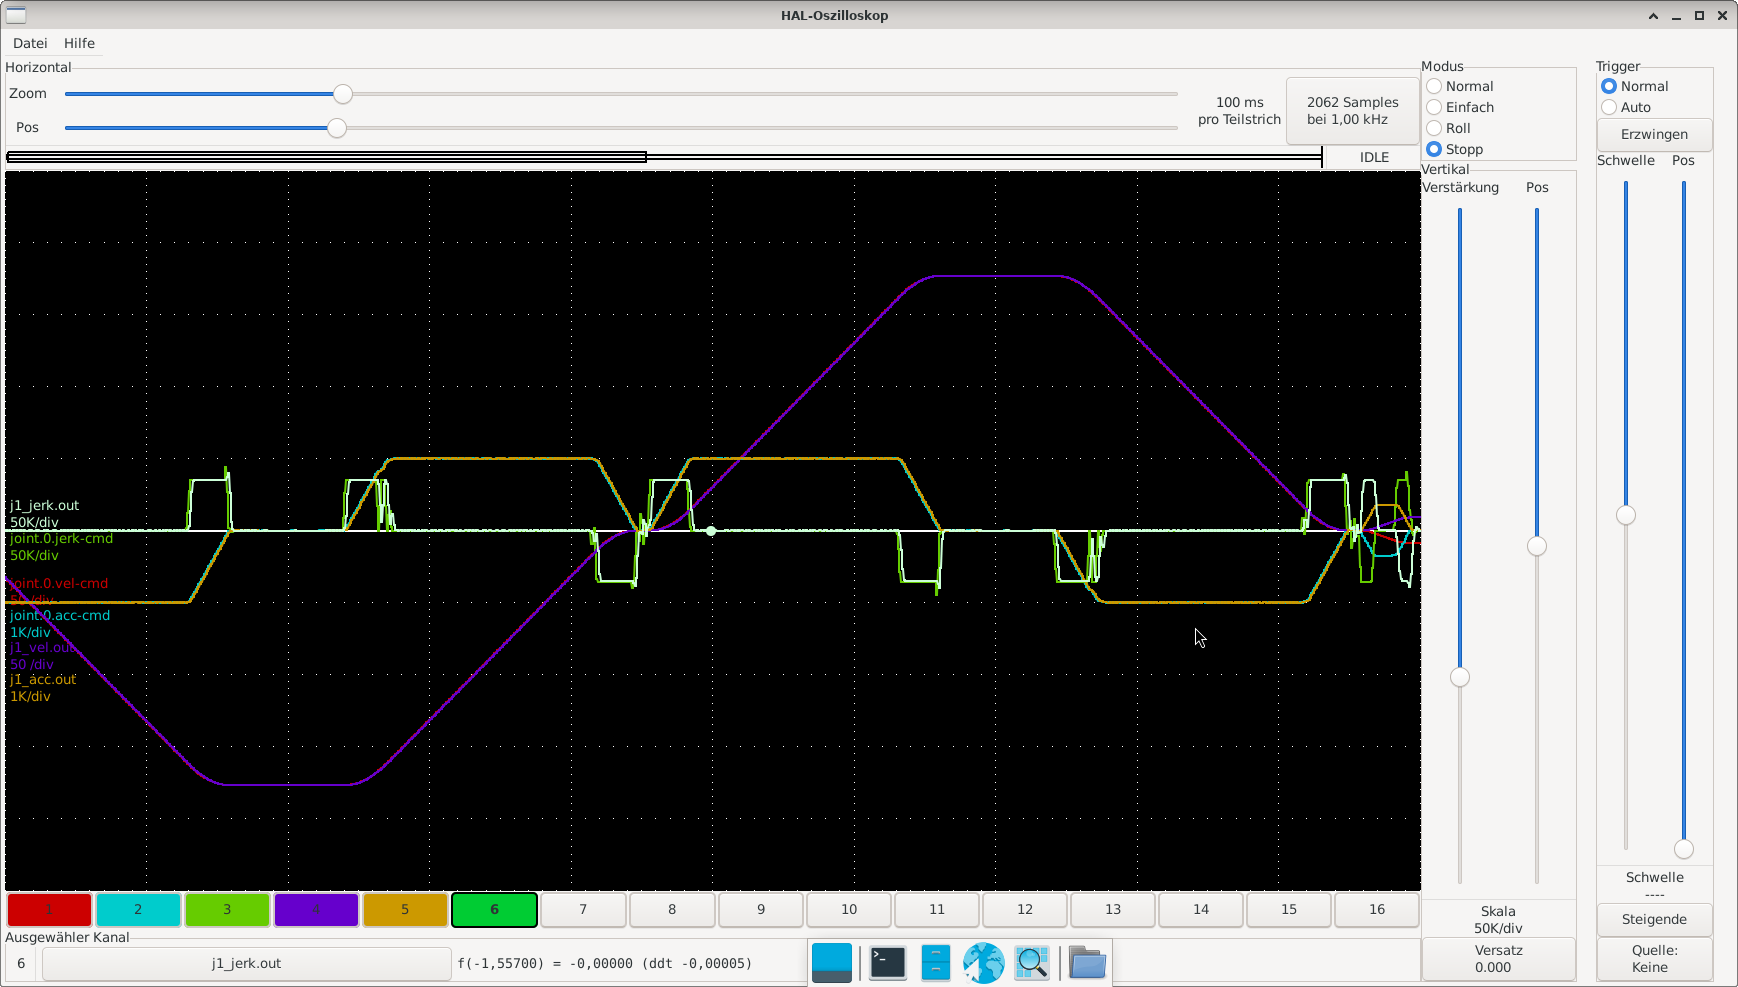
but I am still taking just about pin which allready read position from allredy presented 50ms buffer .. you are providing us from sTP posCmd(t), velCmd(t) (command speed is compensated cycle with PID FF1 and we do no use 60B1 for now), accCmd(t) and jerkCmd(t) and we need for ethercat posExtraCmd(t+2) for ethercat devices which is running in Constant Synchronized Position mode because of absention PID and therefore FF1 absention too (2 cycle lag present of ethercat) - this is just array position value which allready exist in buffer because of time(you notice 50ms) precalculation ...
and I know this is topic connected with ethercat but it is directly connected to trajectory planner ... Beckhoff, Codesys, Deltaww it has implemented as I said because their native bus is ethercat ...
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
yes interpolation servo period.. Rod please check this repo codeberg.org/endian/Beckhoff_AX5ZYZZ_lcec_driver here it is solved at all ... there is a .hal file example and everything neededVery good stuff! I made a start today forum.linuxcnc.org/ethercat/58260-lichua...r-need-help?start=20
is dt = Delta time = servo period?
I'll have to follow you guys a bit more closely!
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.

Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.