LinuxCNC S-Curve Accelerations

More
8 months 2 weeks ago #342949 by endian

New PR from YangYang is ready, hopefully will be merged soon in master

This adds ruckig in the planner type 1
if you want to test it get the binary from

github.com/LinuxCNC/linuxcnc/actions/runs/21975584400

or build source from my repo

github.com/grandixximo/linuxcnc

Testers are welcome to report here or in github, thanks!
 
Hello gentlemen,

movement are incredible smooth ... basic shaping what I have tested till now is pretty ... but during movement at more points during simulation of rotation interpolation its jumping or woobing ... kind off braking and next accelleration 

most spiking during cloud of points are gone ... some spiking are still present but it a huuuuge step forward 

testing setup 2ms benchtop profibus master 3axis geany gui ... 3 servo axis with synchronized speed control loop at 2ms

some testing fault popups triggered during the movement of file 3_1001.ngc

I am still testing at default simulation file from past but splitted to separated operations ..

thanks a lot for your progress ... I am watching it every single day with mount open and box of popcorn to reading the edits ... 

regards E.
The following user(s) said Thank You: besriworld

Please Log in or Create an account to join the conversation.

More
8 months 2 weeks ago #342961 by ruediger123
My initial tests showed no violations of the limits for jerk and acceleration.

Has the track speed for circles G2/G3 been reduced in the past?

The speed with G2/G3 seems very low to me.

Regards,
Rüdiger
The following user(s) said Thank You: endian

Please Log in or Create an account to join the conversation.

More
8 months 2 weeks ago #342963 by grandixximo
if you don't touch the feed override, the errors can still come up?

Please Log in or Create an account to join the conversation.
More
8 months 2 weeks ago #342965 by endian

New PR from YangYang is ready, hopefully will be merged soon in master

This adds ruckig in the planner type 1
if you want to test it get the binary from

github.com/LinuxCNC/linuxcnc/actions/runs/21975584400

or build source from my repo

github.com/grandixximo/linuxcnc

Testers are welcome to report here or in github, thanks!
 
Hello gentlemen,

movement are incredible smooth ... basic shaping what I have tested till now is pretty ... but during movement at more points during simulation of rotation interpolation its jumping or woobing ... kind off braking and next accelleration 

most spiking during cloud of points are gone ... some spiking are still present but it a huuuuge step forward 

testing setup 2ms benchtop profibus master 3axis geany gui ... 3 servo axis with synchronized speed control loop at 2ms

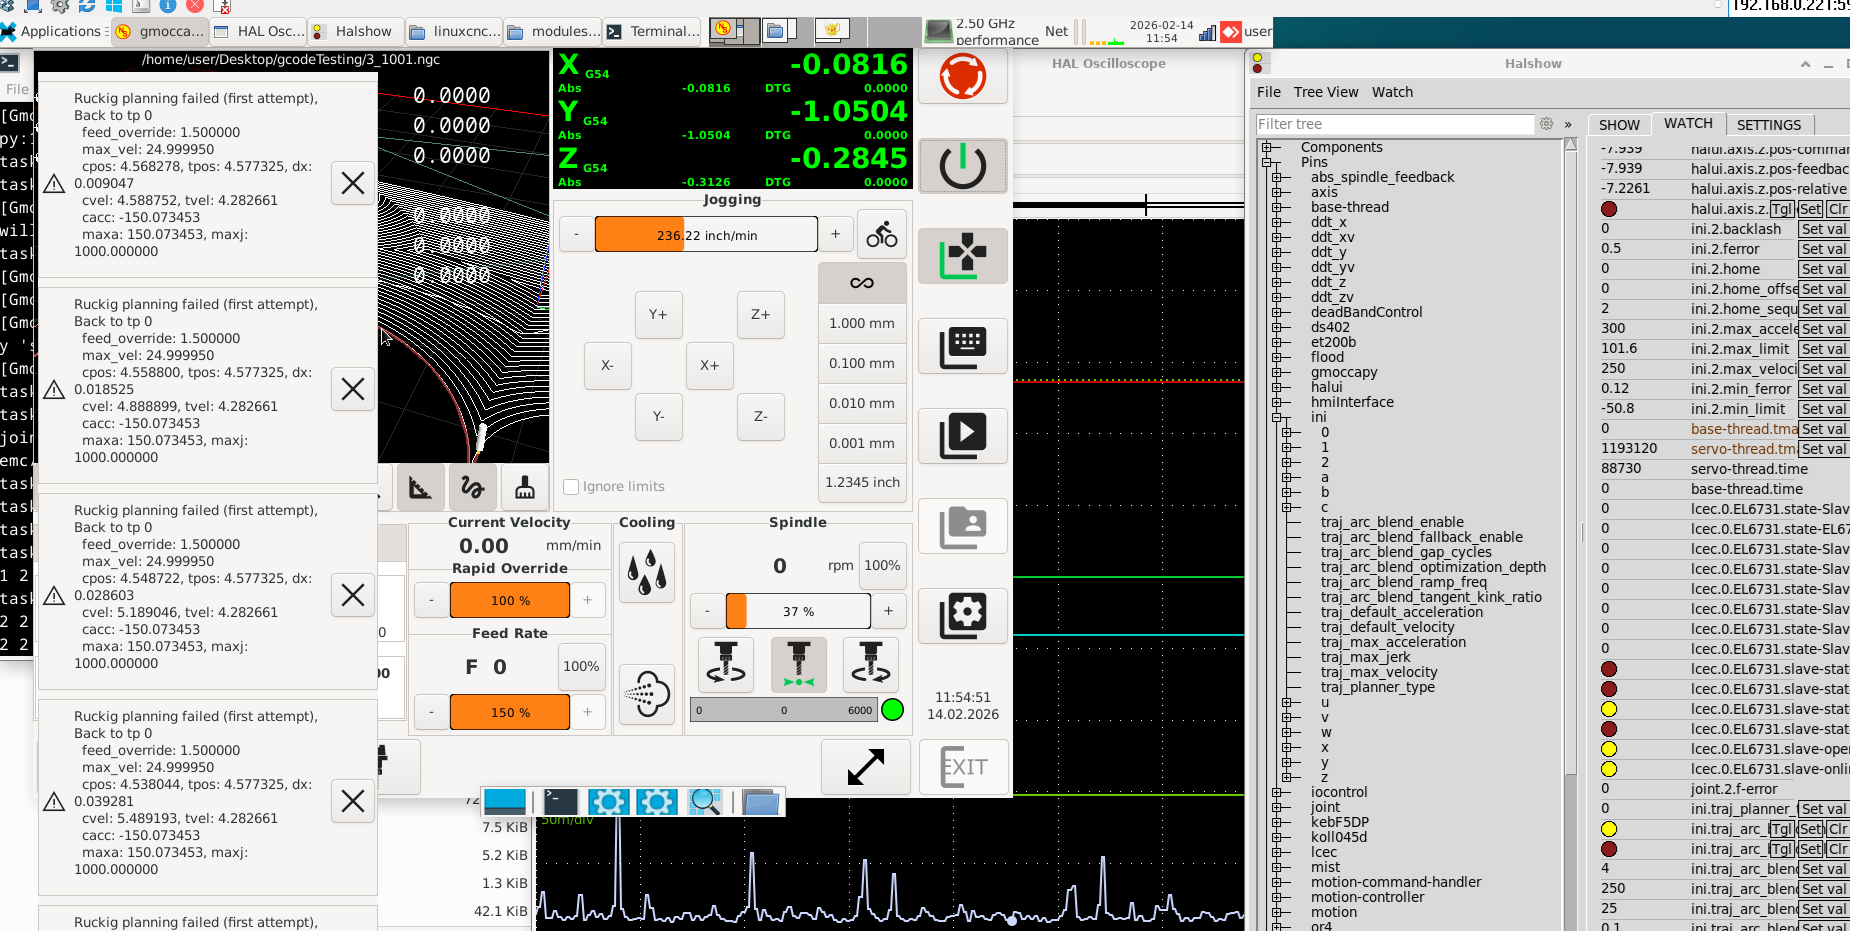
some testing fault popups triggered during the movement of file 3_1001.ngc

I am still testing at default simulation file from past but splitted to separated operations ..

thanks a lot for your progress ... I am watching it every single day with mount open and box of popcorn to reading the edits ... 

regards E.
 
I have noticed the slowing during the round movement too but I forgot to noticed it here.... yes it is present and its present during 100% feed value ...

crashes are not present during the 100% feed just if its not 100% ... 

crash log is in the attachement if somebody are interested ... 
The following user(s) said Thank You: grandixximo, Darium

Please Log in or Create an account to join the conversation.
More
8 months 2 weeks ago #342972 by grandixximo
I will have YangYang take a look after the holidays, thank you for testing.
We are on a Chinese new year brake for a couple of weeks.
I'm still working on Planner Type 2, will see what YangYang thinks after the holidays, hopefully Rob will also do some testing
The following user(s) said Thank You: endian, Darium, NWE

Please Log in or Create an account to join the conversation.

More
8 months 2 weeks ago - 8 months 2 weeks ago #342989 by endian
hello,

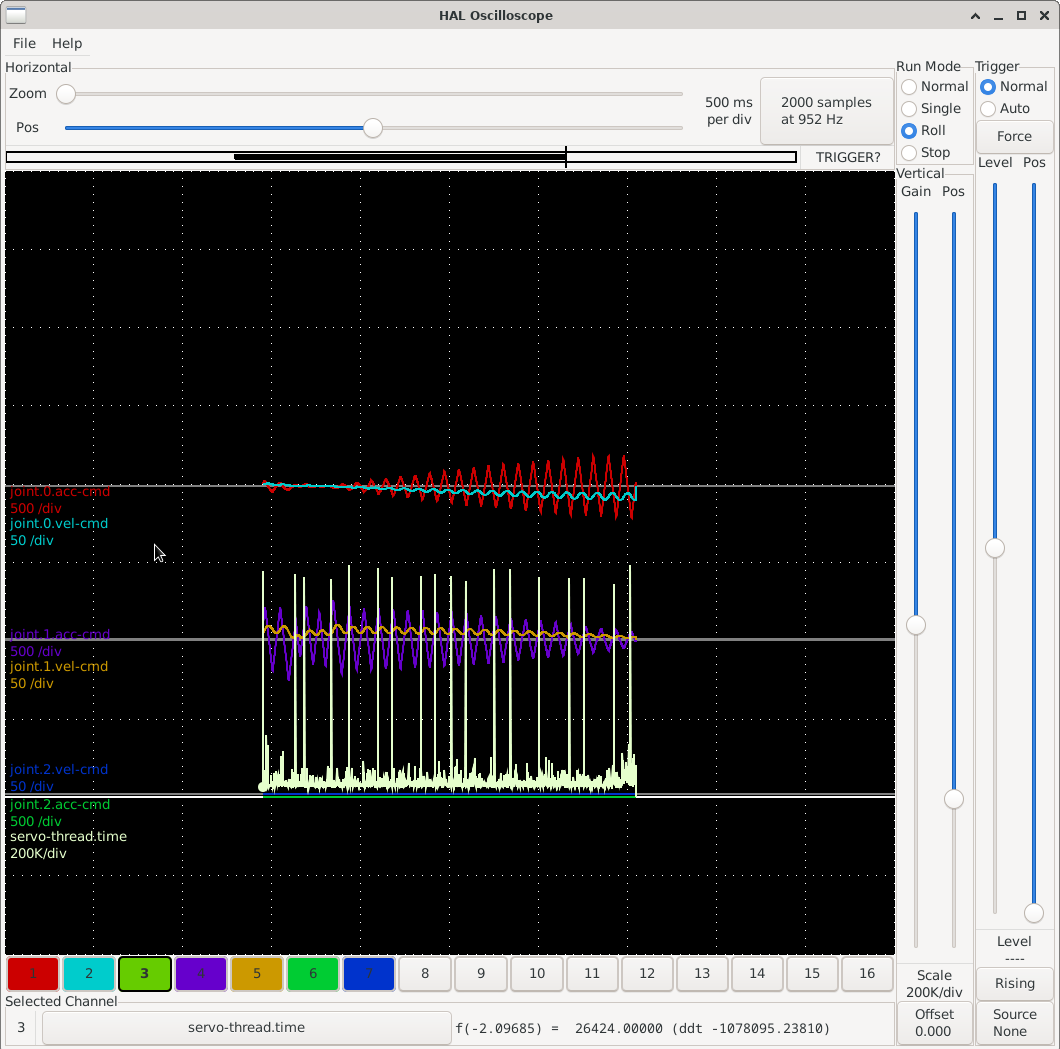
During todays testing Ive noticed time spiking during the G64 P0.005 and less ... I know there is a huge tolerance limit but I am reporting it for full testing approach ... code 1_1001.ngc from .tar file - again simulation or circural interpolation by cloud of point 

otherwise timing get huge improve ... no big spikes and no big spikes of accelleration during the movement too!!!

I wish happy new year to China! Take a rest and we will see us after !

thanks
Last edit: 8 months 2 weeks ago by endian. Reason: Editor messing
The following user(s) said Thank You: grandixximo, Becksvill

Please Log in or Create an account to join the conversation.

Time to create page: 0.169 seconds
Powered by Kunena Forum
