ROS LinuxCNC Link

More
5 years 7 months ago - 5 years 7 months ago #203892 by Grotius
Replied by Grotius on topic ROS LinuxCNC Link
Hi,

Nice test lab !

I have asked Daniel about if they plan to release the software and he said not in the near future.
Does he mean its not ready, or does he mean it's closed source?
This is quite important for open-source development. If they do not release the code, i think they have a problem with
the opencascade licence. At least they have to publish certain parts of their code. If they have some unique code with
intelectual property, they can keep that behind. The rest has to be published on request.

I have never used Qtvcp, is that what you wrote the Qt-Skynet-App in? That App looks nice and could be the base for the GUI.
No the skynet app is pure c++. I also never used Qtvcp. But i used glade-gkt2 before with linuxcnc for plasma.

One thing I will need is the ability to control external axises

This is no problem. Kdl can do a really good job with external axis. You will be surprised by the robot movements. In fact
i wass stunned when i tested the external axis.

For the ethercat leadshine's.
Maybe we can ask Chimeno to get the config file for this.
Last edit: 5 years 7 months ago by Grotius.
The following user(s) said Thank You: DPFlex

Please Log in or Create an account to join the conversation.

  • thefabricator03
  • Topic Author
  • New Member
  • New Member
More
5 years 7 months ago #203893 by thefabricator03
Replied by thefabricator03 on topic ROS LinuxCNC Link
I think he meant its not ready for release as they are still testing the software. I asked him if they would release it for a nominal fee like they do with PathPilot.

I think from the video we can see everything they are doing and most of it should be do-able.

Please Log in or Create an account to join the conversation.

  • thefabricator03
  • Topic Author
  • New Member
  • New Member
More
5 years 7 months ago #203894 by thefabricator03
Replied by thefabricator03 on topic ROS LinuxCNC Link
Yeah I was not too worried about setting up the Ethercat hardware as I have seen Chimeno's posts and he is always very helpful with Ethercat stuff.

Please Log in or Create an account to join the conversation.

More
5 years 7 months ago #203896 by Grotius
Replied by Grotius on topic ROS LinuxCNC Link
I think from the video we can see everything they are doing and most of it should be do-able.
There is no abracadabra.

Maybe something to think about :
I would like to start with a sps channel (safety channel) that start's when pc boots. Just like the ethercat starts at boot
and the mac adress is configured at boot time.

It run's separate from everything and has a few shared memory places to do communication.
It loops every second and checks if the emergency system is ok. This is a kuka standard. I think i adapt the emergency state
into the linux distro in the menu item, next to system date and time. This is also very interesting solution for a linuxcnc gantry production machine.

Please Log in or Create an account to join the conversation.
More
5 years 7 months ago - 5 years 7 months ago #203932 by rodw
Replied by rodw on topic ROS LinuxCNC Link

Grotius wrote: I would like to start with a sps channel (safety channel) that start's when pc boots. Just like the ethercat starts at boot
and the mac adress is configured at boot time.

It run's separate from everything and has a few shared memory places to do communication.
It loops every second and checks if the emergency system is ok. This is a kuka standard. I think i adapt the emergency state
into the linux distro in the menu item, next to system date and time. This is also very interesting solution for a linuxcnc gantry production machine.


There are two simple ways to achieve this in linuxcnc.
You can create a seperate thread in hal that fires every one second. Lets call it the safety-thread
The second way is simply to use a component on the standard 1 khz servo thread and fire on every 1000th iteration
Code:
static int ctr=0; ctr += 1; if(!(ctr % 1000)){ // Do something every 1 second }

I guess the seperate thread is cleaner and has a huge amount of time to get stuff done if that is a requirement.
Last edit: 5 years 7 months ago by rodw.

Please Log in or Create an account to join the conversation.

More
5 years 7 months ago - 5 years 7 months ago #203957 by Grotius
Replied by Grotius on topic ROS LinuxCNC Link
Hi Rod,

Just pointing to the fact that the linuxcnc emergency button is not enough. In software design state,
it's maybe just important that software works. It's a quite early state to talk about this.

A file called sps.sub is a file wich run's separate from the program. It locks the safety magnet on door etc.
This is done outside the robot program. If linuxcnc would freeze or something would happen.
This would be not involved. The safety door would unlock when emergency is triggered.

This is how Kuka robotics work.

example sps.sub
Warning: Spoiler!


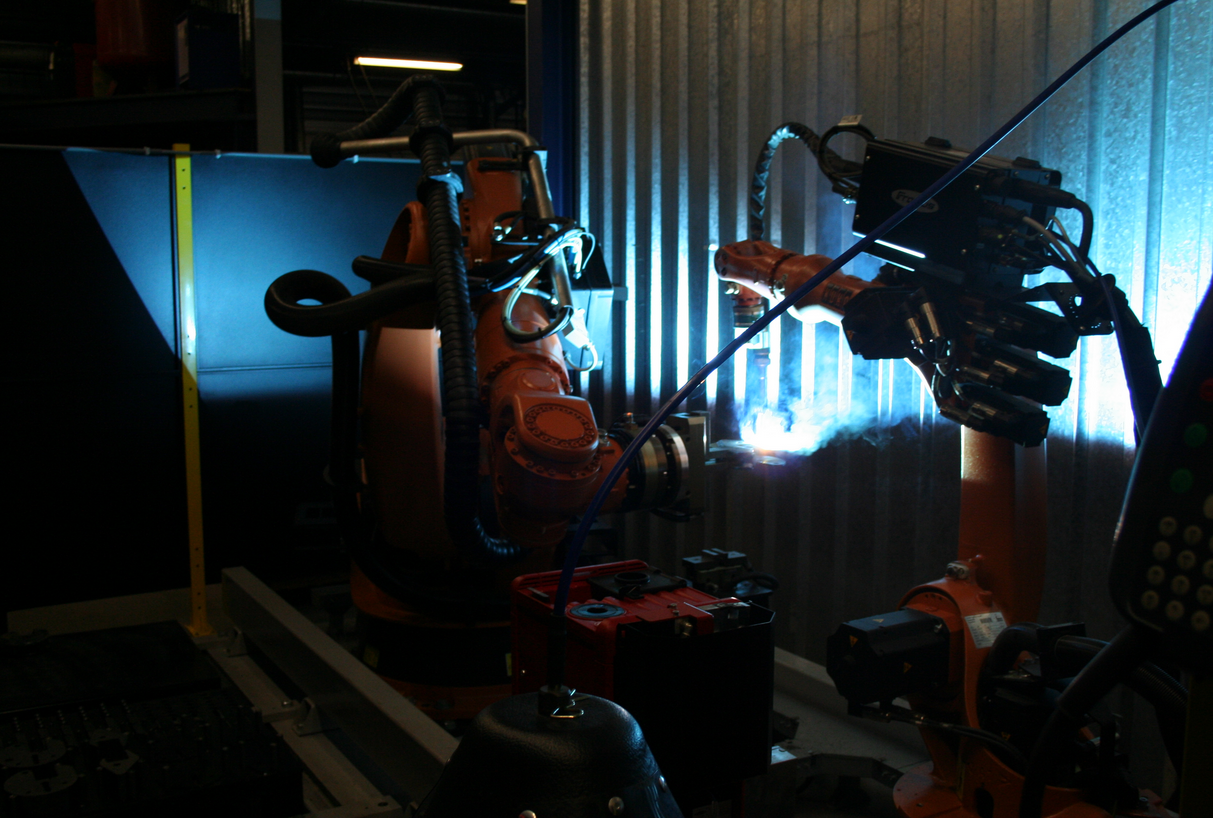
One of my welding projects, i think 15 years ago, last year i heard it was still running :


Attached 2 robot programs parts of a robot backup.
Maybe we can use them for setting up the code standard.
One is the big handling robot, the other is the welding robot.
Last edit: 5 years 7 months ago by Grotius.
The following user(s) said Thank You: rodw, thefabricator03

Please Log in or Create an account to join the conversation.

Time to create page: 0.081 seconds
Powered by Kunena Forum
