
- Posts: 532
- Thank you received: 327
Trajectory Planner using Ruckig Lib
- Joco
- Offline
- Platinum Member
-

Less
More
2 years 11 months ago #286726
by Joco
Replied by Joco on topic Trajectory Planner using Ruckig Lib
scurve branch has now been synchronised with Grotius's latest works and proven to compile/run using the build_make and build_cmake script sequence from the cmake directory.
This means no need to setup for OCC compile dependencies.
Cheers - J.
This means no need to setup for OCC compile dependencies.
Cheers - J.
The following user(s) said Thank You: Grotius
Please Log in or Create an account to join the conversation.
- aleksamc
- Offline
- Platinum Member
-
Less
More
- Posts: 569
- Thank you received: 67
2 years 11 months ago - 2 years 11 months ago #286729
by aleksamc
Replied by aleksamc on topic Trajectory Planner using Ruckig Lib
Currently, it's only for art models - there is no circles and other similar forms. Such g-code could be only parted with small lines.But thanks.
Last edit: 2 years 11 months ago by aleksamc.
Please Log in or Create an account to join the conversation.
- ihavenofish
- Offline
- Platinum Member
-
Less
More
- Posts: 1029
- Thank you received: 286
2 years 11 months ago #286739
by ihavenofish
Replied by ihavenofish on topic Trajectory Planner using Ruckig Lib
Modern cad spits out micro segments. A modern machine needs to keep up. Linuxcnc actually does mostly keep up, but without jerk control it can be a rattling experience. G64 mode does smooth over 90% of the moves automatically. The last 10% is what I am hoping will eventually get worked out here.
Please Log in or Create an account to join the conversation.
- Mecanix
- Offline
- Platinum Member
-
Less
More
- Posts: 447
- Thank you received: 229
2 years 11 months ago #286742
by Mecanix
This project/thread seems the way to go.
Replied by Mecanix on topic Trajectory Planner using Ruckig Lib
True. The CAM I use for 3d contours is all linear output and constrained within "in-tolerance" & "out-tolerance". Can easily put up a beefy half-a-million blocks for a 5-10min machining operation (eg. mold surfacing). I wouldn't expect this to run on Lcnc without an ultra-fast smoothing algo the like of CYCLE832 (Sinumerik).Modern cad spits out micro segments. A modern machine needs to keep up.
This project/thread seems the way to go.
Please Log in or Create an account to join the conversation.
- Joco
- Offline
- Platinum Member
-
Less
More
- Posts: 532
- Thank you received: 327
2 years 11 months ago #286743
by Joco
I will have another crack later in the day and if still having issues will attach the config in case you spot a silly mistake.
cheers - J.
Replied by Joco on topic Trajectory Planner using Ruckig Lib
Hi Grotius. I got this compiled on my plasma table and gave it a whirl using the same config in use for previous tests. Just with new runner module active. Things home ok but as soon as I try and run a test ngc joints 0,1,2 all get follow errors. NB this is a 4 joint setup being a gantry machine.Hi Joco,
Good luck with your machine.
Indeed the xyz ruckig back-end runners ensure at least a valid motor output with no velocity jumps.
I still believe in our own trajectory planner, I think we have to add blending to it first.
Then we could use the G64 P0.01.
So i started writing a blending function, 3d blending wich works now for line-line blending. Arc-line blending still todo.
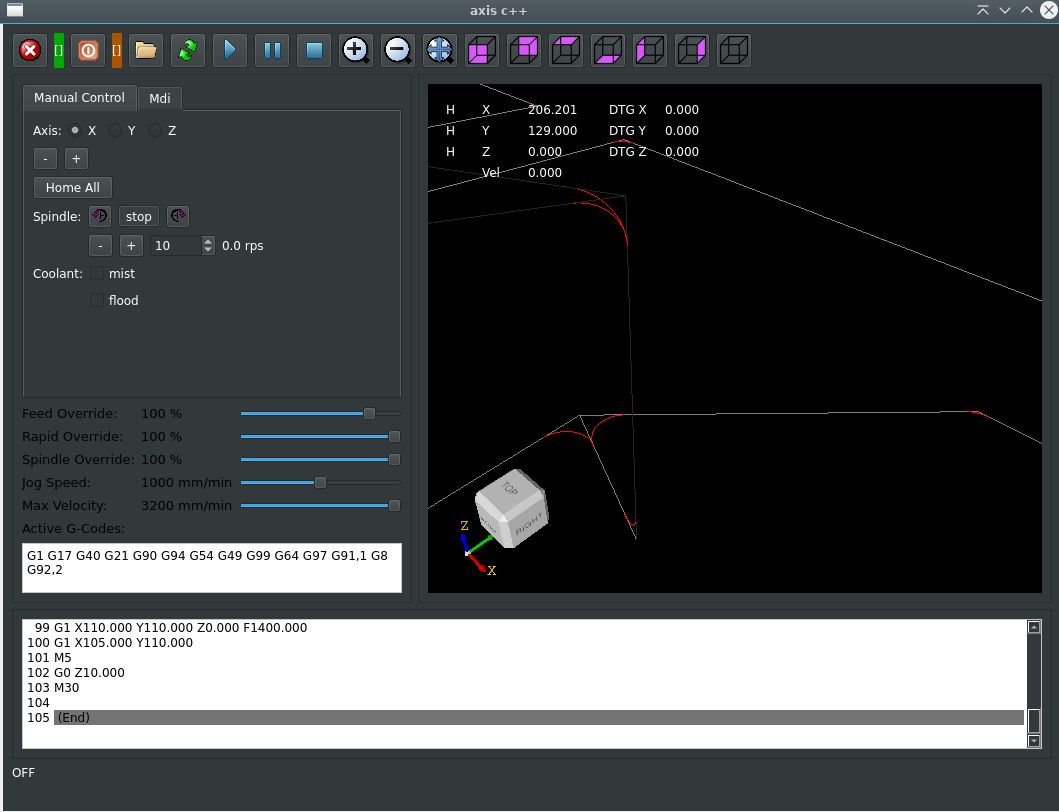
I will have another crack later in the day and if still having issues will attach the config in case you spot a silly mistake.
cheers - J.
Please Log in or Create an account to join the conversation.
- ihavenofish
- Offline
- Platinum Member
-
Less
More
- Posts: 1029
- Thank you received: 286
2 years 11 months ago #286744
by ihavenofish
Replied by ihavenofish on topic Trajectory Planner using Ruckig Lib
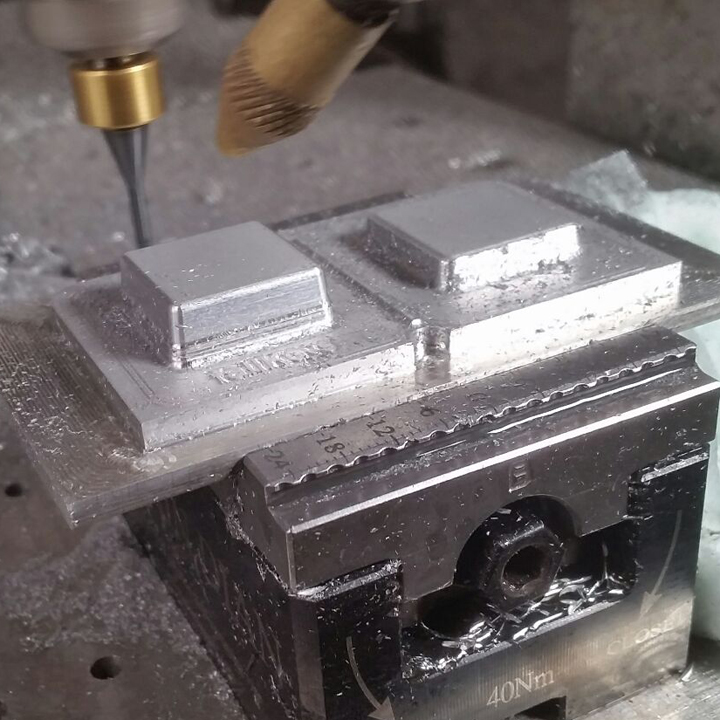
I've been surprised. I recently did a vac form mold in aluminium and it happily moved along at 200+ipm. The limit seems to be the machine, not the software at least in this zone. My program was like 14mb for under 30 mins of cutting.
Please Log in or Create an account to join the conversation.
Time to create page: 0.462 seconds