Glasmaßstab EIA-422 an Mesa 7i85 (S)

More
1 year 1 month ago #334712 by WKS-3D
@PCW

Sorry for only getting back to you now, but I've only just had a chance to try it out.
When I insert this:

setp    hm2_7192.0.encoder.00.index-enable true

and comment out this:

net x-index-enable  joint.0.index-enable  <=>  hm2_7i92.0.encoder.00.index-enable

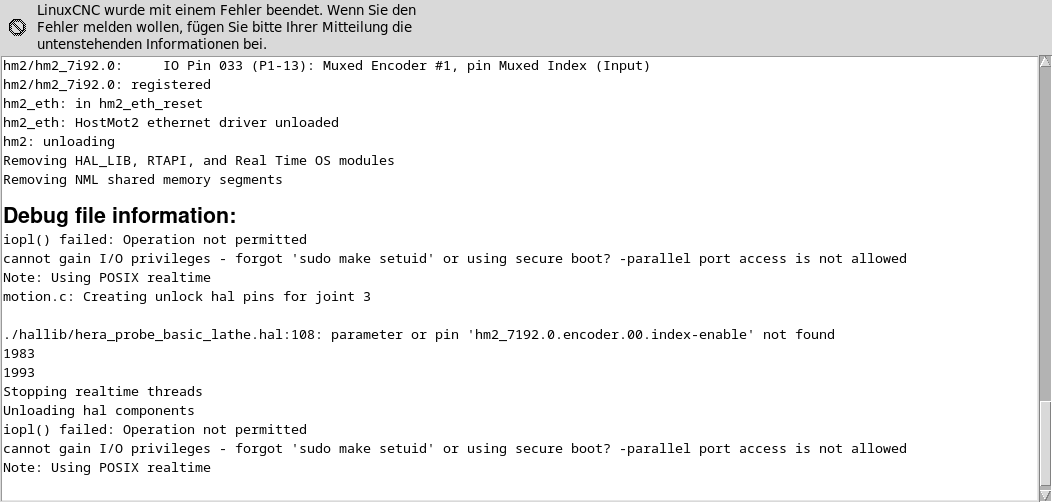
I get an error message when starting LinuxCNC.

The complete section for the X-axis looks like this:
Code:
# Verwendete LinuxCNC version:  Master (2.9) # Mesa 7i76 LAUFT IN MODE 1 MIT 4 ANALOGEN EINGANGEN (sserial_port_0=1000000x) !!!!!! loadrt [KINS]KINEMATICS loadrt [EMCMOT]EMCMOT unlock_joints_mask=0x8 servo_period_nsec=[EMCMOT]SERVO_PERIOD num_joints=[KINS]JOINTS num_dio=6 num_aio=3 loadrt hostmot2 loadrt hm2_eth board_ip="10.10.10.10" config="num_encoders=5 num_pwmgens=0 num_stepgens=5 sserial_port_0=1000000x"  loadrt flipflop count=2 setp   hm2_7i92.0.watchdog.timeout_ns 5000000 loadrt pid names=pid.x,pid.z loadrt debounce cfg=8,1 setp debounce.0.delay 1 addf debounce.0                 servo-thread setp debounce.1.delay 1 addf debounce.1                 servo-thread addf flipflop.0                 servo-thread addf flipflop.1                    servo-thread addf hm2_7i92.0.read              servo-thread addf motion-command-handler       servo-thread addf motion-controller            servo-thread addf pid.x.do-pid-calcs           servo-thread addf pid.z.do-pid-calcs           servo-thread #addf pid.s.do-pid-calcs           servo-thread addf hm2_7i92.0.write             servo-thread setp hm2_7i92.0.dpll.01.timer-us -50 setp hm2_7i92.0.stepgen.timer-number 1 # --- Pinole Input Signale --- net taster-pinole-minus  <=  hm2_7i92.0.7i76.0.0.input-25 net taster-pinole-plus   <=  hm2_7i92.0.7i76.0.0.input-24 # Set flipflops net taster-pinole-minus => flipflop.0.set  net taster-pinole-plus => flipflop.1.set net buf_taster-pinole-minus <= flipflop.0.out => hm2_7i92.0.7i76.0.0.output-01 net buf_taster-pinole-plus <= flipflop.1.out => flipflop.0.reset => flipflop.1.reset # --- Werkzeug-Revolver loesen-spannen --- net   revolver-unlock  joint.3.unlock  =>  hm2_7i92.0.7i76.0.0.output-00 net   revolver-is-unlocked  joint.3.is-unlocked  <=  hm2_7i92.0.7i76.0.0.input-09 net   joint.3.is-locked  motion.digital-in-00  <=  hm2_7i92.0.7i76.0.0.input-15 #******************* #  AXIS X JOINT 0 #******************* setp   pid.x.Pgain     [JOINT_0]P setp   pid.x.Igain     [JOINT_0]I setp   pid.x.Dgain     [JOINT_0]D setp   pid.x.bias      [JOINT_0]BIAS setp   pid.x.FF0       [JOINT_0]FF0 setp   pid.x.FF1       [JOINT_0]FF1 setp   pid.x.FF2       [JOINT_0]FF2 setp   pid.x.deadband  [JOINT_0]DEADBAND setp   pid.x.maxoutput [JOINT_0]MAX_OUTPUT setp   pid.x.error-previous-target true # This setting is to limit bogus stepgen # velocity corrections caused by position # feedback sample time jitter. setp   pid.x.maxerror 0.012700 net x-index-enable  =>  pid.x.index-enable net x-enable        =>  pid.x.enable net x-pos-cmd       =>  pid.x.command net x-pos-fb        =>  pid.x.feedback net x-output        <=  pid.x.output # Schritt-Gen Signale/Setup setp   hm2_7i92.0.stepgen.01.dirsetup        [JOINT_0]DIRSETUP setp   hm2_7i92.0.stepgen.01.dirhold         [JOINT_0]DIRHOLD setp   hm2_7i92.0.stepgen.01.steplen         [JOINT_0]STEPLEN setp   hm2_7i92.0.stepgen.01.stepspace       [JOINT_0]STEPSPACE setp   hm2_7i92.0.stepgen.01.position-scale  [JOINT_0]STEP_SCALE setp   hm2_7i92.0.stepgen.01.step_type        0 setp   hm2_7i92.0.stepgen.01.control-type     1 setp   hm2_7i92.0.stepgen.01.maxaccel         [JOINT_0]STEPGEN_MAXACCEL setp   hm2_7i92.0.stepgen.01.maxvel           [JOINT_0]STEPGEN_MAXVEL # ---Closed-Loop Schrittmotor-Signale--- net x-pos-cmd    <= joint.0.motor-pos-cmd net x-vel-cmd    <= joint.0.vel-cmd net x-output     => hm2_7i92.0.stepgen.01.velocity-cmd net x-enable     <= joint.0.amp-enable-out net x-enable     => hm2_7i92.0.stepgen.01.enable # ---Einrichtung Referenzfahrt X-ACHSE / Signal des Endschalters--- #(--- Hier nur normaler positiv Endschalter und Home-Switch ---) net x-home-sw  hm2_7i92.0.7i76.0.0.input-06-not   =>  joint.0.home-sw-in net x-pos-limit     =>  joint.0.pos-lim-sw-in # --- Mit Glasmassstab --- #net x-pos debounce.0.0.in  <=  hm2_7i92.0.7i76.0.0.input-06-not #net x-pos-limit debounce.0.0.out #net x-pos-limit  =>  joint.0.pos-lim-sw-in  joint.0.home-sw-in # ---Encoder Feedback Signals/Setup setp    hm2_7i92.0.encoder.00.counter-mode 0 setp    hm2_7i92.0.encoder.00.filter 0 setp    hm2_7i92.0.encoder.00.index-invert 0 setp    hm2_7i92.0.encoder.00.index-mask 0 setp    hm2_7i92.0.encoder.00.index-mask-invert 1 setp    hm2_7i92.0.encoder.00.scale  [JOINT_0]ENCODER_SCALE setp    hm2_7192.0.encoder.00.index-enable true # ---Indexsignal GMS fuer Referenzpunkt X (NICHT MIT NORMALEM ENDSCHALTER) net x-pos-fb  <=  hm2_7i92.0.encoder.00.position net x-vel-fb  <=  hm2_7i92.0.encoder.00.velocity net x-pos-fb  =>  joint.0.motor-pos-fb net x-index-enable  joint.0.index-enable  <=>  hm2_7i92.0.encoder.00.index-enable net x-pos-rawcounts  <=  hm2_7i92.0.encoder.00.rawcounts

What's wrong?
 

Please Log in or Create an account to join the conversation.
More
1 year 1 month ago #334917 by WKS-3D
Sind noch alle im Urlaub?
So ruhig geworden hier image missing /media/kunena/emoticons/ermm.png

Please Log in or Create an account to join the conversation.

More
1 year 1 month ago - 1 year 1 month ago #334918 by Hakan
We would like to see the error you get.
Nevertheless, I happen to know why. It's because index-enable is an IO pin, it's both input and output, a bit special.
So you can not set it to true, only connect it to a pin that is IO both input and output. Such as joint..index-enable
Relevant links  www.linuxcnc.org/docs/html/drivers/hostmot2.html#_pins_5
linuxcnc.org/docs/html/man/man9/motion.9.html#JOINT%20PINS
Last edit: 1 year 1 month ago by Hakan.

Please Log in or Create an account to join the conversation.

More
1 year 1 month ago - 1 year 1 month ago #334924 by PCW
Actually you can:

setp  hm2_7192.0.encoder.00.index-enable true

As long as hm2_7192.0.encoder.00.index-enable is not connected to
a signal in the hal fiie. It will be set true once at LinuxCNC startup.

The error you have is that you did not comment out the net command connecting
hm2_7192.0.encoder.00.index-enable to the signal x-index-enable:

# ---Indexsignal GMS fuer Referenzpunkt X (NICHT MIT NORMALEM ENDSCHALTER)

net x-pos-fb  <=  hm2_7i92.0.encoder.00.position
net x-vel-fb  <=  hm2_7i92.0.encoder.00.velocity
net x-pos-fb  =>  joint.0.motor-pos-fb
net x-index-enable  joint.0.index-enable  <=>  hm2_7i92.0.encoder.00.index-enable
net x-pos-rawcounts  <=  hm2_7i92.0.encoder.00.rawcounts

But for testing it's better to do this in halshow

Note that while you cannot change hm2_7192.0.encoder.00.index-enable
in halshow (or the hal file) if it's connected to a signal, you can
change the signal ( x-index-enable) in halshow for testing.
 
Last edit: 1 year 1 month ago by PCW.

Please Log in or Create an account to join the conversation.

More
1 year 1 month ago #334965 by WKS-3D
That's what I did:
net x-index-enable joint.0.index-enable <=> hm2_7i92.0.encoder.00.index-enable

but it doesn't work

Please Log in or Create an account to join the conversation.

More
1 year 1 month ago #334968 by WKS-3D
I changed it as follows:

# ---Encoder Feedback Signals/Setup

setp    hm2_7i92.0.encoder.00.counter-mode 0
setp    hm2_7i92.0.encoder.00.filter 1
setp    hm2_7i92.0.encoder.00.index-invert 0 # war 0
setp    hm2_7i92.0.encoder.00.index-mask 0
setp    hm2_7i92.0.encoder.00.index-mask-invert 1  # war 1
setp    hm2_7i92.0.encoder.00.scale  [JOINT_0]ENCODER_SCALE
setp    hm2_7192.0.encoder.00.index-enable true

# ---Indexsignal GMS fuer Referenzpunkt X (NICHT MIT NORMALEM ENDSCHALTER)

net x-pos-fb  <=  hm2_7i92.0.encoder.00.position
net x-vel-fb  <=  hm2_7i92.0.encoder.00.velocity
net x-pos-fb  =>  joint.0.motor-pos-fb
#net x-index-enable  joint.0.index-enable  <=>  hm2_7i92.0.encoder.00.index-enable
net x-pos-rawcounts  <=  hm2_7i92.0.encoder.00.rawcounts
 but I get this error message: 

Please Log in or Create an account to join the conversation.

Moderators: Muecke
Time to create page: 0.148 seconds
Powered by Kunena Forum
