Aufschaukeln mit JMC iHSS60-36-30-21-38 in Verbindung mit Linear Encodern

More
11 months 1 week ago - 11 months 1 week ago #338831 by Jensner
Hello,

today I did the steps from tommy`s link.
At the end i played around with the P and FF1.
After arount 50 different tests, slowly the hard errors dissapeared and at the end i found the best working configuration with P=15 and FF1 =1

So I configured this parameter on all 3 Axes and it works.
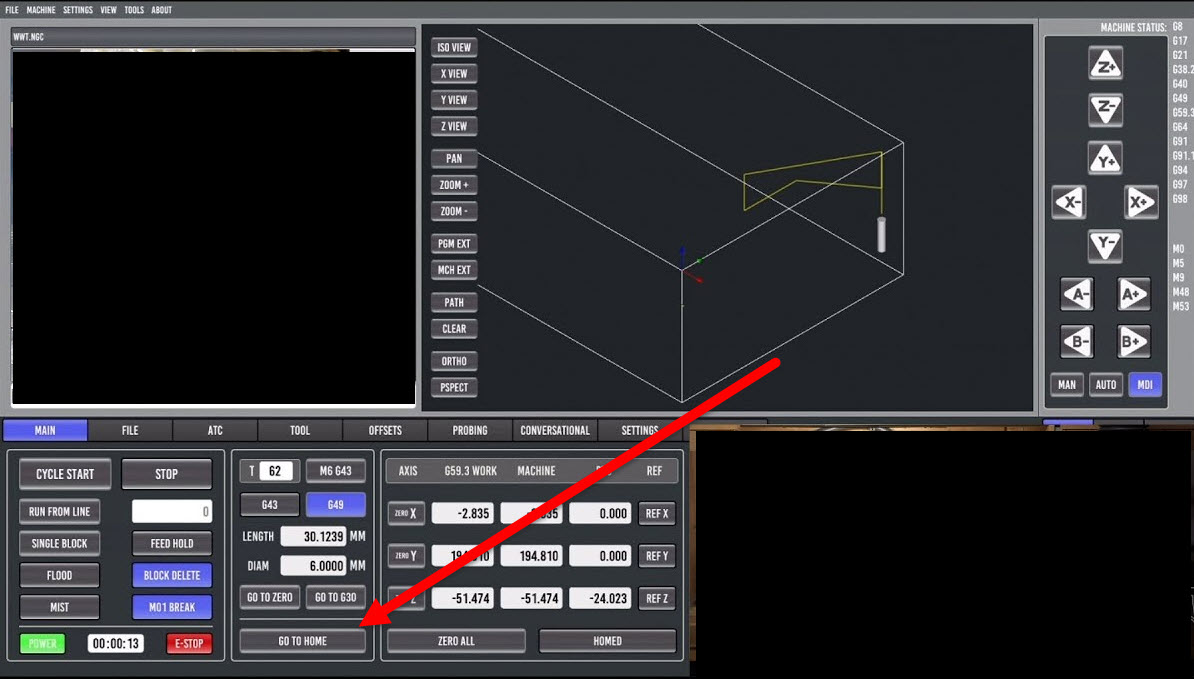
Only one last problem is the speed for "Go To Home"
Is ther a info where i can find the different settings for all moves?
Jogging Speed is OK and i can change ist via the GUI.
Homing Speed is also OK, but "Go Home" is far to fast.

Best regards
Jens 

Here is my config (with working Linear-Encoders​ & Closed Loop Stepper)
 

File Attachment:

File Name: FraeseNEU_...1-20.ini
File Size:10.16 KB


File Attachment:

File Name: FraeseNEU_...1-20.hal
File Size:14.1 KB
​​​​​​
Last edit: 11 months 1 week ago by Jensner.
The following user(s) said Thank You: tommylight

Please Log in or Create an account to join the conversation.

More
11 months 1 week ago #338832 by tommylight
Was ist "go home" ?
A button on the GUI?
Probably by editing that button from G53 to G54 Fxxxx ...

Please Log in or Create an account to join the conversation.

More
11 months 1 week ago - 11 months 1 week ago #338833 by Jensner
Sorry, this is a Button at the Probe Basic GUI


Furthere more where can i decrease the "G0" speed? 

 
Last edit: 11 months 1 week ago by Jensner.

Please Log in or Create an account to join the conversation.
More
11 months 1 week ago #338858 by Jensner
Becouse of this speed-problem i had a look at the documantation for the INI.
There are many more questions, but maybe I found some answers.
  •  In [TRAJ] i lowered the DEFAULT_LINEAR_VELOCITY and MAX_LINEAR_VELOCITY
    By the way, at the moment I do not check exactly how there where Velocity and acceleration-variables in TRAJ, AXIS_ and JOINT_
  • One more thing i found, was the DEADBAND = 0.0
    In the documentation it means that this is the tolerance-variable for the PID if the position is between the tolerance.
    So in my config this is 0.0 this should be to less an leads to "Servo Hunting"

Please Log in or Create an account to join the conversation.

More
8 months 1 week ago #343399 by Jensner
After nearly 3 Month i have to thank all of you.
Last November I startet these upgrade with linear encoders on all axis and after view days with try and error i just solved the problems and i can`t tell what a gamechanger this upgrade was to my mill.

Before this upgrade I allways had the problem, that on long programs with many moves i often had some losses of steps and the result never was perfect. (mostly on my 2m long X-axle) After the upgrade to the encoder its a dream to work. No more losses of steps and i can work on a level i never dreamd of.

Next project will be an upgrade to an ATC Spindle with a cabinet.
So i think th next thead is coming soon ...

Thanks a lot at all
Jens
The following user(s) said Thank You: tommylight

Please Log in or Create an account to join the conversation.

Moderators: Muecke
Time to create page: 0.445 seconds
Powered by Kunena Forum
