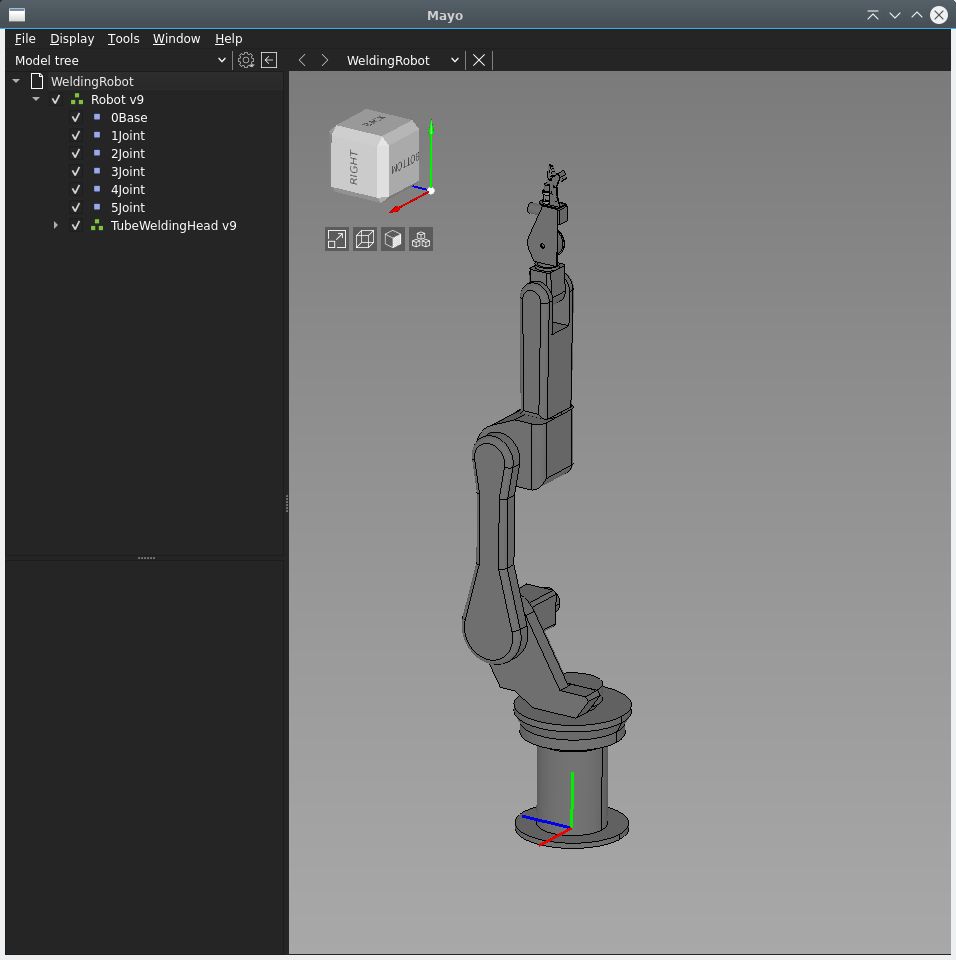
Hi,
Nice drawing !
For other users. To load and preview step files like this, you can use the program Mayo.
It can be found over here :
github.com/grotius-cnc/mayo/releases/tag/v1.0.0
This is indeed a nice starting point for testing, good found!
github.com/grotius-cnc/skynet_robot_cont.../releases/tag/1.0.21
It does the stepper output quite nice from what i remember, but not optimal.
But nevertheless a good example to get familar with code techniques.
If you look at hal-core the code technique is different.
It uses a hal-component (kernel module) that make's usage of c++
helper libs like kdl, opencascade etc.
Because the kernel module is master of the app, the program is performed from kernel land wich is much faster then when performing your app from a userland app.