hal-core

More
5 years 4 days ago - 5 years 4 days ago #224558 by Grotius
Replied by Grotius on topic hal-core
Hi Dave,

I added your Mesa hardware drivers into the source of hal-core. They compile nice to a .so.
- hostmot2
- hm2_eth

Hi Tommy,

I was curious, if i want to travel to Kosovo from Europe by car, Are there many covid restrictions in your country at the moment?

 
Last edit: 5 years 4 days ago by Grotius.

Please Log in or Create an account to join the conversation.

More
5 years 4 days ago #224560 by tommylight
Replied by tommylight on topic hal-core

Hi Tommy,

I was curious, if i want to travel to Kosovo from Europe by car, Are there many covid restrictions in your country at the moment?


Yeah the restaurants close at 11PM, that is the only restriction i am aware off.
The following user(s) said Thank You: Grotius

Please Log in or Create an account to join the conversation.

More
5 years 3 days ago #224664 by Dave3891
Replied by Dave3891 on topic hal-core
Hi Grotius,

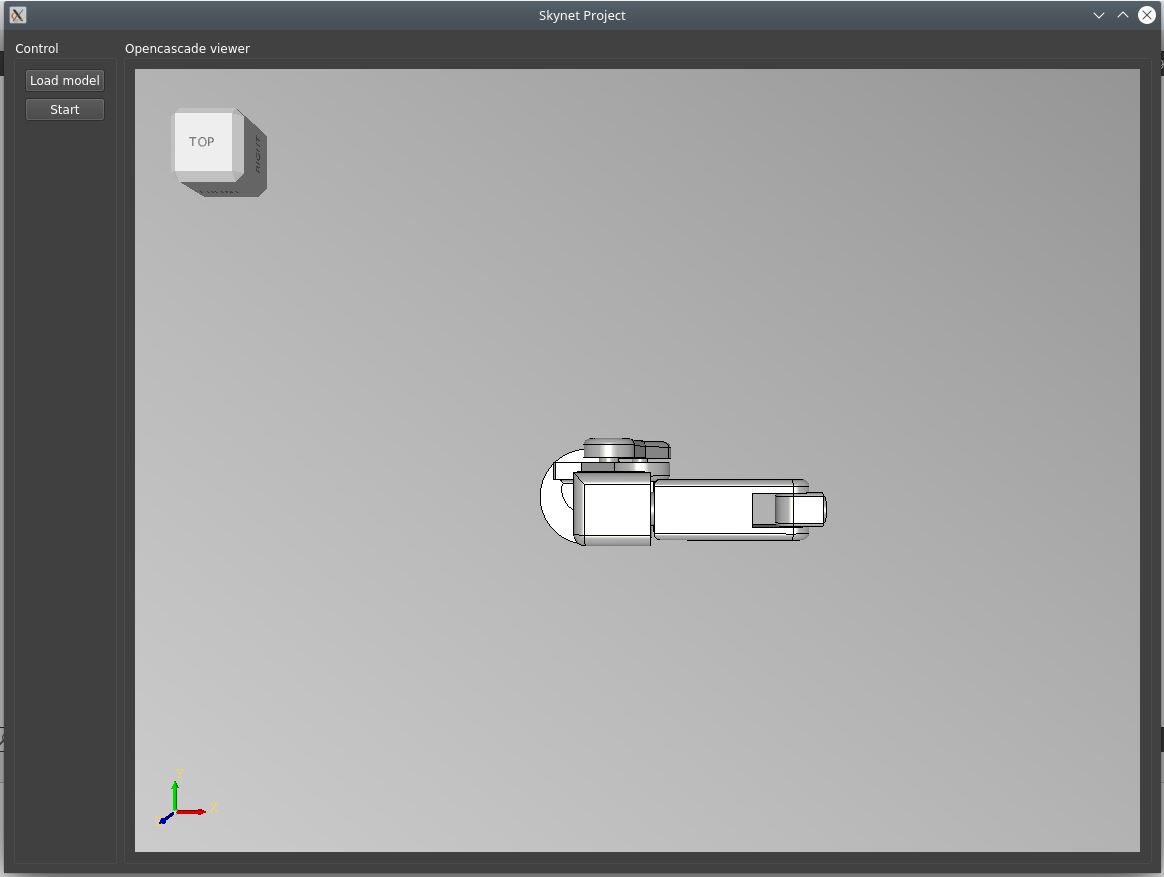
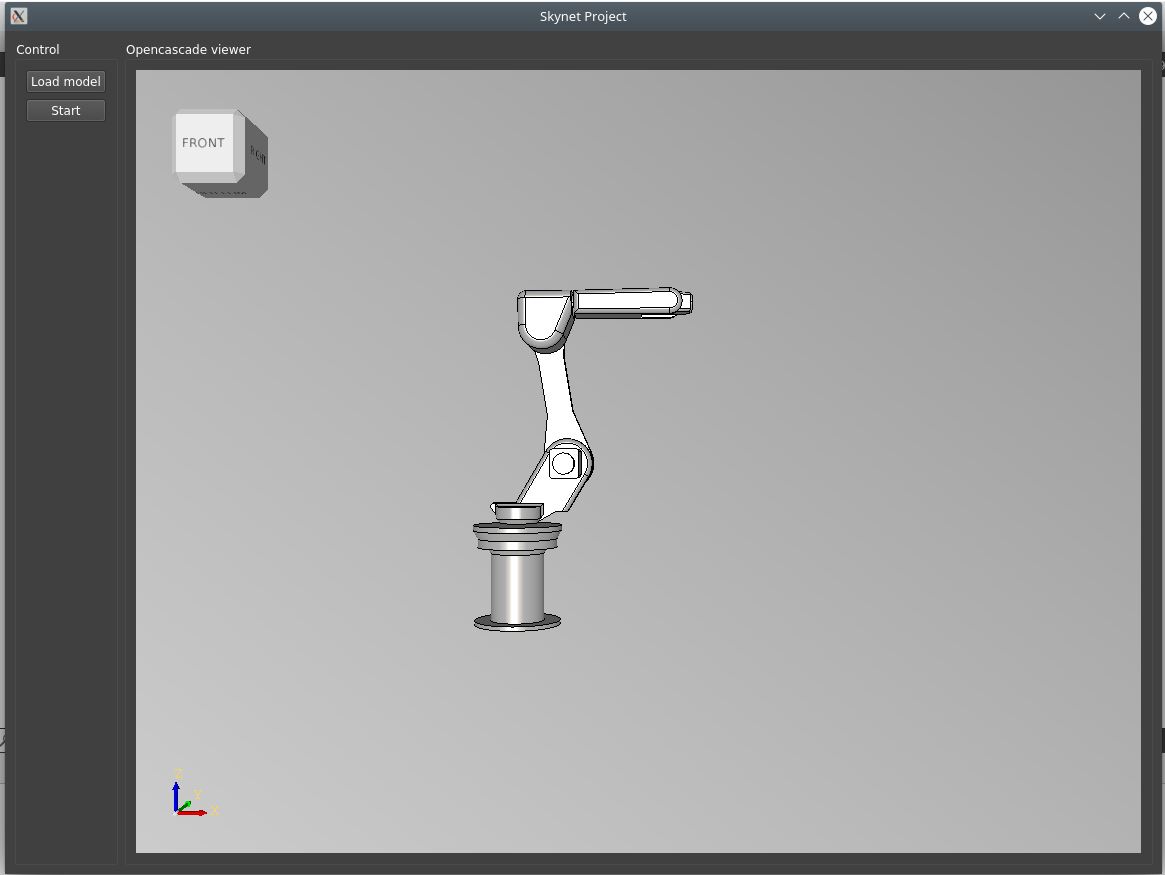
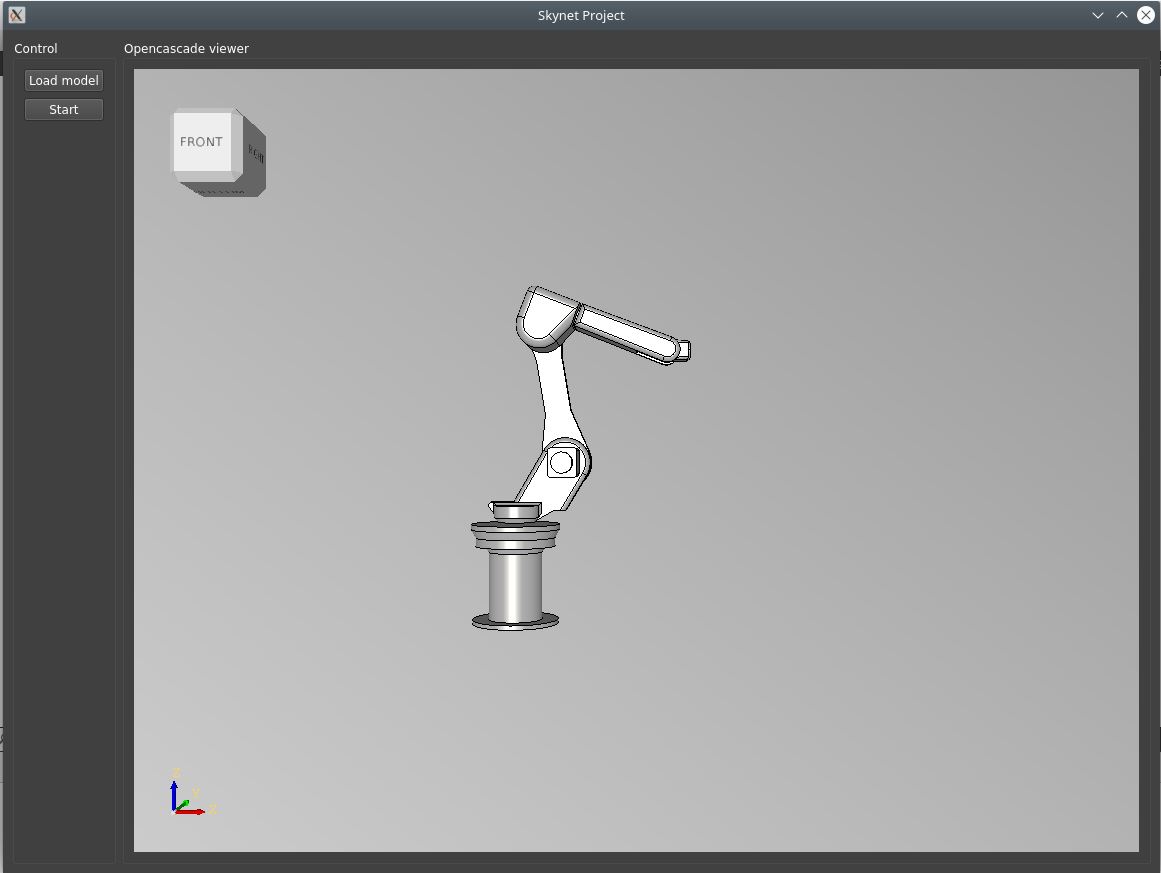
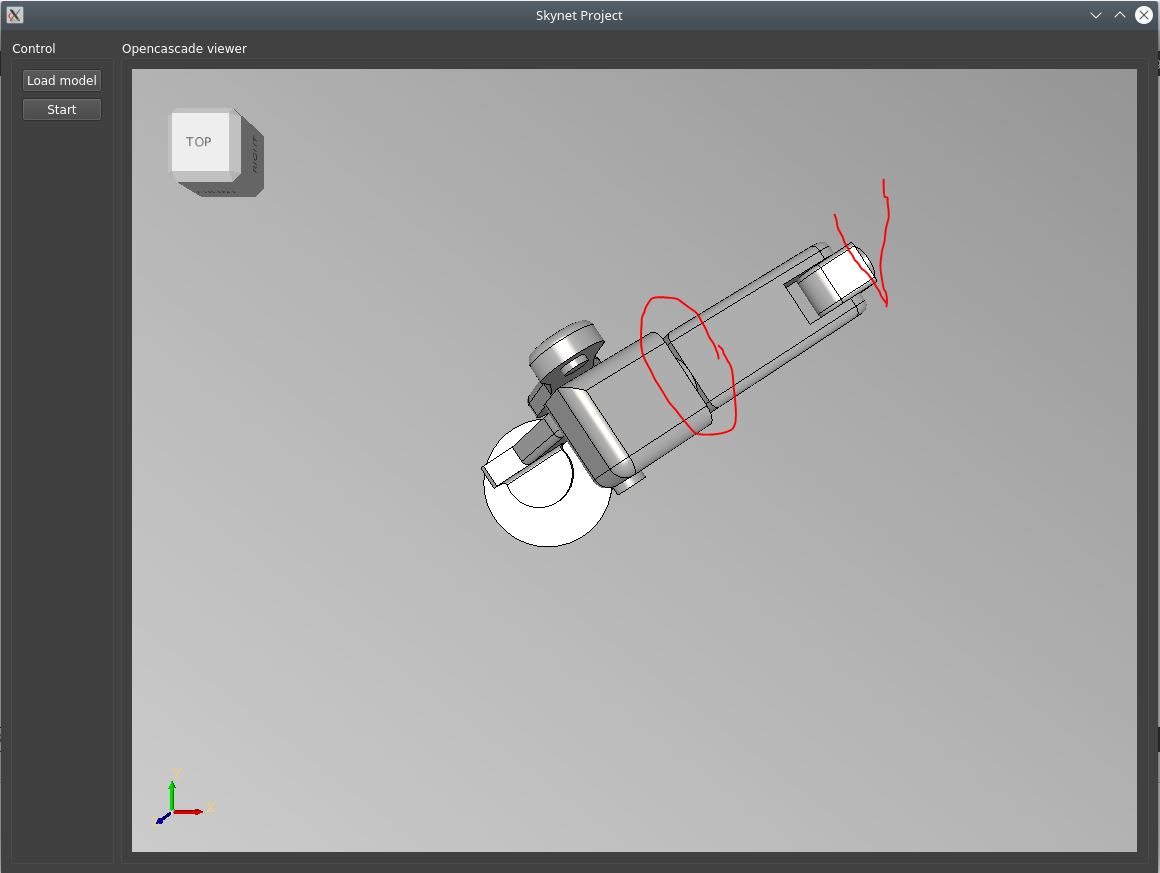
I was able to get the origin points on my model and the kinematics values sorted out for my robot. I also changed the waypoints in the program to make a basic square, but I noticed an issue.
It looks like one of the joints isn't rotating to keep the face parallel with the coordinates.
Here are some images of the problem.
Also is using the kinematics in the qt project the current best way to go? Or should I be using the hal kinematics module? What about sending positions? Keep using the MotionVec.push_back? Or is there another way?

Thanks for all your help with the project.


Please Log in or Create an account to join the conversation.
More
5 years 3 days ago #224679 by Grotius
Replied by Grotius on topic hal-core
Hi Dave,

It looks like one of the kinematic values isn't correct. Tiny problem. image missing /media/kunena/emoticons/smile.png
Check this kdl values with the robot document and compare it to your fanuc arcmate datasheet.

Also is using the kinematics in the qt project the current best way to go?
To learn how it works, it's a good starting point. The example is compact and transparant to see how things are done.

Hal_kinematics is integrated to Hal_opencascade. Hal_opencascade
would be your next starting point. You can off cource try Hal_opencascade any time you want.
But understanding the code is more difficult then your current example.

Keep using the MotionVec.push_back? Or is there another way?
The motionvec is just a databucket used by the example. In real life the robot will follow a motion planner or something like
that.
The example of Hal_opencascade used Lcnc as the motion planner.
I see from the ./runtest it is based on the /opt/linuxcnc install.
 
To install this version, get it here. The dependencies for lcnc are written down here : dependencies

Your second picture has the correct robot start position. Try go get the Forward Kinematic "FK" xyz start position coordinates.
This is one of the first initialized parameters by KDL and you can check them with your drawing.

It looks like one of the joints isn't rotating to keep the face parallel with the coordinates.
In "IK" mode, inverse kinematic mode, the face should be kept parallel indeed. In "FK" mode, that's not the case.

Oke, try to get the robot working. And if you spent more then 4 hours, pass me the robot datasheet if you have one.


Please Log in or Create an account to join the conversation.
More
5 years 3 days ago - 5 years 3 days ago #224680 by Grotius
Replied by Grotius on topic hal-core
Edit.

The Hal_opencascade project is entirely compiled with lcnc halcompile procedure and is documented that way.
So on first sight, this looks very difficult to get going. I did not have integrated Hal_opencascade into Hal-core yet.

Project compiling in Hal-core is way much easyer then with Lcnc halcompile. Sorry for that.

One thing about Hal_opencascade. The opencascade c++ code has a class called : draw_primitives. Here you can find
the Quaternion function. This is a function that can rotate your heat exchanger drawing in 3d, if you need to.
Don't use the rotate and translate function's for that. Quaternion's are working great for that purpose.


Last edit: 5 years 3 days ago by Grotius.

Please Log in or Create an account to join the conversation.
More
5 years 3 hours ago #224915 by Grotius
Replied by Grotius on topic hal-core
Hi, for info:

I did some work on hal-core.

- There is are now 2 robot example's included. link
- Added a 16 axis s-curve Ruckig Dofs component including a build in stepgeneration. link
- Added to the installer : cam, qt, opencascade, kdl, halview. link

If you use the installer, it should work. The install takes about 5 minutes.

To finish : hal_trajectory.
I have a question about this, and will ask it in a general forum topic.

Please Log in or Create an account to join the conversation.
Time to create page: 0.350 seconds
Powered by Kunena Forum
