hal-core

More
4 years 11 months ago #225315 by Grotius
Replied by Grotius on topic hal-core
Hi Dave,

That's ok. Moving in x.
Jogging is solved for cart xyz.

I want to review (improve) a few files related to hal-core.
Will try to setup a more modular machine data input that suits robots, gantry's etc.


Please Log in or Create an account to join the conversation.
More
4 years 11 months ago #225758 by Grotius
Replied by Grotius on topic hal-core
Hi,

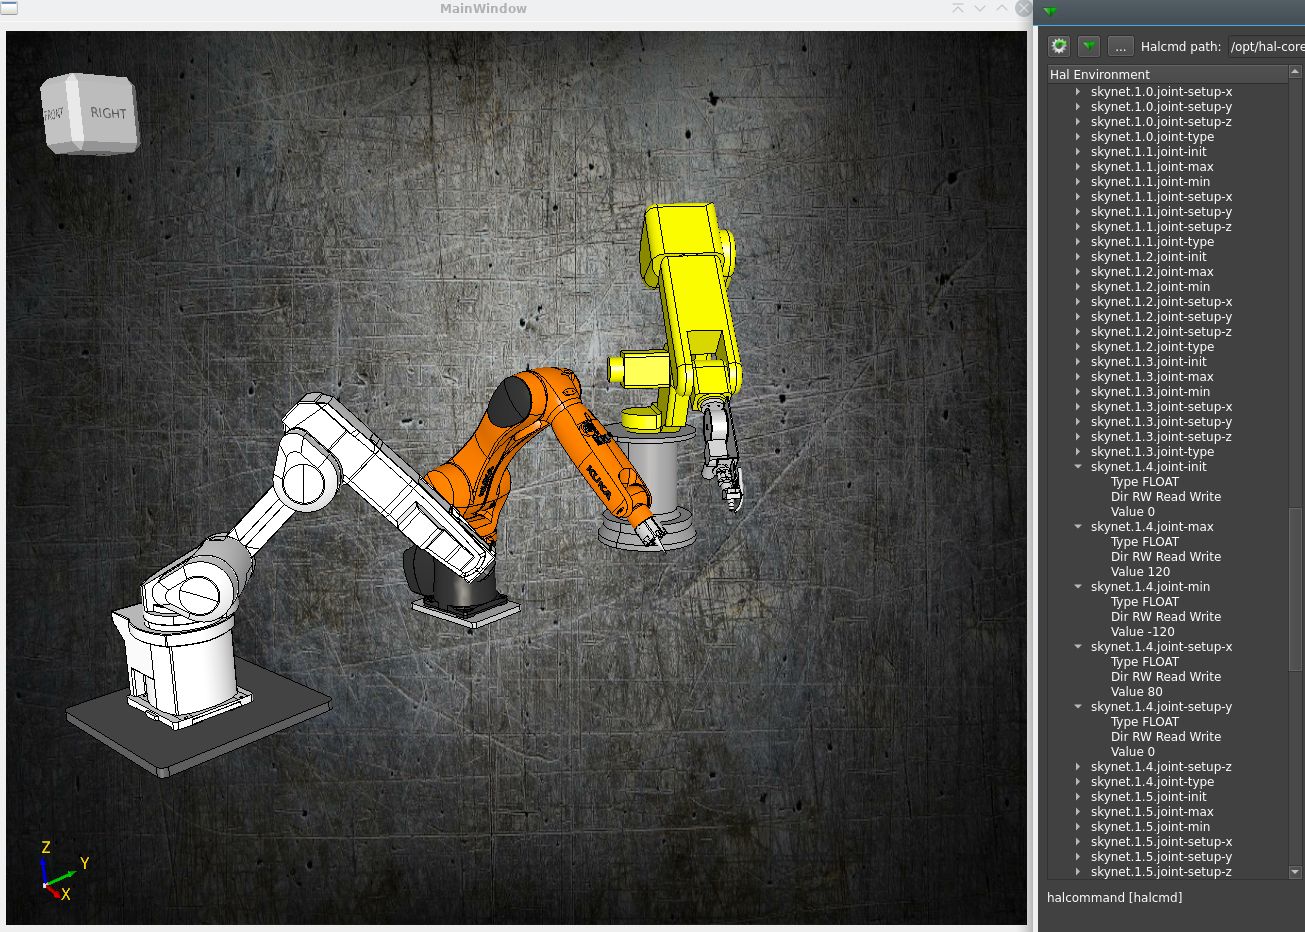
Just a hal-core update. 


I started coding from the bottom trough hal, kinematics and opencascade.
A few day's are past.

What i learned is to use dynamic memory allocating in a c coded hal component.
Then i was able to setup a dynamic realtime program. Where you can add multiple robots or gantry's at the same time.
The shape of the machine doens't matter. The machines may even be stacked to each other. The kinematics models can be
stacked and moved around in 3d realtime, connected to the previous 3d node in hal this is possible.
This is really a crazy program.

All my previous code was not dynamic in c. Also the kinematic c++ code was not dynamic for a machine setup.
As far as i am now, This is becoming amazing.

I had to apply some rules to the hal setup, like how do you call machine 0 and machine 1?
How do you organize stepfiles for different models to load etc.
The following user(s) said Thank You: tommylight

Please Log in or Create an account to join the conversation.
More
4 years 11 months ago #225957 by Grotius
Replied by Grotius on topic hal-core
Hi,


This is really a crazy program.

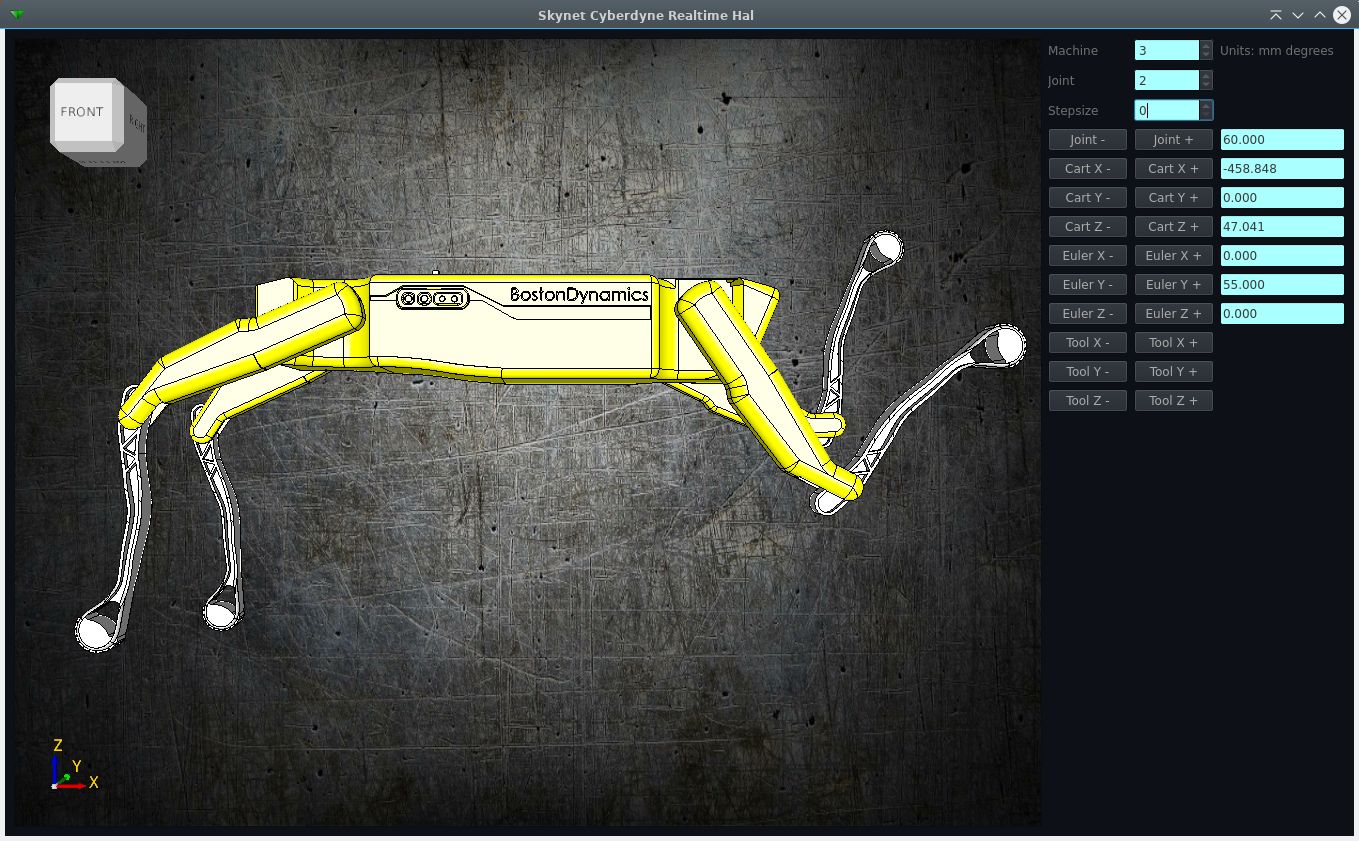
This is a hal-core example of a boston dynamics robot dog. It is equiped with a stack of 4 dynamic kinematic chains.
Each chain representing a dog's leg. The dog can be equipped with secundairy robots on his back wich are slave nodes, connected by 6 hal parameters. Translation + 3d rotate.

The robot dog can perform a s-curve motion profile for the leg's. I think this is a proof of concept hal-core is working dynamicly and
can do complex tasks.

Next item to test is a chirurgical robot operation implementation with hal-core.
By this i mean 2 robot humaniod hands reflecting the real human positions. The data is then transferred trough a internet connection. So i have to make a internet interface for hal-core.

 
The following user(s) said Thank You: tommylight

Please Log in or Create an account to join the conversation.

More
4 years 11 months ago #225964 by tommylight
Replied by tommylight on topic hal-core

Next item to test is a chirurgical robot operation implementation with hal-core.
By this i mean 2 robot humaniod hands reflecting the real human positions. The data is then transferred trough a internet connection. So i have to make a internet interface for hal-core.
This i am interested in.

Please Log in or Create an account to join the conversation.

More
4 years 11 months ago #225995 by Reinhard
Replied by Reinhard on topic hal-core
Hi Grotius,

I'd like to know, how much linuxcnc do you use?

If I got you right, you said, that you don't use nml - so you probably don't use interpreter and taskmanager.
... and if that is true, how do you do jobs like jogging, touch workpiece, measure toollength or set coordinate systems?
Afaik they are all nml-based.
The following user(s) said Thank You: Grotius

Please Log in or Create an account to join the conversation.

More
4 years 11 months ago #226026 by Dave3891
Replied by Dave3891 on topic hal-core
Hi Grotius,
That is looking really great! There will be a lot more automation applications that it could be use on.

I am away from the shop this week so I won't be able to look at the modifications until next week, but at the rate you are going it will have changed by then haha.

Keep posting updates!
The following user(s) said Thank You: Grotius

Please Log in or Create an account to join the conversation.

Time to create page: 0.361 seconds
Powered by Kunena Forum
