Hi,
A tiny update. The gcode runner is now captured on video.
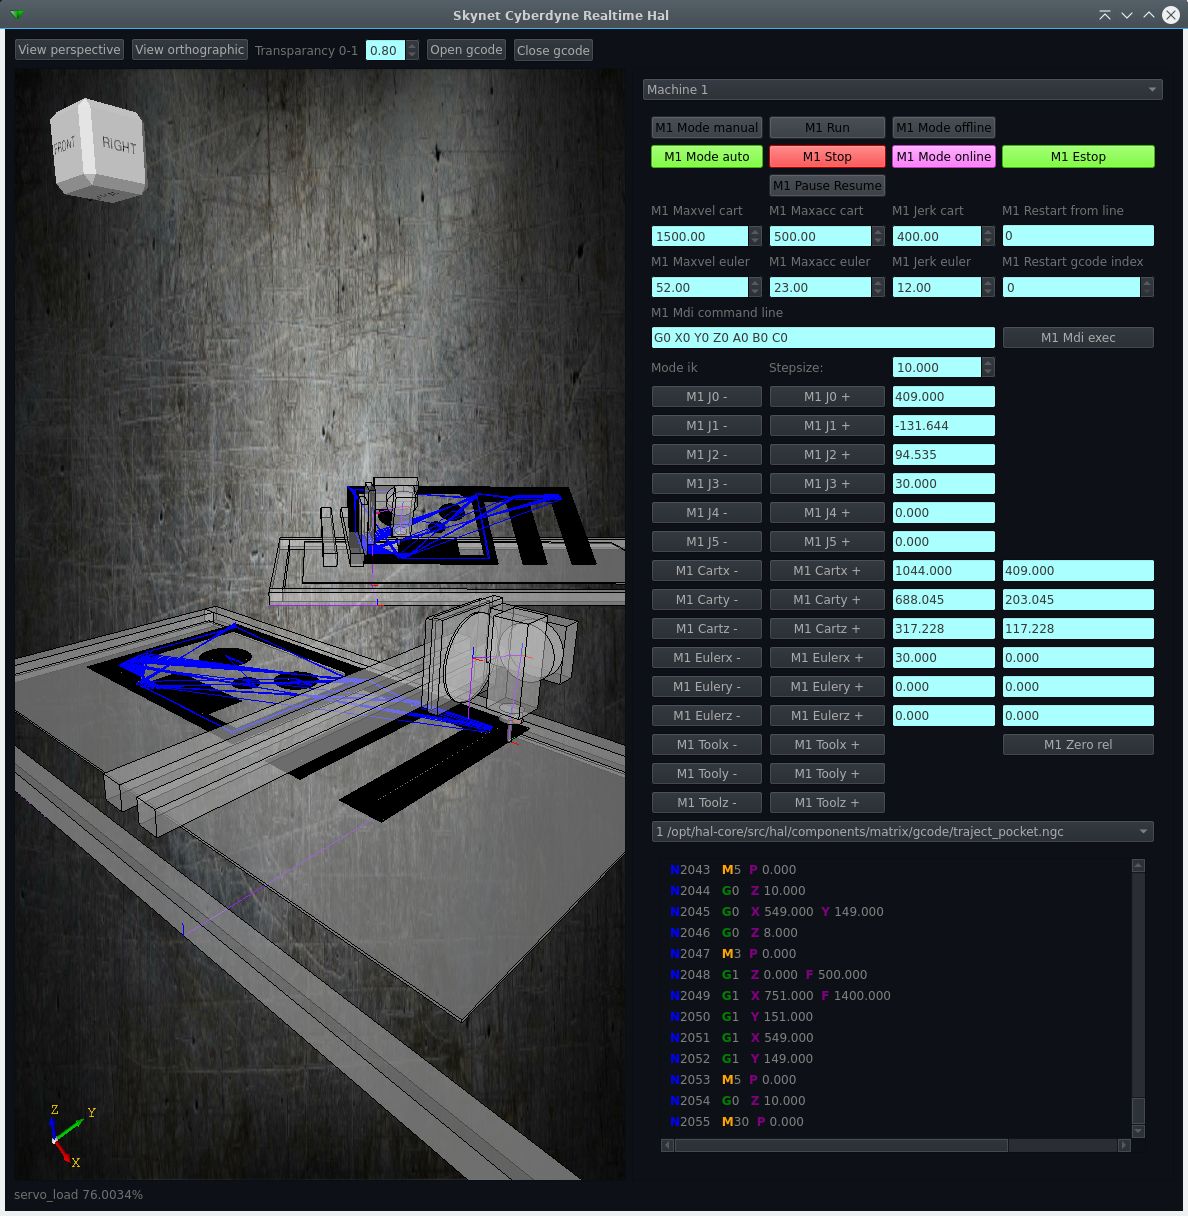
The program has loaded a standard .ngc gcode file. This file is then placed in 3d on the machine table.
The machine has to follow. If you have a good look at the path's you can see the path follow error is visible.
This is when the joint velocity, acceleration and jerk are set to low. In fact the machine xyz speeds are to high. But
nice to mention this.
Then there is no path optimization for the end velocity at the moment. It now stops at every gcode line. This off course
has to change.
a image missing /media/kunena/emoticons/unsure.png video:
user-images.githubusercontent.com/448801...94b-2b6bf52af1aa.mp4
The servo-load, lower left of the window, is glad not ticking far over the 100% load.
I have a old pc. So it can not get much worse than this.
And a video of doing a gcode pocket program. 2000+ gcode lines to being exec. for each machine.
a cool image missing /media/kunena/emoticons/w00t.png video:
user-images.githubusercontent.com/448801...308-38a88b8f102a.mp4