hal-core

More
4 years 10 months ago #229263 by Dave3891
Replied by Dave3891 on topic hal-core
Hi Grotius,

Thank you for the explanation, it makes a lot more sense now.

Looking at that example, am I right in assuming that velocity and acceleration and speed are either handled with the stepgen module or by feeding in small chunks of movements to the kinematics module?
I did not see any speed/velocity pins in the kinematics module so I am assuming that it takes the XYZ request and gives the J0-J5 end positions instantly?

Sorry for all the questions.


Please Log in or Create an account to join the conversation.

More
4 years 10 months ago #229557 by Grotius
Replied by Grotius on topic hal-core
Hi Dave,

Looking at that example, am I right in assuming that velocity and acceleration and speed are either handled with the stepgen module or by feeding in small chunks of movements to the kinematics module?
Yes, stepgen handles that in the example.

I did not see any speed/velocity pins in the kinematics module so I am assuming that it takes the XYZ request and gives the J0-J5 end positions instantly?
Yes, the kinematics only calculates the positions visa versa.

For hal-core i am busy with the scurve library for several day's now.
The ruckig scurve lib has some problems:
  • In a realtime 1ms kernel powered thread bringing back the current velocity to 0.001 will crash at longer paths.
  • End velocity accuracy out of control when crossing waypoints.
  • When end velocity can not be reached, ruckig end velocity value is 0 instead of value at end of path.
My own scurve lib is able to cross the waypoints with perfect endvelocity. But... it had no realtime velocity transition
under the hood.

So i started for the third time coding my scurve lib.
Now hoping to get everything ok within a few day's. I think i make a flag so lineair transition can be added in the
scurve between the concave and convex period. This makes the machine even faster as a normal scurve.
A period of lineair transition is all the time "2* max acceleration".

The picture shows the front curve, using a concave and convex period.
The curve can do a acceleration start value, and a acceleration end value.
I am coding it as stand alone c/c++ compatible library.





Please Log in or Create an account to join the conversation.

More
4 years 10 months ago #229559 by Grotius

Please Log in or Create an account to join the conversation.

More
4 years 10 months ago - 4 years 10 months ago #229577 by Dave3891
Replied by Dave3891 on topic hal-core
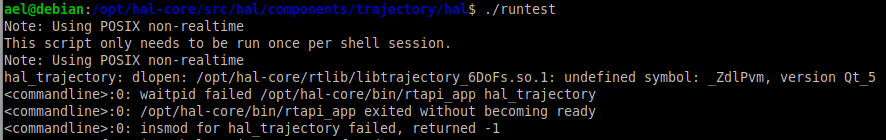
Figured out the problem, had to install the qtcreator deb from your github since it was looking for the library in the /opt/qtcreator directory


Hi Grotius,

Have you ever seen this error? I started getting it after I installed Qt Designer (5.15) and I am not sure what I need to do to correct it


Last edit: 4 years 10 months ago by Dave3891. Reason: fixed problem

Please Log in or Create an account to join the conversation.

More
4 years 10 months ago - 4 years 10 months ago #229719 by Grotius
Replied by Grotius on topic hal-core
Hi Dave,

The quickest way to solve this, is to recomplie the qt part of trajectory component with your qt version.
This type of errors can be caused by a qt library change. Or it can not find the qt libraries.
You can add a : ldconfig ./ path to qt library in the trajectory startup script.
Last edit: 4 years 10 months ago by Grotius.

Please Log in or Create an account to join the conversation.

More
4 years 10 months ago #229781 by cakeslob
Replied by cakeslob on topic hal-core
Hey grotius, a few questions. the s curve hal component for syncdof, would you use that within linuxcnc to achieve s curve acceleration smooth accel/decel but while maintaining the linuxcnc path planning?

also, what does it mean, "30 days trial mode", im afraid to ask...  

Please Log in or Create an account to join the conversation.

Time to create page: 0.619 seconds
Powered by Kunena Forum