Allow infinite acceleration/speed on one axis

More
9 years 9 months ago - 9 years 9 months ago #86344 by Stunning_Rob
You can see a few pics of my setup here:

www.instructables.com/id/Add-Laser-Etchi...ities-to-a-CnC-Mill/

I wrote about adding the laser so I could mill and engrave within the same coordinate system. It is working really well for vector engravings so I recently started trying to engrave images and that's where I'm at now.

The 3d printed housing really doesn't add that much weight to the Z-axis since the majority of it is 8mm HDPE plastic, so I don't think my adding the laser + housing made my bearing issue much worse. It was destroying bearings at about the same rate before I added the laser (once per year or so), but only since trying to raster engrave did I kick up the velocity to around 1500mm/min and that's when the bearing went bad after about 2 months of that, so I dialed it way back down.

Anyways I can beat all the cool kids and their laser cutters since they cry when material gets over 5-8mm thick but I laser etch whatever I want then mill through any piece of wood I can fit under my Z-axis (about 30mm).
Last edit: 9 years 9 months ago by Stunning_Rob. Reason: Edited for clarity.

Please Log in or Create an account to join the conversation.
More
9 years 9 months ago #86347 by andypugh

Stunning_Rob wrote: Can't explain that yet, maybe the order of loading hal components matters?


The order that components are loaded is not important, but the order that they are added to the servo thread matters.
You should read inputs, then do calculations, then write outputs.

You can actually add a number to the end of an "addf" command to force a position in the thread sequence. positive numbers from the top, negative numbers from the bottom.

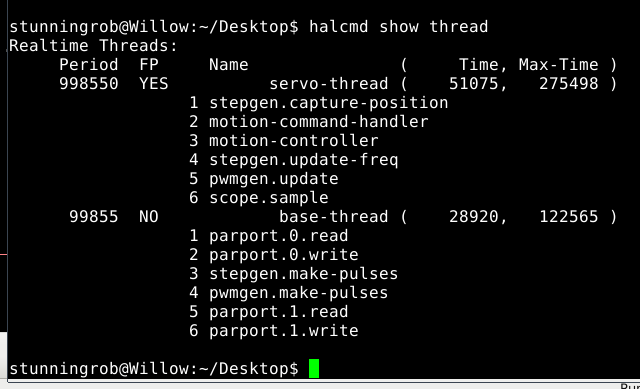
With Linuxcnc running you can run the command "halcmd show thread" in a terminal to get a list of the functions and the order they are executing. Make sure that they are in the read-process-write ordering.

Please Log in or Create an account to join the conversation.

More
9 years 9 months ago #86375 by Stunning_Rob
Andy,

Thanks for the heads up about the loading order. I've never adjusted it before. Here's what I have now:


For the servo thread I'm not sure if anything there needs to be reordered?

For the base thread, should I reorder it to load as follows:
parport.0.read
parport.1.read

stepgen.make-pulses
pwmgen.make-pulses

parport.1.write
parport.2.write

Its not much of an adjustment, but perhaps it matters as you've pointed out.

Note: I see that my servo thread 'max time' is less than my servo thread period, while the same is not true for the base thread (122k vs 100k). Perhaps this is potentially where the random flutter I am getting on M67 commands is coming from? I've never adjusted or worried much about these values as the machine has worked well for cnc and vector engraving, but maybe now that I'm doing raster the max-time in the base thread is causing me some problems?

Please Log in or Create an account to join the conversation.

More
9 years 9 months ago #86378 by andypugh
You might be able to move parport.read to the servo thread if you are not reading encoders.
The following user(s) said Thank You: Stunning_Rob

Please Log in or Create an account to join the conversation.

More
9 years 9 months ago #86380 by tommylight
Rob mind the port numbering, as you wrote it it will not work, it has to be same for read and write.
In your case read0 and write0, read1 and write1.
paraport0 is always the first paraport1 is the second etc.
The following user(s) said Thank You: Stunning_Rob

Please Log in or Create an account to join the conversation.

More
9 years 9 months ago #86443 by Stunning_Rob
Gentlemen,

Here's what I have so far:


Question: Does the (updated -> Thanks for the tip, no encoders here!) servo and base thread order of operation make sense now? I rearranged the load order by numbering the addf line (thanks for that tip also) to arrive at this order, but only because it made logical sense to me.

Read both parallel port cards, do stuff, write to both parallel ports.

Please Log in or Create an account to join the conversation.

Time to create page: 0.103 seconds
Powered by Kunena Forum
