ASD-A2 EtherCAT on LinuxCNC

More
6 years 3 weeks ago #185441 by jirkam
Replied by jirkam on topic ASD-A2 EtherCAT on LinuxCNC
Hello.
No.
I have: 750W Delta servo motor ECMA-CA0807RS with absolute encoder and Delta driver ASDA A2-E EtherCAT.
Thanks Jirka
The following user(s) said Thank You: tommylight

Please Log in or Create an account to join the conversation.

More
6 years 3 weeks ago - 6 years 3 weeks ago #185723 by chimeno
Replied by chimeno on topic ASD-A2 EtherCAT on LinuxCNC
Hello @jirkam
I'm sorry I have never worked with the ASDA driver, I use the BECKHOFF, I attach the screenshots made with your "latest1200.ngc" file in case it can help you,


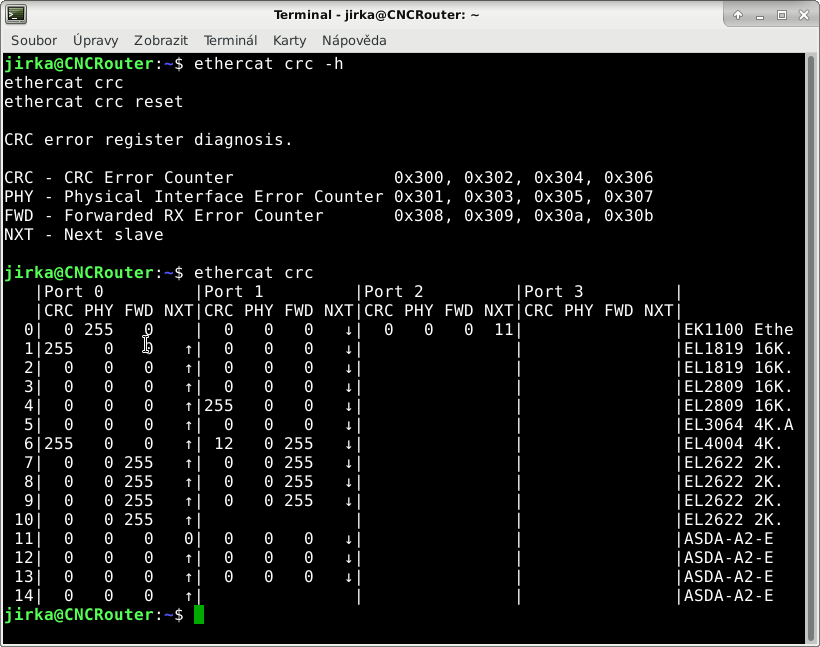
the problem of the communication of only SYNC0 is not so important at low speeds, simply that when linuxcnc accesses your device, it does it in a click or two, let's say until the frames are found again. One way to see it is with the cross-device error log with the command,
Code:
ethercat crc


if you have problems with synchronization, you will have to use the patches included in linuxcnc-ethercat
github.com/sittner/linuxcnc-ethercat/tree/master/patches


greeting
Chimeno
Last edit: 6 years 3 weeks ago by chimeno. Reason: Edit: Pathes

Please Log in or Create an account to join the conversation.

More
6 years 3 weeks ago #185749 by jirkam
Replied by jirkam on topic ASD-A2 EtherCAT on LinuxCNC
Hi, chineno.
Thank you very much for the pictures.
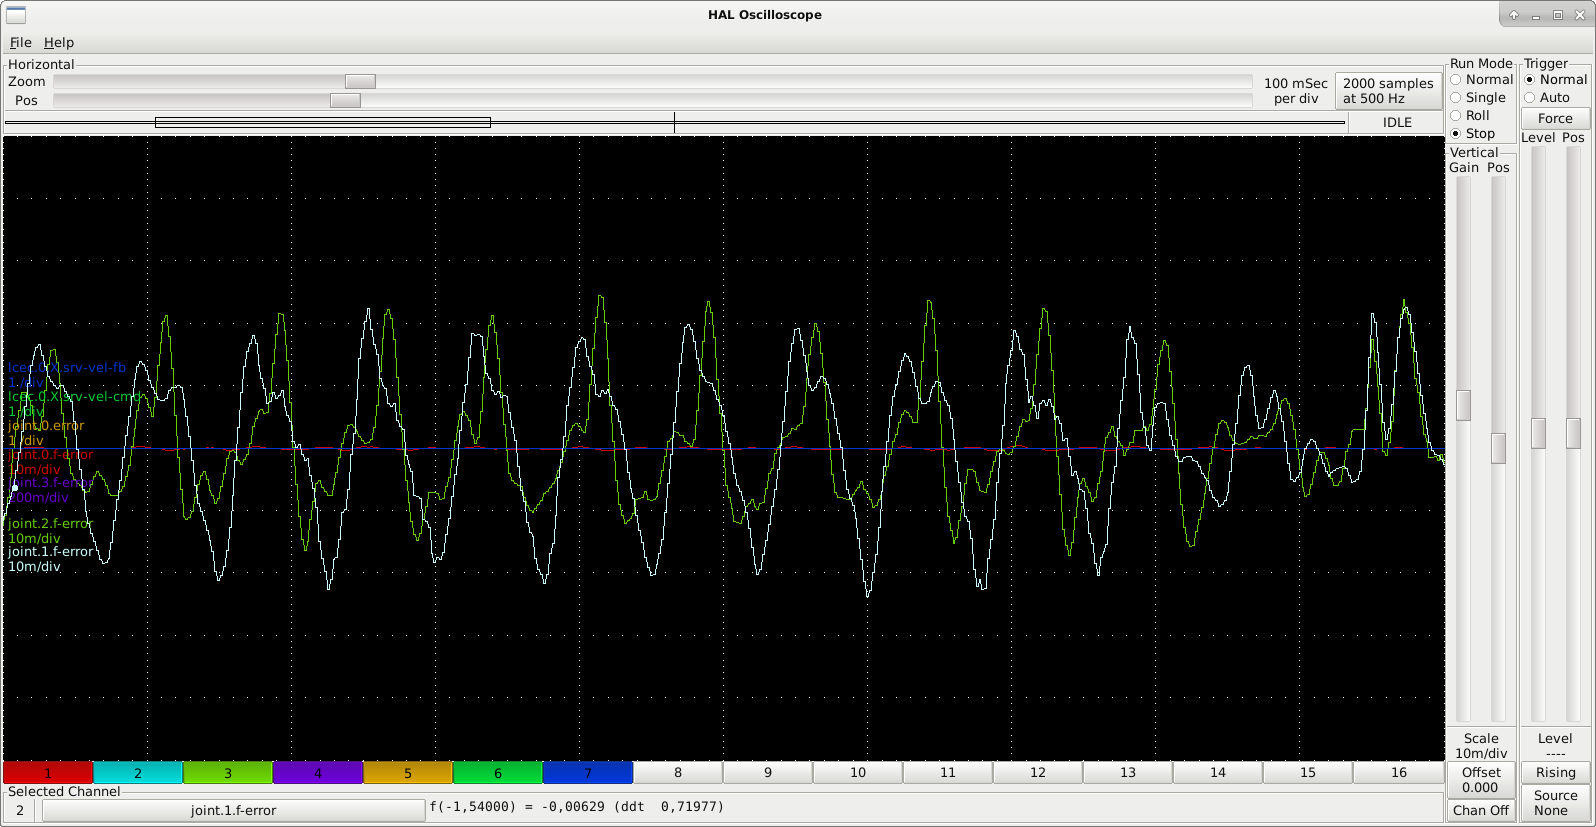
What was the error in the oscilloscope?

Is it even realistic to achieve a better result than 0.002 mm with Delta?

I discovered new facts.
The X axis is ok. There is an error of 0.0025 mm. See "result.png


But for the Y-axis (gantry), I found that both servos were arguing. At least I think according to the picture "2xY.png". It is at a manual crossing of 18000mm / min. The eye can see how the portal vibrates.


I don't know how to set it up to improve.
Due to inaccurate combs I have to use Y1.comp file and Y.comp file. And it will be more complicated.

Thank you so much for the ideas.
Jirka
The following user(s) said Thank You: chimeno

Please Log in or Create an account to join the conversation.

More
6 years 2 weeks ago #185813 by jirkam
Replied by jirkam on topic ASD-A2 EtherCAT on LinuxCNC
Hello.

About ok.


Jirka
The following user(s) said Thank You: chimeno

Please Log in or Create an account to join the conversation.

More
6 years 2 weeks ago - 6 years 2 weeks ago #186122 by chimeno
Replied by chimeno on topic ASD-A2 EtherCAT on LinuxCNC
Hello @jirkam

What was the error in the oscilloscope?

I did the tests with new servos, the error was 0.0155, I have not adjusted the servos.

Is it even realistic to achieve a better result than 0.002 mm with Delta?

the truth is that I get better results with PID in linuxcnc at high speeds I think not,

El eje X está bien. Hay un error de 0,0025 mm. Ver "result.png

it's very good!

But for the Y-axis (gantry), I found that both servos were arguing. At least I think according to the picture "2xY.png". It is at a manual crossing of 18000mm / min. The eye can see how the portal vibrates.
I don't know how to set it up to improve.
Due to inaccurate combs I have to use Y1.comp file and Y.comp file. And it will be more complicated.

Thank you so much for the ideas.

I did not realize that you were using a gate with 2 motors, I find it quite difficult to configure two PIDs to feed 2 motors at the same time and that its precision is extreme, I think that if you need such precision you could try to re-set the controller mode and go to position mode, leaving the PID in the servo drive, and the portico having a master motor and another slave, all configured in the servo drive, leaving linuxcnc free of heavy load. I'm not an expert and there are so many guys on the forum that you sure have a better idea


have you used it as
Code:
ethercat crc
while servos are in OP, working? If so, you have no problems with errors in frames, although you can still try to place the ASDAs first and then leave the inputs / outputs..


I'm sorry I'm not much more helpful

Greeting
Chimeno
Last edit: 6 years 2 weeks ago by chimeno.

Please Log in or Create an account to join the conversation.
More
6 years 2 weeks ago - 6 years 2 weeks ago #186128 by jirkam
Replied by jirkam on topic ASD-A2 EtherCAT on LinuxCNC
Hello.
Thanks for the information and for your opinion.
I try to avoid switching to position control. Because I don't know how to do it. I'm a linuxcnc amateur.

I cannot use the "master-slave" servo control. The toothed combs are very inaccurate and I have to use "COMP_FILE" Y1.comp and Y2.comp.
And if I understood the "master-slave" servo control well, I don't think COMP_FILE will help me.

Yes, I tried "ethercat crc" when spiral milling.

Thanks so much for your time.
Jirka
Last edit: 6 years 2 weeks ago by jirkam.

Please Log in or Create an account to join the conversation.
Time to create page: 0.552 seconds
Powered by Kunena Forum
