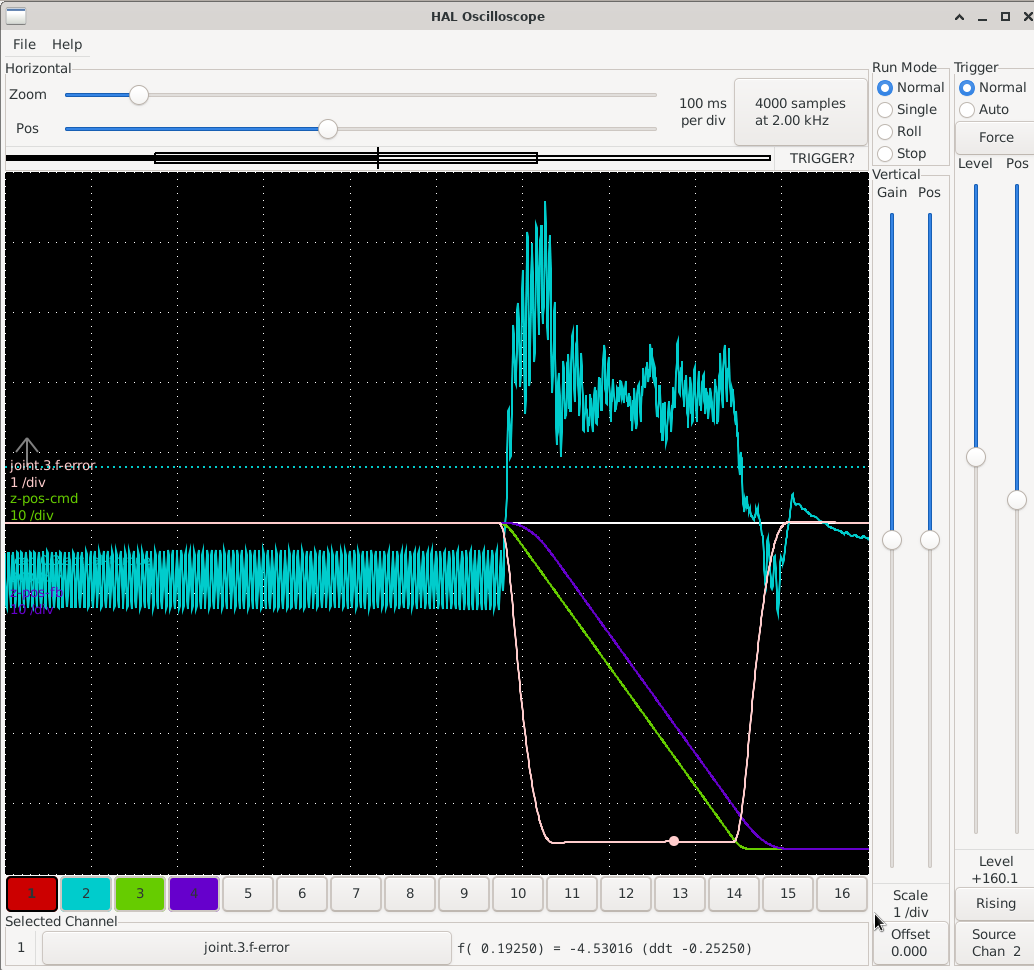
@andypugh I started from the Marco Reps config. Everything is working as intended except for the delay/following error in the servo drive. I suspect the error to be within the drive, but I uploaded the configs as I am no LinuxCNC EtherCAT professional, and there is always the possibility of some stupid errors. The drive-internal parameter for following error is staying at 0. It is always exactly 0, so that could be a bug as well.
@PCW I tried CSV mode (without success, as the problem seems to be there as well but with different symptoms), and within the scope I can see the first reactions to the control signal within 3–4 ms. So I suspect EtherCAT is running fine and without (or at least with a very small) delay. I think I can confirm the existence of some form of filter, as acceleration values of 10,000–20,000 mm/s² are smoothed out a lot compared to a similar machine with 1 kW servos with step/dir signals.
Regarding the poor position loop – I have had settings without this oscillation, but I was trying around with pretty much all settings within the drives and was at the point of giving up when taking the screenshot. All plots without oscillations had similar bad following errors.
@Hakan Switching to CSV mode and including LinuxCNC within the feedback loop was reported successful by other users, but I was not able to get it working with a following error of <<0.5 mm. As including LinuxCNC within the feedback loop creates many more parameters to be tuned (LinuxCNC PID and parameters within the drives), that turned out to be a very time-consuming project without any real success.All in all, the Lichuan support was very unhelpful, and after trying to tune just one of the four drives (Z-axis first) for about three days, I am thinking of ditching the Lichuan drivers and motors and using Leadshine servos. If there are any ideas, I am open to trying almost everything

Thanks in advance.Alex