Advanced Search

Search Results (Searched for: )

  • vre
  • vre
Today 17:29
Replied by vre on topic Mesa modbus and pktUart

Mesa modbus and pktUart

Category: Other User Interfaces

Link with latest src ?
  • Dudelbert
  • Dudelbert
Today 17:05
Replied by Dudelbert on topic I Made a CAM Program for My Lathe (AI Made It)*

I Made a CAM Program for My Lathe (AI Made It)*

Category: CAD CAM

First of all, thanks for the kind words! I was a little worried that I might get some grief for having made this with AI, but so far that doesn't seem to be the case.

Regarding threading, what exactly are the capabilities you would like to see?

I hadn't considered tapered threads at all, but I've received feedback that this is a missing feature.
As I understand it, this should be possible using a G33 spindlesynchronised move. I don't have any first-hand experience with this, but I think it should be possible to implement most of the G76 functionality, more or less, while also allowing for a taper.

Would that cover what you're looking for?

I'm happy to implement new features, but adding functionality that I don't fully understand or have any experience using will leads to poor usability, or worse.
  • NWE
  • NWE's Avatar
Today 14:38

PancakeSlicer, a Self-hostable and Non-planar 3D Printer Slicer on OrcaSlicer en

Category: Additive Manufacturing

I raised an issue on GitHub, they responded and removed the 15 minute slicing timeout on the desktop version of Pancake Slicer.
  • Sviper
  • Sviper
Today 14:22

LCNC-Cyclo: Conversational Programming for LinuxCNC

Category: Other User Interfaces

Hi, thanks a lot for the kind words!

Tech stack: It’s plain Python 3 with PyQt5. It’s a standalone display, not QtVCP or QML. It talks to LinuxCNC through the regular linuxcnc Python module and is set as DISPLAY in the INI file. The conversational programs are translated into normal LinuxCNC G-code by a separate translator. The cycles are plain .ngc subroutines. The simulation (material removal, machine model, collision checks) uses numpy.

LinuxCNC itself is only changed in a very small way. So far the only addition is a new kinematics module for my machine: src/emc/kinematics/xyzbh-kins.c (XYZ plus a B swivel head parallel to Y). It can switch between direct axis mode and TCP via switchkins. Everything else is standard LinuxCNC.

Cycles: All cycles were written completely from scratch, and no code from other projects went into them. That also means they are still at a first-iteration stage. They will most likely need a few more rounds of refinement, and later on help from testers to improve them.

Testing: Not yet, sorry. First I want to reach a state where my own test machine runs safely and has all the basic functions you need for productive work. That doesn’t mean every cycle is fully tested, but the essentials have to be there. Once that’s done, I’ll open it up, and beta testers will be very welcome.

Open source: Yes, definitely. The whole project will be released as open source, including all modules, subroutines and cycles, so it’s freely available to everyone. Since it’s based on LinuxCNC, it will follow LinuxCNC’s licensing (GPL). The repository will go public at the same time as the first test version.

Language: The UI has already been translated into English, and the English help/documentation will follow soon.

I’ll post updates here as things progress on the real machine.

Best regards
  • Hakan
  • Hakan
Today 13:09 - Today 13:12

StepperOnline A6 EtherCAT – Servo-Tuning unter LinuxCNC / Hoher Schleppfehler

Category: EtherCAT

Siehe hier für ecatsetup: forum.linuxcnc.org/ethercat/59377-new-ex...ental-ethercat-layer
Servo-Tuning ist in der neuen Version 0.21 enthalten.

`ecatsetup` scannt den EtherCAT-Bus, generiert die Konfiguration für LinuxCNC und ermöglicht das Lesen und Schreiben von SDOs. Es enthält außerdem einen Testmodus für Antriebe.

Der neue Reiter "Response" bewegt die Achse vor und zurück und analysiert den folgenden Fehler in seine Komponenten: Buslatenz, Sollwertfilterung, Positionsregelschleife (v/Kp) und Beschleunigungskomponente.

Das Tool zeigt relevante Parameter für den Antrieb an. Sie können einen Wert ändern (nur im RAM), den Test erneut ausführen und die Ergebnisse vergleichen.

Voraussetzungen: LinuxCNC 2.10 (läuft im "Run-in-Place"-Modus; Version 2.9 funktioniert nicht, aber ecat usw. können problemlos parallel zu 2.9 ausgeführt werden, ohne die bestehende Konfiguration zu beeinträchtigen) und mein EtherCAT-Master im Benutzermodus - im Gegensatz zum Kernel-basierten Master und `lcec`.
Alles befindet sich noch im experimentellen Stadium. Ich selbst besitze kein A6-Laufwerk, daher wären Sie der Erste, der es damit testet.

Download: github.com/MetalMusings/ecat/releases/tag/ecat-v0.21 (Master: github.com/MetalMusings/ethercat/releases/tag/uspace-v1.5)
Anleitung (auf Englisch): github.com/MetalMusings/ecat/blob/main/d...o-drive-step-by-step
und github.com/MetalMusings/ecat/blob/main/docs/getting-started.md
Ich helfe Ihnen gerne bei Problemen beim Testen Ihres A6-Laufwerks.
  • laurentl38
  • laurentl38
Today 13:08
Replied by laurentl38 on topic I Made a CAM Program for My Lathe (AI Made It)*

I Made a CAM Program for My Lathe (AI Made It)*

Category: CAD CAM

I’ve just tested your software, and it’s brilliant—it’s exactly what I need to use right next to the machine in the workshop, so I don’t have to keep going back and forth between the office and the shop floor.

Personally, I don’t have the technical skills to implement this myself, but if you have the time and the inclination, it would be fantastic to add a feature for creating threads with custom profiles—something along the lines of this software, RopeCAM (www.cenic.fi/english/ropecam/).

In any case, thanks again for such great work!
  • Hakan
  • Hakan
Today 12:52
Replied by Hakan on topic New experimental ethercat layer

New experimental ethercat layer

Category: EtherCAT

0.21 Servo tuning release

- Servo tuning workflow added to ecatsetup

Workflow for tuning settings of closed loop stepper motors and real servo drives added.
Check out github.com/MetalMusings/ecat/blob/main/d...o-drive-step-by-step instead of me copying everything.
The function of a StepperOnline A6 servo was programmed in my own EaserCAT card and used for feed-forward tests.
The servo manual was the basis for this. Of course some aspects are impossible to bring in like mechanical properties.
But registers and responses were implemented reasonably enough that a real servo has a big chance to work in this workflow.
Also tested on real ECT60s and following errors were reduce by 2/3. Reducing the command filtering x2009:00 was the (surprising) key there.

Ihavenofish, do that, with some right. 
Just waiting for you to start testing and commenting now

 
  • ihavenofish
  • ihavenofish
Today 12:20
Replied by ihavenofish on topic New experimental ethercat layer

New experimental ethercat layer

Category: EtherCAT

Sometimes things just need a fresh perspective and a kick in the butt.

I will pretend my endless ranting has helped.

:P

Thanks for this. And to all the others making headway on fundamental features.
  • CADdy
  • CADdy's Avatar
Today 11:15
Replied by CADdy on topic Change cursor color and thickness

Change cursor color and thickness

Category: Qtvcp

Thanks a lot!
The “qproperty-styleColorCursor” entry wasn't there. I added it and set the color. It works perfectly—thank you very much for the tip.

Peter
  • PCW
  • PCW's Avatar
Today 10:12
Replied by PCW on topic Mesa modbus and pktUart

Mesa modbus and pktUart

Category: Other User Interfaces

Here is a pinout file for a 7I96S with a V3 PktUART

( The latest source build the select version based on the version number in the pinout file
make sure you have the latest source )

File Attachment:

File Name: PIN_7I96SD_PKTV3.zip
File Size:3 KB

 
HOWEVER:

Unfortunately, The issue with 25IOC32's seems to be in their firmware, that is, they seem to crash
randomly every couple of days regardless of the interface method. The reason I think it's a firmware issue
is that the only recovery method that works is to reset/power cycle  the  25IOC32. This is with differing
interface methods...

It may be that they were never tested with continuous communications, not sure.
  • MarkoPolo
  • MarkoPolo
Today 09:35
Replied by MarkoPolo on topic Change cursor color and thickness

Change cursor color and thickness

Category: Qtvcp
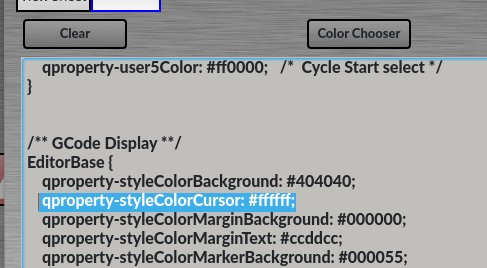
You can change the color in the stylesheet

   
  • CADdy
  • CADdy's Avatar
Today 08:26
Change cursor color and thickness was created by CADdy

Change cursor color and thickness

Category: Qtvcp
Hi all,
is it possible to change the color and width of the editor cursor in QTDragon HD? The cursor is barely visible.


Peter
 
  • Maho400P
  • Maho400P
Today 08:24

StepperOnline A6 EtherCAT – Servo-Tuning unter LinuxCNC / Hoher Schleppfehler

Category: EtherCAT

Hello, i will be the next free rider on this subject.

I just got my book, hopefully relevant on this subject:
Callum Drexler, 2026, Industrial Ethercat Motion Control Explained, achieving Ultra-Low_Latency servo synchronization for precision manufacturing.
ISBN 9798188540975
  • tommylight
  • tommylight's Avatar
Today 08:02

A mill with 3 x 750 W 230 V drive on one phase or every drive on another phase

Category: General LinuxCNC Questions

It makes no difference at all.
All drives will turn the input AC power to DC first, then do the PWM and out it to the motor.
I have both versions in use, i never noticed any variation between them.
The only situation you would be better to use 3 phases is if the machine has an input transformer, that will share the load between windings.
Displaying 1 - 15 out of 290230 results.
Time to create page: 3.210 seconds
Powered by Kunena Forum