Advanced Search

Search Results (Searched for: )

  • tommylight
  • tommylight's Avatar
29 Oct 2026 21:27
Replied by tommylight on topic Lenovo T490 Laptop Tuning issues

Lenovo T490 Laptop Tuning issues

Category: General LinuxCNC Questions
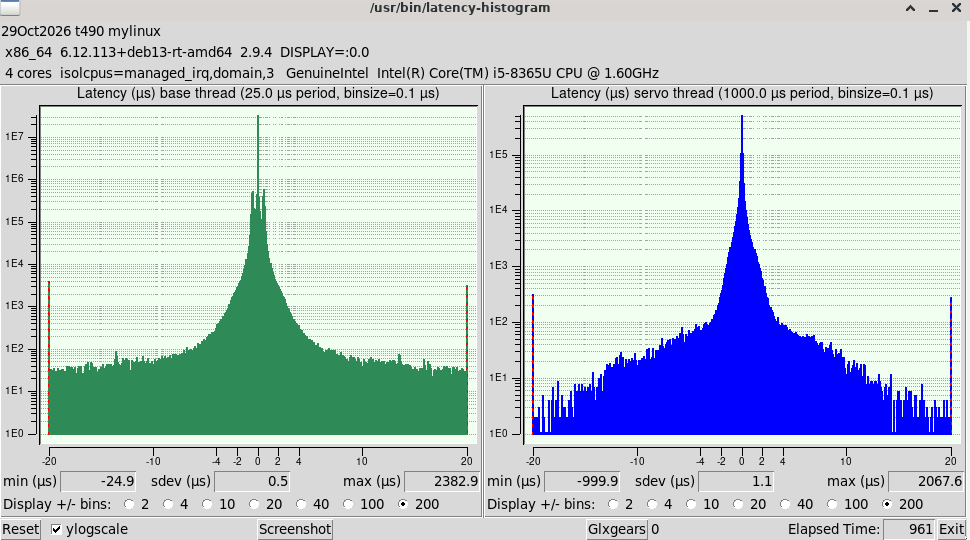
latency-histogram --nobase --sbinsize 1000 --show
  • CNCJIM
  • CNCJIM
29 Oct 2026 20:55
Replied by CNCJIM on topic Remora with STM32H753ZI

Remora with STM32H753ZI

Category: Computers and Hardware

I was just getting an urge to buy a Flexi-Hal Expatria Technologies card but this might be a better choice over a STM32F446. BigTreeTech Scyllia V.1 - correct - is there a github for the software?
  • FabLabRacing
  • FabLabRacing
29 Oct 2026 20:50

FabScan - LinuxCNC Camera-Assisted Tracing / Scanning Project

Category: Plasma & Laser

I would expect FabScan to run on a Pi 5 with 8GB RAM without any major performance issues.

FabScan is written primarily in Python and uses OpenCV for camera processing. LinuxCNC handles the actual motion control, so FabScan itself doesn't have any hard real-time requirements.

That said, I haven't tested it on ARM hardware yet. All my development and physical testing has been on a Dell OptiPlex running LinuxCNC with Mesa Ethernet hardware.

There may be some minor adjustments needed for Python dependencies and CPU affinity, since my current launch configuration is tuned specifically for that machine.

If you're interested in trying it, I'd be happy to help work through any compatibility issues. It would actually be very useful to have someone testing on different hardware.
  • CNCJIM
  • CNCJIM
29 Oct 2026 20:30
Replied by CNCJIM on topic Lenovo T490 Laptop Tuning issues

Lenovo T490 Laptop Tuning issues

Category: General LinuxCNC Questions

I have documented most of my prior setup. I will look for the live ISO images on the dowload page - I have a ventoy drive - its an easy thing to do.
so 2.8.4 first then.
  • mwc
  • mwc
29 Oct 2026 20:29
Replied by mwc on topic Ethercat drive configuration woes

Ethercat drive configuration woes

Category: EtherCAT

Yes.

The only thing I changed to test that XML snippet, was to remove the Z-axis stuff from the hal file, then paste that snippet in to replace the existing Z slave (slave 2) information.
The names used in my handcoded XML vary from the lcec_configgen names, so I can't do a straightforward copy and paste, but just running the XML with no hal parameter linking is enough to establish if the XML is good.

Ultimately if the XML is good, the ethercat slaves should be configured, even if hal makes no use of them.

It seems to be an error with how the ethercat PDOs are defined, but I've so far not found any kind of definitive guide about syncmanagers/PDOs, and what is expected.
  • CNCJIM
  • CNCJIM
29 Oct 2026 20:22
Replied by CNCJIM on topic Lenovo T490 Laptop Tuning issues

Lenovo T490 Laptop Tuning issues

Category: General LinuxCNC Questions

The latency-histogram is not a good one -   It is from today after I turned on the wifi adapter and Thunderbird driver.   I had those shut off and the Ethernet as well in the Bios along with SD card io  -   I will recapture and start again with the drivers disabled -  root@t490:/home/mylinux# lspci -nnk | grep -iE "Ethernet|WiFi"
    Kernel driver in use: iwlwifi
    Kernel modules: iwlwifi
00:1f.6 Ethernet controller [0200]: Intel Corporation Ethernet Connection (6) I219-LM [8086:15bd] (rev 30)
root@t490:/home/mylinux# 
So those are the controllers - but the Intel Ethernet module is not loaded.  

The power has been throttled back on each boot via a service .  root@t490:/home/mylinux# cat /usr/local/bin/cnc-bench-init.sh 
#!/bin/bash
# Enable thinkpad_acpi fan control and lock to Level 7
echo "level 7" > /proc/acpi/ibm/fan

# Lock Intel RAPL sustained power limit to 15W (15,000,000 uW)
echo 15000000 > /sys/class/powercap/intel-rapl/intel-rapl:0/constraint_0_power_limit_uw

---  Where the default power is 25W   or 25000000  
The /etc/systemd/system/cnc-bench-init.service   -has to be created to get a systemctl  enable cnc-bench-init-service
to start at run time.      
oot@t490:/home/mylinux# systemctl status cnc-bench-init.service
○ cnc-bench-init.service - LinuxCNC Test Bench Power & Thermal Initialization
     Loaded: loaded (/etc/systemd/system/cnc-bench-init.service; enabled; preset: enabled)
     Active: inactive (dead) since Thu 2026-10-29 13:03:28 MDT; 1h 3min ago
 Invocation: e7cfed2c425b41528e32b456cbcf7ef6
   Main PID: 1019 (code=exited, status=0/SUCCESS)
   Mem peak: 1.8M
        CPU: 7ms

Oct 29 13:03:28 t490 systemd[1]: Starting cnc-bench-init.service - LinuxCNC Test Bench Power & Thermal Initialization...
Oct 29 13:03:28 t490 systemd[1]: cnc-bench-init.service: Deactivated successfully.
Oct 29 13:03:28 t490 systemd[1]: Finished cnc-bench-init.service - LinuxCNC Test Bench Power & Thermal Initialization.
root@t490:/home/mylinux# cat /etc/systemd/system/cnc-bench-init.service
[Unit]
Description=LinuxCNC Test Bench Power & Thermal Initialization
After=multi-user.target

[Service]
Type=oneshot
ExecStart=/usr/local/bin/cnc-bench-init.sh

[Install]
WantedBy=multi-user.target
root@t490:/home/mylinux# -
Summary - I did what I could - from my  Mesa 7i96 settup  there is a watchdog timer that defaults to 5ms -   And I do not know if this watchdog will cover my 1430000ns  servo thread jitter  and the 2500000ns base thread jitter.   
This is after all a laptop -and it has overhead and SMI's that are not completely managed. 
I have a PI400 that is politely running 65us servo thread jitter  and 125us base jitter.  And a Gigabyte B250-4E3 that has an i5-gen 10 with 4 cores/4 threads -  getting 16us servo thread jitter and 97us base thread.  So I have systems I can use with Mesa cards.  So my simple question-  can I run production jobs with this T490 and its 1.4ms and 2.5ms Jitter.  If the answer is no-  so be it.


  • mwc
  • mwc
29 Oct 2026 20:13
Replied by mwc on topic AMSAMOTION IO module

AMSAMOTION IO module

Category: EtherCAT

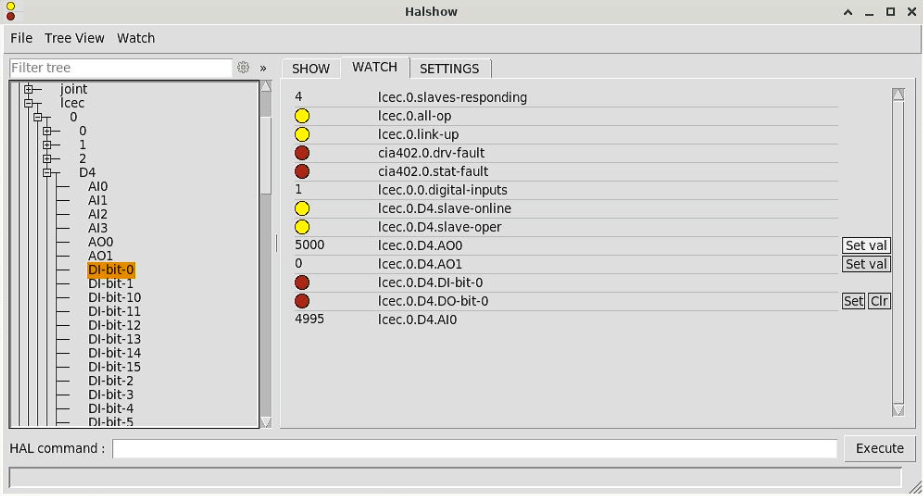
Well that was far less painful than I thought it would be.
AO0 looped back to AI0 gives comparable readings.
 

All it took was a bit copying and pasting, a few minor value edits, and I have the Analogue and Digital IO working with the following code-
<slave idx="3" type="generic" vid="0x00000b96" pid="0x00001400" name="D4">
      <!--EC1A-CORE1-->
      <syncManager idx="0" dir="in"/>
      <syncManager idx="1" dir="out"/>
      <syncManager idx="2" dir="out">
        <pdo idx="1601">
          <!--Digital Output process data mapping-->
          <pdoEntry idx="7010" subIdx="01" bitLen="16" halPin="DO-bit" halType="bit"/>
        </pdo>
        <pdo idx="1603">
          <!--Analog Output process data mapping-->
          <pdoEntry idx="7030" subIdx="01" bitLen="16" halPin="AO0" halType="u32"/>
          <pdoEntry idx="7030" subIdx="02" bitLen="16" halPin="AO1" halType="u32"/>
        </pdo>
      </syncManager>
      <syncManager idx="3" dir="in">
        <pdo idx="1a00">
          <!--Digital Input process data mapping-->
          <pdoEntry idx="6000" subIdx="01" bitLen="16" halPin="DI-bit" halType="bit"/>
        </pdo>
        <pdo idx="1a02">
          <!--Analog Input process data mapping-->
          <pdoEntry idx="6020" subIdx="01" bitLen="16" halPin="AI0" halType="u32"/>
          <pdoEntry idx="6020" subIdx="02" bitLen="16" halPin="AI1" halType="u32"/>
          <pdoEntry idx="6020" subIdx="03" bitLen="16" halPin="AI2" halType="u32"/>
          <pdoEntry idx="6020" subIdx="04" bitLen="16" halPin="AI3" halType="u32"/>
        </pdo>
        </syncManager>
    </slave>

Obviously doesn't include the ModBus stuff, but I have no use for that.
The lcec_configgen halPin naming did use duplicate names, and the unknown halTypes ( !!type 002e!! ) can be set to either bit or u32 depending on your own preferred usage. I've used bit for now.
  • tommylight
  • tommylight's Avatar
29 Oct 2026 19:50
Replied by tommylight on topic Ethercat drive configuration woes

Ethercat drive configuration woes

Category: EtherCAT

lcec: rtapi_app_main: Invalid argument (-22)
Is there a
loadrt lcec
line in the hal file?
If yes, there is something not right in that line.
-
This is just an educated guess from the error as i have no experience with EtherCat.
  • mwc
  • mwc
29 Oct 2026 19:21
Replied by mwc on topic Ethercat drive configuration woes

Ethercat drive configuration woes

Category: EtherCAT

To follow up with the lcec_configgen output, this is what it generated -

<slave idx="2" type="generic" vid="0x00000a79" pid="0x00001000" name="D3">
      <!--CL3-E57H-->
      <syncManager idx="0" dir="out">
        <pdo idx="1a01">
          <!--TxPDO 2-->
          <pdoEntry idx="603f" subIdx="00" bitLen="16" halPin="errorcode" halType="u32"/>
          <pdoEntry idx="6041" subIdx="00" bitLen="16" halPin="2-statusword" halType="u32"/>
          <pdoEntry idx="6064" subIdx="00" bitLen="32" halPin="position-actual-value" halType="s32"/>
          <pdoEntry idx="60fd" subIdx="00" bitLen="32" halPin="digital-inputs" halType="u32"/>
          <pdoEntry idx="6061" subIdx="00" bitLen="8" halPin="modes-of-operation-display" halType="s32"/>
        </pdo>
        <pdo idx="1601">
          <!--RxPDO 2-->
          <pdoEntry idx="6040" subIdx="00" bitLen="16" halPin="2-controlword" halType="u32"/>
          <pdoEntry idx="6060" subIdx="00" bitLen="8" halPin="modes-of-operation" halType="s32"/>
          <pdoEntry idx="607a" subIdx="00" bitLen="32" halPin="2-target-position" halType="s32"/>
          <pdoEntry idx="6081" subIdx="00" bitLen="32" halPin="profile-velocity" halType="u32"/>
          <pdoEntry idx="6099" subIdx="01" bitLen="32" halPin="search-switch" halType="u32"/>
          <pdoEntry idx="6099" subIdx="02" bitLen="32" halPin="search-zero" halType="u32"/>
        </pdo>
      </syncManager>
      <syncManager idx="1" dir="out"/>
      <syncManager idx="2" dir="out">
        <pdo idx="1600">
          <pdoEntry idx="6040" subIdx="00" bitLen="16" halPin="out-controlword" halType="u32"/>
          <pdoEntry idx="6060" subIdx="00" bitLen="8" halPin="mode-of-operation" halType="s32"/>
          <pdoEntry idx="607a" subIdx="00" bitLen="32" halPin="out-target-position" halType="s32"/>
          <pdoEntry idx="60ff" subIdx="00" bitLen="32" halPin="target-velocity" halType="s32"/>
        </pdo>
      </syncManager>
      <syncManager idx="3" dir="in">
        <pdo idx="1a00">
          <pdoEntry idx="6041" subIdx="00" bitLen="16" halPin="in-statusword" halType="u32"/>
          <pdoEntry idx="6061" subIdx="00" bitLen="8" halPin="mode-of-operation-display" halType="s32"/>
          <pdoEntry idx="6064" subIdx="00" bitLen="32" halPin="position-actual" halType="s32"/>
          <pdoEntry idx="606c" subIdx="00" bitLen="32" halPin="velocity-actual" halType="s32"/>
          <pdoEntry idx="6077" subIdx="00" bitLen="16" halPin="torque-actual" halType="s32"/>
        </pdo>
      </syncManager>
    </slave>


Which without editting results in this error -

Debug file information:
Note: Using POSIX realtime
Failed to register PDO entry: No such file or directory
LCEC: master 0 syncUnit default PDO entry registration failed
LCEC: failure, clearing config
LCEC: exiting
LCEC: returning -EINVAL
lcec: rtapi_app_main: Invalid argument (-22)
./my_EtherCAT.hal:10: waitpid failed /usr/bin/rtapi_app lcec
./my_EtherCAT.hal:10: /usr/bin/rtapi_app exited without becoming ready
./my_EtherCAT.hal:10: insmod for lcec failed, returned -1
1740
Stopping realtime threads
Unloading hal components
Note: Using POSIX realtime


Is there any kind of documentation about syncmanagers anywhere that explains what is required/how they work?
  • tuxcnc
  • tuxcnc
29 Oct 2026 18:30

Feedrate changes not affecting Z plunge rate

Category: G&M Codes

G0 is rapid, and not uses F value.
Use G1 F3.
  • scsmith1451
  • scsmith1451's Avatar
29 Oct 2026 18:25

Feedrate changes not affecting Z plunge rate

Category: G&M Codes

Hi All;

I'm trying to write a surfacing program that slows the plunge rate of the spindle. I've tried:

G0 Z-0.005 F3

and 
F3
G0 Z-0.005

Neither change the feed rate of the plunge. However, when using G38.2 combined with an F3 in a probing routine, the spindle slows as expected.

Does spindle plunge rate not respond to the Fn modal command or is there something that I'm missing?
  • tuxcnc
  • tuxcnc
29 Oct 2026 17:35
Replied by tuxcnc on topic Ethercat drive configuration woes

Ethercat drive configuration woes

Category: EtherCAT

So tried lcec.activate, but that results in an error that activate isn't a valid command.
 

Should be:
initf lcec.activate servo-thread
  • meister
  • meister
29 Oct 2026 09:27

LinuxCNC-RIO - RealtimeIO for LinuxCNC based on FPGA (ICE40 / ECP5)

Category: Computers and Hardware

Hi Mirko,

The external step generators are controlled by velocity commands, so they require a PID controller to convert the position into velocity commands.

To start with, set the error parameter for the rotary axis to 20 and the min-error to 2:

Flow -> StepDir plugin -> Joint -> General -> *error

I hope that sorts out the follow error for now.

You can also lower the acceleration parameter.
Most default settings are for linear axes and will not work well with rotary axes.
  • my1987toyota
  • my1987toyota's Avatar
29 Oct 2026 09:22 - 29 Oct 2026 10:05
Replied by my1987toyota on topic Usefull Open Source software, vibe coded in Rust

Usefull Open Source software, vibe coded in Rust

Category: Off Topic and Test Posts

Thanks for the info tommylight. The use of the raspberry pi zero 2W wasn't my first choice, it became a requirement 
for a work related project I am working on (physical size constraints). As far as me using AI lets just say I have been
very reluctant to use it partially because of the incessant push to install data centers everywhere the tech bros can
put one (consequences be damned), the price of parts (that's a big one), and me not knowing how to efficiently use it. LOL.
  I will give your recommendations a try.  
  • MirkoCNC
  • MirkoCNC
29 Oct 2026 09:13

LinuxCNC-RIO - RealtimeIO for LinuxCNC based on FPGA (ICE40 / ECP5)

Category: Computers and Hardware

Hello Meister

Since a week, I have been trying to set up a rotary axis A with a TangBob. It works at snail speed, but not at higher speed. I am always confronted with joint follow error of the axis.
I need the axis in a winder setup to wind bobbins. Hence A must rotate "endless" depending on the windings I want to achieve. I need to achieve at least 1000 rpm. There is no problem with a linear axis.
I have used rio-flow-gui to set up an open loop stepper type angular, 1600 micro steps. Scale in and scale out are set to 1600. Whatever I do with the ini parameters to achieve higher speeds it fails on the joint follow error.
As I do not understand the internal mechanics of the actual feedback that should confirm the requested speed, I am lost. Furthermore, I do not understand the fole of the PID, which should have no meaning for an open loop set up.
I also cannot find any example of my application to help me out.
Hence, I hope you can help me out to set up a rotary axis at 1000 rpm to overcome that joint follower error (in simulation mode and with the hardware (currently only with the Tangboard only - no ChinaBob attached).
Thanks a lot in advance.
Displaying 16 - 30 out of 11537 results.
Time to create page: 1.297 seconds
Powered by Kunena Forum