Search Results (Searched for: )

  • IndeeSales
04 Nov 2026 22:52
Rtapi memory errors was created by IndeeSales
has anyone run into this I have kinda hit a wall and am looking for some insight

rtapi_shmem new failed due to shmget(key=0x48484c34): Permission denied
rtapi_init: could not open shared memory for uuid
HAL LIB: ERROR: rtapi init failed
hal lib: rtapi app main: Invalid argument (-22
Note: Using POSIX non-realtime
tpnod: dlopen: /usr/Llib/linuxcnc/modules/tpnod. so: undefined symbol: hal init
<commandline>:0: waitpid failed /usr/bin/rtapi app tpmod
<commandline>:0: /usr/bin/rtapi app exited without becoming ready
<commandline>:0: insmod for tpmod failed, returned -
  • hansfbaier
04 Nov 2026 22:11
Yes I had to buy their lathe controller to reverse the protocol as their tech support would not give me the protocol. It is thus still sitting idle here and I could sell it. Give the salesperson Aanny greeting from me when you order it :)
  • hansfbaier
04 Nov 2026 22:08
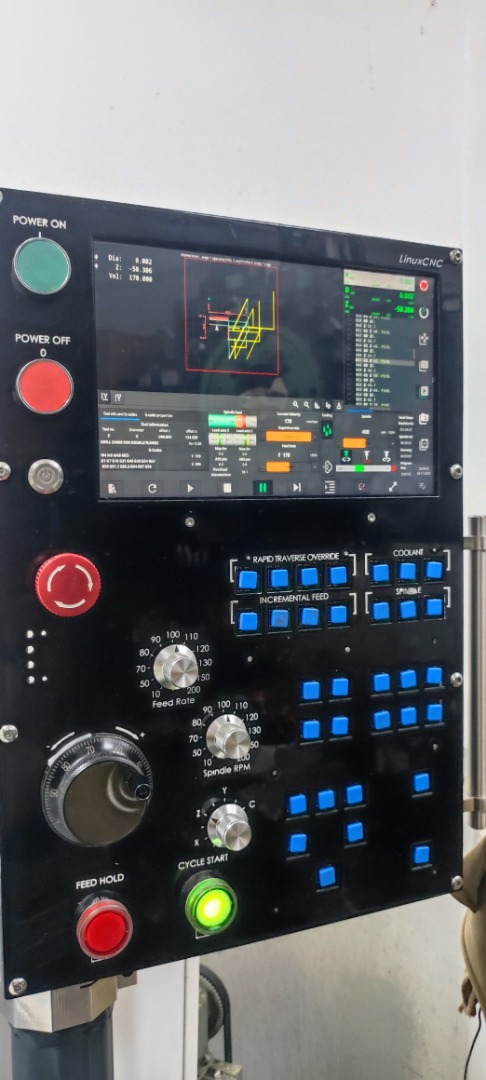
That is such a cool control panel build!
The GUI is gmocappy, I suppose?
  • MikkelRS
04 Nov 2026 19:48
Totally recognized that control panel!
Ive bought many things from SZGH tech, including a new lathe that should arrive in a month.
Thats so awesome you figured out the communication and connected it to linuxcnc!! Means ill have to order a couple panels to add to my existing linuxcnc machines :)
  • Zerosenka
04 Nov 2026 16:44
Replied by Zerosenka on topic Raspberry Pi Image heads up
yeah I sadly left it at tmp then I needed to reset to isolate the cores so the screenshot is gone sadly. I only remembered after I started writing the post. sorry
  • besriworld
04 Nov 2026 16:35
You've put a lot of work into this project. Thanks for sharing it!It's a really cool project, and you've got me thinking about whether I should follow a similar approach for my upcoming project: building a control system for a Mori Seiki MV Junior VMC.I still have some spare circuit boards from my lathe project, and I was originally thinking of just adding a few more buttons and a larger display. But after seeing your project, I'm starting to reconsider my approach! 
  • HughF
04 Nov 2026 16:08 - 04 Nov 2026 16:38
servotune: free parameter and scope tool for Lichuan A5 (LC10P) and B2 drives, testers wanted

Hi all,

Lichuan's PC software for the A5/LC10P and B2 is a parameter editor and not much more. I wanted something closer to the tuning tools other drive makers ship, so I've started writing one. It's called servotune. It's free (GPL), and runs on Linux and Windows.

It talks to the drive through its RS-485 Modbus port (CN3/CN4 on the A5, CN2 on the B2) using an ordinary USB-RS485 adapter. It doesn't need LinuxCNC and doesn't touch the step/dir side. The drive can stay wired to your Mesa card while you watch it and LinuxCNC moves the axis.

What the first release does:
  1. Scan and probe: finds the drive at any baud rate and format. A strictly read-only probe writes a report of which registers answer and how fast.
  2. Parameters: every parameter by group, showing the drive's value, the default, the range, and when a change takes effect (immediately, at stop, or after a power cycle). You can edit one, or load an .lcd file from Lichuan's software and write only the differences after a review screen. It can also save the drive to an .lcd file.
  3. Program a drive from a file: writes only what differs, reads everything back to verify it, and saves a report. The original values are journalled to disk first, so an interrupted session can be restored.
  4. Scope: the drive's own position following error, speed against speed command, and torque, live. It has triggers, cursors, captures you can overlay to compare before and after a gain change, and CSV export. This is useful with step/dir, where LinuxCNC never sees the following error but the drive does.

One thing to watch if you script this yourself: .lcd files trim trailing zeros, so "P08-00=30" on a 0.1 Hz parameter means 30.0 Hz (raw register 300). servotune takes the scaling from the manual, not from the file.

The honest bits:
  1. So far it has only been tested against its built-in simulated drive, not on a real drive. That's why it's tagged as a pre-release.
  2. The scope polls over Modbus. Lichuan doesn't expose an internal capture buffer, so expect roughly 30-180 samples a second depending on baud rate. That's enough for following error through a move, overshoot and settling time. It isn't enough to see fast oscillation, and the scope warns you when that might be happening.
  3. It doesn't drive test moves or offer guided tuning yet. That's next.
  4. The Windows build hasn't been run on Windows yet.
  5. The EtherCAT LC10E isn't supported.

How you can help:

If you have an A5/LC10P or a B2, please run the read-only probe and post the report, here or as a GitHub issue. It only sends Modbus read requests.

Each report answers something the manuals leave unclear: B2 register numbering, whether the A5 really runs at 115200 baud, and which monitor registers are 32-bit.

Downloads (Windows zip and Linux AppImage), source and docs available from my GitHub, linked under my profile.

Not affiliated with Lichuan, just a user for many

Hugh
  • awallin
04 Nov 2026 16:01
Replied by awallin on topic Tuning Steperonline A6 Servos

A brief description of the script would be helpful.
What does it do?
How does the process work?

Without a detailed description, I wouldn’t test the script—my servos are too valuable to me to risk it.
 

use the source?
* reads parameters (SDOs) with 'ethercat upload' and displays them in an editable table
* writes SDOs with 'ethercat download'
* monitors following error with halcmd

I tried the windows-program from stepperonline (with a USB cable to the drive) and it does similar things, with something similar to halscope for plotting following-error etc, but this tuning-script is more convenient as it talks over ethercat to the drive while linuxcnc is running. No automation for actually finding the gain parameters, that still has to be done manually e.g. following the post by StepperOnline above.
  • Wischi
04 Nov 2026 15:25
Replied by Wischi on topic Re-designing the Gmoccapy DRO
I really like this new style! But i would also do all of the axis the same style, so no A and B in smaller font and in different columns, instead all digits lining up. Maybe make the G54 and DTG the same font size as X,Y,Z.

Is there anyway to test this already or was this just a mockup?
  • hansfbaier
04 Nov 2026 15:16 - 04 Nov 2026 15:25
Yes, that's the one for the lathe.
They also have one for the mill,
which is very similar.
It costs 200 USD plus shipping and communicates with LinuxCNC over RS485.
I wrote a HAL client driver for it, which I just open sourced:
github.com/LiNC-CNC/cnc-panel-rust
This repo also has a python HAL driver.
  • besriworld
04 Nov 2026 15:09
Do you use this control panel? If so, could you please let me know how much it costs and how it communicates with LinuxCNC?

www.szghtech.com/SZGH-CNC-control-system-1080TC
  • grandixximo
04 Nov 2026 14:46
Replied by grandixximo on topic Raspberry Pi Image heads up
You have to save the screenshoot in an image file, upload the image, and then add it to the post.
  • dberegovoy
04 Nov 2026 14:03
  • dberegovoy
04 Nov 2026 14:01
I need two ports so that I can dedicate one to EtherCAT and the other to Ethernet Mesa. 

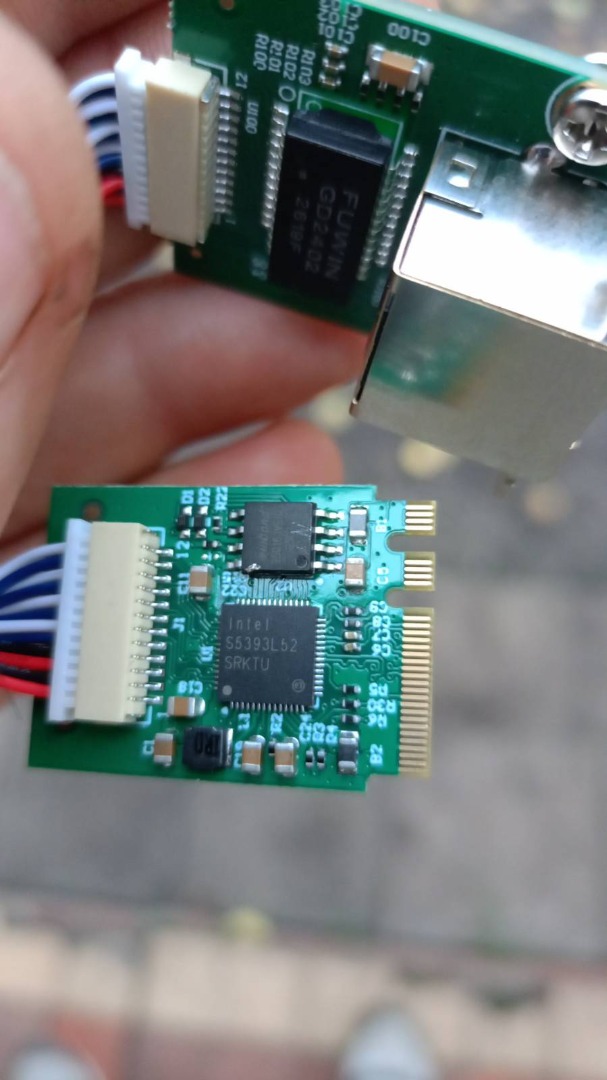
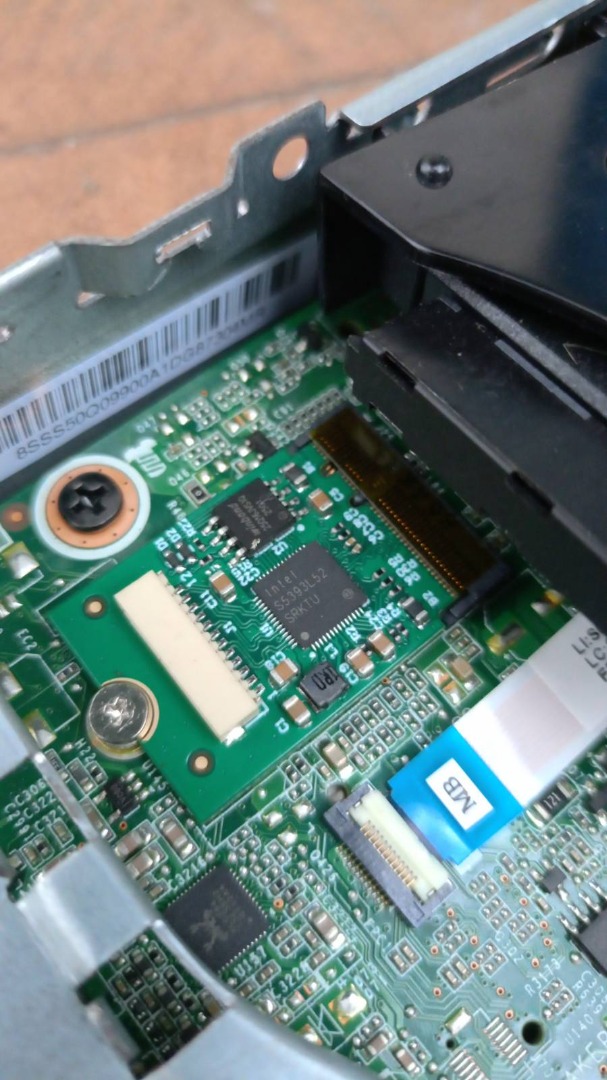
Anyway, here is a photo of the M.2 network card from AliExpress that I tried using.
Right after I installed it, the PC froze on the very first reboot.
After that, I managed to successfully configure the card for EtherCAT and even saw the slave devices. I was thrilled and decided to connect the Mesa card to the built-in onboard network port to test them running together. As soon as I plugged it in, the computer suddenly rebooted. 

Following that, the M.2 card disappeared from the system completely. I double-checked the physical connection, and it showed up again, but the glitches kept happening. In the end, I just pulled it out and threw it into a drawer. 

In theory, there is another option: installing a network card into the NVMe M.2 slot instead of the Wi-Fi slot. The power delivery there should theoretically be better than on the Key-E Wi-Fi slot, but I am really not sure about that approach since it would require buying either an adapter or a completely new card, and the end result would still be highly questionable.
  • Zerosenka
04 Nov 2026 13:59
Raspberry Pi Image heads up was created by Zerosenka
Hello I am very new to everything so I don't know much

I have downloaded the rpi image from download page and installed it with Raspberry Pi Image app and I found my latency and histogram very bad.
I had installed linuxcnc a long while ago with the same stuff it was bookworm then so I was very worried and though I might just go back to that image but I notice something on histogram it said no_isolcpus. which I remember that I read that core 2,3 should be isolated so I googled how and isolated them and the latency became much better.

I took a screen shot of the histogram but it was saved in tmp /media/kunena/emoticons/
Displaying 106 - 120 out of 11094 results.
Time to create page: 0.127 seconds
Powered by Kunena Forum