Advanced Search

Search Results (Searched for: )

  • Bram kersten
  • Bram kersten
14 Oct 2025 08:46
WCS Problem with Linuxcnc/qtdragon was created by Bram kersten

WCS Problem with Linuxcnc/qtdragon

Category: General LinuxCNC Questions

I have avidcnc from 2017 from wich i recently replace the breakoutboard with a mesa7i76EU to make it work with linuxcnc.
Everything seems to be working fine,

The only problem i have is that it doesn't seem to use the WCS coordonates after i zero my machine But keeps using only the absolute coordinates when im running my gcode
This causes the machine(zaxis) to move into the bed when starting the program.

can somebody help me please.
Thanks in advance.i added my gcodeand my hall/ini files for qtdragon.  
  • vibram
  • vibram
14 Oct 2025 08:42
Replied by vibram on topic Servo analog command, PID and El5101

Servo analog command, PID and El5101

Category: EtherCAT

It's possible for my specific servo but there is not point to do this as my servo is not piloted by position but with analog (no ethercat drive)
  • Hakan
  • Hakan
14 Oct 2025 08:04 - 14 Oct 2025 08:06
Replied by Hakan on topic Ohmic sensing with IPTM-60

Ohmic sensing with IPTM-60

Category: Show Your Stuff
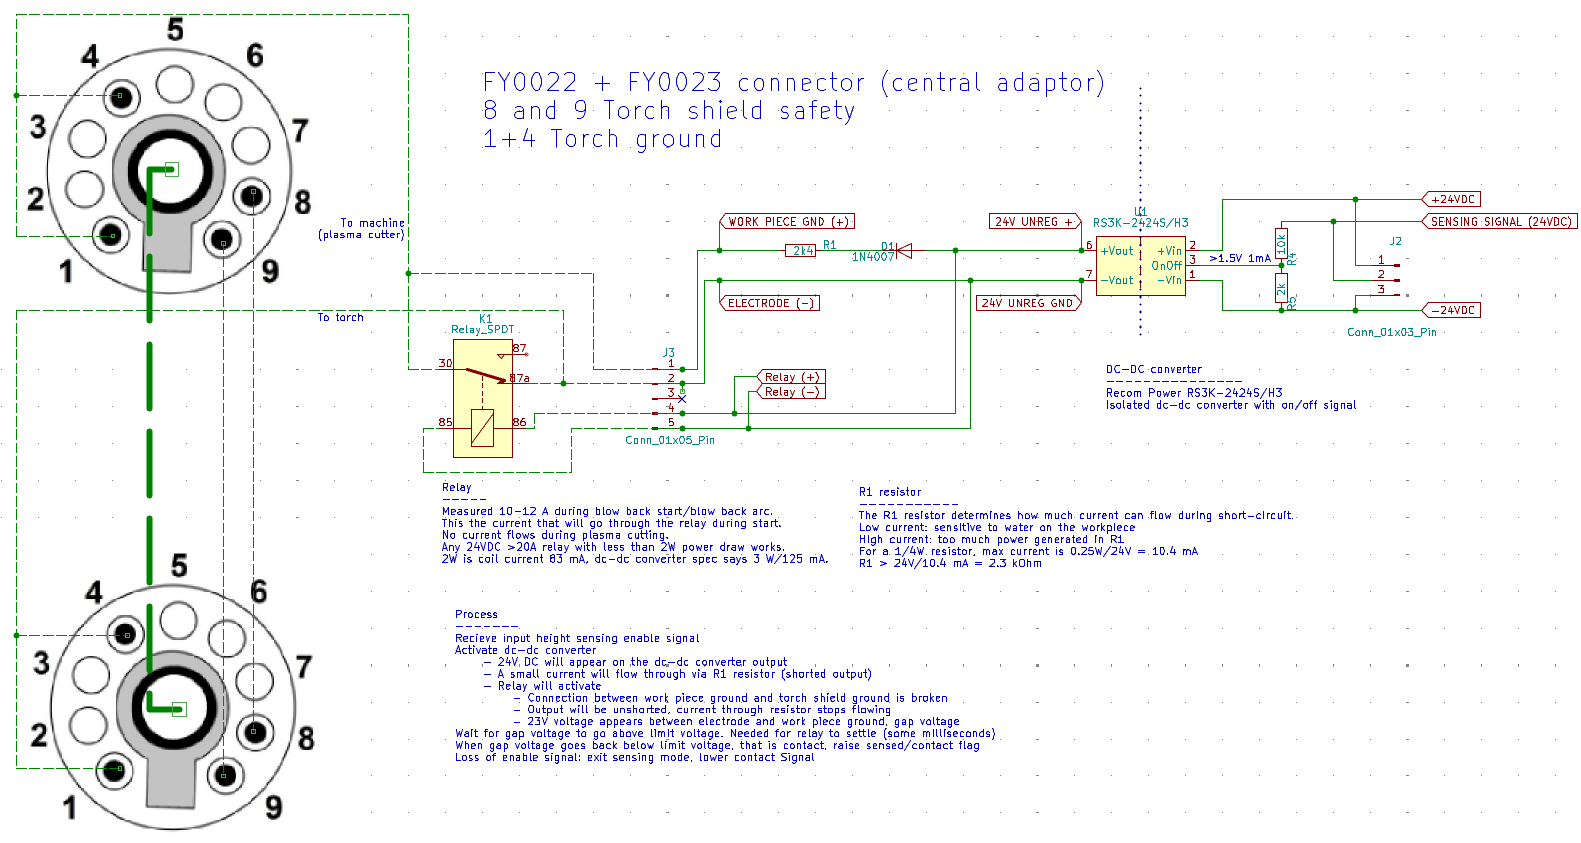
Updated schematics 
  • Hakan
  • Hakan
14 Oct 2025 08:02
Replied by Hakan on topic Ohmic sensing with IPTM-60

Ohmic sensing with IPTM-60

Category: Show Your Stuff

Update of this project.
Regarding water on the table and difficulty to properly detect contact.
Yes, been there, done that. 
It seems to be caused by too low R1 resistance. Which means too low current at short-circuit.
Stray currents through water are in the same order of magnitude as the short-circuit current
and influences the voltage measurements. 
Too high R1 (low short-circuit current) and water on the table causes two things:
1. The measured voltage will only go to single-digit voltages, like 8V instead of 24V
2. The measured short-circuit voltage drop is only a few Volts. The voltage stays at some 8-3 = 5 V, where it should be 0V.
When looking at the voltage, well working means sharply up to some 23V, then sharp drop to 0V.
Not well working: Damped rise to some 10-ish V, damped drop of a few Volts at short-circuit.

Using R1 = 100 kOhm, short-circuit current = 0.24 mA. This is too low.
Using R1 = 2k7 kOhm, I = 8.9 mA works much better.
 
  • yuuahmad
  • yuuahmad's Avatar
14 Oct 2025 07:04
control spindle motor using modbus was created by yuuahmad

control spindle motor using modbus

Category: General LinuxCNC Questions

I have a spindle motor that can be controlled using Modbus with a list of addresses sent as shown in the image.

I want to control it using USB/RS485, but I don't fully understand the Linux CNC documentation. Furthermore, there are not enough project examples and the configuration settings are not intuitive. So, I'd like to ask a question here.

I've included all the configuration programs in my GitHub link. I plan to use mb2hal for general function code, and Python for custom function code (0x44).

The program on GitHub has the same issue as the one I've included. 

github.com/yuuahmad-aii/axisXYZ-linuxcnc  github link
Displaying 12796 - 12800 out of 12800 results.
Time to create page: 1.304 seconds
Powered by Kunena Forum