

- Posts: 19311
- Thank you received: 4655
Fitting an encoder on a Tormach 1100
8 years 6 months ago #108562
by andypugh
You haven't actually said what you want to do with the encoders yet...
And as PCW says, the output seen so far is only useful to know which pins on the FPGA card are doing what.
You need the HAL pin names to use the encoders in HAL.
In a non-pathpilot setup you can use:
halcmd show pin
halcmd show param
When LinuxCNC is running to get all the pins and parameters. I am not sure how you do that in PP. Possibly
admin halcmd show pin
You are going to need help from someone who actually uses Pathpilot I am afraid.
Replied by andypugh on topic Fitting an encoder on a Tormach 1100
Clive s wrote: can you please help me with the correct syntax to use the above in hal
You haven't actually said what you want to do with the encoders yet...
And as PCW says, the output seen so far is only useful to know which pins on the FPGA card are doing what.
You need the HAL pin names to use the encoders in HAL.
In a non-pathpilot setup you can use:
halcmd show pin
halcmd show param
When LinuxCNC is running to get all the pins and parameters. I am not sure how you do that in PP. Possibly
admin halcmd show pin
You are going to need help from someone who actually uses Pathpilot I am afraid.
Please Log in or Create an account to join the conversation.

8 years 6 months ago #108612
by Clive S
Replied by Clive S on topic Fitting an encoder on a Tormach 1100
Thank you Andy & Peter for your patience.
I am having trouble getting halcmd to work ( I can see it on the machine in various places) but I have managed to print this from halmeter which i believe is the correct pins
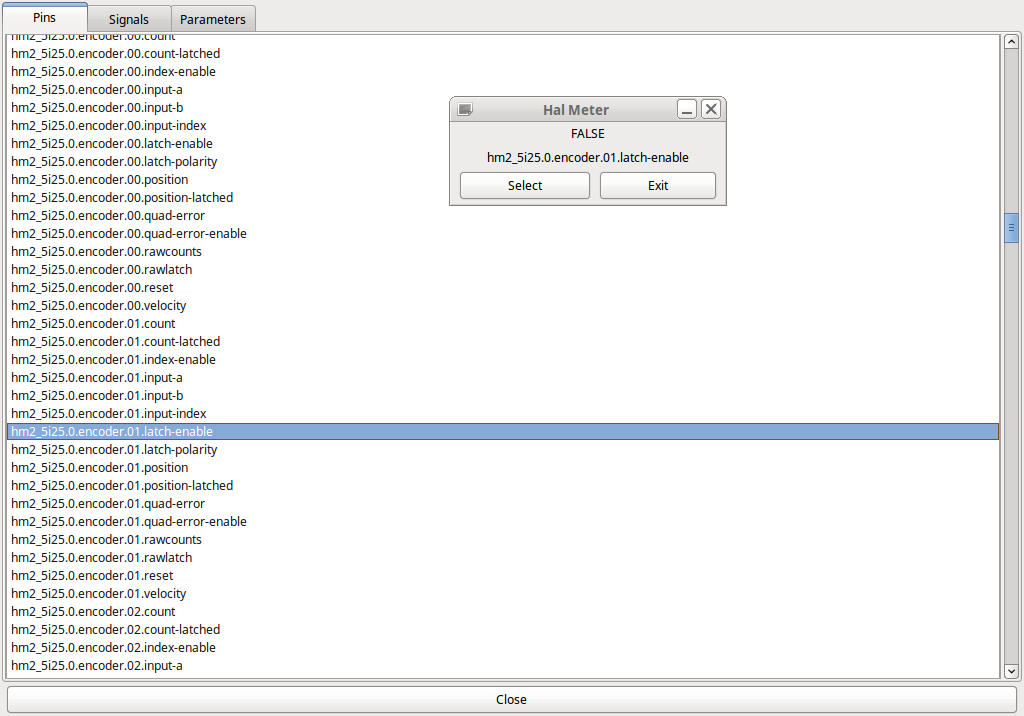 and
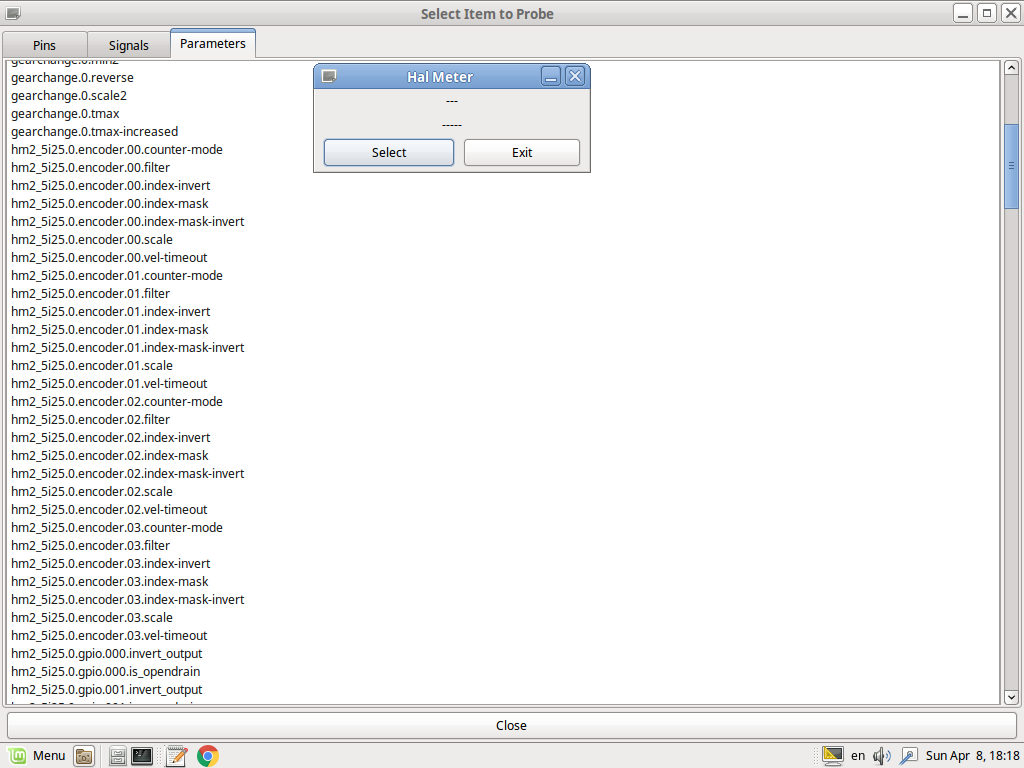
I have loaded 4 encoders but initially I would like to use encoder.0 to use the spindle for rigid tapping it has 2000p/r I could change it for 1000p/r if needed. Then if I can get that going first I would like 3 MPG's as well.
I am having trouble getting halcmd to work ( I can see it on the machine in various places) but I have managed to print this from halmeter which i believe is the correct pins
I have loaded 4 encoders but initially I would like to use encoder.0 to use the spindle for rigid tapping it has 2000p/r I could change it for 1000p/r if needed. Then if I can get that going first I would like 3 MPG's as well.
Please Log in or Create an account to join the conversation.
8 years 6 months ago - 8 years 6 months ago #108613
by PCW
Replied by PCW on topic Fitting an encoder on a Tormach 1100
OK so as a start you will want to:
setp hm2_5i25.0.encoder.00.scale 8000
( a 2000 PPR encoder has 8000 quadrature counts per turn )
You can verify this by hand rotating the spindle, and "halmetering" hm2_5i25.0.encoder.00.position
if scaled properly, the encoded position should change by 1 for each turn of the spindle
setp hm2_5i25.0.encoder.00.scale 8000
( a 2000 PPR encoder has 8000 quadrature counts per turn )
You can verify this by hand rotating the spindle, and "halmetering" hm2_5i25.0.encoder.00.position
if scaled properly, the encoded position should change by 1 for each turn of the spindle
Last edit: 8 years 6 months ago by PCW.
Please Log in or Create an account to join the conversation.
8 years 6 months ago - 8 years 6 months ago #108614
by andypugh
Should be all you need.
Replied by andypugh on topic Fitting an encoder on a Tormach 1100
Code:
net spindle-position hm2_5i25.0.encoder.00.position => motion.spindle-revs
net spindle-velocity hm2_5i25.0.encoder.00.velocity => motion.spindle-speed-in
net spindle-index-enable hm2_5i25.0.encoder.00.index-enable <=> motion.spindle-index-enable
setp hm2_5i25.0.encoder.00.scale 8000
Should be all you need.
Last edit: 8 years 6 months ago by andypugh.
Please Log in or Create an account to join the conversation.
8 years 6 months ago #108618
by Clive S
Replied by Clive S on topic Fitting an encoder on a Tormach 1100
Thank you both. I will report back:)
Please Log in or Create an account to join the conversation.
8 years 6 months ago #108672
by Clive S
Ok after several hours I decided to re read the manual on the 7i85s and realised I had the jumpers to RS-422 instead of TTL:blush:
I now have hm2_5i25.0.encoder.00.position showing me one full turn per count forward and back.
Do I need to add anything else like filtering etc. to the hal file to achieve rigid tapping
Replied by Clive S on topic Fitting an encoder on a Tormach 1100
andypugh wrote:
Should be all you need.Code:net spindle-position hm2_5i25.0.encoder.00.position => motion.spindle-revs net spindle-velocity hm2_5i25.0.encoder.00.velocity => motion.spindle-speed-in net spindle-index-enable hm2_5i25.0.encoder.00.index-enable <=> motion.spindle-index-enable setp hm2_5i25.0.encoder.00.scale 8000
Ok after several hours I decided to re read the manual on the 7i85s and realised I had the jumpers to RS-422 instead of TTL:blush:
I now have hm2_5i25.0.encoder.00.position showing me one full turn per count forward and back.
Do I need to add anything else like filtering etc. to the hal file to achieve rigid tapping
Please Log in or Create an account to join the conversation.
Time to create page: 0.106 seconds