Search Results (Searched for: )

  • Aciera
18 Mar 2026 19:18 - 18 Mar 2026 19:43
Replied by Aciera on topic Updating Old GladeVCP Files?
The first thing I'd try is to load your glade file in the Glade (Version 3) editor and save it.

Also check for error output when starting your config from a terminal.
  • 0x2102
18 Mar 2026 18:44
Der groesste Vorteil fuer mich bei einem EtherCAT System ist die Nutzung von Servos mit Absolut-Encoder. Maschine starten, LinuxCNC liesst die aktuelle absolute Position, "Home All" druecken, fertig (nichts verfaehrt da absolut). Selbst diesen Schritt koennte man sich mit ein paar Verbindungen in der HAL sparen und gleich bei "Machine On" bereit sein.

Falls das gewerblich genutzt werden soll dann nur Servos mit STO.
  • andrax
18 Mar 2026 18:39
Also Empfehlung meinerseits.
Wenn A6 dann richtig!
Bestellt zu den Servos die Encodercabel mit Batteriebox, erspart euch jede menge Ärger.
Die Servos dann auf Absolutwert Multiturn umstellen und noch ein einziges mal das Homing durchführen. 
Derzeit sieht es leider so aus, dass der Ethercat hall Treiber, sowie die CIA402 Homing Komponenten noch eine große Baustelle sind.
Es gibt zwar hierzu Entwicklungen, aber keiner weiß, wann die in den Hauptzeig einfließen. Näheres zu den Problemen sind im englischen Teil zu finden.
Zum EMV:
EMV ist ein richtiges Problem, ich hatte hier zu kämpfen bevor die Ausgabe von dmesg fehlerfrei war, dennoch reagieren die Servos empfindlich auf Störungen. 
Die empfohlenen Netzfilter für jeden Servo findet ihr Hier:
Stepperonline-A6
Netzwerkkabel Cat 6 sind Pflicht, besser Industriestandart und diese mit Feritkernen entstören, keine Schlaufen legen.
Netzwerkkarte mit Intelchip benutzen. Hier einfach mal bei Beckhoff vorbeischauen, die haben eine Liste mit Zertifizierten Chips.
Andere Karten gehen auch, aber können Probleme machen. 
  • 0x2102
18 Mar 2026 18:23
Replied by 0x2102 on topic LinuxCNC 2.98 - Ethercat - ProbeBasic
I had a similar issue. Was running an older linuxcnc-ethercat version - which worked well but when I went to the latest version to address the "random jitter" issue it crashed with signal 11.

forum.linuxcnc.org/ethercat/58103-etherc...-fix?start=60#344310

Try grandixximo's linuxcnc-ethercat repo - which has the "jitter fix" and the "zero-initialized" fix.

Make your custom mods and compile:

github.com/grandixximo/linuxcnc-ethercat
  • Todd Zuercher
18 Mar 2026 18:13
Replied by Todd Zuercher on topic Updating Old GladeVCP Files?
I'm still not getting anywhere with this. This GadeVCP worked fine with Linuxcnc 2.7 on Debian 7, but on the upgraded control PC running Linuxcnc 2.9 on Debian 13, The Python handler file doesn't seem to work. The problem is that it isn't creating any of the hal pins that it used to.  I've tried this with several different GladeVCPs that I had created a number of years ago for these machines. and all of them are giving similar issues.  
  • georgio
18 Mar 2026 18:10
  • PCW
18 Mar 2026 18:02
If you measure from
TB1 pin 8 (-) to TB1 PIN 5 (+)
 What do voltage do you get?

 
  • 858PSJ
18 Mar 2026 17:53
Replied by 858PSJ on topic pocketing program
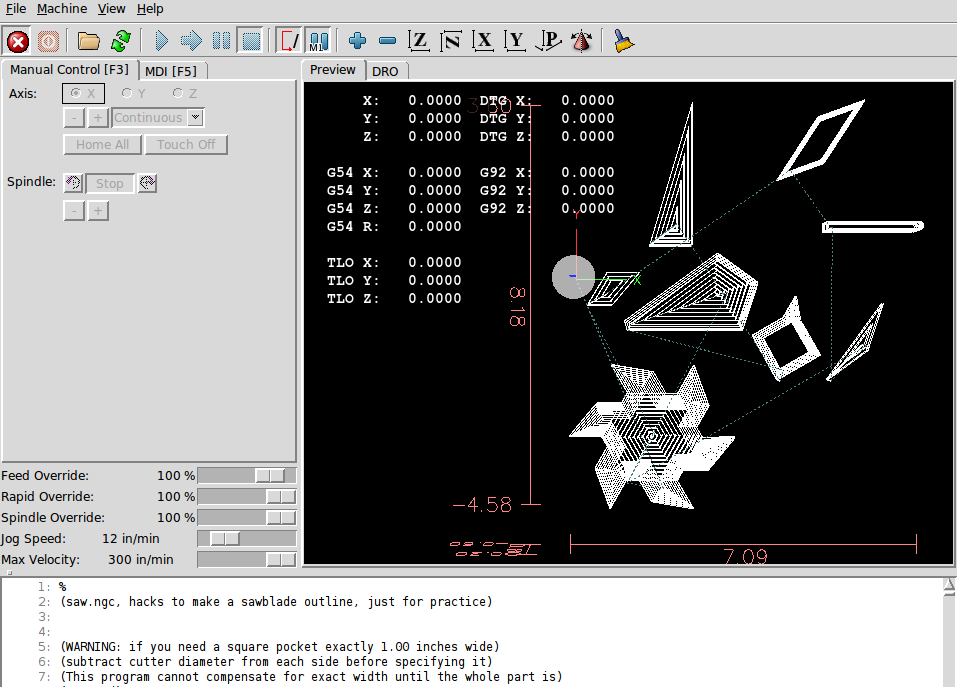
here's a screenshot and a pocketingprogram

File Attachment:

File Name: polygonpoc...3-18.zip
File Size:6.9 KB
  • georgio
18 Mar 2026 17:32
W1 is in the default position left and the fileld power is correctly conneced
Thanks
George
  • PCW
18 Mar 2026 17:29
OK that means you have no VIN so the field I/O section is unpowered

Normally VIN comes from VFIELD (W1 LEFT)

So either you have:

1.  No VFIELD

2. W1 is in the right hand position (it should be in the default left position)

3. Some hardware issue with the field I/O section.
  • georgio
18 Mar 2026 17:18
no it never lights,
thanks
  • Spezidrohne
18 Mar 2026 17:17
Replied by Spezidrohne on topic StepperOnline A6 Servo
Hello, 
Im new and have just started with linuxcnc, and im also a newbie with linux. I have installed linuxcnc  on a machine and installed ethercat. I can see my a6 drive under the slaves. But now i dont know what to do. Where should i copy the working configuartion files from Page 1? What do i have to do after that? Can someone please guide me through everything? I have not done anything else on this machine except from adjusting the Internet settings. I can see the drive in preop Mode, but how do i go on? As i said, im a complete newbie. Help much apreciated. Thanks.
  • nicklego
18 Mar 2026 17:14
Motor timing help was created by nicklego
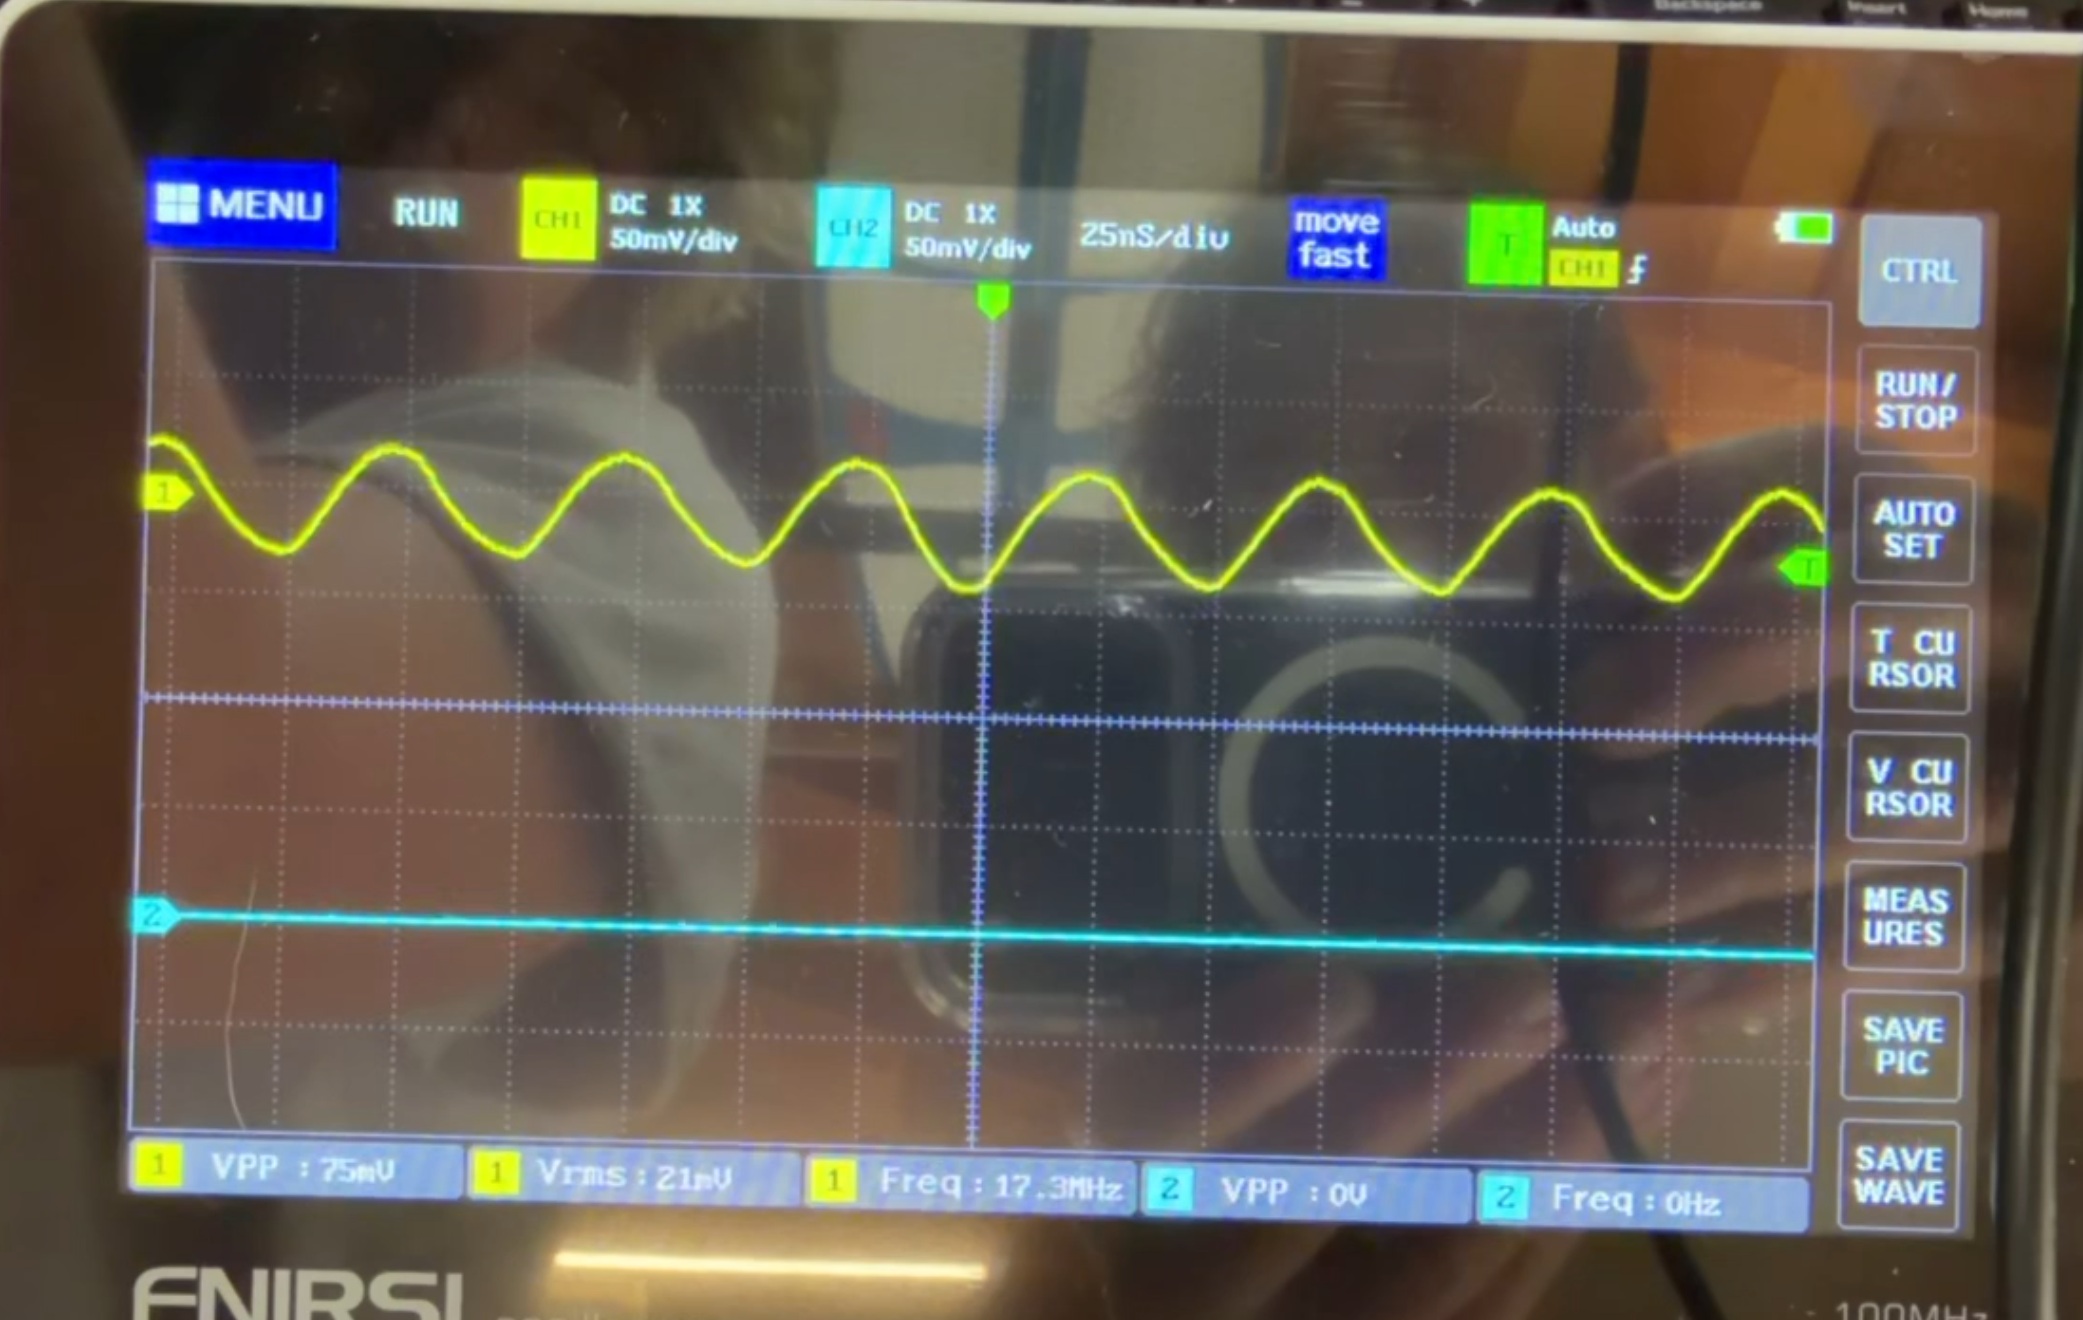
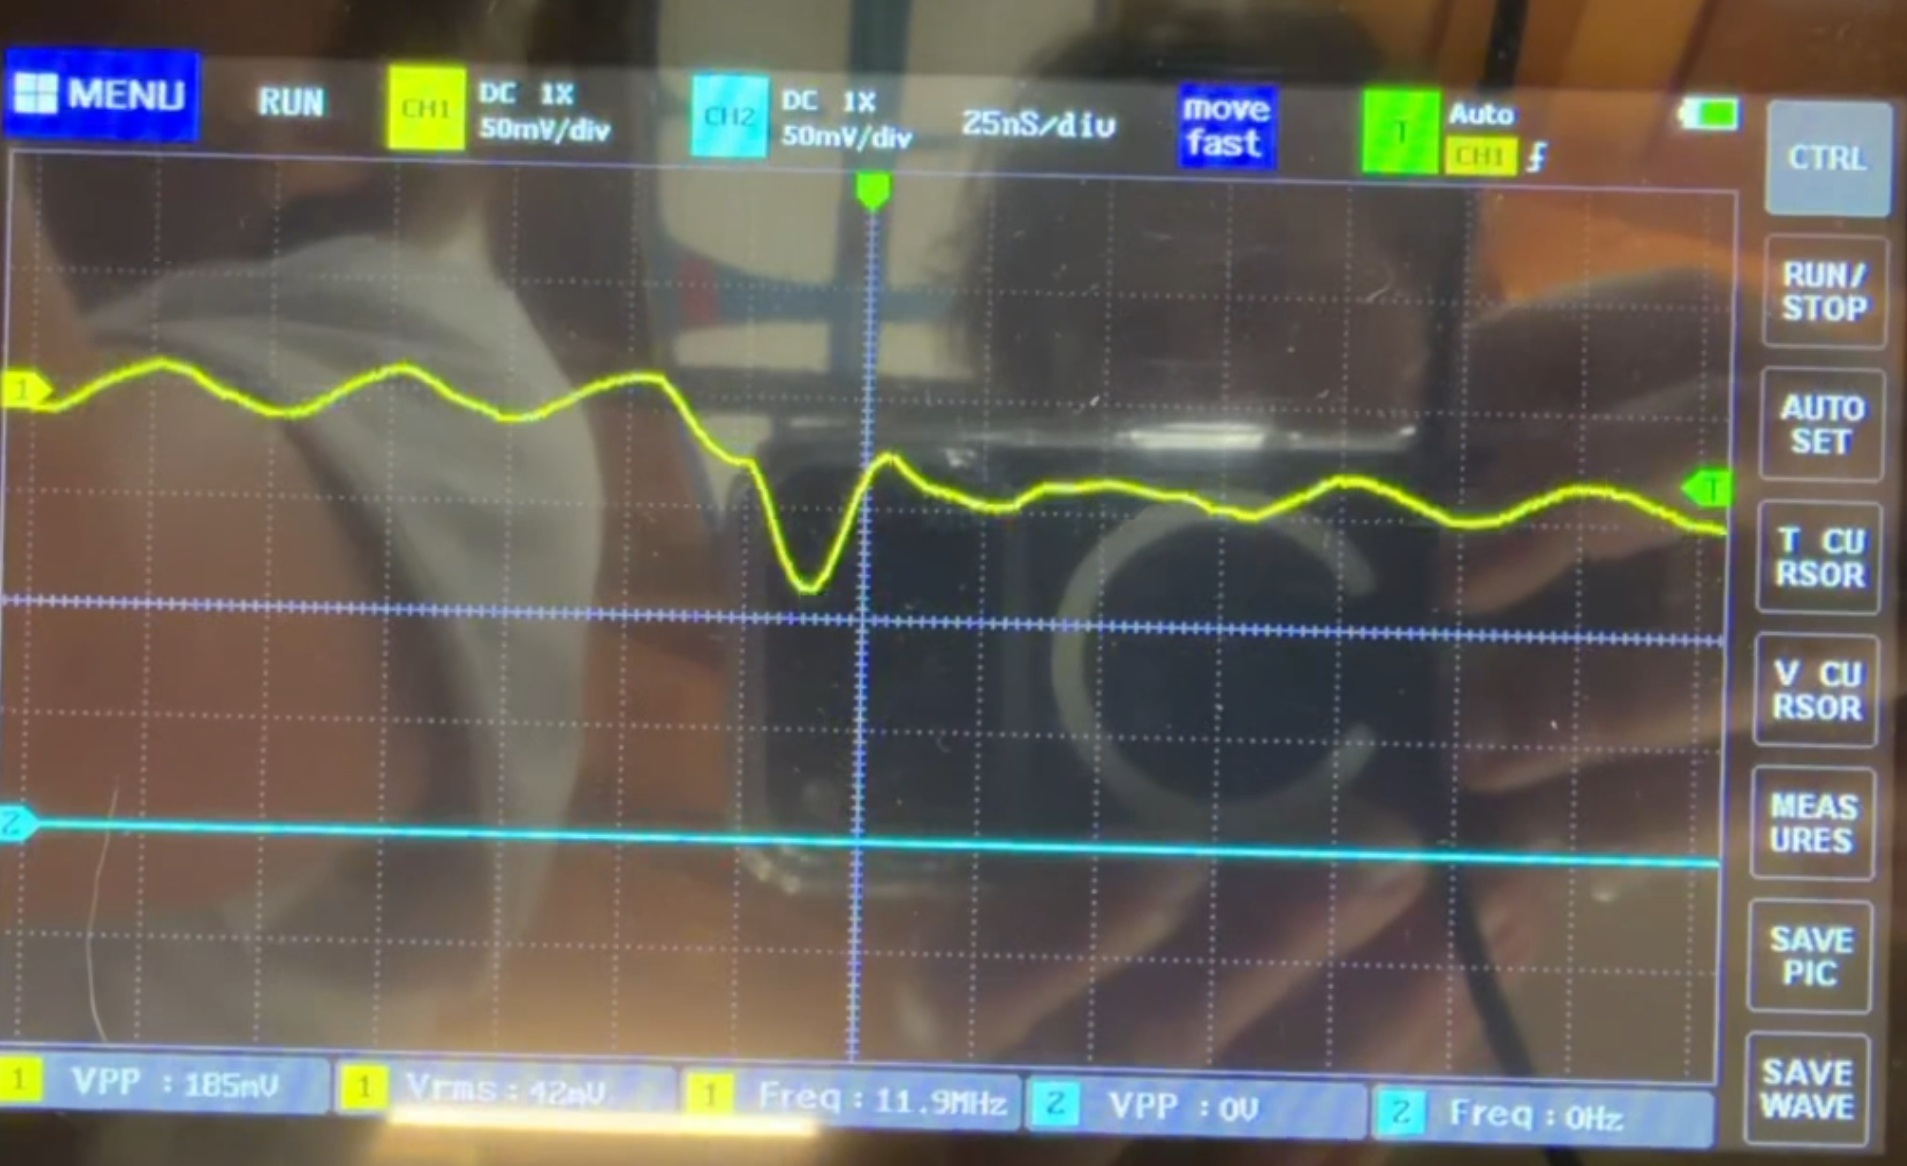
 Hi, I'm trying to get my motors running with LinuxCNC, and I have an old controller for the machine that can move the motors, but the card reader on it is broken. I have tried many times to get it working with LinuxCNC, but now I've tried to diagnose it with an oscilloscope on the old controller. For the x-axis output, the step pin outputs a constant 20MHz signal when not being told to move, but when being told to move, it outputs a 12MHz signal. Image 1 is the motor not moving (Consistent wave), and image 2 is the motor moving (weird-looking wave). I took a video of them side by side and is linked to a google drive. If anyone knows how I can replicate this signal/frequency in LinuxCNC, that would be greatly appreciated. Thanks. Link to video -->  drive.google.com/file/d/1qQ6TFAT_yjkfDdm...Lns/view?usp=sharing
Image 1 -->      Image 2 --> 
  • PCW
18 Mar 2026 17:07
Before you start LinuxCNC, does red LED CR11 (above TB4) Illuminate?
 
  • georgio
18 Mar 2026 17:01
Hi PCW,
I have attached the linuxcnc report. I put it for line 36 in hal but all of the other inputs 05-09 were the same errors. No there aren't any red led's on the board at that location with the error i get there will be one in amonst the boot up led's.
Thanks
Displaying 5746 - 5760 out of 11902 results.
Time to create page: 0.174 seconds
Powered by Kunena Forum