Search Results (Searched for: )

  • rodw
25 May 2026 21:47
You don't need bitslice, just do it in the xml
Code:
<pdoEntry idx="60FD" subIdx="0" bitLen="32" halType="complex"> <complexEntry bitLen="1" halPin="CW-limit" halType="bit"/> <complexEntry bitLen="1" halPin="CCW-limit" halType="bit"/> <complexEntry bitLen="1" halPin="in-home" halType="bit"/> <complexEntry bitLen="13"/> <complexEntry bitLen="1" halPin="in-1" halType="bit"/> <complexEntry bitLen="1" halPin="in-2" halType="bit"/> <complexEntry bitLen="1" halPin="in-3" halType="bit"/> <complexEntry bitLen="1" halPin="in-4" halType="bit"/> <complexEntry bitLen="1" halPin="in-5" halType="bit"/> <complexEntry bitLen="1" halPin="in-6" halType="bit"/> <complexEntry bitLen="10"/> </pdoEntry>
 NOte there are some unused bits in this example
  • RMJ fabrication
25 May 2026 21:46
I don’t think it is Plasma/EMI related. My plasma cutter was not connected or turned on.
  • ChrisB_II
25 May 2026 21:44
Hallo, 
ich habe mein System auf einem Lenovo ThinCentre 710 mit i3 aufgesetzt, darauf läuft das aktuelle LinuxCNC 2.9.6/7/8 (alle 3 mit gleichem Problem). Falls es irgendwie hilft, habe ich meine Config mal angehängt.

Mein Problem ist, dass meistens alles sauber funtioniert, wenn ich aber einen längeren Fräsvorgang (5-10 Minuten) am Laufen habe, gelegentlich die gesamte Software einfriert - nur die Spindel wird nicht gestoppt und die Maus lässt sich noch bewegen. Alles an Bewegung friert ein und die Software lässt sich nicht beenden. Es hilft nur noch, den Ein-/Aus-Schalter so lange zu drücken, bis das System abschaltet und dann alles neu hoch zu fahren, "homen" und wider von vorne, in der Hoffnung, dass es dann durchläuft.

Hat jemand Ideen, wie ich das Problem untersuchen, debuggen, oder gar beseitigen kann? Ich stehe wie Ochs vor'm Berg... Ich habe den Verdacht, dass es irgendetwas mit "verpennten" Interrupts zu tun haben könnte, weiß aber nicht, wie ich das untersuchen kann.

Vielen Dank im Vorraus!
Chris
  • rodw
25 May 2026 21:40
probably a Beckhof EK1100 and 2 x EL1008 will look after your inputs. you might need to add EL2008 for any outputs. an EL5151 if you need an encoder input for spindle
 
  • PCW
25 May 2026 21:40 - 25 May 2026 23:01
Is this possibly Plasma/EMI related?

That is, do you still get communication loss when the Plasma source is off?
  • Ismacr63
25 May 2026 21:35
Replied by Ismacr63 on topic Jumping motion with XHC-WHB04B pendant

I can't help with a fix, but it might help to work out where the fix belongs.
Try plotting the position-cmd in Halscope to see if the problem is in the commands from the WHB or is inside HAL itself.
I'm attaching a short video and my configuration files. I've been trying to use Halscope but I still don't quite understand it. Tomorrow with more time I'll give it another try.

youtube.com/shorts/L8vz-2Y_pZM?feature=share
  • RMJ fabrication
25 May 2026 21:14
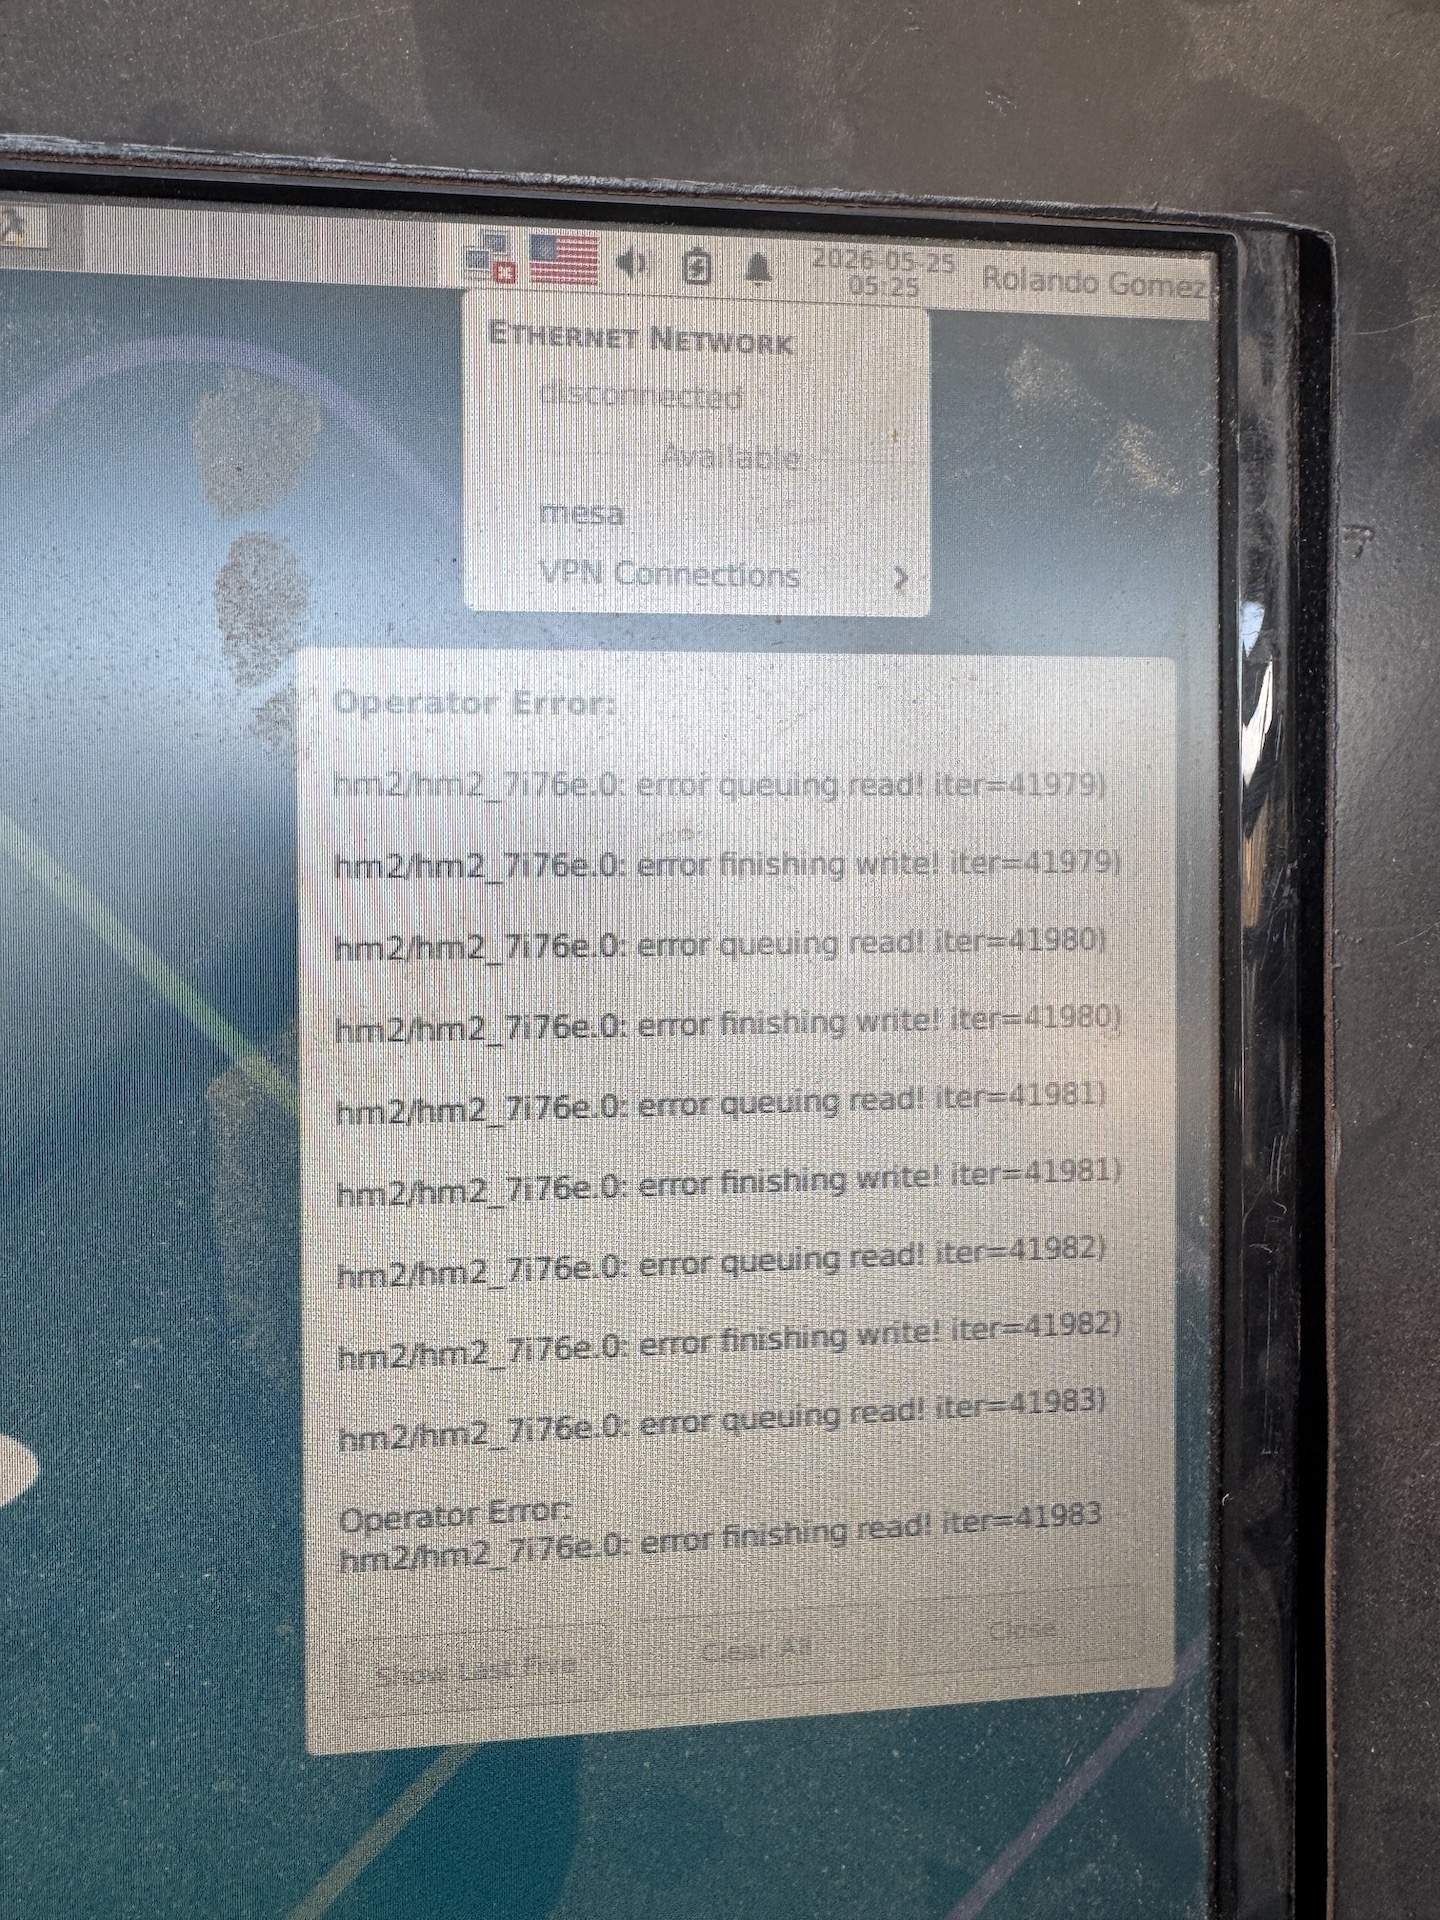
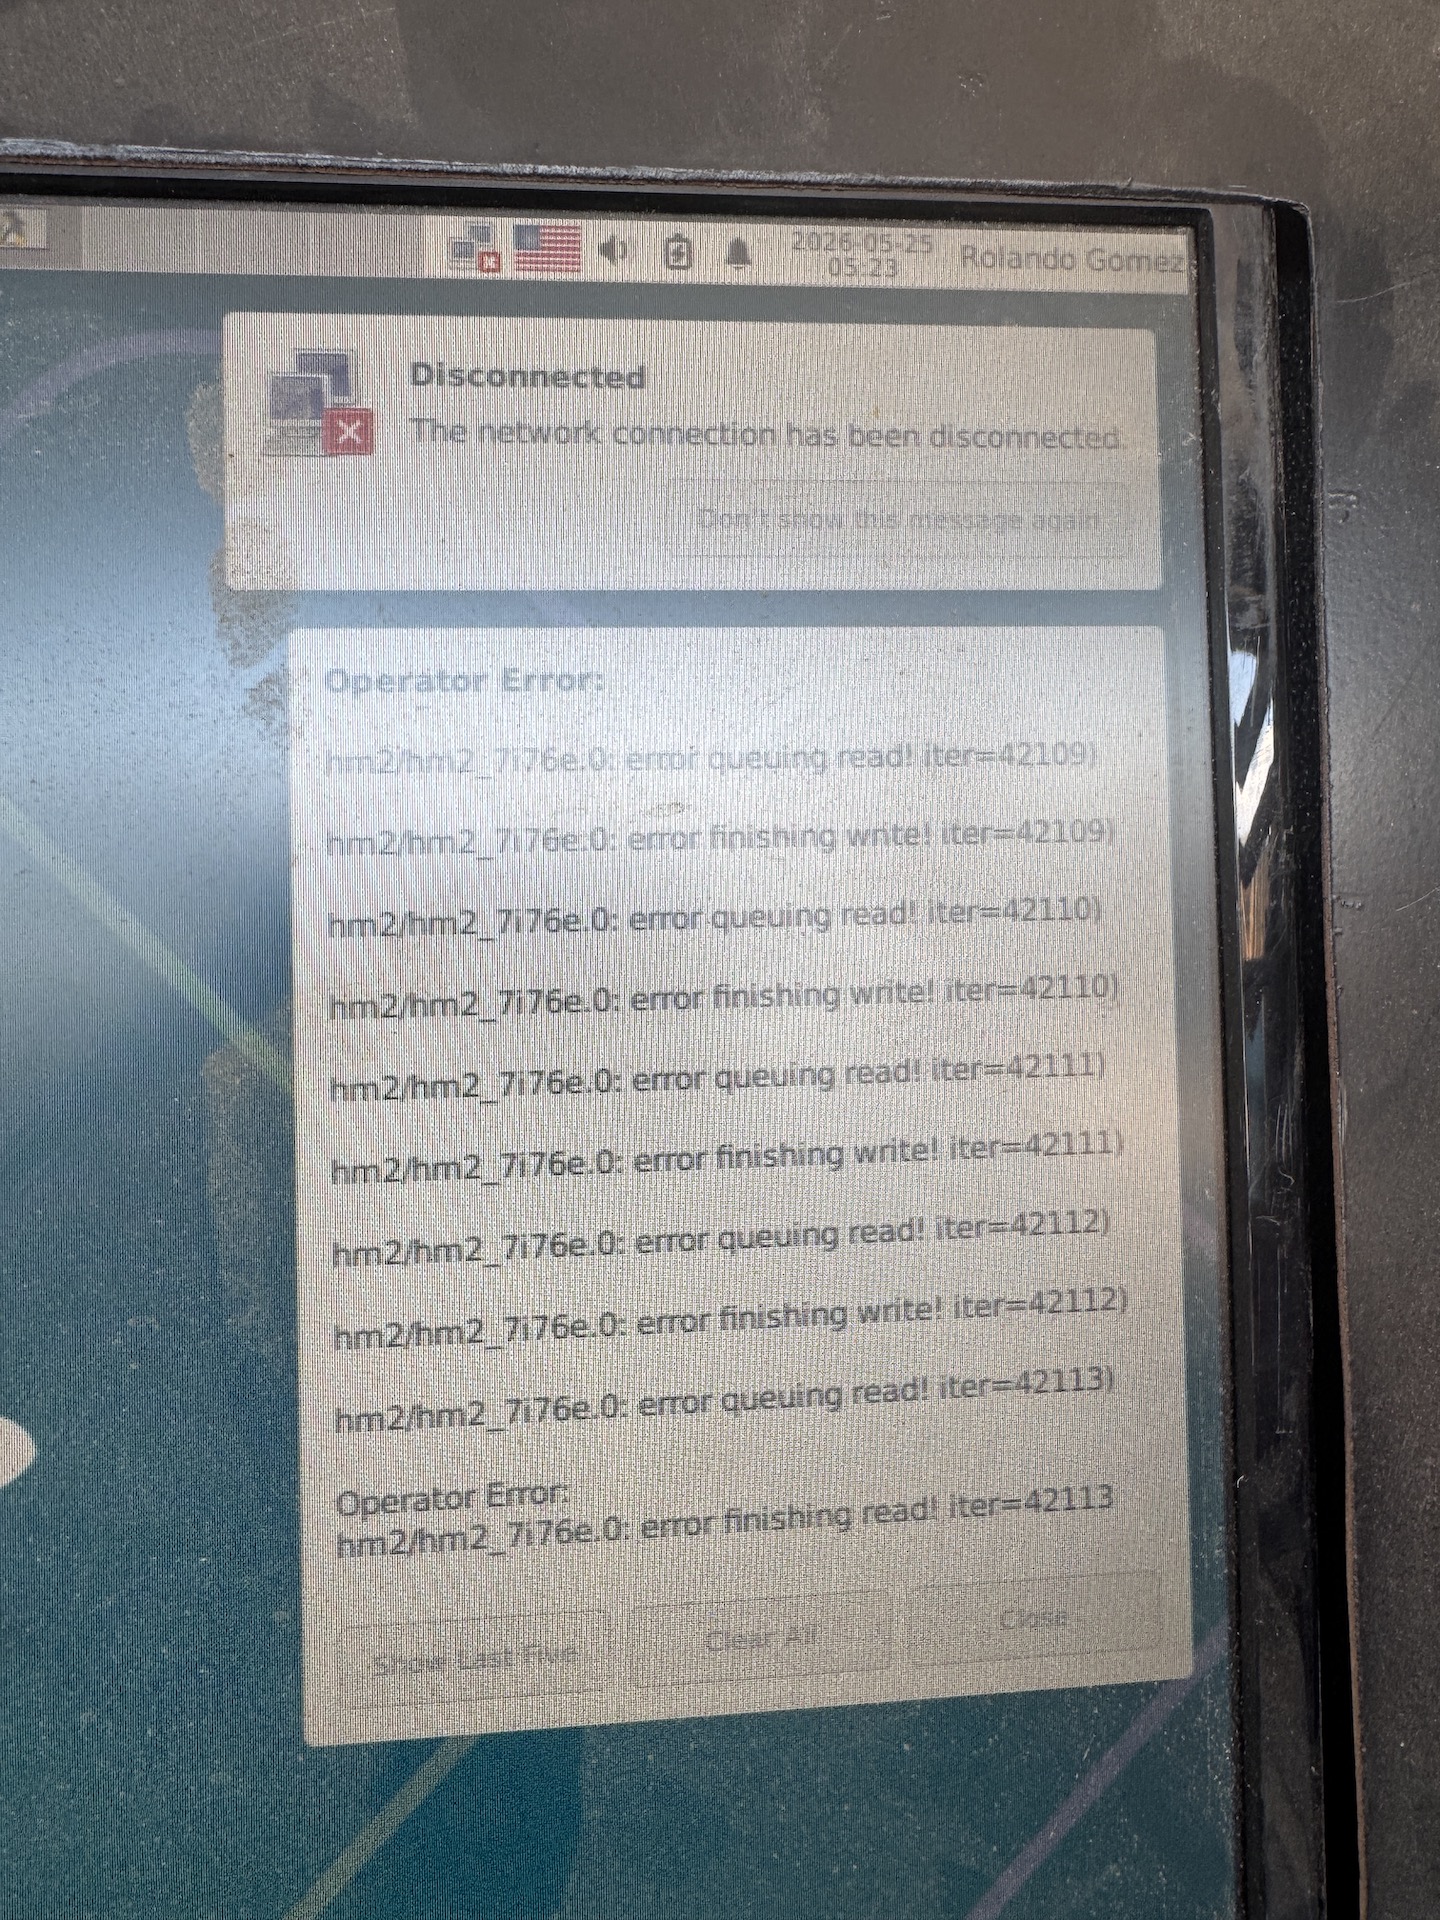
  I ran pnconf wizard and made a configuration for my CNC plasma table. I am able to home and jog my machine for about a minute until I get this error. 
It seems like the ethernet connection is disconnecting on its own somehow. Any ideas on how I could get the ethernet to stay connected so I can use my machine.
  • djdelorie
25 May 2026 20:04
Replied by djdelorie on topic Probe tripped during non-probe move deadlock
I have a probe that bounces during the G0 move away after probing.
  • 5_Zylinder
25 May 2026 19:13 - 25 May 2026 19:19
Replied by 5_Zylinder on topic Hurco BMC 30 AP
I replaced the optocoupler, and the output is working again.I attempted to set up the tool changer. Unfortunately, I keep receiving the following error messages when starting LinuxCNC. Attached is my .ini file.
  • andypugh
25 May 2026 18:49
Replied by andypugh on topic Probe tripped during non-probe move deadlock
I don't think that a better debounce is the solution. We really ought to be able to solve this in the base code. Unless you have a probe that ounces after the machine has stopped moving.
  • andrax
25 May 2026 17:30
Replied by andrax on topic Jumping motion with XHC-WHB04B pendant
You may have set the deceleration and acceleration ramps too steeply 
  • andypugh
25 May 2026 17:28
The controller doesn't care about the size of the motors, and there are many working EtherCAT systems out there running LinuxCNC.

You probably want to be running the master / dev version of LinuxCNC at the moment as there are various new features aimed at EtherCAT in there (for example the ability to run a initialisation step in the drivers as soon as realtime starts).
  • andypugh
25 May 2026 17:25
Replied by andypugh on topic ABB IRB140
First see if you can work out or find documented the Denavit-Hartenberg parameters for the robot.
Also look at the sample robot configs which include a visualisation of the robot, For example:
linuxcnc/configs/sim/axis/vismach/puma/ in the config picker.
  • andypugh
25 May 2026 17:18
Have you tried creating a config with either the built-in PnCConf wizard, or the MesaCT wizard?

linuxcnc.org/docs/stable/html/config/pncconf.html

github.com/jethornton/mesact
  • andypugh
25 May 2026 17:12
Replied by andypugh on topic Jumping motion with XHC-WHB04B pendant
I can't help with a fix, but it might help to work out where the fix belongs.
Try plotting the position-cmd in Halscope to see if the problem is in the commands from the WHB or is inside HAL itself.
Displaying 3556 - 3570 out of 11384 results.
Time to create page: 0.150 seconds
Powered by Kunena Forum