
Search Results (Searched for: )
- PCW
LinuxCNC, and then turn on the spindle at 1/2 speed.
Then, in a terminal window, type:
halcmd show all | grep spin > spindle.txt
and post the created spindle.txt file here.
- clayton2ndtry
- PCW
in the DSPIC code (the setup and working images) This is done to allow
live updates.
This is the complete 7I76 image:
- mariob
und danke für die Antwort Luca, ich lasse mir etwas Zeit, sorry. Der Rechner läuft noch nicht wieder, ich strukturiere gerade meine EDV neu, Winterarbeit. Sobald das erledigt ist geht es hier weiter, ich melde mich, das ist bestimmt noch nicht die letzte Frageimage missing /media/kunena/emoticons/smile.png.
Gruß
Mario
- Aciera
You might want to give some more information on your vfd and how you have wired it to your 7i96s.
- Mark Kraus
I am curious if the mesa config is better than the pncconf and can I make a separate profile in it? I was working on getting the encoder working and at the same time I changed some settings and now my spindle does not work. I have the m3 come on and the vfd shows hz rising and then stabalizing but the fan on the vfd does not come on and i have no 3 phase coming out. I should not have been messing with the wiring and at the same time changing settings and will try not to do that again, but for now I dont know which one it is, the settings in pncconf or a wiring issue.
- rodw
-

- grandixximo
-

test with this, this is dlen2 code
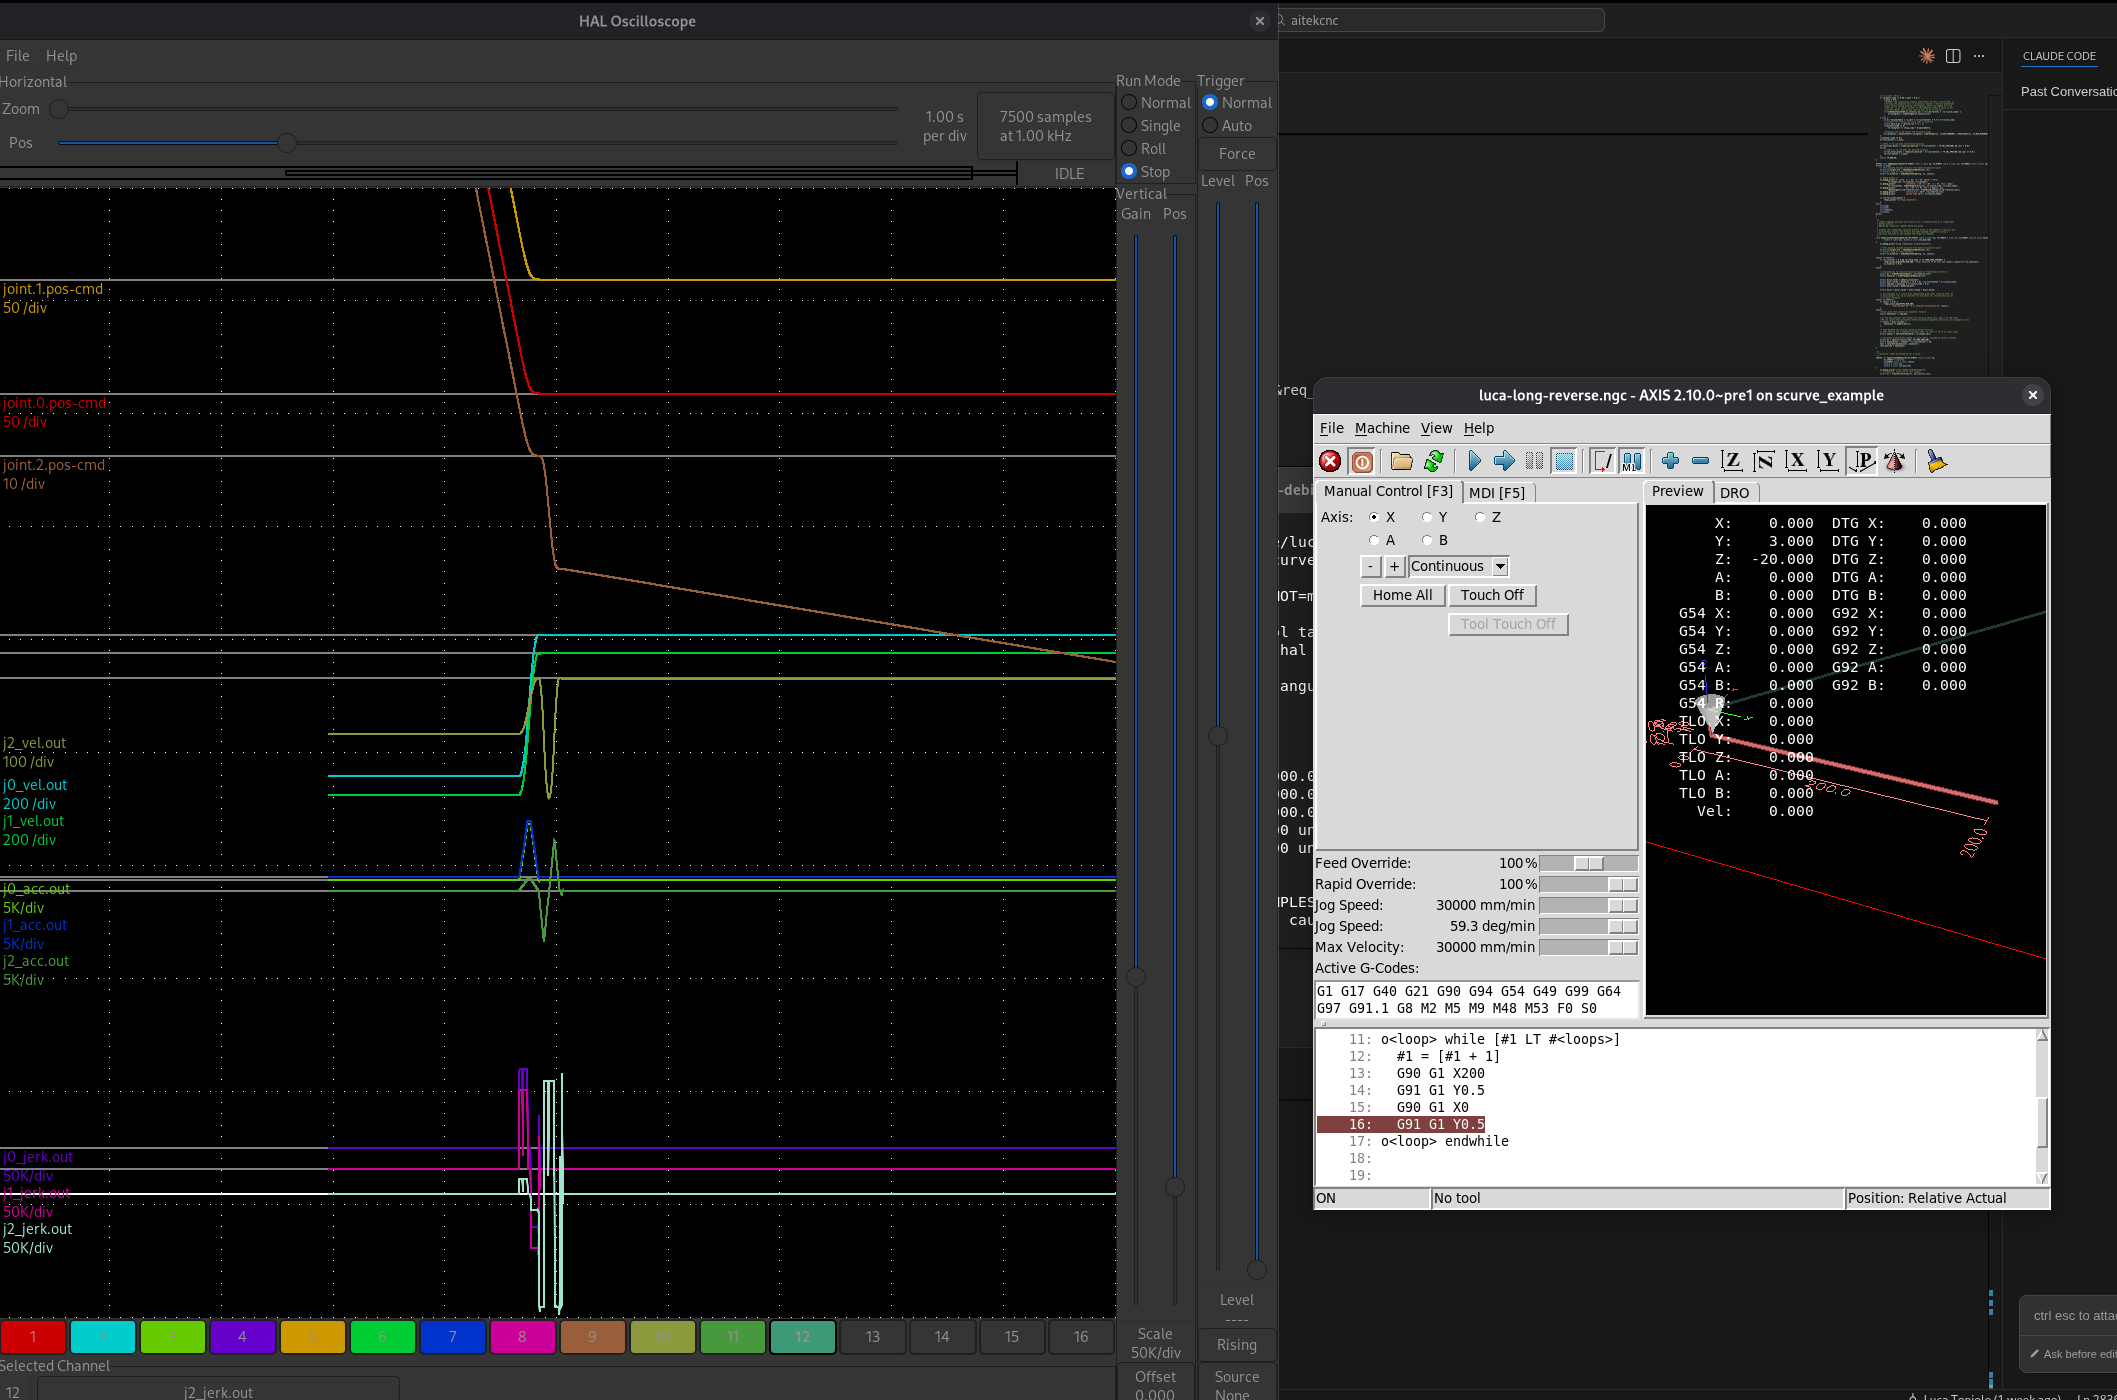
this is without
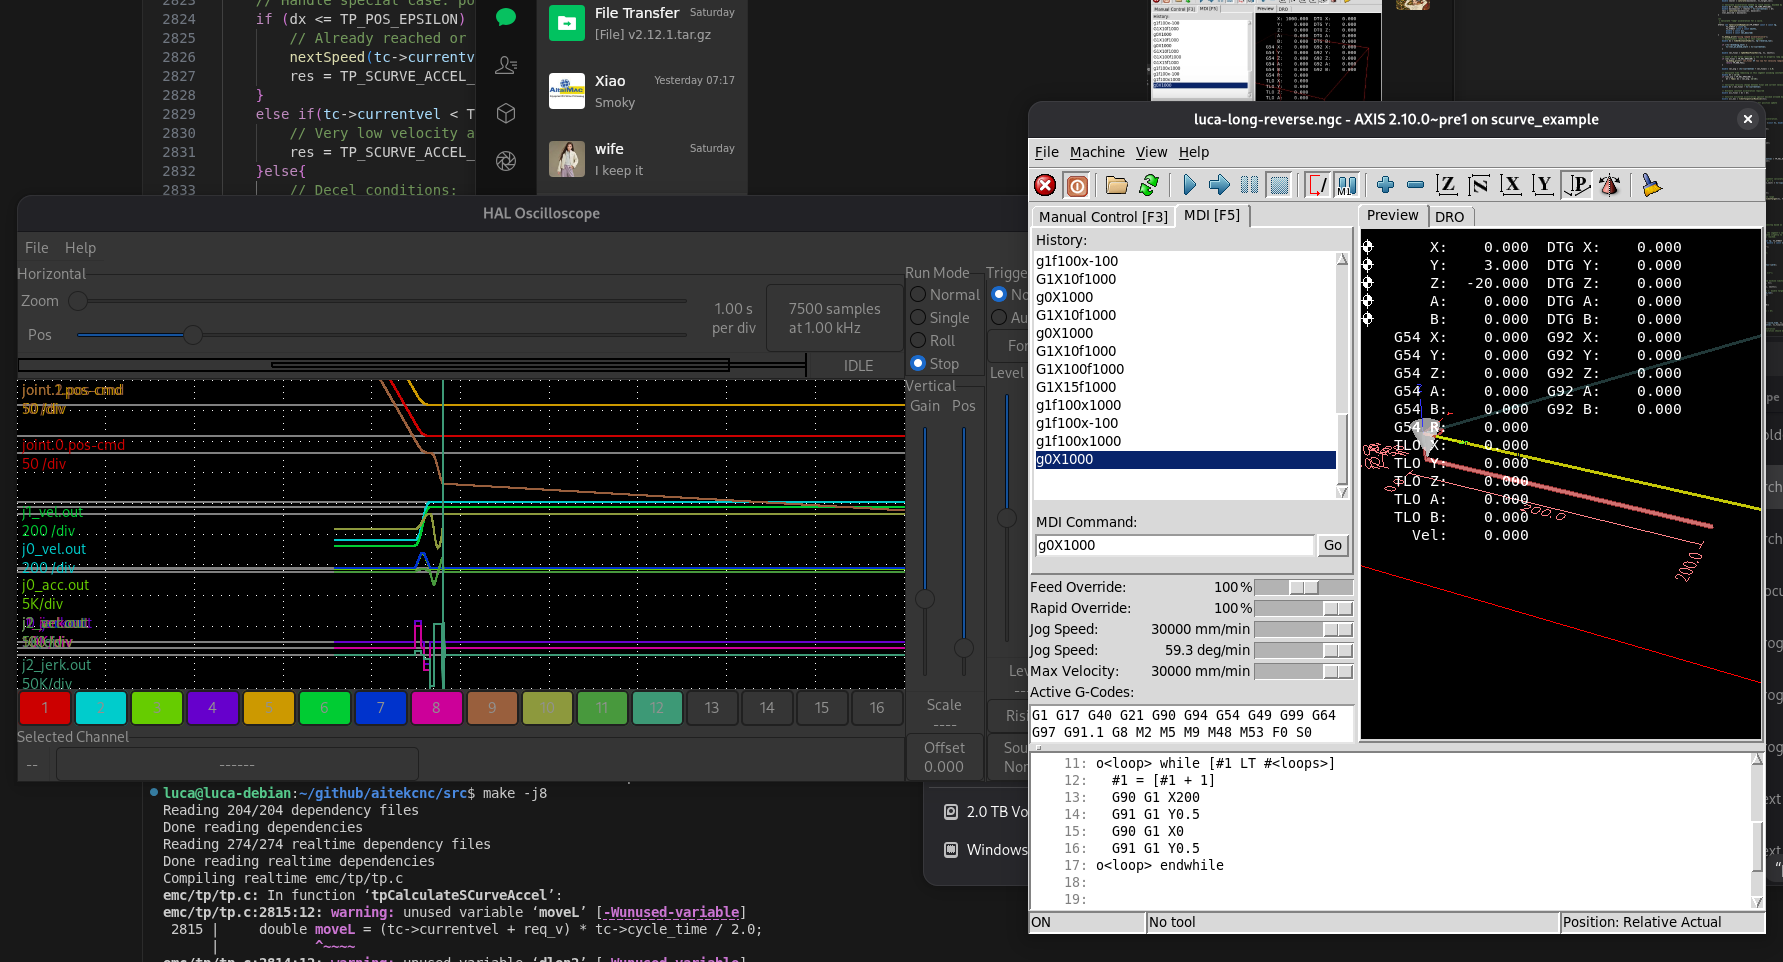
we know is not ideal, but at the moment, best we can do
- ruediger123
After commenting out " || (dx - moveL <= dlen2)", the scope looks like this.
- hhscott
- grandixximo
-
No apologies needed image missing /media/kunena/emoticons/wink.png, I discussed this with YangYang. We agree this is a real issue on some hardware, but it should not be in the TP.The TP's job is to generate a geometrically correct path with proper dynamics. It does that. The path is correct.Transport delay compensation is a communication/hardware layer problem. Different drives, different bus cycles, different delays. Some drives have 0x60B1, some don't. Some run 250µs, some run 1ms. This varies per setup.Your HAL component is the right approach. It sits between TP output and drive input, users can tune lead_cycles and kff for their specific hardware. People who need it use it, people whose drives handle it properly don't.Keep the TP clean, keep hardware compensation in HAL. Well defined purposes.
Code:My apologize ... sorry I can not show same speed test because I am currently weeks out of office but we can just multiply or devide values ... because it is linear dependecy during constant speed movemet ... I can just customize current images to show exact difference ... compensation off ferror = 0.125mm at 15m/min ... compensation on ferror = 0.00009028mm at 1m/min and multiply it by 15 we get 0,0013542mm which is significantly less then 0.125 .. What I remember from testing by my short eyes it whas something near 0.001mm during that 15m/min testing was done with bentch top setup without any load presented... just AX5106 with AM8xxx motor but I can go home for testing this weekend to create exact speed difference testing if it is neccessary
- Aciera
2.
Still have no clue what could be wrong. The at speed light comes on but nothing in halshow. Could someone please guide me?
We might be able to if you actually told us what your are trying to do. You maybe want to connect a encoder to your spindle and are not getting the 'spindle-at-speed' signal to work in hal? Hardware used (a MESA board maybe)? If so which one?
- meister
2. Closed Firmware & 'Over-engineering' I respect the Open Source philosophy, but io_decoder is a professional project that includes dedicated hardware. The 'over-engineering' you see in the HAL driver is actually optimization. While a user-space component can work, a dedicated C component ensures deterministic polling and much lower jitter. If you want a 'professional feel' on the handwheel, those milliseconds matter.
ahh, ok, This is what professional code looks like when compiling.
“Bare-Metal” Firmware (No Bootloader)
We have removed the Arduino bootloader for two critical reasons:
Safety: No random pin state changes during startup (typical of bootloaders).
Speed: The board is operational within a few milliseconds.
what about updates ?
- unknown

- NWE
-

of=/path/to/my/hardDiskBackup.img
first make sure your directory has enough free space to hold a file as large as your source disk.
writing that img file to a new empty drive then instead change the if= bit:
if=/path/to/hardDiskBackup.img