Search Results (Searched for: )

  • Unlogic
04 Nov 2025 10:42 - 04 Nov 2025 20:55
Replied by Unlogic on topic How do I close a g-code file in Gmocapy?
I made some progress on this issue.

The following command will show all open files in Samba which have some form of lock:

smbstatus -L

Edit: Ignore the text below it gave some weird side effects after some more testing.

Adding the following lines to the configuration of the share in smb.conf allows me to overwrite the files even though they are locked.

oplocks = no
level2 oplocks = no
strict locking = no

I'm using Probe Basic and it recently received a "RELOAD PGM" button in the development version which is very welcome.

However it doesn't seem to pick up the changes if I overwrite the file on the share and press the "RELOAD PGM" button. But if I open another file and then open the first file again it picks up the changes right away.
  • vmihalca
04 Nov 2025 10:09
Replied by vmihalca on topic How do I program an 8 figure oil groove?
Yes, this is what I am talking about. I attached a picture with a few oil groove patterns among which there are the grooves I am talking about.
  • mariusl
04 Nov 2025 09:19 - 04 Nov 2025 09:22
Replied by mariusl on topic USB activity causes network error
I got this result when I ran the checkmask file. I am sure that I don't know how to use isolcpu. I want to isolate two cores with last core being 7.  SO cores 6 and 7 to be used for linuxcnc.

Cores: 8
Actual CPU Mask: ff
Desired CPU Mask: 128
IRQ: 24
Kernel command line: BOOT_IMAGE=/boot/vmlinuz-6.1.0-40-rt-amd64 root=UUID=bfdcf9b0-7caa-4c4b-b4c3-585accea347a ro quiet isolcpus=2,7
  • axemas
04 Nov 2025 09:08 - 04 Nov 2025 11:06
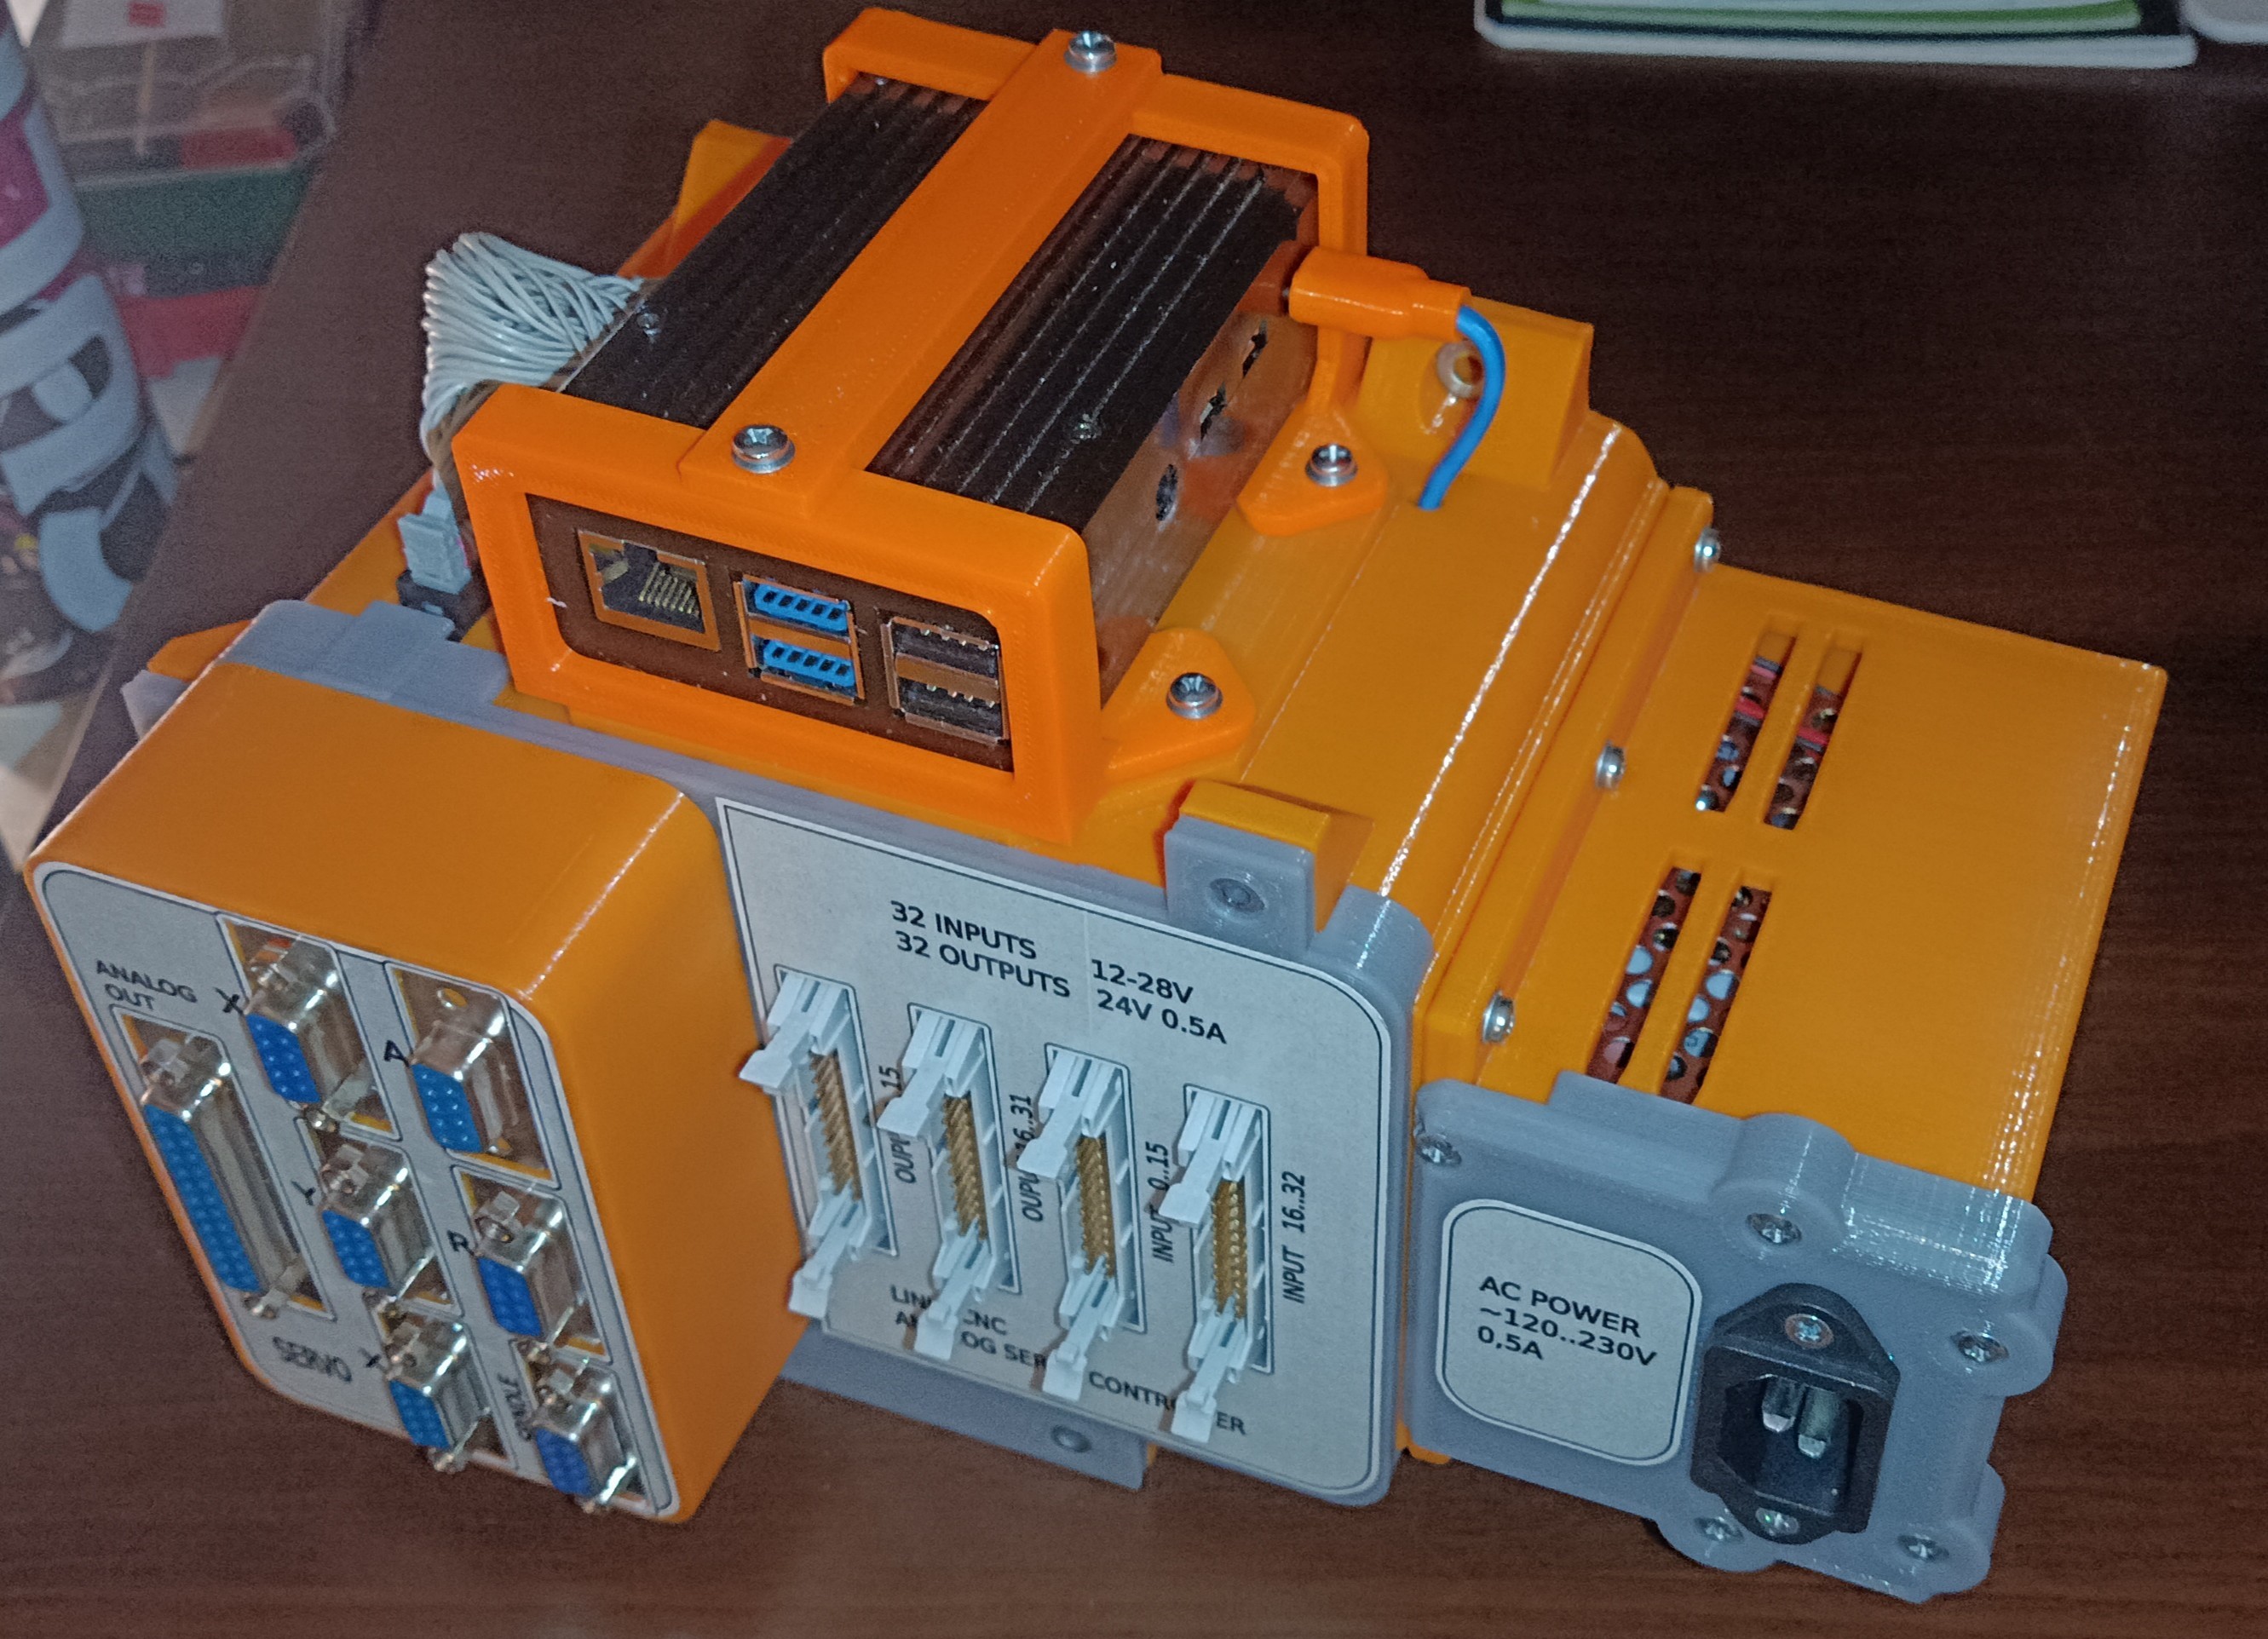
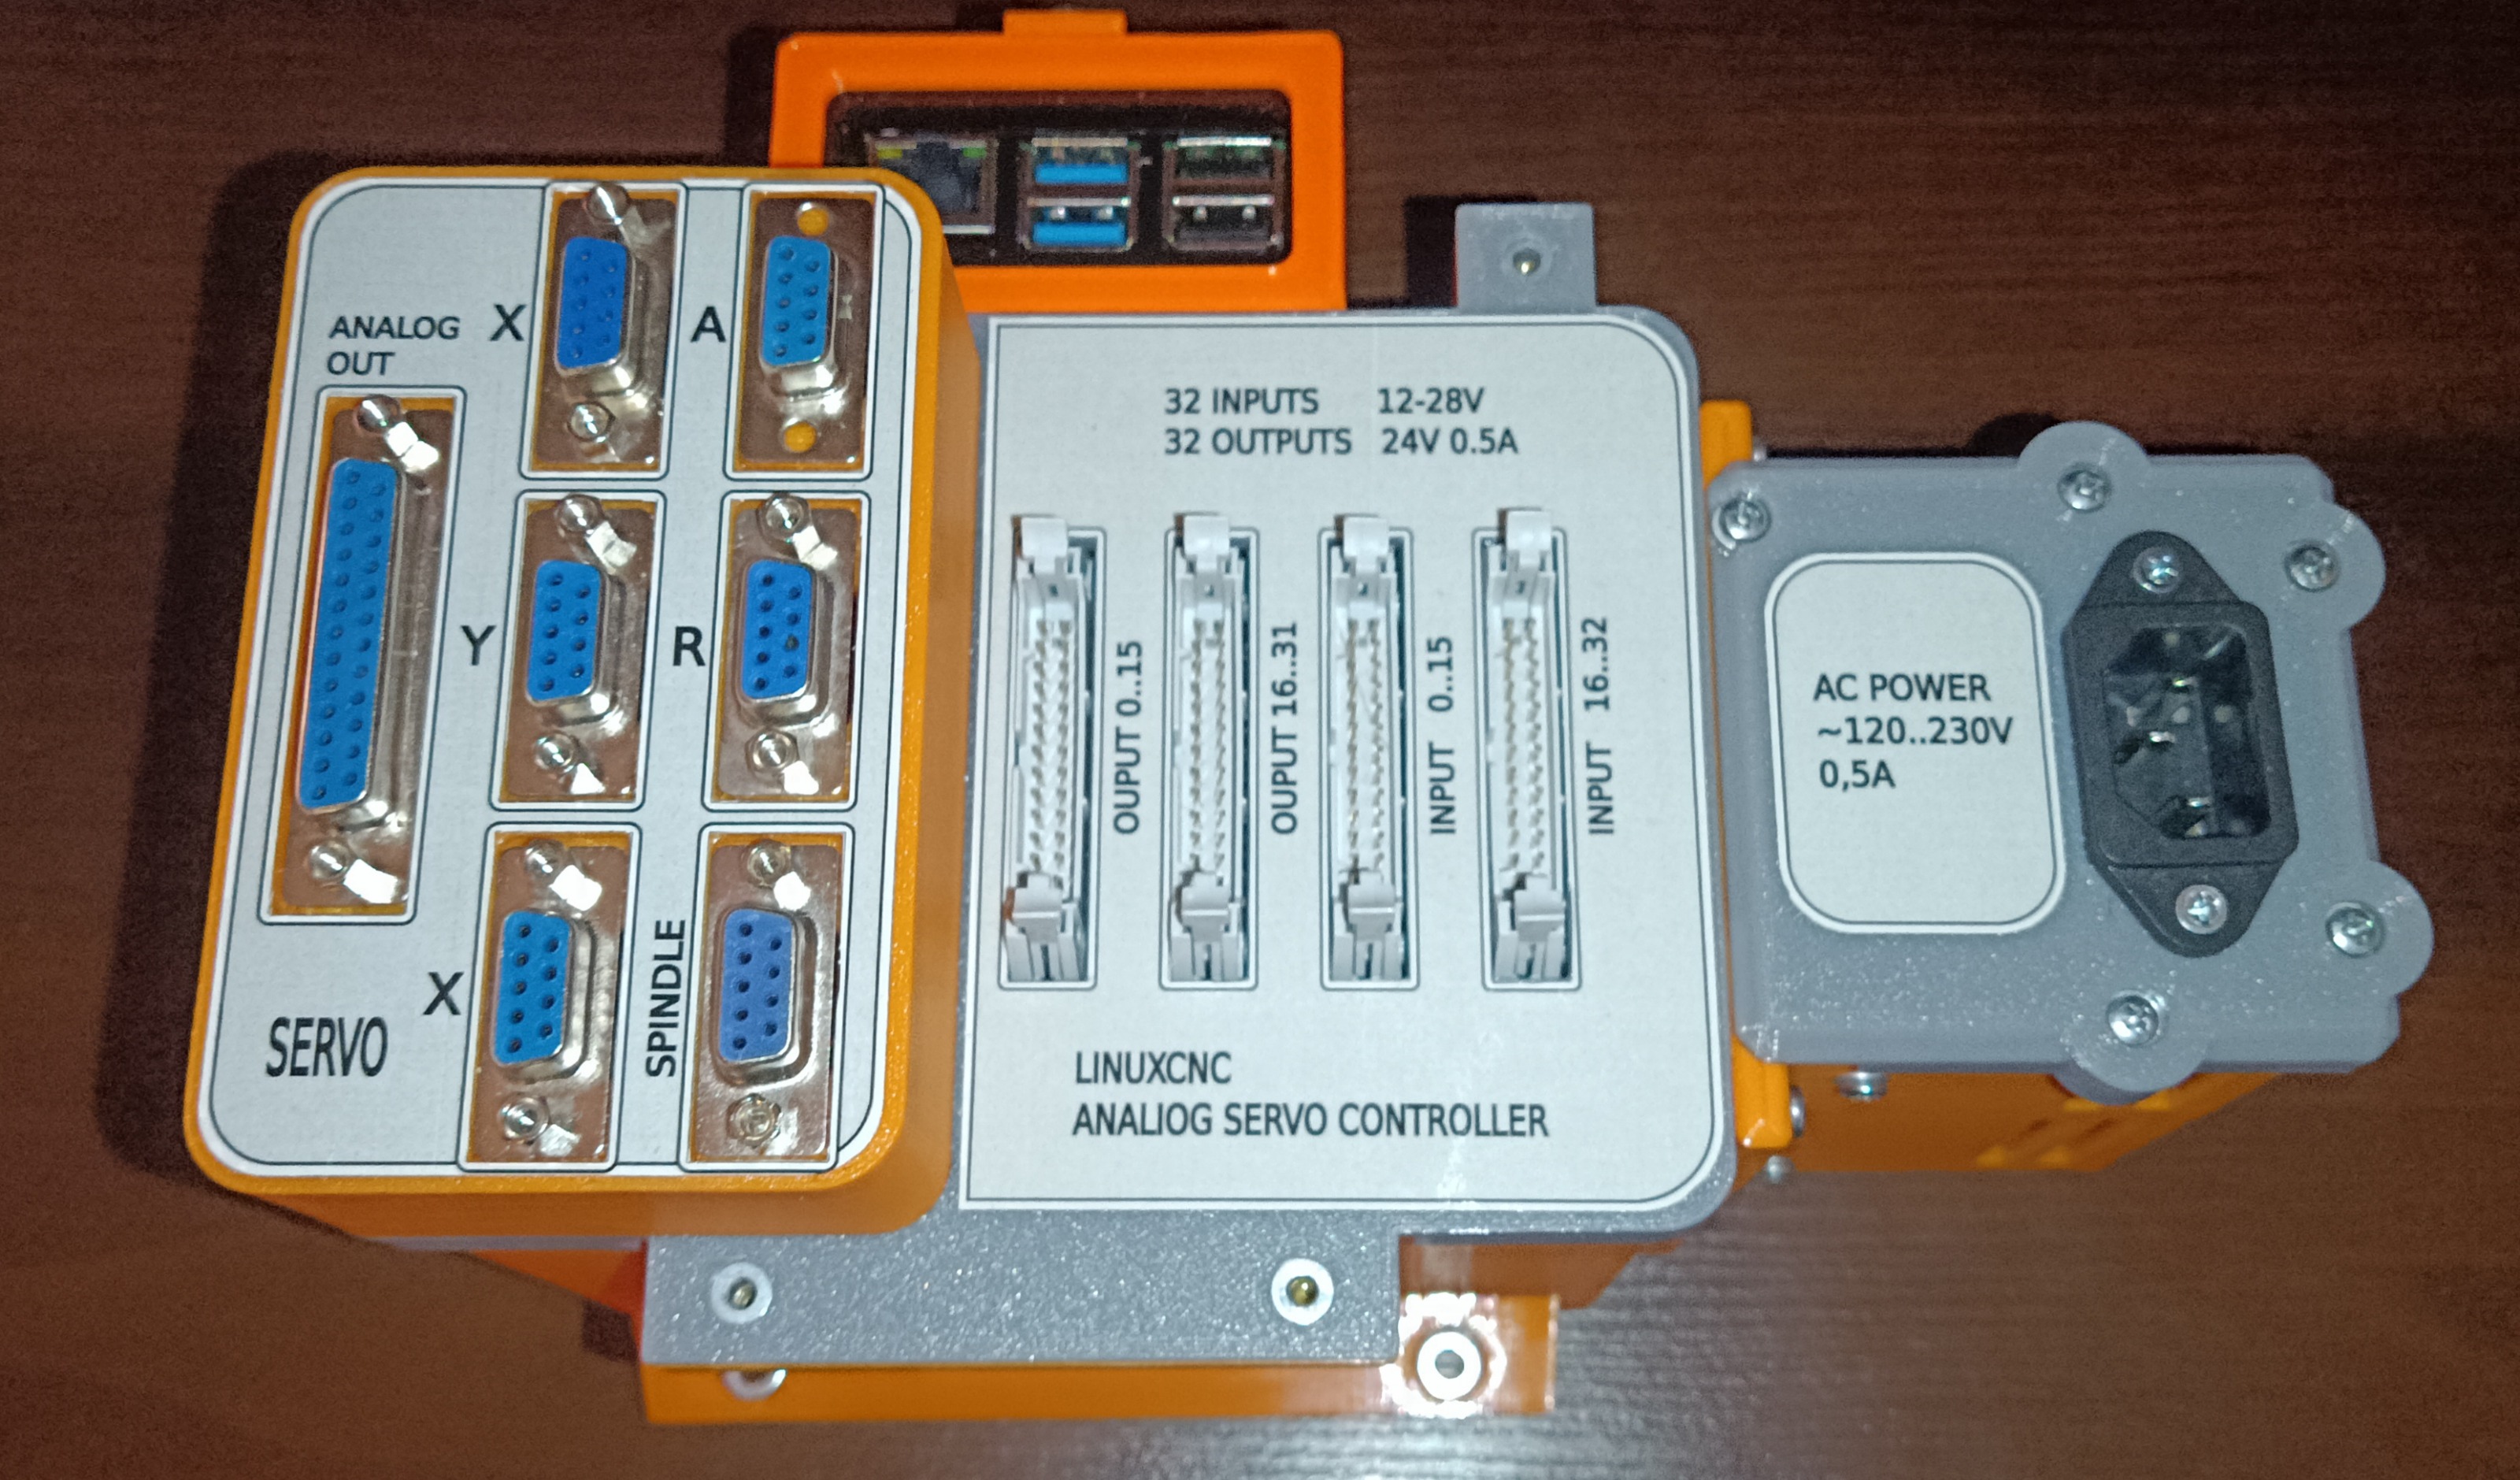
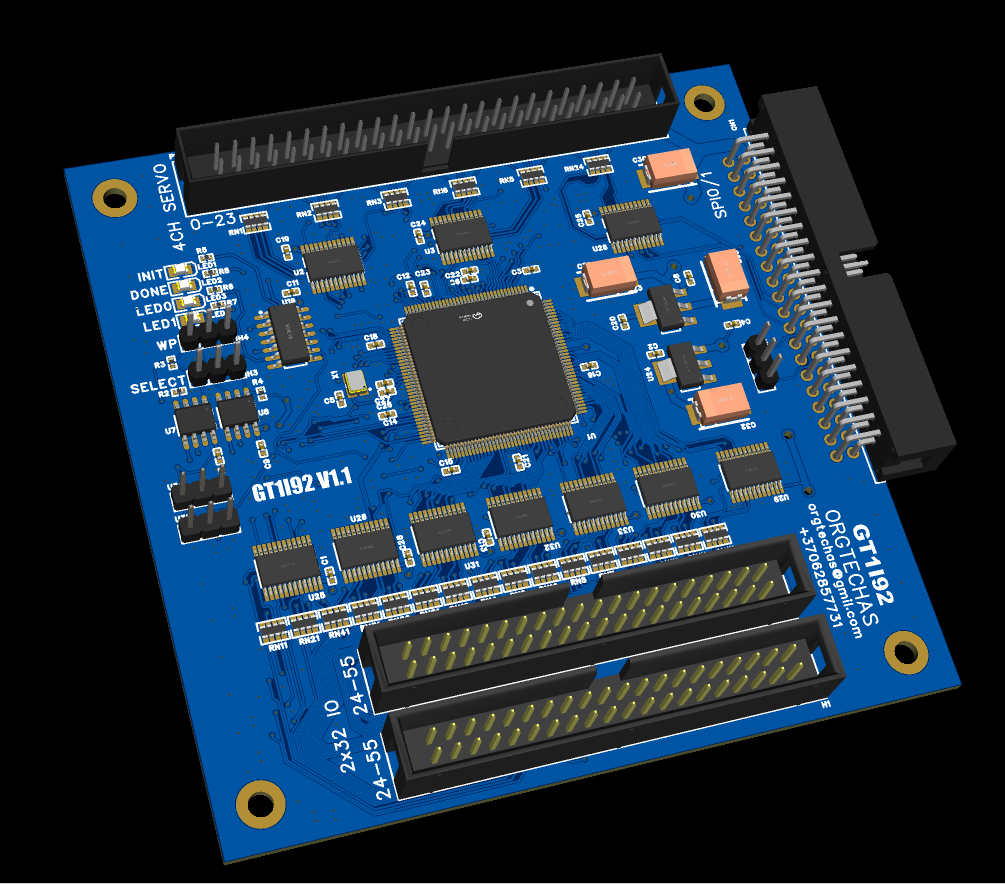
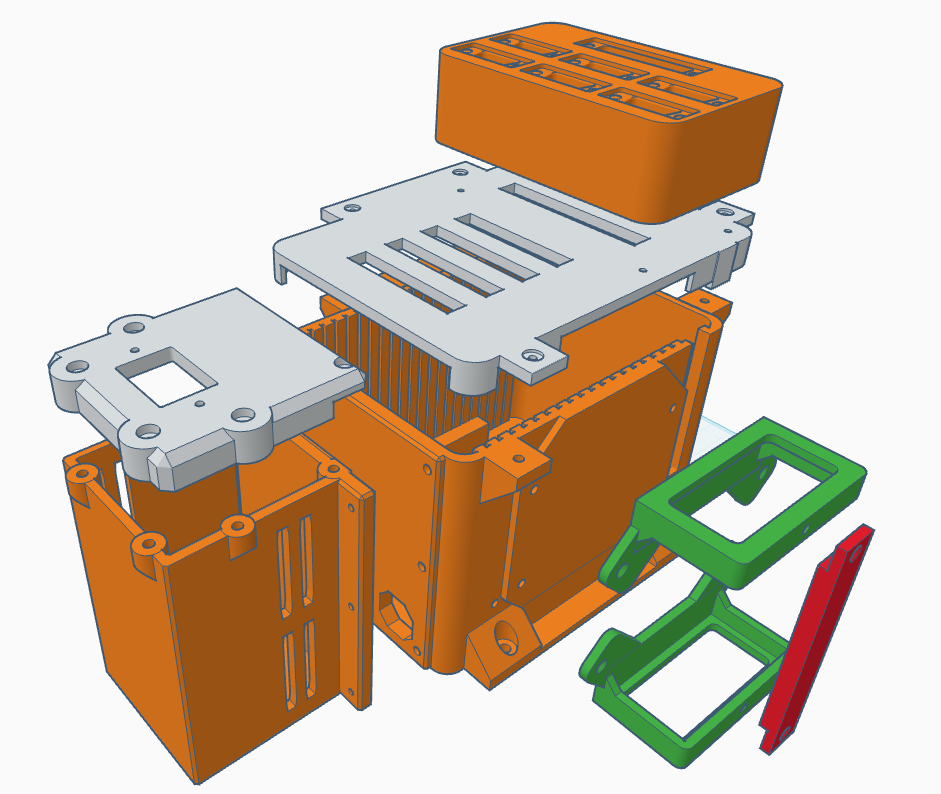
Hello, I have a few questions.I am building a complete computer with fpga and all other boards, and I have some questions:
1. What firmware should I choose, mesa, remora or, write my own?
2. I want a universal solution, so what input/output boards should I design?
3. Should I design my own case or choose a ready-made one?
Here is one of the prototypes:
-32 outputs 24v 0.5A, 32 inputs 24V, four boards
-4 analog servo -10V.. 10V outputs, 4 encoders input, one board
-Fpga 96 IO board with buffers, one board ()
-Firmware - ported and modified mesa for SPI interface.
-software driver - modified hm2 driver from source code.
-3d printed case.
-Computer Raspberry pi 5 aluminum case

all works fine and stable 
   
  • gravedigger
04 Nov 2025 09:00
ECAM 5 POST Processors was created by gravedigger
I’m just getting started with LinuxCNC and have switched over from Mach4. I’ve been using the Italian ECAM 5 software and would like to continue using it. How different is the G-code between Mach and LinuxCNC? What are the main differences?
  • Jamanji
04 Nov 2025 08:11
issues with MESA to SCARA kins was created by Jamanji
Hi all,

First time poster so i hope you'll excuse if this is a simple fix. I'm attempting to make something like an ArcDroid for a uni project but I've run into a road block. I'm using a MESA 7i96s as my controller and two knock off tb6600 as my drivers. after using the Pncconfig i got both my motors spinning in the XYZ setup, but once i tried to change it to SCARAkin, it didn't work. At first it loaded but was still in the XYZ config, then once i changed enough it stopped working outright. At the moment I'm aiming for simple motion control and I'm not sure if the issue lies in something I'm doing or in my coding. I've made several attempts so i have multiple files, mostly just coping from the existing SCARA config that exists in LinuxCnC but also from consulting with ChatGPT. Any help would be greatly appreciated, functional files for something like this would be a life saver and a more direct line to someone who is happy to provide help would be out of this world.
  • Hakan
04 Nov 2025 07:31
No, this is close. It should work. But I have sometimes noticed that the ethercat master
uses old settings and not the new ones. Keep 1a00 and 1600.
Try these in order
"ethercat rescan",
if no change "sudo systemctl  restart ethercat",
and finally if no change, restart PC and drives.
See error messages in syslog when you start linuxcnc

You should also, not causing the problem with the drive, but still, change the line order in the hal file to
Code:
addf lcec.read-all servo-thread addf cia402.0.read-all servo-thread addf motion-command-handler servo-thread addf motion-controller servo-thread addf cia402.0.write-all servo-thread addf lcec.write-all servo-thread
 
  • Gartenzwerg
04 Nov 2025 07:26 - 04 Nov 2025 07:27
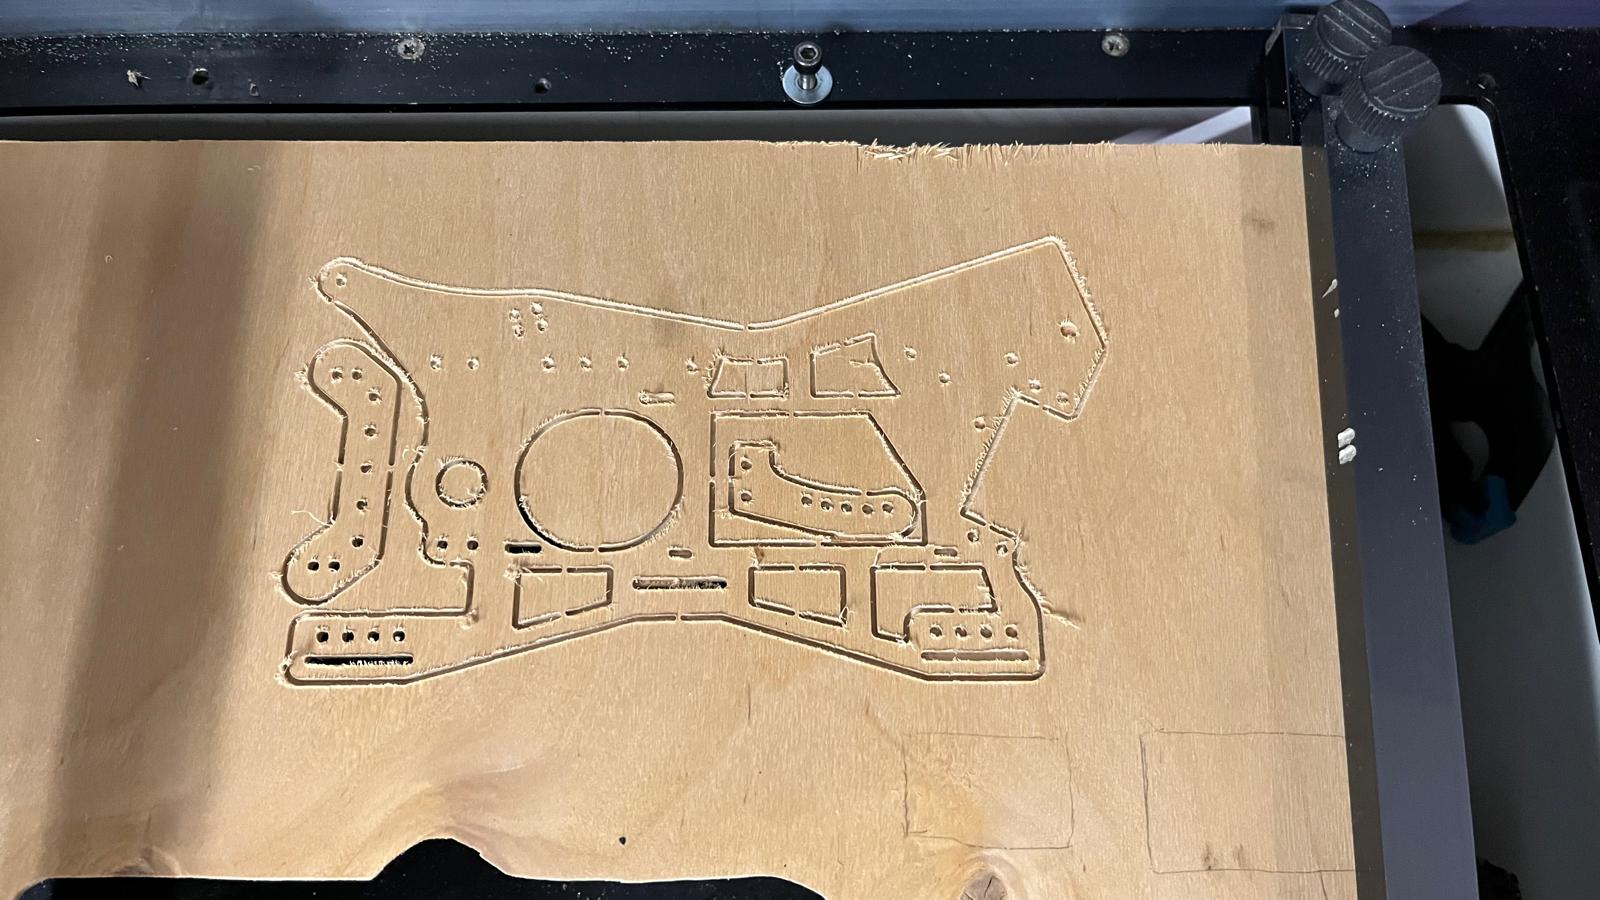
Replied by Gartenzwerg on topic Tipps für aktuelle LinuxCNC Hardware gesucht
Ihr habt natürlich recht! 
Der Stift war doch wackeliger eingespannt als gedacht.
Eine Fräsung in einem Reststück ergibt ein schönes Ergebnis - damit bin ich zufrieden!


Die Mesa-Karte ist immer noch am Weg, damit spiele ich mich vermutlich im Winter mal.

Ich bin jetzt noch am überlegen ob ich die Ansteuerung der Spindel-Drehzahl auch über LinuxCNC machen möchte, einfach um unabhängig von der eingebauten Platine zu sein.

Laut dem Blog von Entropia brauche ich die folgende Ansteuerung:
Über SPI auf den Pins 14,16 und 17 wird die Drehzahl eingestellt.
Die Datenrate ist 30 kHz; die Daten werden in 16bit-Worten (Big Endian) übertragen.
Bei einem ATMega328p mit 128 kHz Clock haben die folgenden SPI-Settings funktioniert:
SPCR = _BV(SPE) | _BV(MSTR) | _BV(SPR0) ;
SPSR = 1 << SPI2X;

Die gesendeten Werte sind linear Interpoliert zwischen:
14000 RPM in Editasc -> 2866
20000 RPM in Editasc -> 4094 (0x0FFE -- erster Nibbel soll stets 0 sein!)

man kann die Spindelgeschwindigkeit auch mit 64kHz (= 8MHz F_CPU / Divider 128) senden.

Wäre das eurer Meinung nach eher ein Fall für einen externen Arduino, oder kann das der Raspberry ebenfalls erzeugen und ausgeben?
  • unknown
04 Nov 2025 05:16
Replied by unknown on topic Motor Driver Electrical Question

The reason I mentioned the 48V not being necessarily ideal is some electronics are made with almost zero headroom above their limits.

For example, I own a 12V DELTA power supply that can be adjusted to output 14VDC; however, its filter caps are only rated for 16V!

That's 2V of headroom!

Which is absolutely fine, that is the way the designers intended.

Discussion on voltage values
www.eevblog.com/forum/beginners/is-there...igher-rated-voltage/
  • Quail
04 Nov 2025 04:01
Hello, this is my first post in the forum. Have used it a lot to set up my machine to the point it is currently at.

So far I have it all pretty much set up and good to go with the QTPlasmaC UI, but I need some help removing the Z-axis movement from the machine.

The machine is a 2 axis plasma tube cutter, one for the rotary motion, and one for the linear. The rotary axis is actually treated like a linear one. with some clever sheetcam post processing I have created something where you can input a flat profile of the tube, and get prompted to input the tubes diameter that will do some maths to get the correct feed rate at the surface of the tube, depending on the tube diameter that was entered.

My problem starts when the plasmac software tries to home the Z-axis, even though there should be no z-axis instructions in the g-code. Then when the g-code runs it sort of gets stuck at the homing of the Z-axis, that shouldnt exist....Is there a good way to remove it entirely from the machine, and maybe even the qtplasmac UI? 

I have tried to comment out all the Z-axis parameters in the .ini and .hal files, but then i just get errors when opening up the cnc software. This is for a school related project so go easy on me!image missing /media/kunena/emoticons/smile.png (I have added a screenshot of the machines design in cad)
Thanks! 
  • bentiggin
04 Nov 2025 00:53
Replied by bentiggin on topic Hypertherm hsd130 interface
Thanks again
  • gardenweazel
03 Nov 2025 22:38
Replied by gardenweazel on topic Motor Driver Electrical Question
As always, thanks to all for your valuable feedback.
  • tommylight
03 Nov 2025 22:09
Replied by tommylight on topic Hypertherm hsd130 interface
I have the delay set to 0.2 or 0.3 always, depending on thickness, i would guess 80% of my machines are at 0.3.
  • kwanlokto
03 Nov 2025 21:36
Replied by kwanlokto on topic Pathpilot Reset Functionality
Good idea! I'll add a locking mechanism to the route and see if that helps. I do already have try-except wrapping the entire endpoint.

Since I'm modifying Tormach's code directly, I'm trying to keep changes minimal to avoid breaking PathPilot's core functionality.
Displaying 11866 - 11880 out of 11916 results.
Time to create page: 0.425 seconds
Powered by Kunena Forum