
Search Results (Searched for: )

  • NWE
05 Jun 2026 17:51
Signal wire colors default to color codes representing the signal type, but can be edited. If the rat's nest is a confusing mess of same-colored wires, double-click or right click a wire to edit its color. All wires connected to the same output are synced and will change to your edit.

You can also change the wire (hal signal) name, but the current version of halflow gives you no capability to load your edits back into your linuxcnc hal config.
  • dlv
05 Jun 2026 16:54
Replied by dlv on topic Question about an Intel NUC core-i3
Also not sure about the frequency on cpu 1. The governor looks right but current freq = 400Mhz. This doesn't seem good if I understand it right. (again very new to this)

$ sudo cpupower -c all frequency-info
[sudo] password for cnc:
analyzing CPU 0:
driver: intel_pstate
CPUs which run at the same hardware frequency: 0
CPUs which need to have their frequency coordinated by software: 0
maximum transition latency: Cannot determine or is not supported.
hardware limits: 400 MHz - 2.10 GHz
available cpufreq governors: performance powersave
current policy: frequency should be within 400 MHz and 2.10 GHz.
The governor "performance" may decide which speed to use
within this range.
current CPU frequency: Unable to call hardware
current CPU frequency: 2.10 GHz (asserted by call to kernel)
boost state support:
Supported: no
Active: no
analyzing CPU 1:
driver: intel_pstate
CPUs which run at the same hardware frequency: 1
CPUs which need to have their frequency coordinated by software: 1
maximum transition latency: Cannot determine or is not supported.
hardware limits: 400 MHz - 2.10 GHz
available cpufreq governors: performance powersave
current policy: frequency should be within 400 MHz and 2.10 GHz.
The governor "performance" may decide which speed to use
within this range.
current CPU frequency: Unable to call hardware
current CPU frequency: 400 MHz (asserted by call to kernel)
boost state support:
Supported: no
Active: no
  • dlv
05 Jun 2026 16:45 - 05 Jun 2026 16:56
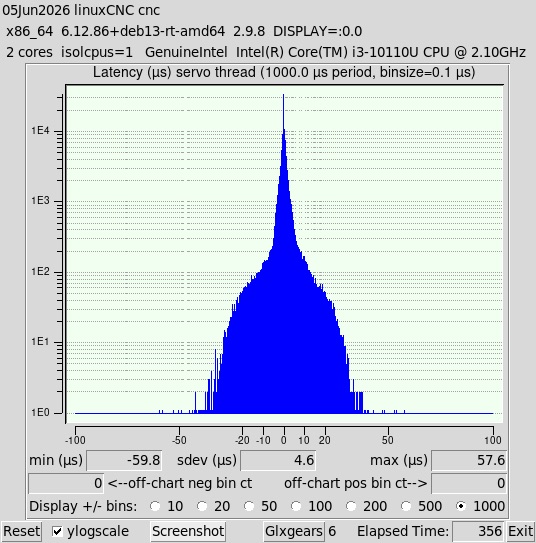
I'm very new to this so please pardon the questions.  I recently acquired an INTEL NUC core-i3 with 8GB of ram. This is intended to drive a MESA 7i76e board on a plasma table.  

tldr; I'm primarily curious to know if the latency results I'm getting are going to work (if that's possible to advise).

I've downloaded the latest iso and  went through performance tuning.  I *think* I've done all the things.  It's sometimes hard to follow all the different threads on tuning.

1) Turned off things in BIOS (hyper threading, power management etc.). This left me with two CPUs
2) Grub configured (including isolcpus)
3) CPU governor set to performance
4) IRQ coalescing disabled (intel NIC)
5) CPU core isolated for LinuxCNC (cpu 1) (I am not sure how to confirm this is actually working as intended)
6) Ethernet IRQ pinned to isolated CPU (cpu 1)

The latency histogram as a result looks like this (6 glxgears & running YT videos):
 

~60 us of max latency.   Is this worth continuing to try to use or should I be looking at a better computer?  Any advice appreciated.

I have not hooked it up to the machine yet to try it.  Hope to be attempting that in coming weeks.  Thought I'd post this to see if I need a different computer first.

- Dave

 
  • NWE
05 Jun 2026 16:28 - 06 Jun 2026 06:26
I am aware of one or more similar projects, but they did not seem to fit my use case.

This is entirely vibe coded. I have not studied the code. I chose GPL for the code license, but considering this is an ai production, I was wondering, maybe I should change it to 'public domain' ?

Use at your own risk. This software is not for use anywhere it could cause machine damage or personel injuries.

This project is currently 'pre-release' stage. It can be installed via git from [1].
you will need to install sshpass, and have ssh access over the local trusted network to linuxcnc.

Goals of this project:

1. Visualization of the current running hal config on any LinuxCNC machine over local trusted network.
2. Editing of parameter values, signal names and values.
3. Automatic detection of loadable hal components on the running LinuxCNC instance.
4. Load/Save configuration projects within the linuxcnc/configs directory.
5. Live parameter and pin value displays while connected to a live hal system.
6. Live editing of the running hal via net, setp, unlinkp, loadrt, and related commands over ssh connection to the machine directly via interaction with the nodes in the canvas. This action will be preceded by a popup strongly encouraging the user to first e-stop the machine. This will avoid having to constantly reload linuxcnc after minor edits.
7. Still dreaming...


Of the above list:

(1.) is working on my pc.
(2.) Is working.
(3.) detects installed components; to properly detect custom components make sure you fully installed with:
sudo halcompile --install my-custom-component.comp
sudo halcompile --install-doc my-custom-component.comp

TODO: find custom python components also.
(4-7) Coming soon...

[1]  git.disroot.org/nwe/halflow.git
  • djdelorie
05 Jun 2026 14:31
Replied by djdelorie on topic Post-M6 - restore X,Y ?
I could do that, but keeping track of the old Z might be tricky, especially if subroutines are involved.
I was also thinking that wrapping the "G0" and "G1" gcodes in a short python script (or even gcode wrapper) might work, but it would take more time than I waste waiting for the machine ;-)
I guess what I was originally asking was "does everyone else do it this way too?" ;-)
  • Miller Turner
05 Jun 2026 14:06 - 05 Jun 2026 14:09
does private messages not work for this forum was created by Miller Turner
Hi All,

For my account,(under profile section) the button 'private messages' is linked to " forum.linuxcnc.org/cb-profile ".
Is that just for me, or is it not possible at all to use private messages on this forum?

Thanks in advance image missing /media/kunena/emoticons/smile.png
  • rhscdn
05 Jun 2026 13:50
Test nc files was created by rhscdn
A bit of a strange request. I'm looking at `gcode.parse(...)` the CPython extension function implemented by `gcodemodule.cc`. It is a blocking call from the Python caller's perspective: it initializes an interpreter, opens the file, executes init codes, then loops over `pinterp->read()` and `pinterp->execute()` until the file finishes, an interpreter error occurs, or a Python callback aborts.

I am trying to benchmark a few things and I was wondering if anyone knows of a repository of g-code files for testing?. Basically I'm looking for a small set of .ngc files: small known-good, medium CAM, large CAM, arc-heavy, and many-short-segment. I could create some, but I thought I'd ask if a set already existed.
  • Todd Zuercher
05 Jun 2026 10:47
Replied by Todd Zuercher on topic Keyboard Jogging Problems!!!.
To answer a few questions,

Tommy,
The soft limits work fine after the machine is homed. The crash into the hard limit happened before homing the machine while jogging from a long distance to get close to the home switch before homing.

This is a new pc bought just a few months ago for this refit.

NWE and Rod
It is an ordinary USB wired keyboard, and exhibits no signs of physical sticking keys, (other than this issue while jogging).

I'll try the xset -r, and report back. But the problem is intermittent, and may not act up for testing.
  • marq_torque
05 Jun 2026 07:41
Replied by marq_torque on topic 5 Axis ParPort Stepper Setup with RTCP
Hello Andypugh,

This modification was really helpful in last machine I made. I'm now trying to achieve similar but Linuxcnc has changed a alot. Also changed a lot in kinematics. I tried to modify kinematics as per this thread but as expected it's failing with errors.

I want to use XZ and B axis with TCP along with tool length probing. Setup in this thread is working in older version.. I'm struggling to getit worli with Debian 13 rt 2.9.8 Any help or suggestions would be appreciated,


Thanks
  • marq_torque
05 Jun 2026 07:35
Replied by marq_torque on topic Kinematics for 4th Axis?
Hello Aceiera,

I'm also trying to achieve similar 4Axis TCP kinematics. I want to use Rotating spindle head and XZ gantry with fixed table. No B or C axis. I tried to compile 5Axiskins by removing C axis values but not accepting compilation. Any help would be appreciated.


Thanks
  • rodw
05 Jun 2026 07:10
Replied by rodw on topic Post-M6 - restore X,Y ?

or if there's some magic to restore it only if the next move is anything other than a G0XnYn move (i.e. G1 or G0Zn)?
You could consider adding the required magic with a Gcode filter that is applied when files are opened...
  • rodw
05 Jun 2026 07:06
I suspect the next thing (that causes intermitent latency spikes) is energy efficient Ethernet (EEE) disable it.
Also set the governor to performance.
  • rodw
05 Jun 2026 07:00

MB: P5g41t-m lx
CPU: Intel Core2Duo E7600
Memory: 4GB Ram.
2 cores is not enough anymore. You need 4 cores, 8 gb might be better but 4 gb will work.
  • snowgoer540
04 Jun 2026 22:52
Replied by snowgoer540 on topic Keyboard Jogging Problems!!!.
This sounds like an autorepeat issue I've experienced in the past.

To test if it is, open a terminal window, and enter the following command:

Code:
xset -r


Launch LinuxCNC and jog around. If the problem goes away, that's the issue and we can come up with a more permanent solution.

To turn autorepeat back on:

Code:
xset r
  • tommylight
04 Jun 2026 19:11
Replied by tommylight on topic LinuxCNC 2.9 Live image won't boot with MBR
Definitely 2.7.
Displaying 3421 - 3435 out of 11908 results.
Time to create page: 0.132 seconds
Powered by Kunena Forum


