
- Posts: 27
- Thank you received: 0
Motoman K6SB Retrofit
- boksi
- Offline
- Junior Member
-

Less
More
3 years 6 months ago - 3 years 6 months ago #268654
by boksi
Replied by boksi on topic Motoman K6SB Retrofit
After replacing caps and battery connected.
My arm is YR-K6-C000.

My arm is YR-K6-C000.
Last edit: 3 years 6 months ago by boksi.
Please Log in or Create an account to join the conversation.
- cakeslob
- Offline
- Platinum Member
-

Less
More
- Posts: 927
- Thank you received: 280
3 years 6 months ago #268684
by cakeslob
Replied by cakeslob on topic Motoman K6SB Retrofit
Thanks thats some good stufflol, yeah I did the same thing with the caps. I even tried redoing the cable. It was fine with me jiggling it for a while, but one time the robot arm lost position in that joint and the arm just dropped like a bag of shit, so I sent the motor for rebuild after that.
Hmm the MSV-02 is the daughter board on the msv-01
my arm is the SK6
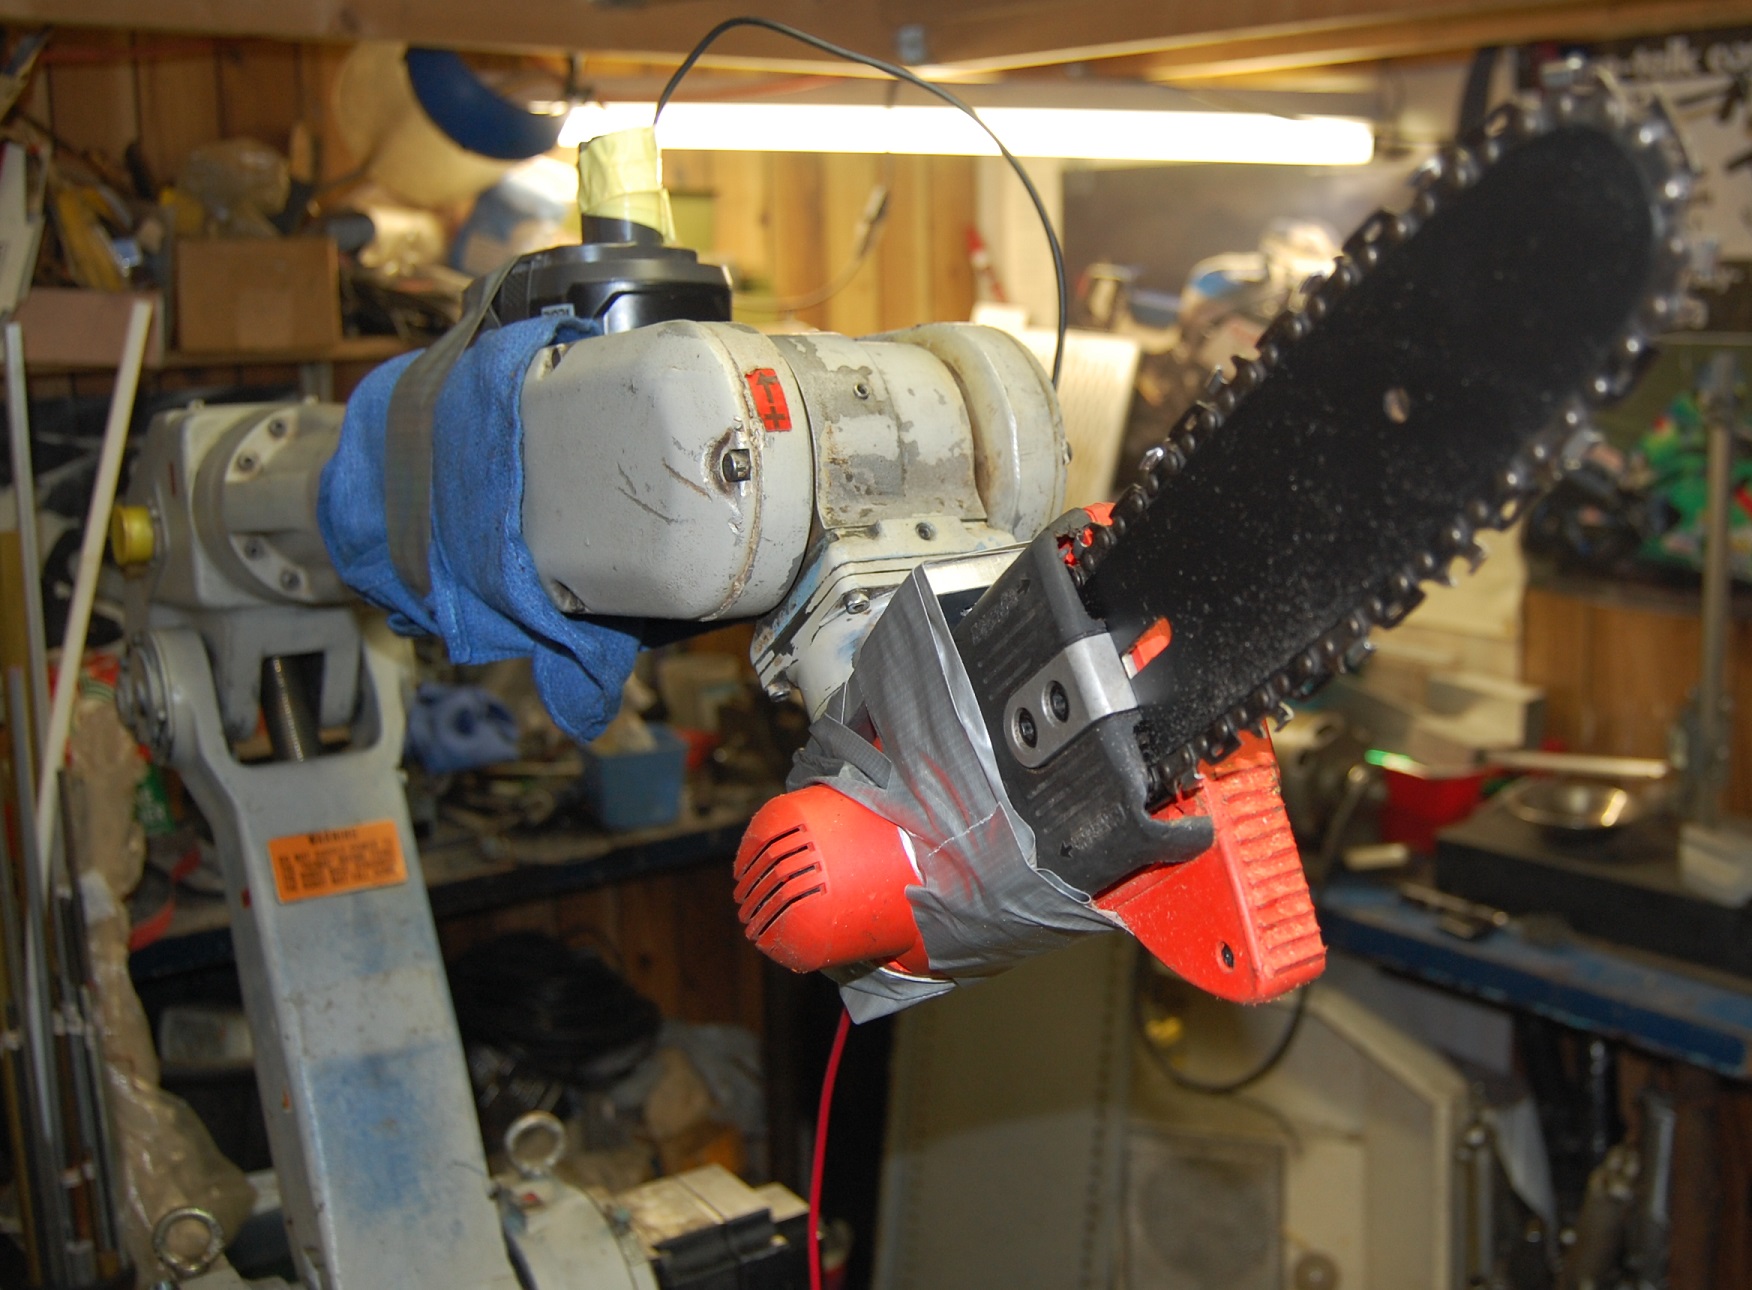
Hmm the MSV-02 is the daughter board on the msv-01
my arm is the SK6


The following user(s) said Thank You: tommylight
Please Log in or Create an account to join the conversation.
- tommylight
- Offline
- Moderator
-

Less
More
- Posts: 22011
- Thank you received: 7491
3 years 6 months ago #268697
by tommylight
Replied by tommylight on topic Motoman K6SB Retrofit
Preparing for a zombie apocalypse ?

Please Log in or Create an account to join the conversation.
- boksi
- Offline
- Junior Member
-
Less
More
- Posts: 27
- Thank you received: 0
3 years 6 months ago #268837
by boksi
Replied by boksi on topic Motoman K6SB Retrofit
Mine is also preparing for sometning seems for bodybuilding competition 
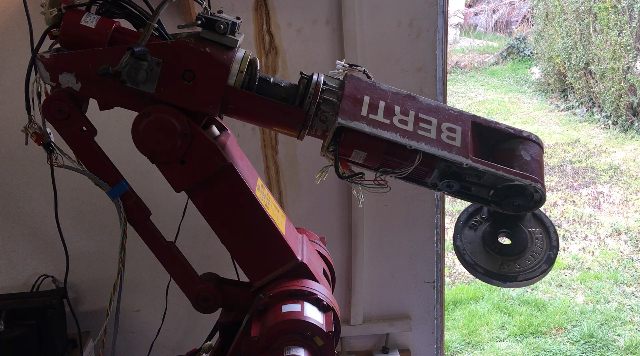
I have some questions for robot control with Linuxcnc.
How far or close quality of robot arm control could be done with Linuxcnc in comparison with original control?
Could it be used for production?
I don’t know for sure but believe that original control work with S velocity curves giving lot smoother movements than trapezoidal profiles.
Also not sure, someone correct me if wrong, but original control should have some sort of real time moment of inertia calculation based on joints position so it could be able to adjust feedforward parameters for velocity and acc + gravity influence.
Also maybe some vibration compensation.
Possibly a lot more involved...
Is it possible on commercial robots to access data like following error or steady state error?
I saw in most cases manufacturers guarantee precision on final position but I don’t know what happens during the way.
I watched Linuxcnc controlling manutec arm with stmbl drives, it looks very nice with slow speeds but with high speed movement it shakes a little bit at top.
Can robot arm g code for joints movement be exported from Linuxcnc?
If can than it can possibly be used with some custom hardware which provides smoother velocity profiles.
Please Log in or Create an account to join the conversation.
- Aciera
- Offline
- Administrator
-

Less
More
- Posts: 4819
- Thank you received: 2177
3 years 6 months ago #268877
by Aciera
Replied by Aciera on topic Motoman K6SB Retrofit
While LinuxCNC can get your robot moving it will likely never offer the functionality of the original controller (this will somewhat depend on the age of the controller of course ). Features like inertia calculation, gravity influence and such will not be possible.
I have a 15 year old mitsubishi arm and it offers "soft joints", meaning that you can define the allowed following error along any direction in space which is very useful for placing/removing parts from a fixture. But it does not offer velocity blending across way points for example.
The thing to realize is that robot control is not the same as CNC and robot control is a very closed environment. Using a robot for CNC machining is generally not really all that good of an idea since a robot arm does not offer the required rigidity. All those videos of robot arms cutting circles in the air are maybe fun to look at but the practical application is questionable at best.
GCode is not really used to program robots, they all use some proprietary language so the first stumbling block is usually how to get the GCode generated for a robot arm in the first place.
Don't get me wrong, I do think that LinuxCNC can be very useful to get a decommissioned robot arm do some useful work but if you are expecting it to do machining, complex 3d welding or high speed manipulations you are likely expecting the impossible.
The following user(s) said Thank You: boksi
Please Log in or Create an account to join the conversation.
- boksi
- Offline
- Junior Member
-
Less
More
- Posts: 27
- Thank you received: 0
3 years 6 months ago - 3 years 6 months ago #268888
by boksi
Replied by boksi on topic Motoman K6SB Retrofit
Thank you for detailed answer.
Can you share some more info about your arm behavior?
"I have a 15 year old mitsubishi arm and it offers "soft joints", meaning that you can define the allowed following error along any direction in space which is very useful for placing/removing parts from a fixture."
Does this mean that controller in that mode is adjusting velocities, acc,decc in real time to be able to stay within defined borders of following error?
Did you noticed some change in behavior due reducers wear out?
In my arm not all reducers are harmonic some of them are planetary. This could be also issue for control due backlash which could happen.
Do you have option to set manually acc and decc values for joint drives?
Did you noticed any servo noise in any mode/orientation/operation condition of robot arm?
Is there any differences in behavior when arm is not loaded and fully loaded?
Last edit: 3 years 6 months ago by boksi.
Please Log in or Create an account to join the conversation.
Time to create page: 0.297 seconds