how to synchronize two servomotors

More
9 years 4 months ago #94474 by Jasper 3
shit just delete it.
again.
thanks for your help.

Here are my hal and ini file.

File Attachment:

File Name: ttest-hal_...6-13.txt
File Size:13.55 KB

File Attachment:

File Name: ttest-ini_...6-13.txt
File Size:3.9 KB


I had set P in 50er steps from 0 to 1000. and than I raised it in 500er steps till 8000.
When P is set to 5000 it is a reasonable value with less oscillations. When P is 5 I get no oscillations. (I was watching the hm2_5i25.0.encoder.02.positon to set up the P value. Is this right? Or what should I use to set the P value?

Please Log in or Create an account to join the conversation.

More
9 years 4 months ago #94475 by PCW
OK the PID maxerror setting for all axis should be changed to 0

Note that you will likely need to set P to 10 or so or you will have violent oscillations

(P was basically not doing anything because of the 0.5 micron max error setting)

Please Log in or Create an account to join the conversation.
More
9 years 4 months ago #94477 by Todd Zuercher
A bit more explanation of what Peter is telling you. The PID maxerror setting, limits the size of the error input into the PID loop, so when you were commanding small/slow moves the pid loop could keep up and calculate the command for the movement, but when a large error occurred it could not calculate a large enough command to keep up (because it was only seeing a fraction of what the real error was) and the error would grow until you got a following error alarm.

Please Log in or Create an account to join the conversation.
More
9 years 4 months ago - 9 years 4 months ago #94481 by PCW
Yes, that's correct.

PNCCONF sets this to number that makes sense if the feedback comes from
the stepgen itself (and your units are in inches)

But its much too small for metric systems and if you have external feedback
(a PID maxerror value of 0 means don't bound the maximum error at all)

A PID maxerror of 0.0005 mm means that the maximum velocity correction is P*0.0005 mm/second
which is why using extremely high P values (which will cause instability with reasonable bounds) helped
Last edit: 9 years 4 months ago by PCW.

Please Log in or Create an account to join the conversation.

More
9 years 4 months ago #94521 by Jasper 3
thanks alot.

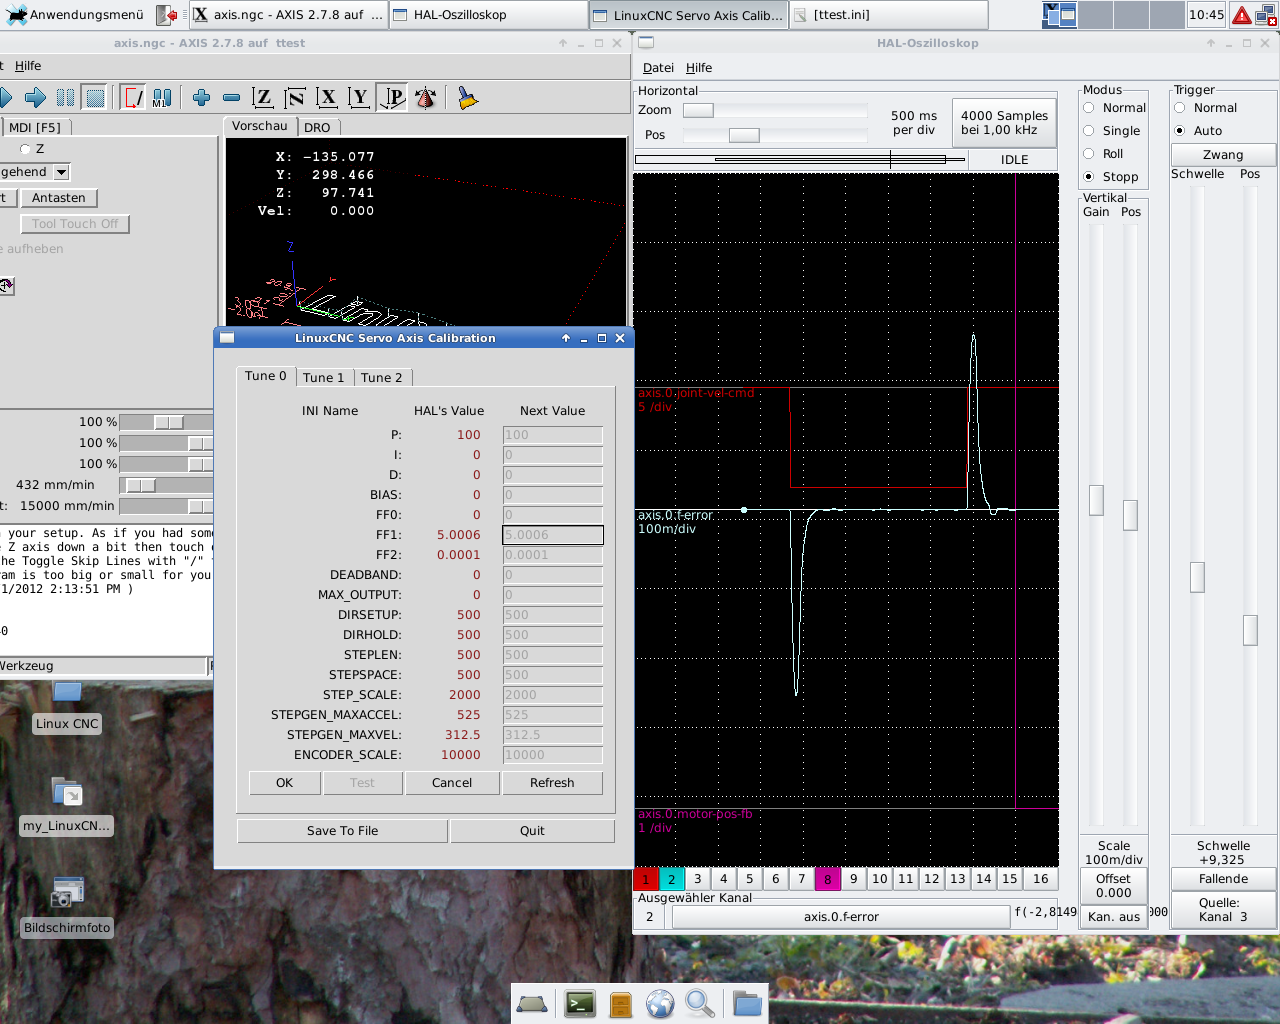
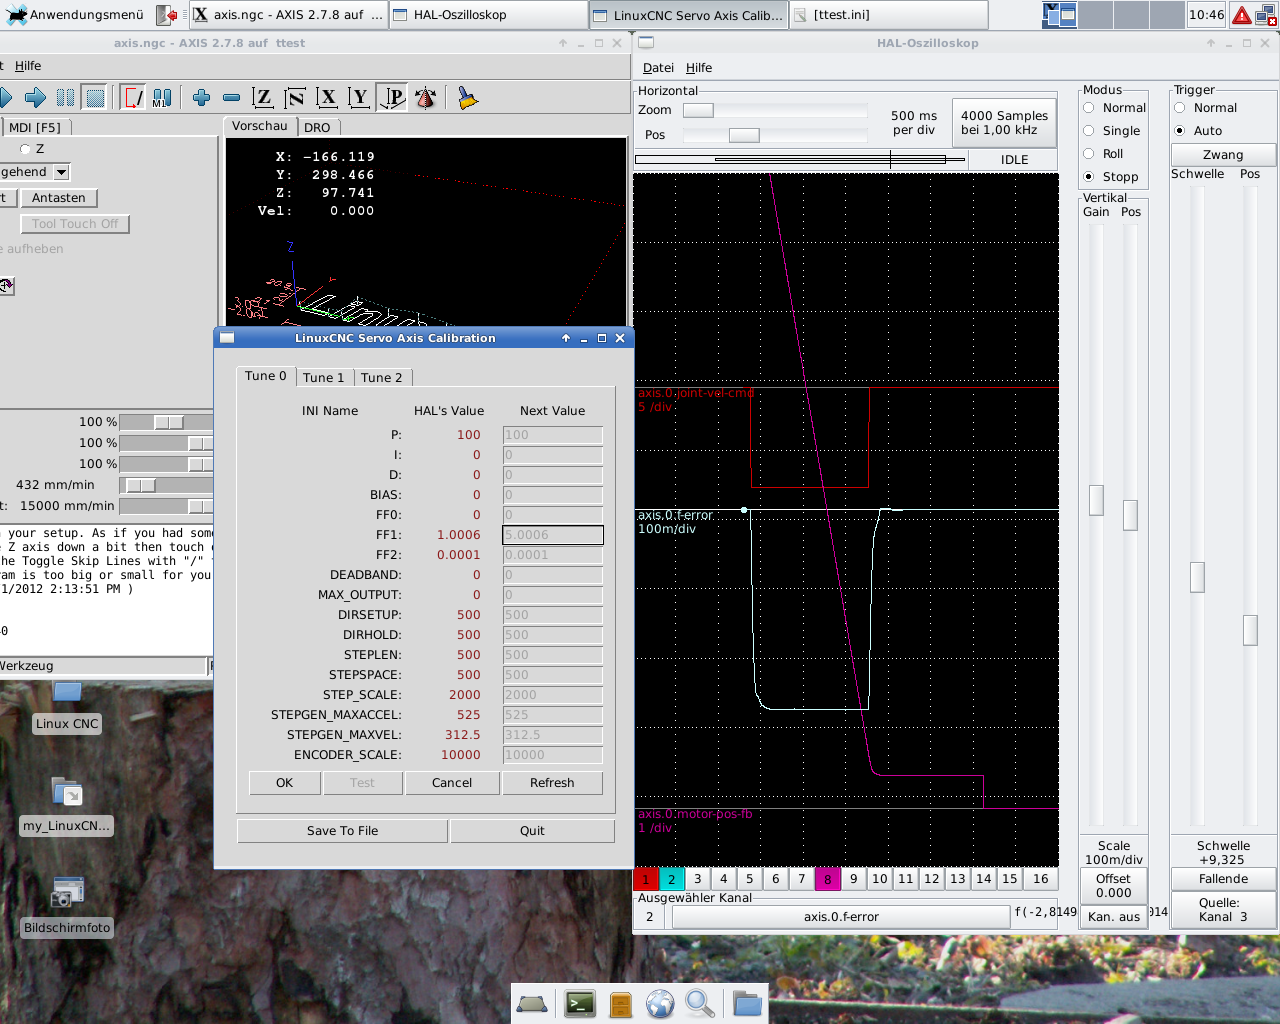
I'm trying to tune my axis. here are the halscope pictures.
My problem is, that I cant get rid of the little overshoot. I tried everthing from these tutorials.
gnipsel.com/linuxcnc/tuning/servo.html
forum.linuxcnc.org/10-advanced-configura...-how-to?limitstart=0

Also Its wierd that my ff1 needs to be set to 5.0006 when I set ff1 to 1 or lower my followring error oscilates not arround "zero". You'll see this in my pictures.


Please Log in or Create an account to join the conversation.

More
9 years 4 months ago #94523 by Todd Zuercher
Maybe it has something to do with the fact that your encoder scale is 5x larger than your step scale? Does the DRO show the correct distance moved? (ie does a 10mm move actually move 10mm)

A little bit of FF2 tuning should help with the spikes of error on acceleration and deceleration. (Assuming the machine can achieve the accel settings you put in the ini file.)

Please Log in or Create an account to join the conversation.

Time to create page: 0.244 seconds
Powered by Kunena Forum
