how to synchronize two servomotors

More
9 years 4 months ago - 9 years 4 months ago #94433 by Jasper 3
Hey,
puh..
i just tried to do what you said.
so that's how far I'm yet.
What should I write instead of the questionmarks in my hal file. does the file is so far correct?
I'm not shure what you mean with your commen signals. Its just for checking if there is a difference between both locations?

File Attachment:

File Name: tandem-hal.txt
File Size:15.2 KB

File Attachment:

File Name: tandem-ini.txt
File Size:4.66 KB
Last edit: 9 years 4 months ago by Jasper 3.

Please Log in or Create an account to join the conversation.

More
9 years 4 months ago - 9 years 4 months ago #94434 by Todd Zuercher
The line where you have the question marks is not needed, you've already connected that signal to the output pin "axis.1.motor-pos-cmd" and there can be only one.
But I don't think you are quite headed in the direction you need to go.
I would suggest you switch to the Master branch of Linuxcnc. It has the capability of doing independent homing of slaved joints, for a moving gantry type machine.

What you are doing now will slave both joints to the y axis command, but will not give you any means to square them. Where they are when you turn on the machine, is where they will be locked together, with no adjust-ability. You might be able to make it work with 2.7 if you used the gantry component. (but it is a work-around hack at best for slaving 2 joints.)
Last edit: 9 years 4 months ago by Todd Zuercher.

Please Log in or Create an account to join the conversation.
More
9 years 4 months ago #94435 by Jasper 3
hey,

the Master branch sounds good. Is there any documentation an possibility to download it?
the best would be to have a Master axis and one slave axis.
But I didn't get it working.

Please Log in or Create an account to join the conversation.
More
9 years 4 months ago #94440 by Todd Zuercher
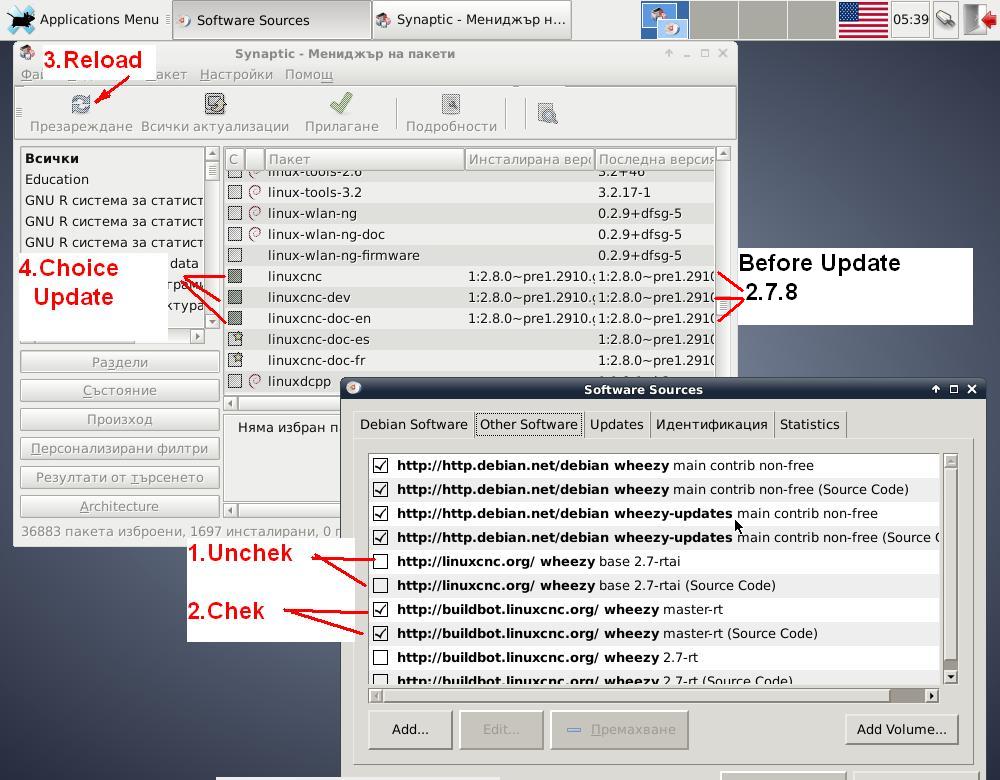
It is simple to update from 2.7 to Master using Synaptic.
Here is a screen shot that pretty much sums up all the steps to update to Master,
(I shamelessly copied it from another thread on this forum.)

Please Log in or Create an account to join the conversation.
More
9 years 4 months ago #94448 by Jasper 3
Hey,

ok I will try this Master branch, when I have again Internet on my Linux CNC computer.


Today I've tried to Tune my Servo-drives via Linux CNC.
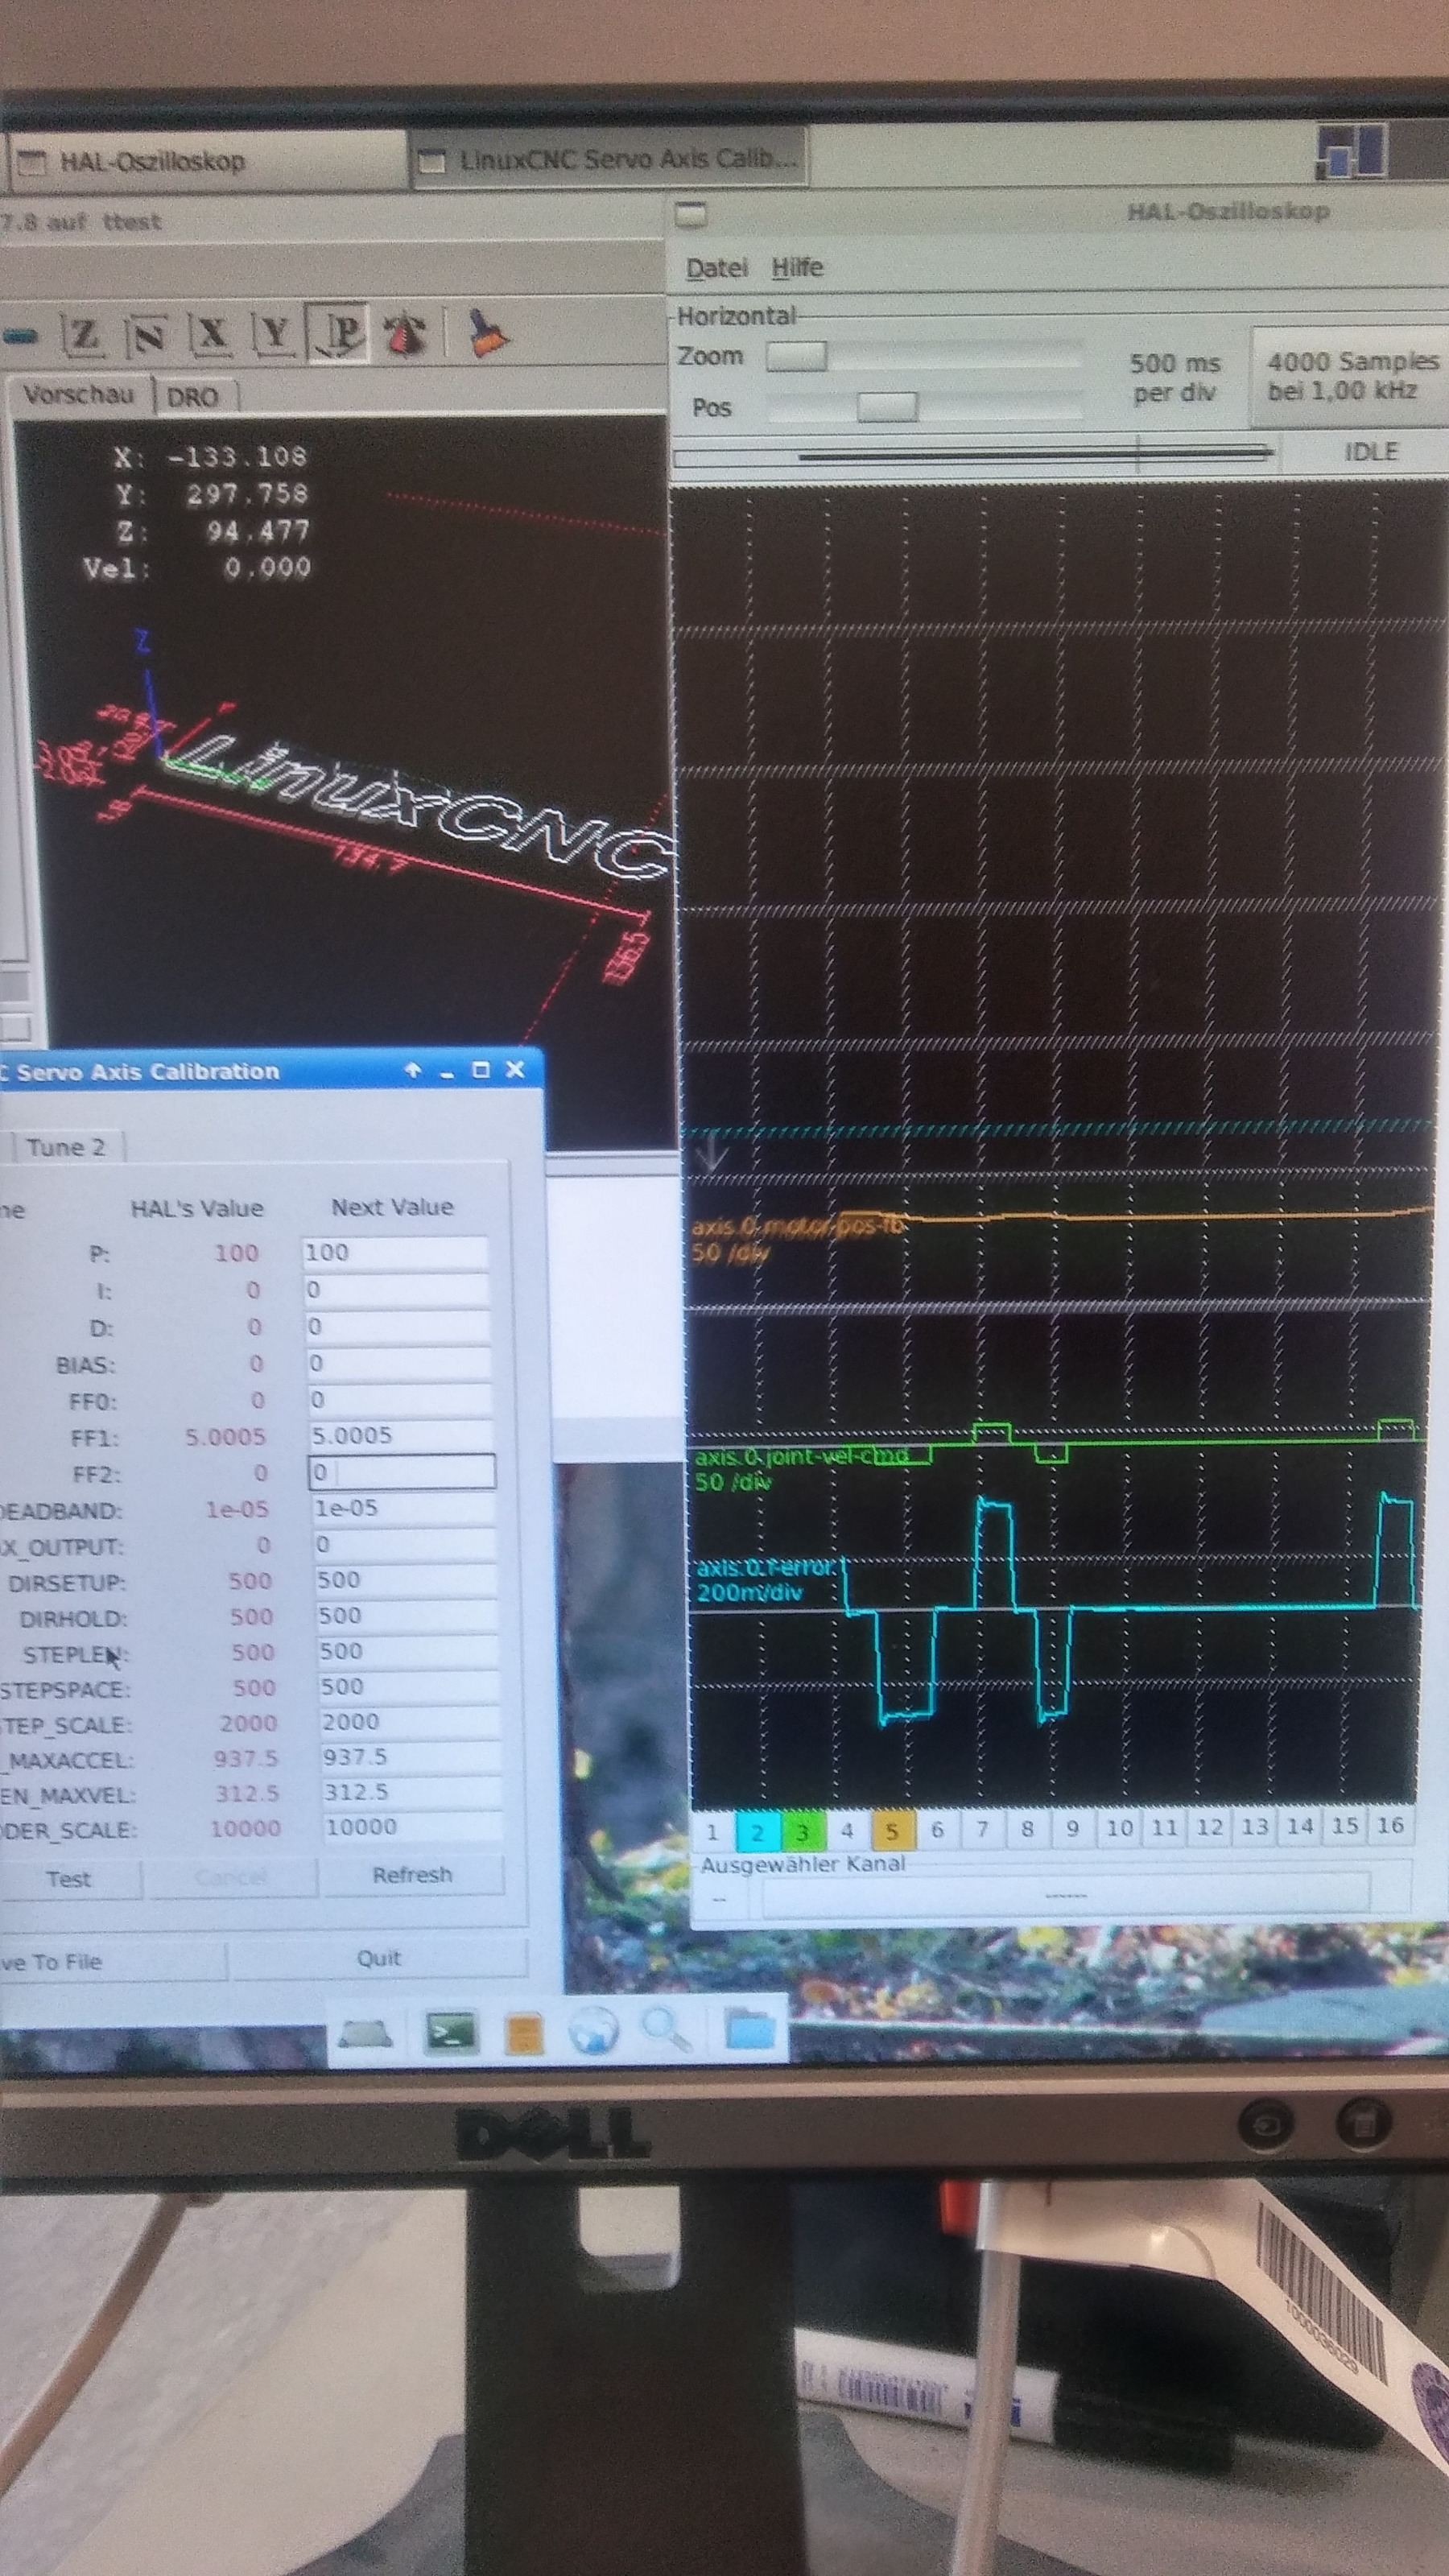
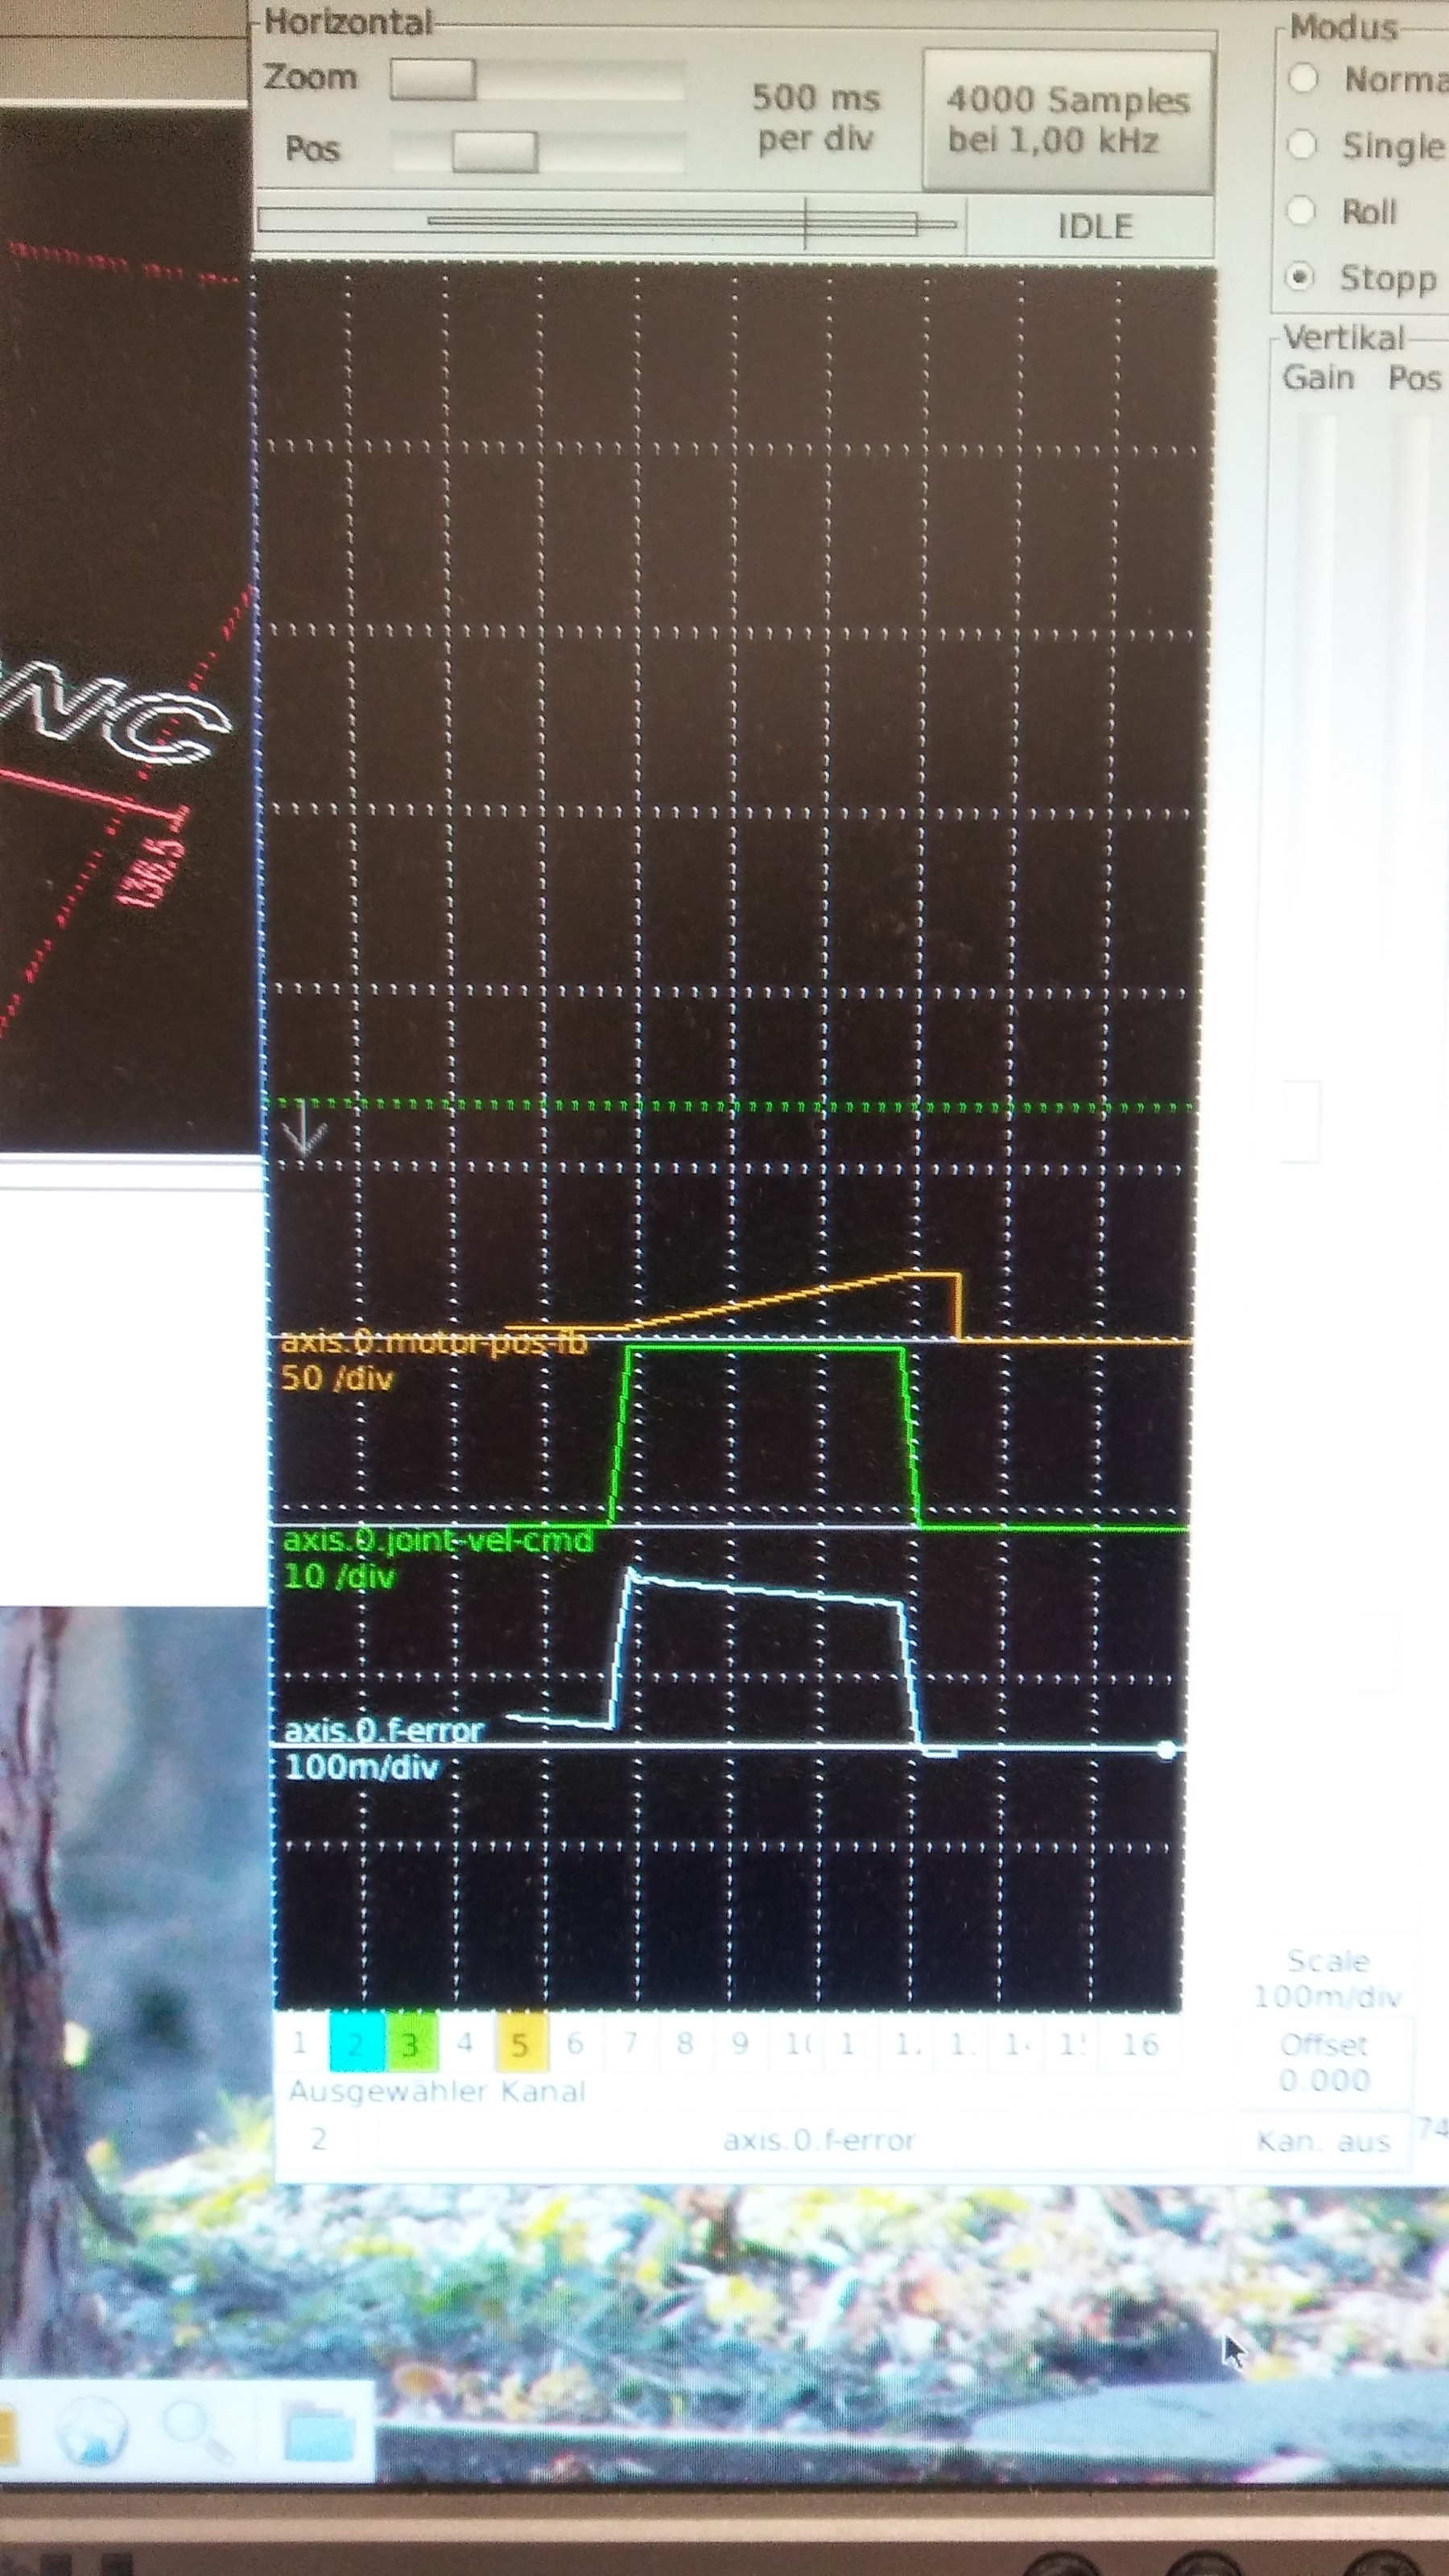
So If I use the Ecoderfeedback to close the loop I always get following erros when I accelerate to fast. I also tuned PID and FF1 to reasonable values. But the max velocity is only 1000mm/min. In an open Loop system I can run 15 000 mm/min without problems.


The reason for this slow travel speed is in my opinion the encoder feedback which causes a f-error. I think the motor can't accelerate as fast as needed. But reducing the acceleration means that the axis only reached a maximum velocity of maybe 3000mm/min. (The axis travel is only 400mm.

The Probelm is that I need to close the Loop with LinuxCNC to synchronize my Axis.
I hope you can help me accelerate much faster in the closed loop system.

Here to pictures of the tuning of my X-Axis

Please Log in or Create an account to join the conversation.

More
9 years 4 months ago #94451 by PCW
FF1 seems really wrong here

If the encoder and step scale are setup properly so encoder position and stepgen position are the same,
FF1 should be 1.000

Please Log in or Create an account to join the conversation.

Time to create page: 0.323 seconds
Powered by Kunena Forum
