Kinematics for XYZAB mill

More
3 years 11 months ago #258120 by Aciera
Replied by Aciera on topic Kinematics for XYZAB mill
As for starting out with vismach, I suggest having a look at this:
/home/user/linuxcnc-dev/configs/sim/axis/vismach/3axis-tutorial

Also maybe the xyzac-trt-gui.py is helpful
/home/user/linuxcnc-dev/src/hal/user_comps/vismach


Generally what threw me off the most is that one has to start assembling the moving parts in what seemed to me a backward way. So you don't start assembling the moving parts from the base but rather from the table that would hold the work piece or in the case of my robot arm from the hand backwards to the base.
The following user(s) said Thank You: tommylight, Grotius

Please Log in or Create an account to join the conversation.

More
3 years 11 months ago #258133 by Grotius
Replied by Grotius on topic Kinematics for XYZAB mill
Hi,

Just for information.

I integrated kdl kinematics into the lcnc kinematics source.
Until now i made 2 tiny examples.

1. Empty xyz kinematics.
inifile:
github.com/grotius-cnc/linuxcnc/blob/mai...xis/axis_kdl_xyz.ini
component:
github.com/grotius-cnc/linuxcnc/tree/mai...mponents/kdlkins_src

2. Robot kinematics for a 6 axis kuka.
inifile:
github.com/grotius-cnc/linuxcnc/blob/mai...s/axis_kdl_robot.ini
component:
github.com/grotius-cnc/linuxcnc/tree/mai...nts/kdlrobotkins_src

For Rod, this kind of kinematic model input could be quite handy, as you only have to edit a few lines 18 to 23
There you can say what kind of axis it is, etc. So easy.

During testing in axis, the lack is the preview, and i got a following error, wich is solvable.   

 
The following user(s) said Thank You: Aciera

Please Log in or Create an account to join the conversation.

More
3 years 11 months ago #258138 by Aciera
Replied by Aciera on topic Kinematics for XYZAB mill
Grotius, looks very interesting.
Just a quick question, as I don't want to high jack Rods thread,
Is your work intended to be something that can be integrated in LinuxCNC or is this likely to remain your own personal fork that is going to evolve further and further away from the main source code?

Please Log in or Create an account to join the conversation.

More
3 years 11 months ago - 3 years 11 months ago #258143 by Aciera
Replied by Aciera on topic Kinematics for XYZAB mill
Just found this Vismach tutorial pdf:
sa-cnc.com/wp-content/uploads/2021/07/CNCCLubVismachA.zip

There is more to explore here:
sa-cnc.com/linuxcnc-vismach/
And in the blog:
sa-cnc.com/?page_id=5375
Last edit: 3 years 11 months ago by Aciera.

Please Log in or Create an account to join the conversation.

More
3 years 11 months ago #258145 by Grotius
Replied by Grotius on topic Kinematics for XYZAB mill
Hi Arciera,

Is your work intended to be something that can be integrated in LinuxCNC
Yes. Integration is just copy one folder.

Just copy the cmake folder into your lcnc clone. Then in the cmake dir, the top cmakelist.txt file, outcomment what you
don't want to compile. And copy the local lcnc config.h file into the cmake common dir, to overwrite. This is for path's
That should do it.
Then you are ready to do : mkdir build, cd build, cmake .. && make install.

So creating a  component, compile it, is so easy now.

or is this likely to remain your own personal fork that is going to evolve further and further away from the main source code?
I don't want to go off the current source.
It is a fork, where the cmake dir can edited in qt-designer. Rene-dev has done something similar in the past.
This one is more fine tuned to single cmakefiles for every lib and component. Tuning is important.

Another way is to use a git recursive on the cmake directory in the future.


The following user(s) said Thank You: Aciera

Please Log in or Create an account to join the conversation.

More
3 years 11 months ago - 3 years 11 months ago #258157 by rodw
Replied by rodw on topic Kinematics for XYZAB mill
Thanks guys. Lots of resources there I never knew about!
Grotius, I will look further at your work. I really want to keep it in bounds of linuxcnc

For the image in the opening post I would say :
WAT = WAB * BAA * AAP * PAT
(which is probably what you meant)
 
 
Yeh, this is what I meant.
A&B have to intersect
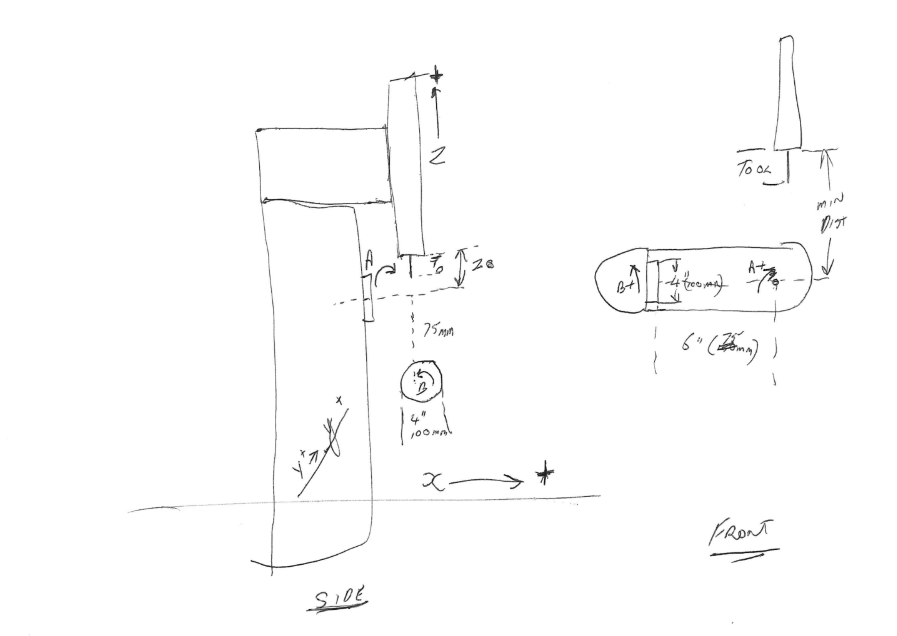
I did up a bit of a sketch of how I see the machine from the public specs (from the first post) Note 6" should be 3"
 
I'll keep plodding away
Last edit: 3 years 11 months ago by rodw.

Please Log in or Create an account to join the conversation.

Time to create page: 0.514 seconds
Powered by Kunena Forum

