Hi Aceria,
These seems to be some problem with the kinematics when using the x-ioffset and z-offset and I am not able to pinpoint it and propose a solution.
I am the original author of switchkins and the idea behind switchable kinematics was that you could switch between machine kinematics without any physical motion of the machine.
Doing the following sequence of actions results in machine motion during kinematics switching
1. Start the xyzab-tdr config
2. x-offset = -20, z-offset= -10, rotation center point = (-50,-50,100)
3. home the machine and switch to MDI mode - still with identity kinematics
4. T2M6G43H2 - this will add a tool with length of 30mm to the Z axis
5. G0x20y20z20
6. G0a90
7. Switch the kniematics to XYZAB kins using the pyvcp button OR M428 and then switch back to identity and watch the machine go for a ride in the vismach window. This can also be observed in the machine coordinates
Now if the x-offset and z-offset are kept to 0, this movement does not happen.
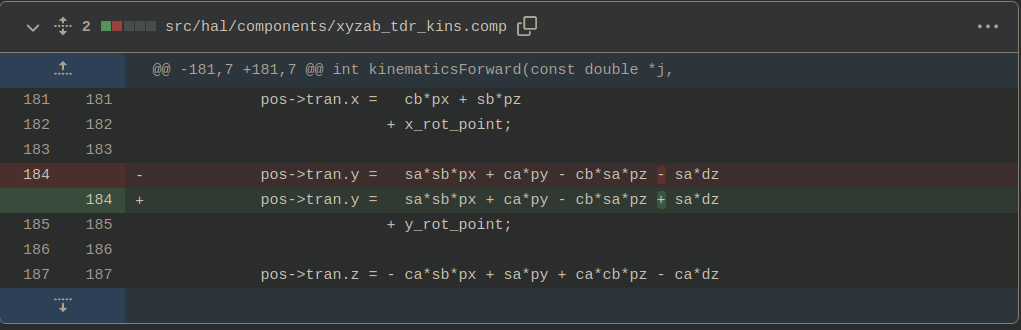
In the forward kinematics, dz seems to be taken into account but dx does not seem to be.
While in the inverse kinematics, dx and dz both are taken into account.
Can you help me take dx and dz correctly into account in the formulas?
Regards,
automata