
- Posts: 83
- Thank you received: 0
Forum Header
Help please !!! Servo configuration with stepconf.
- ishman
- Offline
- Premium Member
-

Less
More
14 years 5 months ago #19783
by ishman
Now I think I have all the numbers needed to run my machine with servo and step/dir with stepconf.
Step Time = 1000
Step Space = 1000
Direction hold = 20000
Direction setup = 20000
Step/Revolution = 10000
Drive Microstepping = ??? (oops! one thing still to understand.)
Pully teeth = 1:1
Lead-screw pitch = 5mm
Maximum Velocity = 1
Maximum Acceleration = 25000/10000*5 = 12.5mm per sec * electronic gear ratio.
Replied by ishman on topic Re:Help please !!! Servo configuration with stepconf.
Thanks !Probably not all that relevant with that drive. But a you always stop before changing direction, it doesn't matter too much. 20,000 ought to be safe.
Now I think I have all the numbers needed to run my machine with servo and step/dir with stepconf.
Step Time = 1000
Step Space = 1000
Direction hold = 20000
Direction setup = 20000
Step/Revolution = 10000
Drive Microstepping = ??? (oops! one thing still to understand.)
Pully teeth = 1:1
Lead-screw pitch = 5mm
Maximum Velocity = 1
Maximum Acceleration = 25000/10000*5 = 12.5mm per sec * electronic gear ratio.
Please Log in or Create an account to join the conversation.
- ishman
- Offline
- Premium Member
-
Less
More
- Posts: 83
- Thank you received: 0
14 years 5 months ago - 14 years 5 months ago #20032
by ishman
Replied by ishman on topic Re:Help please !!! Servo configuration with stepconf.
One good news is that I can run my servo's with stepconf wizard as an open loop system. Every axis is tuned and responding accordingly, smoothly and fast as well. One thing is cleared in which I was confused that Drive Microstepping means Linuxcnc's internal microstepping and it doesn't care about drives electronic gearing system. I don't know how to tell linuxcnc about drives gearing. so it can calculate position accordingly and we can ramp up the speed with the help of drive's processor as well.
I found an indirect solution is to divide screw pitch according to drives gearing ratio. But I think there should be any direct solution.
Right now I have just jogged and tuned the servo with stepconf because I have only two servo drives expansion board in my hand.
I found an indirect solution is to divide screw pitch according to drives gearing ratio. But I think there should be any direct solution.
Right now I have just jogged and tuned the servo with stepconf because I have only two servo drives expansion board in my hand.
Last edit: 14 years 5 months ago by ishman.
Please Log in or Create an account to join the conversation.
- cmorley
- Offline
- Moderator
-

Less
More
- Posts: 7368
- Thank you received: 2181
14 years 5 months ago #20035
by cmorley
Replied by cmorley on topic Re:Help please !!! Servo configuration with stepconf.
drive microstepping is just that - the DRIVE'S microstepping factor (nothing to do with linuxcnc internals)
steps per revolution is meaning the motor - most are 200 steps per rev.
you put 10000 steps per rev which would seem to mean 200 motor steps/rev and 50 microsteps (200x50=10000)
But as you have found out either way will still give you the right scaling. (just wanted you to understand why)
to me your max velocity and max acceleration seem odd - but I never read the rest of the thread.
your max velocity is 1mm/s (60mm per minute) which is pretty damn slow.
but your acceleration is 12.5 mm per sec (x something else) which seems really fast.
and it looks like you calculated the acceleration....I must be missing something
Please Log in or Create an account to join the conversation.
- ishman
- Offline
- Premium Member
-
Less
More
- Posts: 83
- Thank you received: 0
14 years 5 months ago #20038
by ishman
Replied by ishman on topic Re:Help please !!! Servo configuration with stepconf.
Thanks cmorley !
you caught a good point. my velocity is 1mm and acceleration is 12.5mm.............lol.
The reason for my conclusion was when I increased the ratio on screen it changes the speed accordingly. I didn't even touched the drive's gear during test.drive microstepping is just that - the DRIVE'S microstepping factor (nothing to do with linuxcnc internals)
you caught a good point. my velocity is 1mm and acceleration is 12.5mm.............lol.
Please Log in or Create an account to join the conversation.
- andypugh
- Offline
- Moderator
-
Less
More
- Posts: 19899
- Thank you received: 4655
14 years 5 months ago #20042
by andypugh
Replied by andypugh on topic Re:Help please !!! Servo configuration with stepconf.
ishman wrote:
Well, there is only one number to set the scaling, and that is a combination of all the other factors. So, it doesn't matter how you do it as long as the single scale factor for that axis in the HAL is correct.
I found an indirect solution is to divide screw pitch according to drives gearing ratio. But I think there should be any direct solution.
Well, there is only one number to set the scaling, and that is a combination of all the other factors. So, it doesn't matter how you do it as long as the single scale factor for that axis in the HAL is correct.
Please Log in or Create an account to join the conversation.
- ishman
- Offline
- Premium Member
-
Less
More
- Posts: 83
- Thank you received: 0
14 years 5 months ago - 14 years 5 months ago #20052
by ishman
Replied by ishman on topic Re:Help please !!! Servo configuration with stepconf.
I did my first run today with stepconf wizard. Exciting !!! But it was only surfacing because my Z axis still needs to be wired. The drives manufacturer provided me only two expansion cards for drives by mistake. Which connects with CN36 cable. I can order more of them but it takes one week atleast. I have some CN36 connector though and I can run the Z axis immediately if some one help me to know how to hook FG 36 pin (Left bottom side of schematic diagram.)
here is the schematic image.
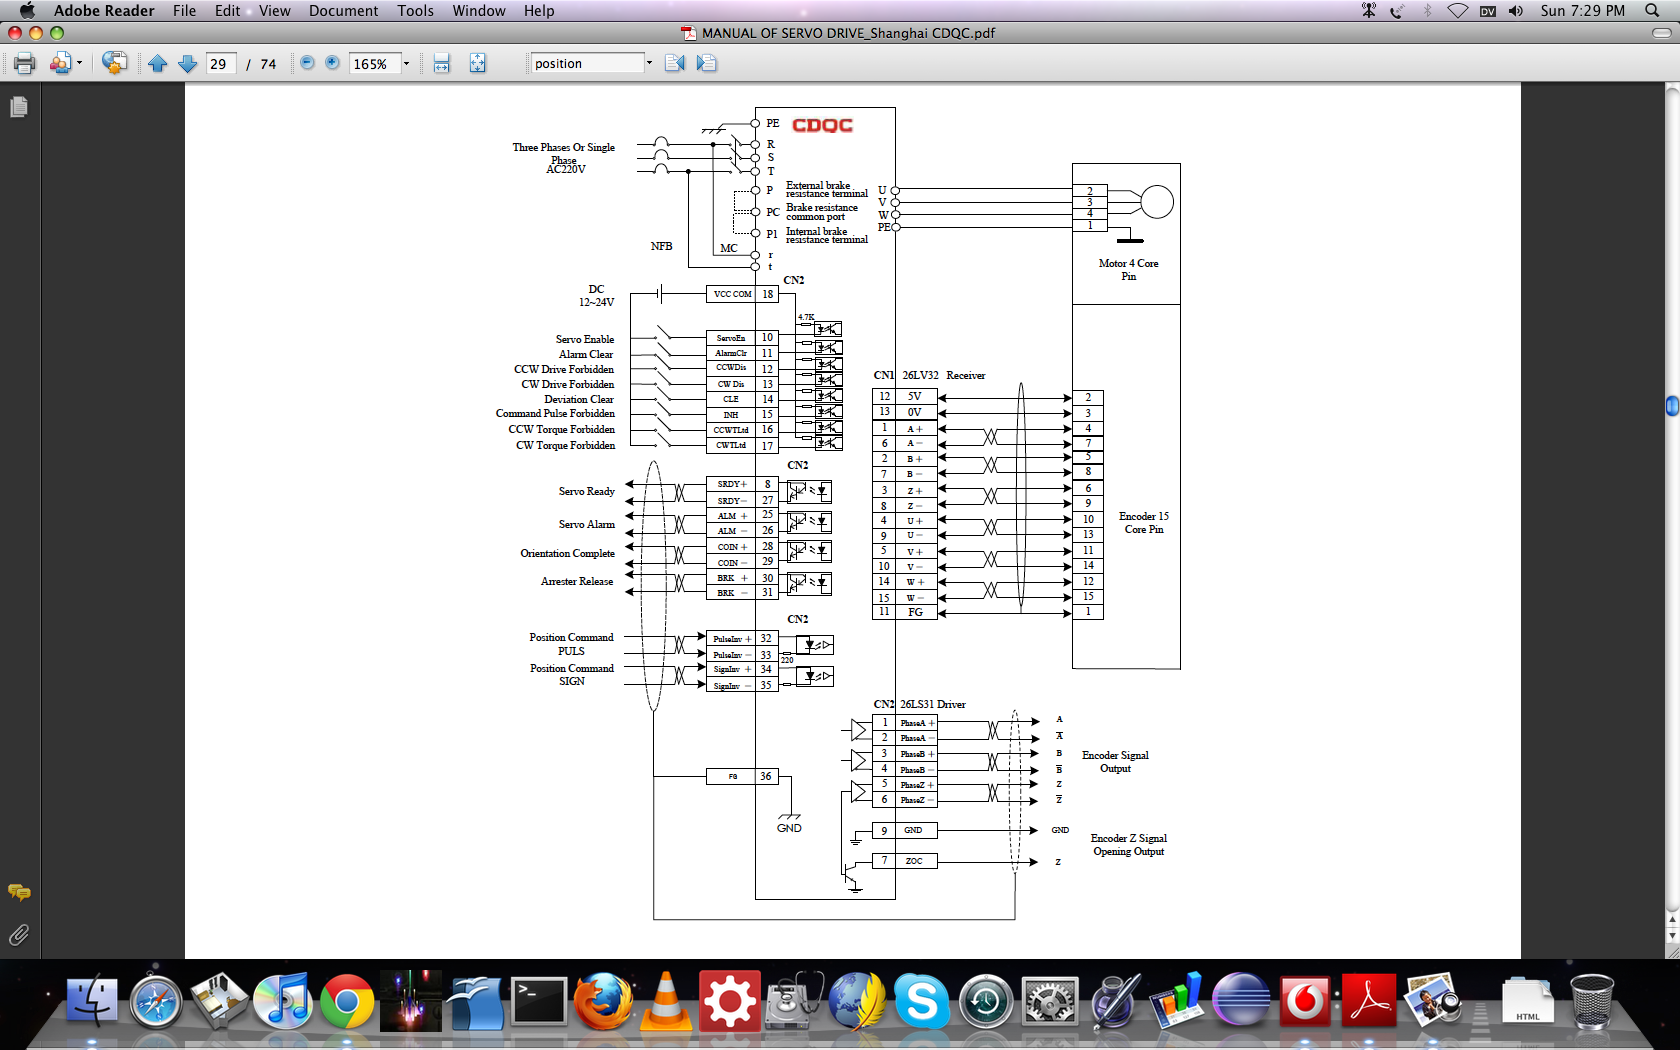
Many thanks in advance.
here is the schematic image.
Many thanks in advance.
Last edit: 14 years 5 months ago by ishman.
Please Log in or Create an account to join the conversation.
Time to create page: 3.275 seconds