
- Posts: 89
- Thank you received: 2

Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
Bari wrote: They didn't do the best job of configuring the preempt_rt kernel posted there.
.
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
wicki wrote: > wicki wrote: >
> now a period of 80.000 is possible.
> What is a possible, usable step-rate?
oh no.
a BASE_PERIOD down to 80000 is possible without getting a
"unexpeted rt-delay"-warning in linCNC is possible with my PI4.
> I'm not sure what you are measuring yet. Are you measuring all the duration of all the > intervals between pulse edges falling and rising, just rising or just falling or?
this are the durations of the high and the low periods of the square signal.
the high-periods is near exactly 80usec.
the low-periods are a mutliple of 80: 160, 240, 320.
that also sounds logical....
with a BASE_PERIOD of 80000 a square of 12500Hz is possible. (as a quad-signal)
but the next frequency below is 6250.
aus you see here:
getp stepgen.3.frequency
4000
and the output square is 4.1kHz
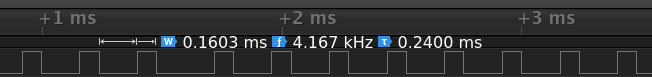
or 3.1kHz
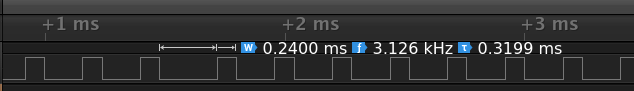
I am still considering whether I can use an arduino for step/dir production.
as far as I now, the mesa-cards are generating their own stepper-signal?
does anyone know how the cards get their information?
do they receive data from stepgen or do they generate them themselves
from the position information?
Please Log in or Create an account to join the conversation.


