Running servos in position mode instead of analog

More
5 years 8 months ago - 5 years 8 months ago #199326 by bevins
I have DYN4 750 watt ac servos with planetary gear reduction and I am tapped at about 500ipm. Any faster and the drive gets overload error and shuts down. This sounds like the same issue and I am running in step/dir mode. I wont need them any faster that that but will never use them again.
Last edit: 5 years 8 months ago by bevins.

Please Log in or Create an account to join the conversation.

More
5 years 8 months ago - 5 years 8 months ago #199327 by Michael
With higher than 45ips/s acceleration I can get them to over current at high speeds also in step/dir. I was definitely hoping for more out of them, the manual and tuning info wasn't helpful or easy for analog setup.

Bevin's, did you close the position loop back to Linux? If so care to share any info or hal files?
Last edit: 5 years 8 months ago by Michael.

Please Log in or Create an account to join the conversation.

More
5 years 8 months ago #199366 by Dbsharp
I will hook up one servo to my lathe it has a 7i33ta board on it with open channels. I might reach out so you can walk me through the steps you were told, an we can check my response time

Please Log in or Create an account to join the conversation.

More
5 years 8 months ago #199367 by Michael
More than happy to help. What model motors and drives did you get from DMM?

Please Log in or Create an account to join the conversation.

More
5 years 8 months ago #199571 by Michael

PCW wrote: An interesting question is whether the 5 ms delay is present in position mode as well.
Connecting the encoders could answer this. This delay might cause issues with spindle
synced motion like rigid tapping.

This brings up a general observation, your errors are not huge, in fact you may have
never noticed them when machining and similar errors may also exist in step/dir
position mode.

A similar situation happens when people add linear encoders and discover all
the backlash and stick-slip errors that they had never noticed before.

Does the overcurrent alarm go away if you reduce the acceleration?
(200 IPS/S is likely beyond what the motors can do with a high inertial load)
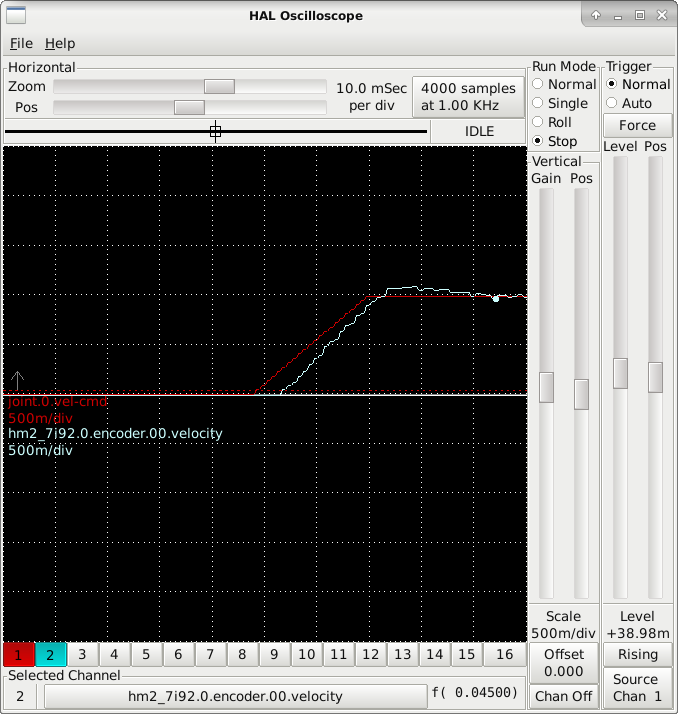
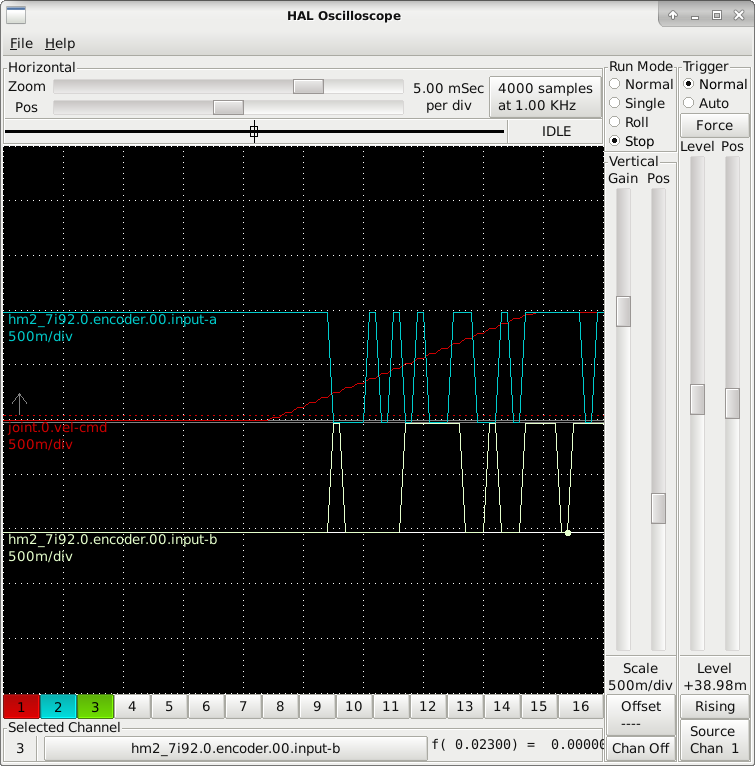
I hooked up the encoders in position mode and they still have a delay in response that can be seen in either of the attached pictures. If I use position mode will this also effect the ability to close the loop with linuxcnc and run consistently? If it does this only leave me the options to use different servos (+$$$) or to try a linear scale on each axis (+$$)

Please Log in or Create an account to join the conversation.

More
5 years 8 months ago #199572 by jmelson
I think a 5 ms delay between command and feedback from the encoder is going to make PID tuning pretty difficult. That's a 5 servo period delay.

Jon
The following user(s) said Thank You: Michael

Please Log in or Create an account to join the conversation.

Moderators: PCW, jmelson
Time to create page: 0.220 seconds
Powered by Kunena Forum
