mesa 5i25 and mx4660 installation and configuration

More
9 years 3 months ago #95499 by goofy
Hi,

Im back again with some questions. We assembled the Y and X axis and tried to run the first time the machine to measure the work area. There is the first problem: It moves, but very very slow. Could you give me an advise how to get the desired jogging speed of at least 10m/min? In the next days I want to touch the configuration of 3 Axis and 4 joints for the Y. If anyone has a configuration to have a look at, It would be great.

Thanks a lot
Mathias

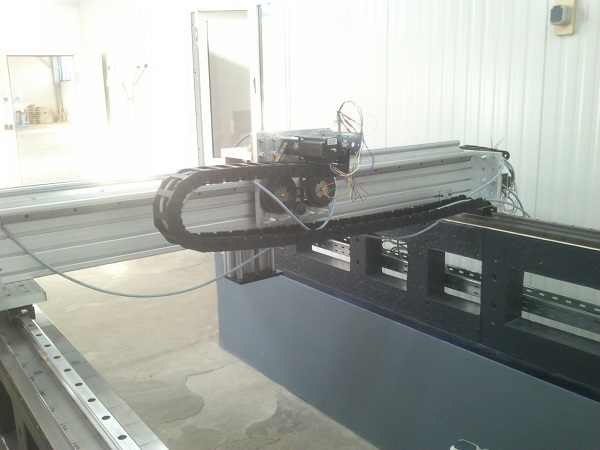
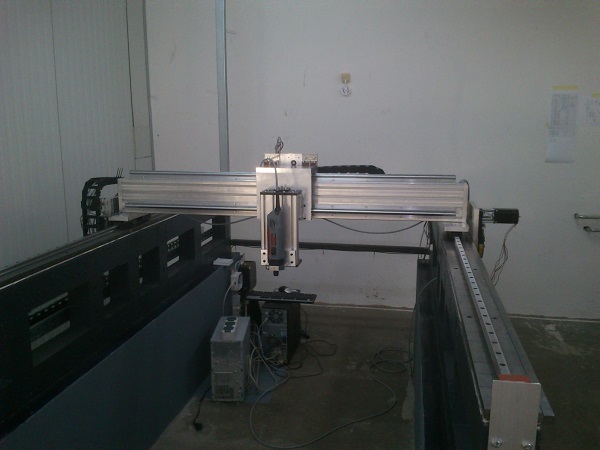
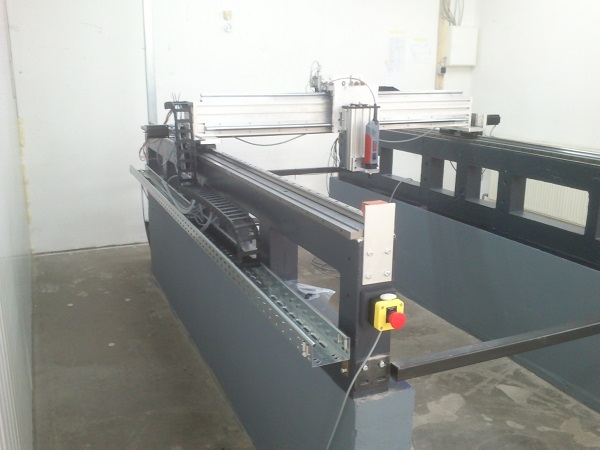
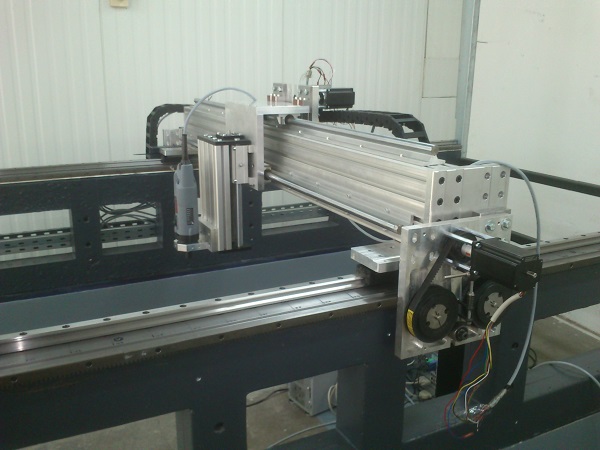
P.S. attached some pictures of the machine itself...


File Attachment:

File Name: configs.zip
File Size:72.33 KB

Please Log in or Create an account to join the conversation.

More
9 years 3 months ago #95501 by tommylight
Open the .ini file with a text editor ( gedit or mousepad or nano ) and look for max_velocity and max_acceleration, edit them as you need for each axis ( not before finding the right ratio or scale ), save, reload Linuxcnc and test.
Set the scale first.

ASUS ROG Crosshair VIII Impact - AMD X570

Please Log in or Create an account to join the conversation.

More
9 years 3 months ago #95502 by goofy
Thanks for your answer.
When I open up the .ini file, there are a lot of VELOCITIES...
The first one is in the DISPLAY area. At the moment at 16.666667. The documentation says something about machine units? Is it in mm, s or rpm? The next velocities are in the joints sections. The values are MAX_VELOCITY = 500.0 and MAX_ACCELERATION = 800.0. At the moment its for all three axis the same, but only X and Y have the same hardware. They have both a rack and pinion drive.
The calculation is: pi x 2mm (modul 2) x 12 (number of teeth) x 0,53125 (gear with 34 and 64 teeth) = 40,0553 mm per revolution. At the moment I have the switches for the microstepping set to 1/10. Thats 2000 steps per revolution and 0,02 mm per step. The Scale I use at the moment is therefor 1/0,02 = 49,93 steps per mm. Is that right?

Thanks a lot and regards
Mathias

Please Log in or Create an account to join the conversation.

More
9 years 3 months ago #95515 by rodw
Your calculations look right to me

The jog speed is set by DEFAULT_LINEAR_VELOCITY in the ini file
See
forum.linuxcnc.org/49-basic-configuratio...ge-default-jog-speed

Assuming you have set the default units to be metric, all of the velocities are in machine units per second so 10 m/min gives 10000/60 mm/sec = 166.66667
I think you are running at 100 mm/min (16.66667)

Please Log in or Create an account to join the conversation.

More
9 years 3 months ago #95912 by goofy
Hi,

thanks for your answer! Meanwhile I got the machine running at reasonable speed of 10m/min.
With the great help of IchGucksLive in the linuxcnc chat, the home switches are configured, the soft limits are set and many of my questions were answered. At the moment I hardly try to understand the structure of the hal. I have a router (Kress) on a relay and want to connect it to spindle on/off (M4/M5). The same I want to do with the vacuum table and the dust collection. The pins in the hal file are

#setp hm2_5i25.0.gpio.029.is_output true
#net spindel hm2_5i25.0.gpio.029.out

#setp hm2_5i25.0.gpio.024.is_output true
#net vakuum hm2_5i25.0.gpio.024.out

#setp hm2_5i25.0.gpio.017.is_output true
#net absauge hm2_5i25.0.gpio.017.out

If you have any idea to connect these pins to M4/M5, M8/M9, It would be great.

Thanks a lot and regards
Mathias

File Attachment:

File Name: wbcnc_2.7.9.ini
File Size:4.08 KB

File Attachment:

File Name: wbcnc_2.7.9.hal
File Size:11.87 KB

Please Log in or Create an account to join the conversation.

More
9 years 3 months ago - 9 years 3 months ago #95924 by Todd Zuercher
For your spindle controls in your hal file M3 will trigger the signal "spindle-cw" (to start the spindle in the normal forward or clockwise direction), and M4 will trigger the signal "spindle-ccw" (for reverse). M5 will change both those signals to false (as well as the spindle-enable).
To connect one of those singals to the halpin hm2_5i25.0.gpio.029.out by adding a line like this to your hal file.
Code:
net spindle-cw => hm2_5i25.0.gpio.029.out

For connecting to the coolant mist/flood (M7/M8) your hal file has signals called "coolant-mist" and "coolant-flood" and like above you could add this to your hal file.
Code:
net coolant-mist => hm2_5i25.0.gpio.024.out net coolant-flood => hm2_5i25.0.gpio.017.out
This would turn on the pin "hm2_5i25.0.gpio.024.out" with the M7 g-code, and turn on "hm2_5i25.0.gpio.017.out" with the M8 g-code and turn them both off with an M9.

There is no way to separate the action of the M7/M8 commands they will always both be shut off by M9.

For this reason for the vacuum table and dust collection controls on the routers I've configured. I choose to use a custom M-codes (M1xx) to control them.
linuxcnc.org/docs/html/gcode/m-code.html#mcode:m100-m199
Here is what the file I use for turning on my vacuum looks like (using your output pin).
M111 (vacuum on)
Code:
M111 #!/bin/bash # file to turn on hm2_5i25.0.gpio.024.out to turn on Vacuum halcmd setp hm2_5i25.0.gpio.024.out 1 exit 0
M112 (vacuum off)
Code:
M112 #!/bin/bash # file to turn off hm2_5i25.0.gpio.024.out to turn off Vacuum halcmd setp hm2_5i25.0.gpio.024.out 0 exit 0
Last edit: 9 years 3 months ago by Todd Zuercher.

Please Log in or Create an account to join the conversation.

Time to create page: 0.614 seconds
Powered by Kunena Forum