ROS LinuxCNC Link

More
5 years 5 months ago #210499 by Grotius
Replied by Grotius on topic ROS LinuxCNC Link
Hi Arciera,

I need a few day's more to code. When it's ready to try will give you the download link.
The following user(s) said Thank You: Aciera

Please Log in or Create an account to join the conversation.
More
5 years 4 months ago - 5 years 4 months ago #211219 by Grotius
Replied by Grotius on topic ROS LinuxCNC Link
Hi,

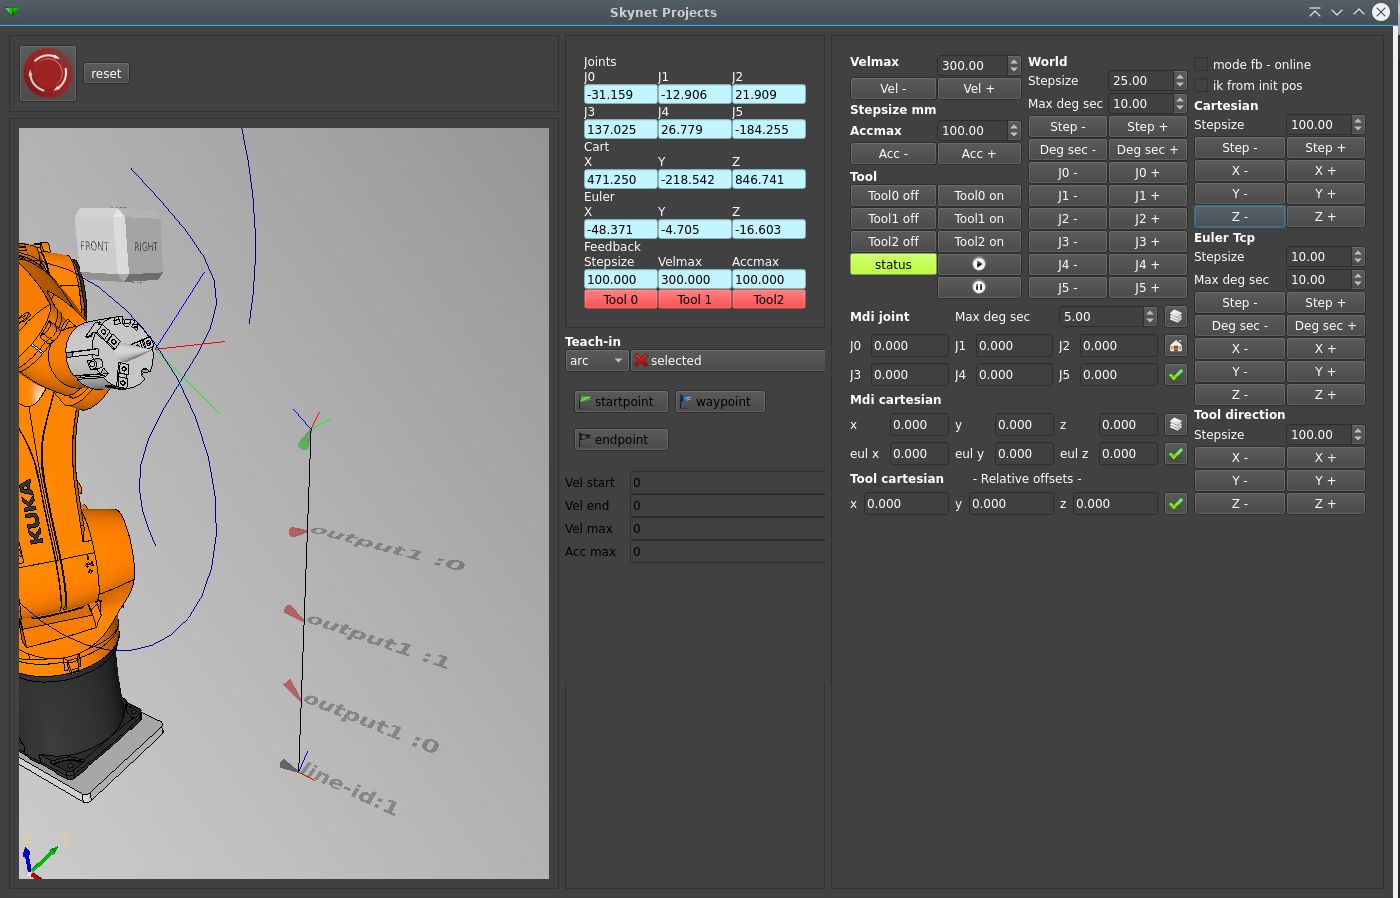
I made little progress. Added some technical details. It can look a bit messy, but for now it's ok.
The controls are fully functional. Now focussing on how to teach and how to store and edit this data in opencascade.

1.Moving the robot in tool direction is done! This works very nice. Also mdi commands are working.

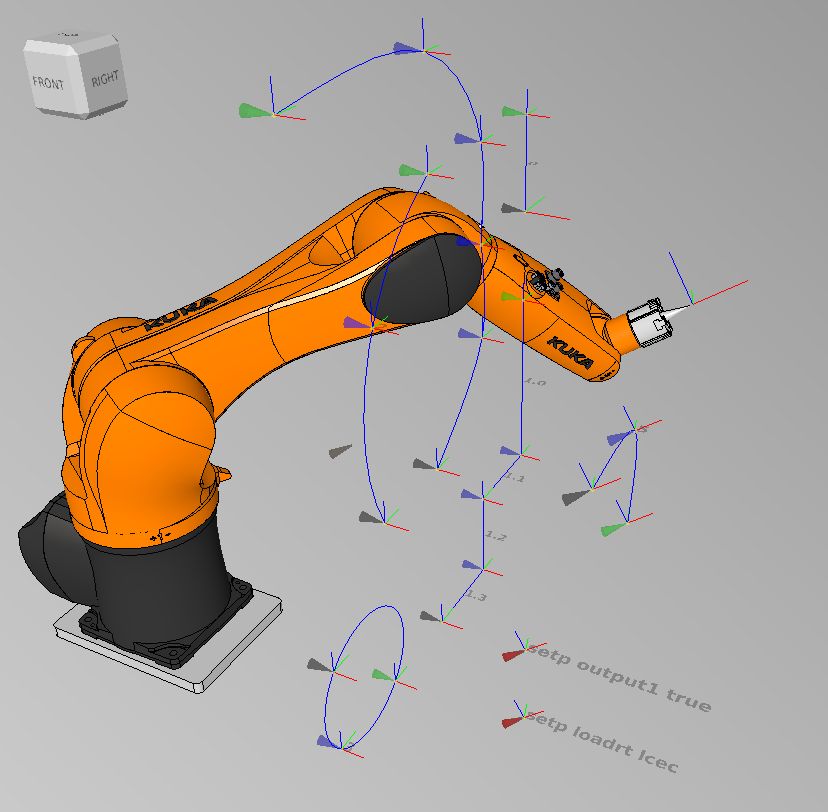
2.When for example teaching a line, it will attach the toolposition's (euler angles) at the begin- and the end of the line to teach.
When clicking on the teached line, you can simple delete it (and it's childs) by one command. This is quite nice.

- The green cone is startpoint.
- The red cone is a halcommand including position & euler angles.
- The black cone is the endpoint.

3. Todo is getting the possibility to edit existing line point's to enable live preview. How the editing works, i have to ask at the opencascade help center. So far i haven't seen a solution how to do this.

So far so good.

Last edit: 5 years 4 months ago by Grotius.
The following user(s) said Thank You: Bari, tommylight, robins, Aciera, DPFlex

Please Log in or Create an account to join the conversation.
More
5 years 4 months ago #211513 by Grotius
Replied by Grotius on topic ROS LinuxCNC Link
Hi,

A tiny project update.

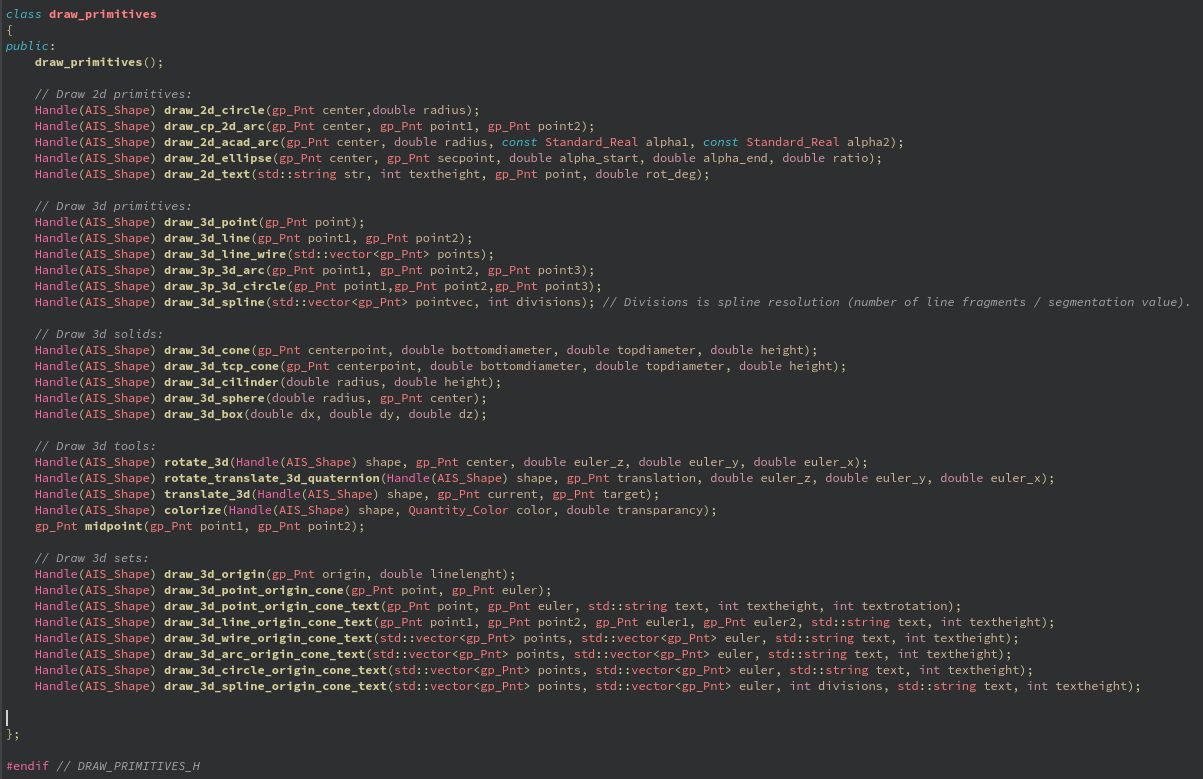
The lines, linestrips, arc's, circle's, splines, tool-io are now showing the euler angles. Oke this is nice.
I re-organized the opencascade function's.
Next i am planning to integrate the dxfrw library. Then we can load some dxf file's into the project and maybe
then we get some idea's how to program a dxf.


So far so good!
The following user(s) said Thank You: Bari, tommylight, robins, Aciera

Please Log in or Create an account to join the conversation.
More
5 years 4 months ago #211643 by Grotius
Replied by Grotius on topic ROS LinuxCNC Link
Hi,

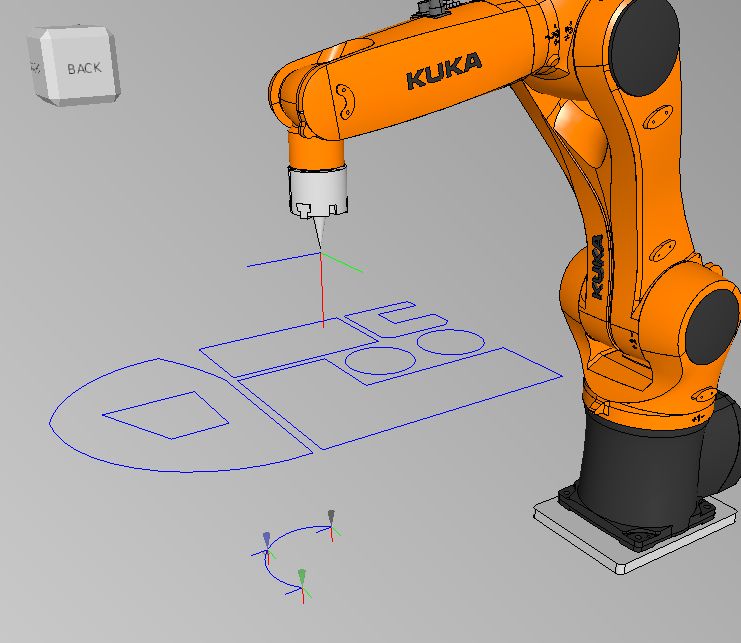
Today i integrated the dxfrw library.

Now is the question how to program this dxf preview if we do a cut or glue operation.
If we load a 3d stepfile model, it would be nice if we can program this the same way.

We could perform a contour recognize algoritme with standard euler angles as output.
We could set the euler angles in tangential direction. This can be used for a cut angle correction when using plasma.

Maybe think some more before start coding.

The following user(s) said Thank You: Bari, tommylight, robins

Please Log in or Create an account to join the conversation.
More
5 years 4 months ago - 5 years 4 months ago #211895 by Grotius
Replied by Grotius on topic ROS LinuxCNC Link
Hi

A tiny update. It can now do a tiny program. I made a tiny video to show what is going on.

user-images.githubusercontent.com/448801...7d0-e38b01950fe4.mp4

If i turn the screencast off, the path following is perfect. At the end of line 4 you see it has difficulties. My pc is quite an oldy.
Motor's are connected. For info, this is realtime 1ms with scurve motion profile.
Last edit: 5 years 4 months ago by Grotius.
The following user(s) said Thank You: Bari, tommylight, Aciera

Please Log in or Create an account to join the conversation.

More
5 years 4 months ago #211944 by Grotius
Replied by Grotius on topic ROS LinuxCNC Link
Hi,

Today i made a video sample where robot does euler angles.

user-images.githubusercontent.com/448801...8d6-e6319185ce63.mp4
user-images.githubusercontent.com/448801...f68-16cc9dcdd676.mp4

So far i am quite satisfied. At some points the c++ code has to improved a bit. It currently calculates the kinematics from init position.
The following user(s) said Thank You: Bari, tommylight, robins, Aciera, Doogie

Please Log in or Create an account to join the conversation.

Time to create page: 0.085 seconds
Powered by Kunena Forum
