ROS LinuxCNC Link

More
5 years 5 months ago #207962 by andypugh
Replied by andypugh on topic ROS LinuxCNC Link

Grotius wrote: One thing i really would like to have is a 3d arc motion path. I was working on this for many hours, but no succes so far.


There is a (very stale) Arbirtrary Arcs branch:

github.com/LinuxCNC/linuxcnc/tree/arbitrary-arc

As far as I am aware, as long as the centre point is specified, only 2 arcs are possible. Without a defined plane I am not sure how you determine clockwise or anticlockwise, I suspect that if all three of IJK were specified then you would have to declare that the shortest arc will always be chosen, regardless of G2 or G3 choice. (and a centre on a straight line between start and end, ie a 180 degree arc, is simply disallowed.

Please Log in or Create an account to join the conversation.

More
5 years 5 months ago #208021 by andypugh
Replied by andypugh on topic ROS LinuxCNC Link

Grotius wrote: I did some work in the meantime.
1. Created a embedded linux install version for robots.
2. Created a advanched s-curve motion planner. We need this for nice moves.
3. Created a realtime path planner wich behaves like a video player with 1000 frames a second. :laugh: This is really a big thing.
4. Created a c++ halviewer. We have now full control. :blink:
5. Now creating the different robot, cnc machine teach in functions for 3d usage.


Where do you buy these 50-hour days?
The following user(s) said Thank You: Grotius

Please Log in or Create an account to join the conversation.

More
5 years 5 months ago #208055 by tommylight
The following user(s) said Thank You: Grotius

Please Log in or Create an account to join the conversation.

More
5 years 5 months ago - 5 years 5 months ago #208082 by Grotius
Replied by Grotius on topic ROS LinuxCNC Link
Hi,

Cyborg here again. :woohoo:

Without a defined plane I am not sure how you determine clockwise or anticlockwise,
That is defined by point order. I now have the 3p 3d arc ready for teach in.
Waypoints out ok.
We don't have to know arc centre. We can reflect a euler angle on the 3d arc if needed in the future.

Where do you buy these 50-hour days?
I changed some priorities in life a few years ago.
Most of the time, my time is related to an old Egyptian filosofi.

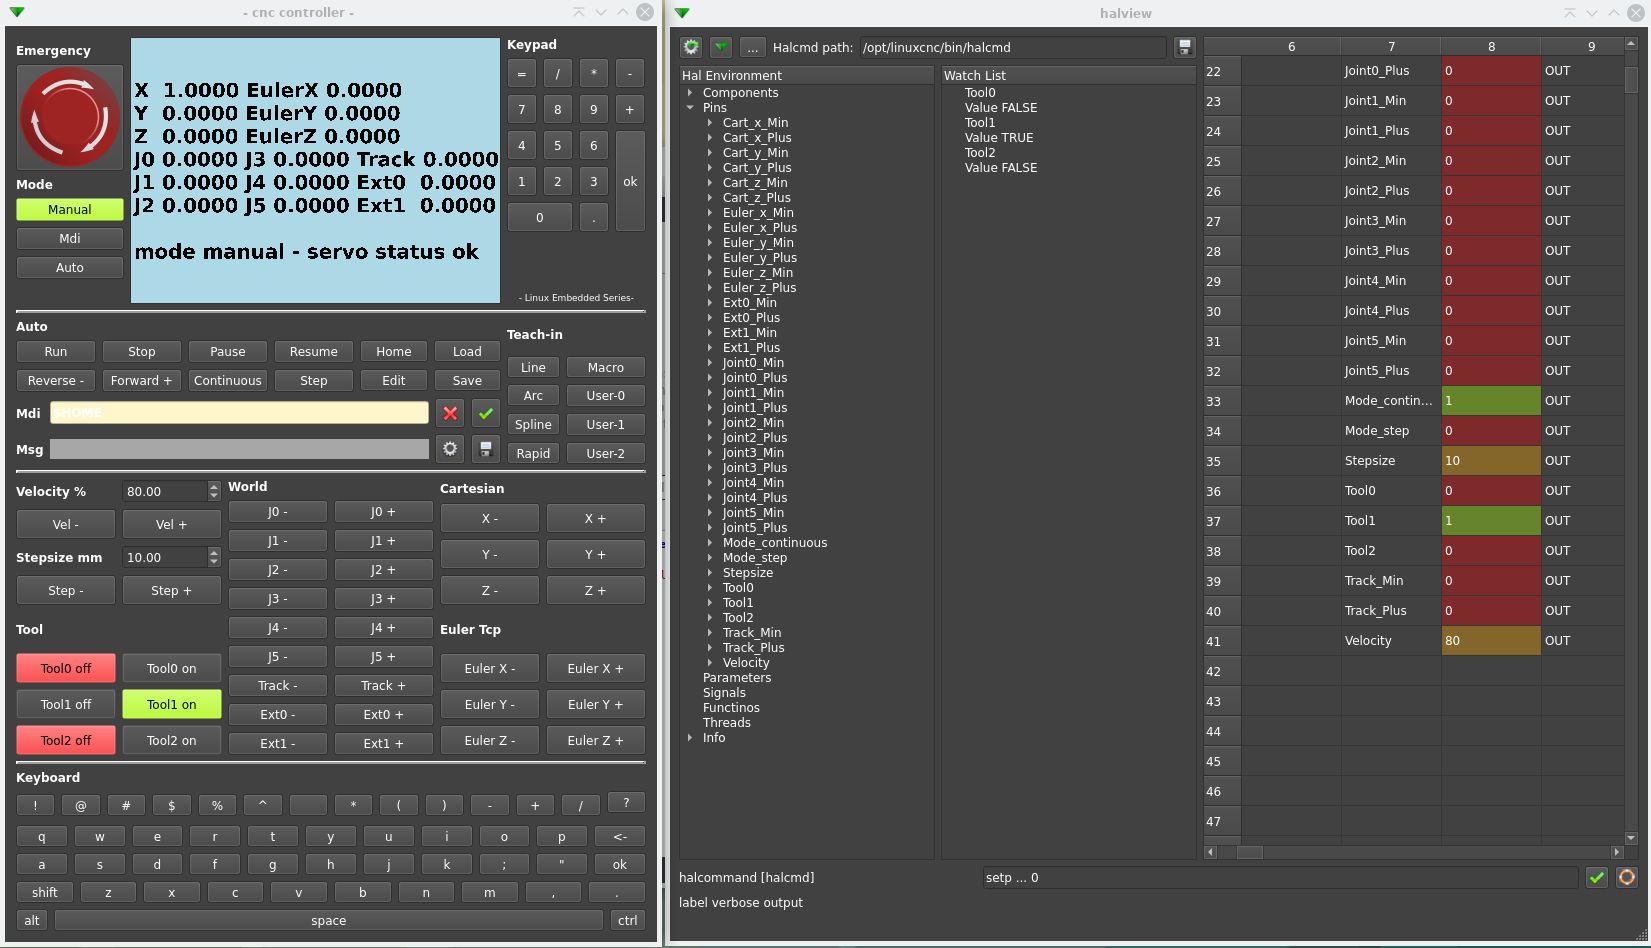
Now finishing the teach pendant.
Let me know if the button's, layout etc is ok. Then i can finish it.

The old display is done with some magic.

Last edit: 5 years 5 months ago by Grotius.
The following user(s) said Thank You: tommylight, Aciera, DPFlex

Please Log in or Create an account to join the conversation.
More
5 years 5 months ago - 5 years 5 months ago #208088 by Aciera
Replied by Aciera on topic ROS LinuxCNC Link
Impressive as usual but I have two questions:

1. Could you also implement rotations (ABC) in Cartesian and TCP modes using the opencascade kinematics?

2. Is there a way to switch between World (joint), Cartesian and TCP modes and execute moves in the respective modes in GCode?
Last edit: 5 years 5 months ago by Aciera.
The following user(s) said Thank You: Grotius

Please Log in or Create an account to join the conversation.

More
5 years 5 months ago - 5 years 5 months ago #208094 by Grotius
Replied by Grotius on topic ROS LinuxCNC Link
Hi Arciera,

1. Could you also implement rotations (ABC) in Cartesian and TCP modes using the opencascade kinematics?
A common implementation is the roll pitch yaw, but i like the euler angles above roll pitch yaw. The euler angles rotates the tool center point inline with the world frame axis.

2. Is there a way to switch between World (joint), Cartesian and TCP modes and execute moves in the respective modes in GCode?
I remember this question. So far as i can see there is no need to switch between modes. All modes are active at the same time. Except moving inline with the tool oriantation. This could be a extra button to activate.

If you press X+, the robot moves along the x world frame. For y and z the same.
If you press Euler X+ the robot rotates about tool center point in direction of the world frame axis x.
If you press J0+ the robot rotates about axis 0.

You can do above sequences without selecting a mode. When pressing a button, the other values will be calculated.

Arciera, if you mean something else, maybe provide a scetch so i can understand your comments even more.

There will be coded a kdl kinematics improvement wich performs anti locking and optimalisation of robot joint positions.
Maybe 300-600 lines of code. 2 day's work.

You did not see it, but the teach in function is really cool. It show your teach in path in the old screen. In fact the old screen is a
modern implementation of 3d opencascade. This widget can also show gcode etc.

For performing a gcode you can input a mdi command. What we can do is make a gcode input accelerator dialog that pop's up when
pressing the mdi line.

We need as much as idea's now. In this stage edit's are quite easy.

Impressive as usual but I have two questions:
Thank you! Coding become's easyer when you have some experience. My next programming project, will be something completely different. It will be a linux virus scanner. It's quite complex, but i did some debootstraps, chrooting, distro's (debian kali) and system.d's
to get some insights. If this suceed's maybe it can prevent something big in the future. :unsure: Or maybe not. :blink:
Last edit: 5 years 5 months ago by Grotius.

Please Log in or Create an account to join the conversation.

Time to create page: 0.497 seconds
Powered by Kunena Forum
