
- Posts: 2419
- Thank you received: 2349
Trajectory Planner using Ruckig Lib
- Grotius
- Offline
- Platinum Member
-

Less
More
2 years 3 months ago - 2 years 3 months ago #306402
by Grotius
Replied by Grotius on topic Trajectory Planner using Ruckig Lib
Hi,
For coleair lines and curves with curvature=0 (clothoid, spline that is in fact a line), i fused them to one piece of type line.
This seems to work better.
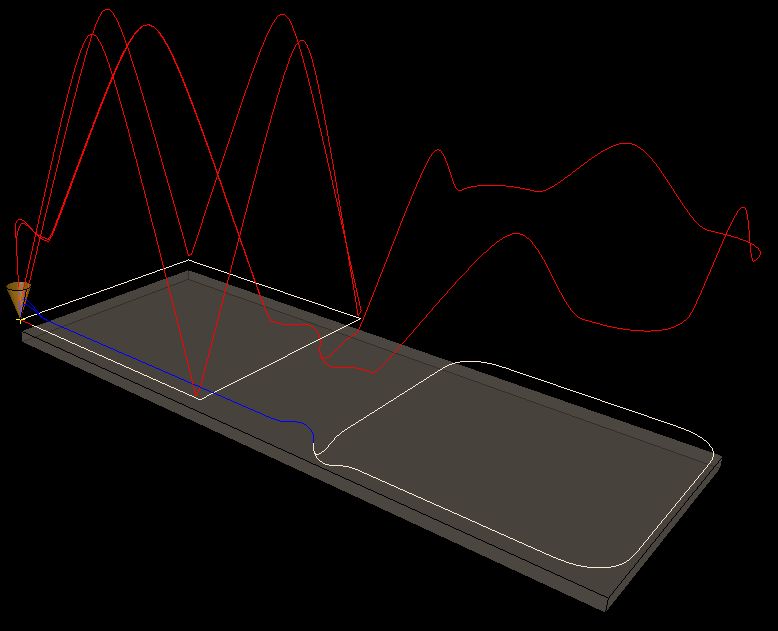
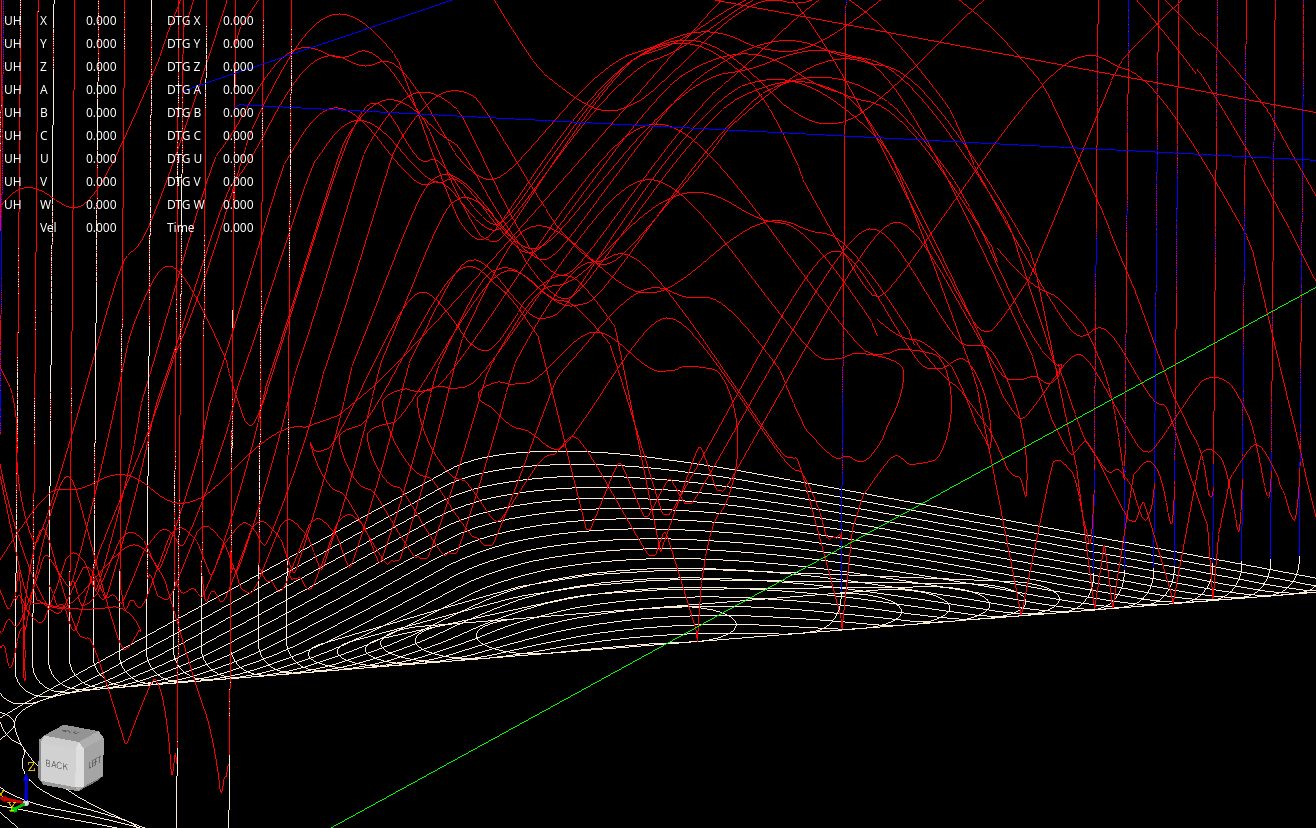
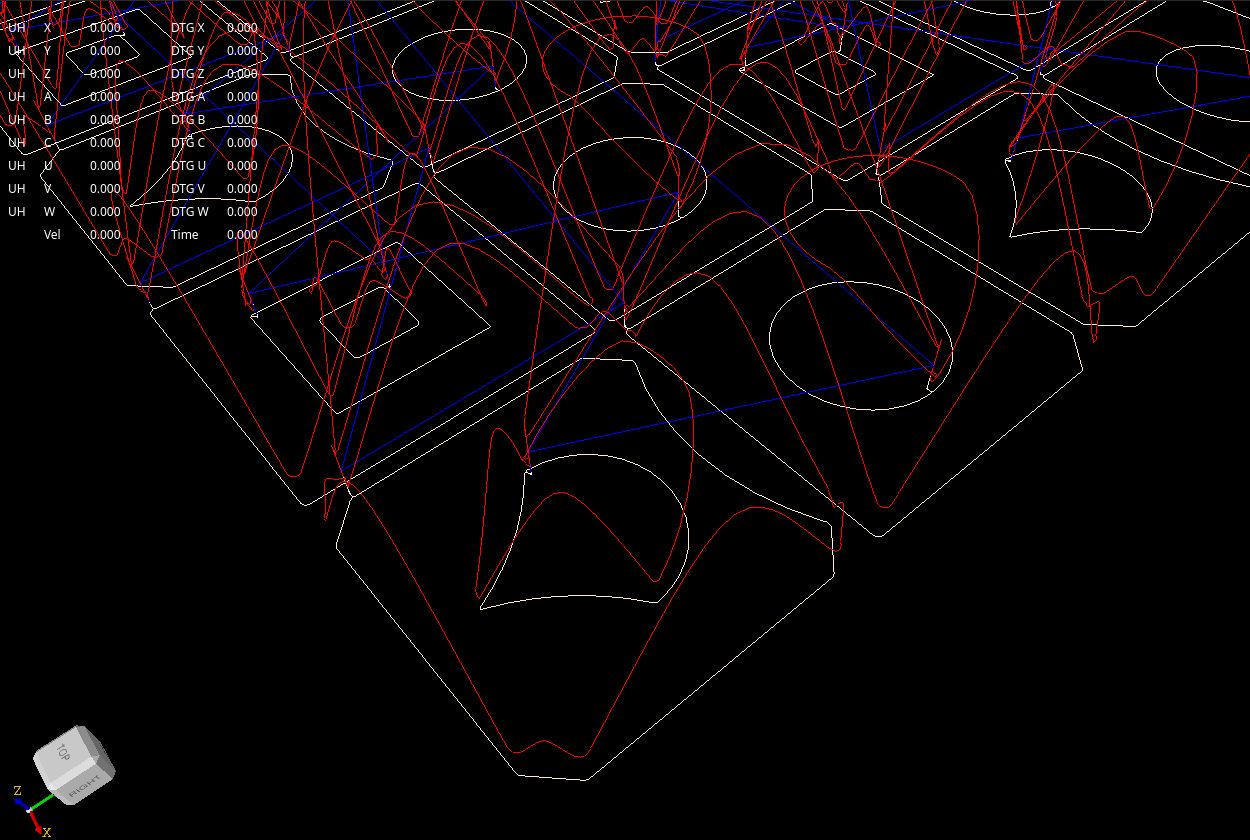
For coleair lines and curves with curvature=0 (clothoid, spline that is in fact a line), i fused them to one piece of type line.
This seems to work better.
Last edit: 2 years 3 months ago by Grotius.
The following user(s) said Thank You: akb1212, tivoi, pommen, Lcvette, Aciera, Darium, JacobRush, nwallace
Please Log in or Create an account to join the conversation.
- Grotius
- Offline
- Platinum Member
-
Less
More
- Posts: 2419
- Thank you received: 2349
2 years 3 months ago #306605
by Grotius
Replied by Grotius on topic Trajectory Planner using Ruckig Lib
Hi,
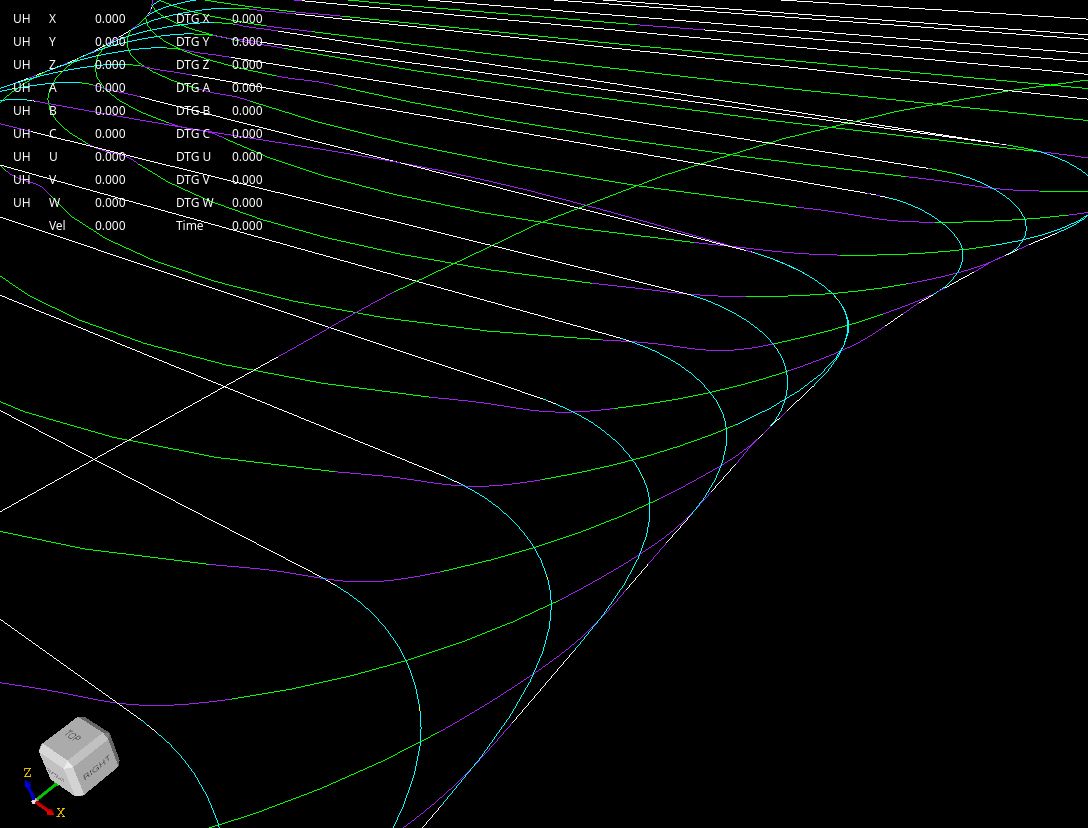
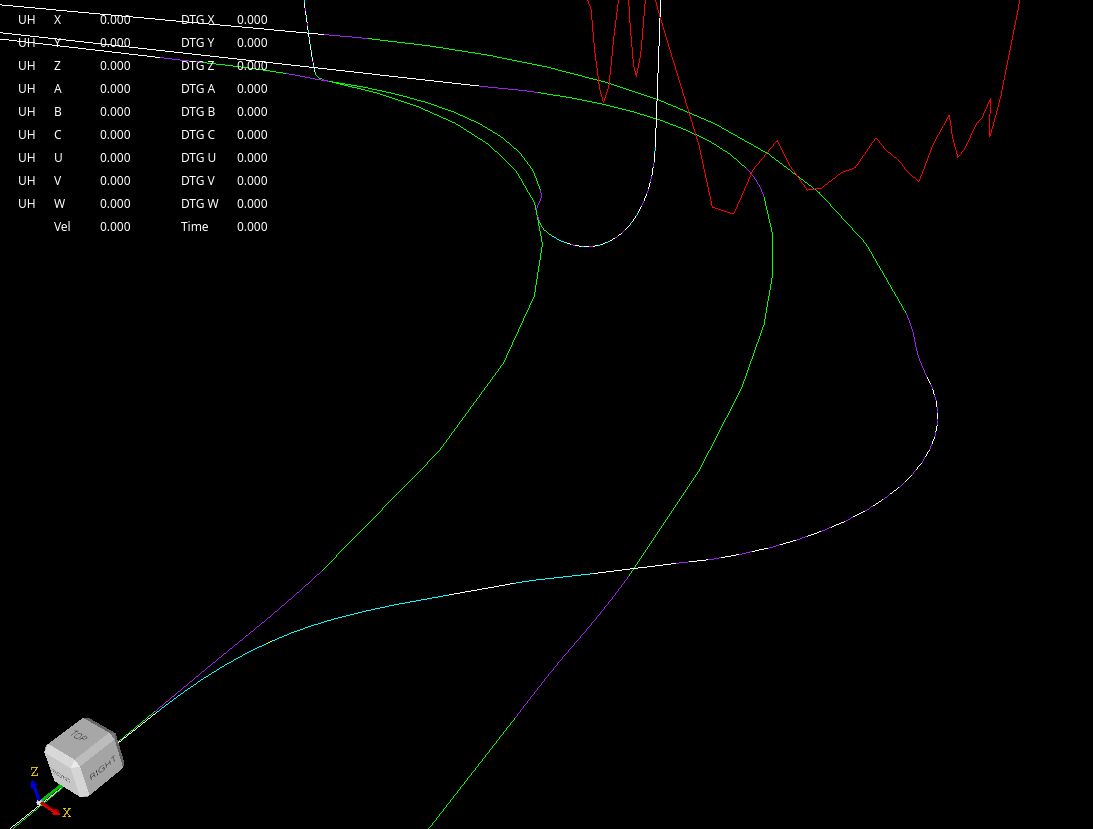
I fixed some issue's in the gcode parser, it now loads the lcevette lift_test.ngc file ok.
In gcode we used:G64 P0.05 Q0.05
It filters out tiny lines according Q value.
It add's fillets according the P value. It first try's to add clothoid fillets, then it add's spline fillets.
There is a lot happening performing the algo. Fillets can be made between 2 helixes for example.
Every scenario had to be code.
Overall this is quite a complex task.
Colors to verify:
red=3d velocity profile.
white=linelight_green=arc
purple=clothoid fillet
cyan=spline fillet
yellow=trimmed helix
dark_green=helix
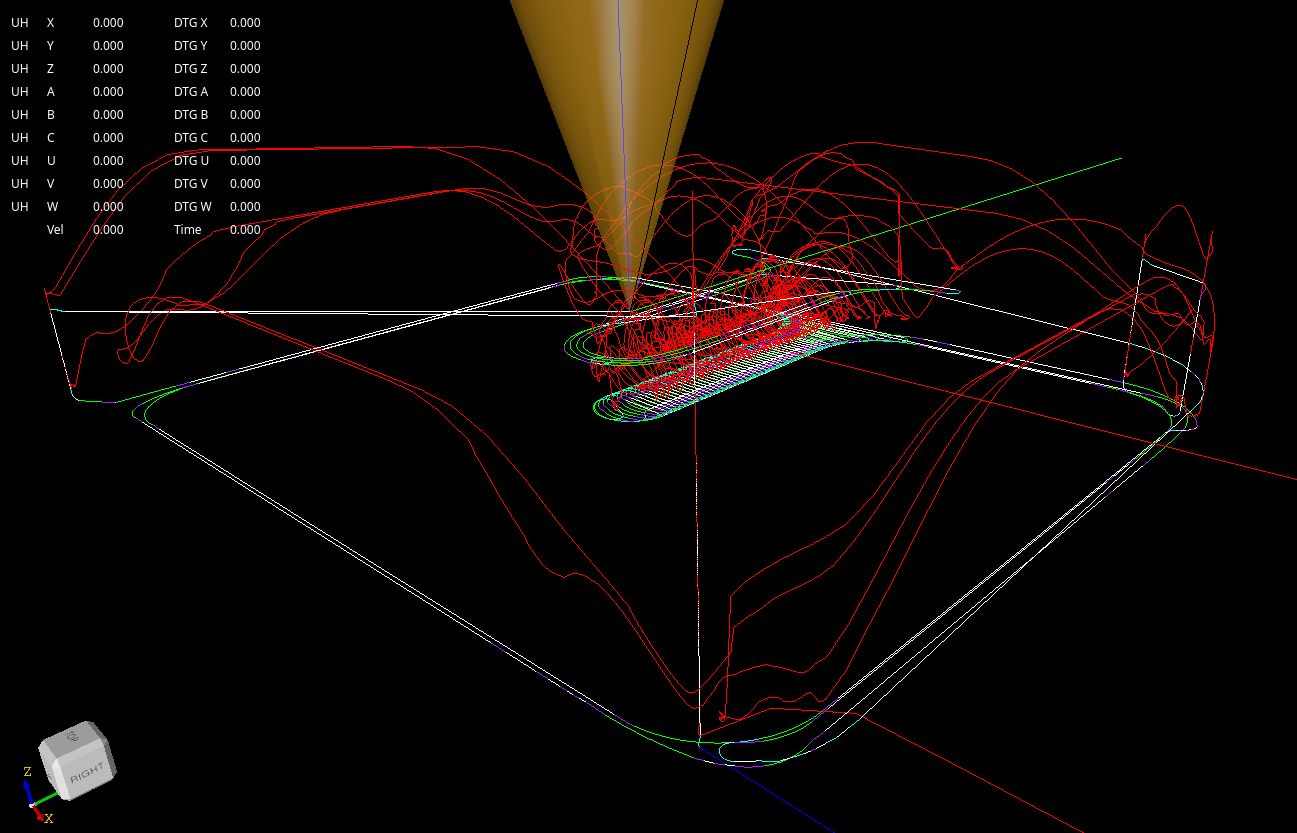
When G64 P0.0 Q0.0 output:
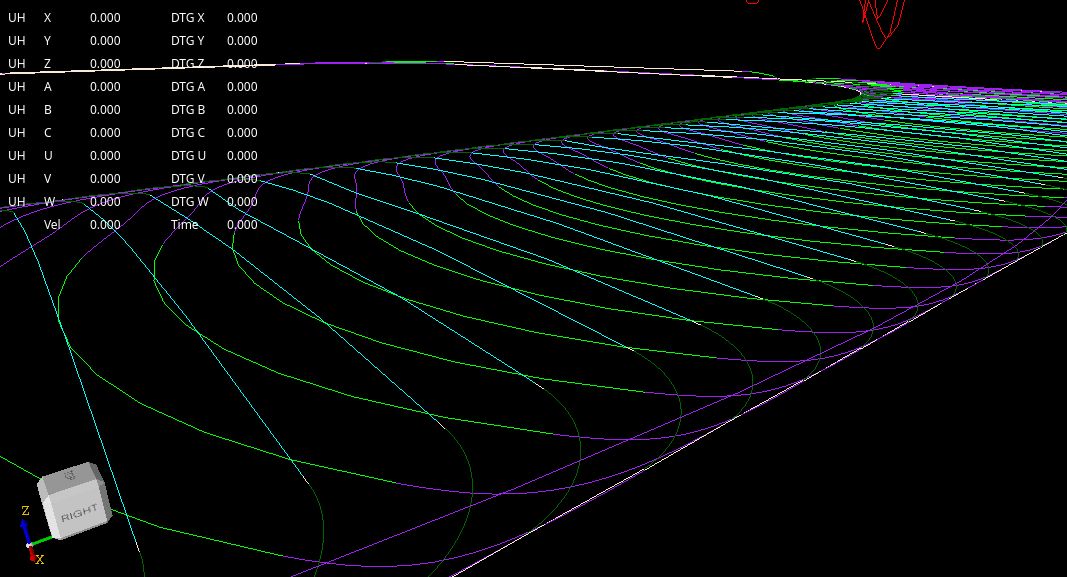
I fixed some issue's in the gcode parser, it now loads the lcevette lift_test.ngc file ok.
In gcode we used:G64 P0.05 Q0.05
It filters out tiny lines according Q value.
It add's fillets according the P value. It first try's to add clothoid fillets, then it add's spline fillets.
There is a lot happening performing the algo. Fillets can be made between 2 helixes for example.
Every scenario had to be code.
Overall this is quite a complex task.
Colors to verify:
red=3d velocity profile.
white=linelight_green=arc
purple=clothoid fillet
cyan=spline fillet
yellow=trimmed helix
dark_green=helix
When G64 P0.0 Q0.0 output:
The following user(s) said Thank You: akb1212, pommen, Lcvette, Aciera
Please Log in or Create an account to join the conversation.
- Aciera
- Offline
- Administrator
-

Less
More
- Posts: 4819
- Thank you received: 2177
2 years 3 months ago #306608
by Aciera
Replied by Aciera on topic Trajectory Planner using Ruckig Lib
Looks _very_ good!
Is this all happening in user-space so far (including the velocity planning)? If so does this output a GCODE file?
Is this all happening in user-space so far (including the velocity planning)? If so does this output a GCODE file?
The following user(s) said Thank You: akb1212, Lcvette, Grotius
Please Log in or Create an account to join the conversation.
- Grotius
- Offline
- Platinum Member
-
Less
More
- Posts: 2419
- Thank you received: 2349
2 years 3 months ago #306613
by Grotius
Replied by Grotius on topic Trajectory Planner using Ruckig Lib
This file has ~12500 lines of gcode.Used G64 P0.5 Q0.5
red=3d velocity profile
white=line
purple=clothoid fillet
cyan=spline fillet

It's now almost time to test the results on a realtime kernel.
Let's work on to that.
For a letter test:
Original input G64 P0 Q0.5
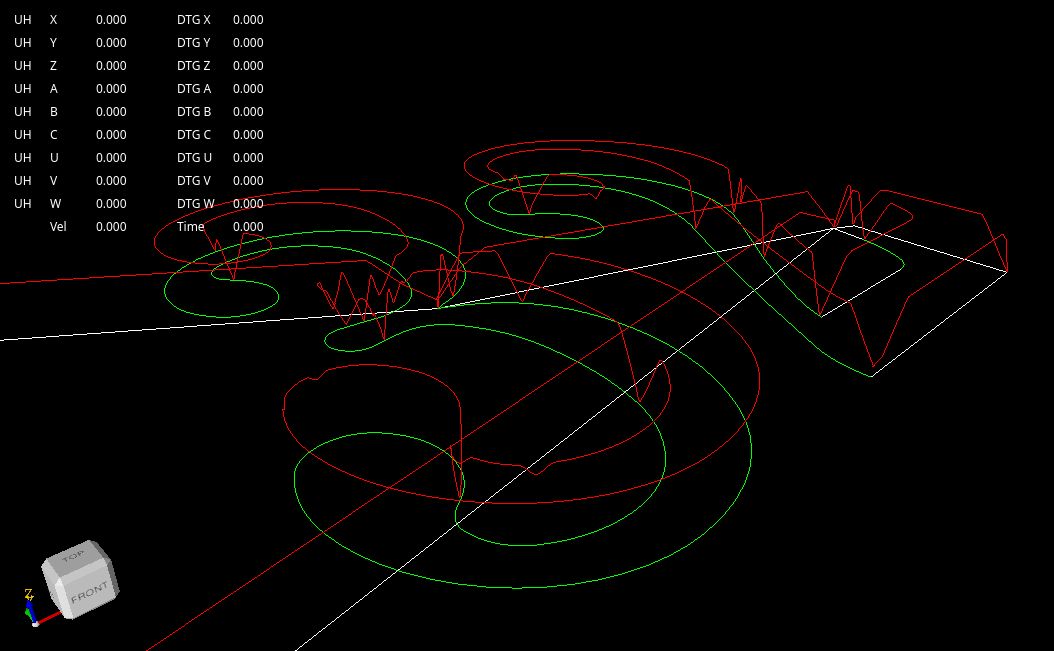
Input G64 P5 Q0.5
The spikes from the velocity profile are gone !
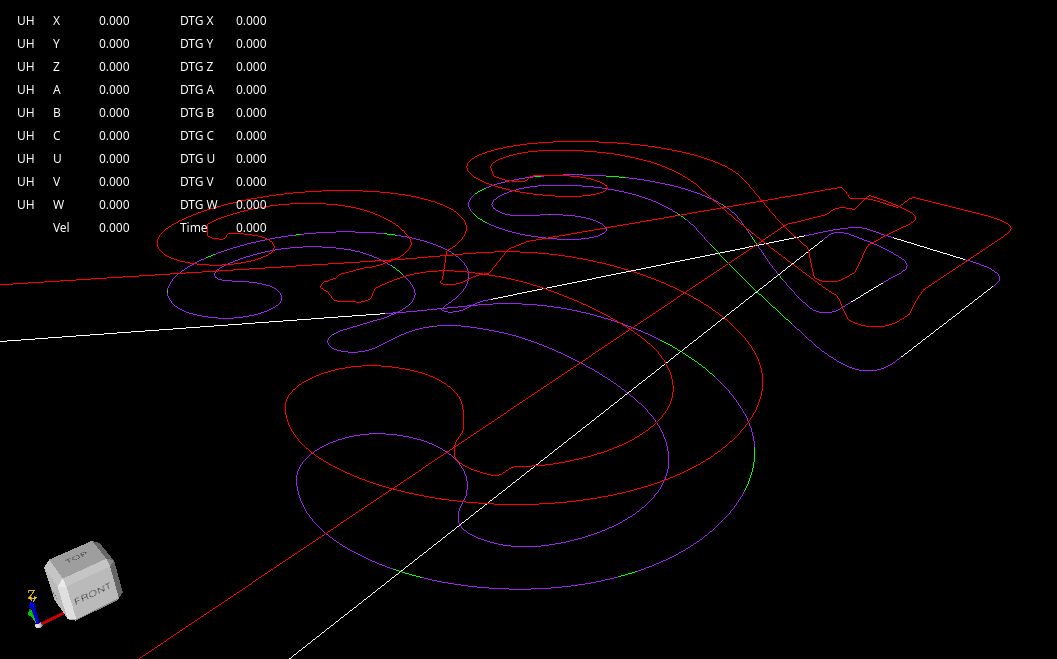
red=3d velocity profile
white=line
purple=clothoid fillet
cyan=spline fillet
It's now almost time to test the results on a realtime kernel.
Let's work on to that.
For a letter test:
Original input G64 P0 Q0.5
Input G64 P5 Q0.5
The spikes from the velocity profile are gone !
The following user(s) said Thank You: akb1212, Lcvette, Darium
Please Log in or Create an account to join the conversation.
- Grotius
- Offline
- Platinum Member
-
Less
More
- Posts: 2419
- Thank you received: 2349
2 years 3 months ago #306614
by Grotius
Replied by Grotius on topic Trajectory Planner using Ruckig Lib
Hi Arciera,
Is this all happening in user-space so far (including the velocity planning)? If so does this output a GCODE file?
Yes, this is all done on a non realtime kernel at the moment. Including the velocity planning indeed.
Currently i have no logic to output a optimized gcode file, but it is certainly possible.
How relevant is this option at the moment?
We could also add a scurve path simulator to the user side.
Then the kernel motion code, can be centralized in a c++ class, then both the user side and kernel side can use
this code to run the program. This is just an idea.
The following user(s) said Thank You: akb1212, Lcvette, Aciera
Please Log in or Create an account to join the conversation.
- Aciera
- Offline
- Administrator
-
Less
More
- Posts: 4819
- Thank you received: 2177
2 years 3 months ago #306624
by Aciera
Replied by Aciera on topic Trajectory Planner using Ruckig Lib
Not relevant, I was just wondering if I could run the output on a simulator.How relevant is this option at the moment?
The following user(s) said Thank You: Grotius
Please Log in or Create an account to join the conversation.
Time to create page: 3.692 seconds