
- Posts: 15
- Thank you received: 0
Ethercat HAL driver
- Coyote
- Offline
- New Member
-

Less
More
12 years 6 months ago #45642
by Coyote
Replied by Coyote on topic Ethercat HAL driver
After reading the examples of IgH my "second hypotesis" was born, and with your additional explanaton there is no doubt anymore. As said before, it was just non logical sequence of processing data when I looked at the first time : read input ->process-> write output .
Thank you for the explanation, and also others involved S.Itnner, IgH,.... Very good driver from Sacha, indeed. The future is here.
Regards, MArko.
Thank you for the explanation, and also others involved S.Itnner, IgH,.... Very good driver from Sacha, indeed. The future is here.
Regards, MArko.
- narogon
- Offline
- Senior Member
-

Less
More
- Posts: 43
- Thank you received: 14
12 years 6 months ago #45804
by narogon
Replied by narogon on topic Ethercat HAL driver
Hi everybody,
I've achieved some results!!
I can communicate with the drives in RT and even I've created some pyvcp to command position, to see the current state and to change the controlword
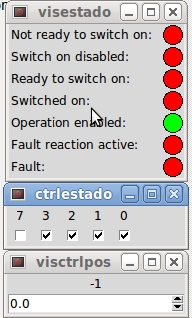
For coding the state depending of the first 7 bits of the statusword (6041) I've created a small function and installed it with comp
Next steps: Try with 4 drives and implements a delta kinematic!!
I can share all the codes if you need them!
Best Regards,
Nacho
I've achieved some results!!
I can communicate with the drives in RT and even I've created some pyvcp to command position, to see the current state and to change the controlword
For coding the state depending of the first 7 bits of the statusword (6041) I've created a small function and installed it with comp
Next steps: Try with 4 drives and implements a delta kinematic!!
I can share all the codes if you need them!
Best Regards,
Nacho
- willrat
- Offline
- New Member
-
Less
More
- Posts: 12
- Thank you received: 1
12 years 6 months ago #45815
by willrat
Replied by willrat on topic Ethercat HAL driver
Nacho,
I would be interested in seeing any information or config files relating to using these drives with linuxcnc.
We have a Panasonic A5 drive we will be using in a machine; I'm reliably informed that the Omron G5 drives are actually made by Panasonic and they are the same drives (and quite economical too!)
I assume you have still got some work todo to get the drive into the OP state to issue motion commands?
Regards
Will
- wazza77
- Offline
- Senior Member
-
Less
More
- Posts: 60
- Thank you received: 2
12 years 6 months ago #46075
by wazza77
Replied by wazza77 on topic Ethercat HAL driver
Hi Roschi
I am new to Linux cnc i have messed around with it years ago using the parallel port but nothing major. i have just stared a conversion of a
RF45 clone and i saw your video of the estun pronet drive i already have this drive but mine is the pronet 8A same encoder but i have a ethercat box added
to the side it has the 2 ports you use in the video but i was told that these will not work for ethercat i brought it from estun in china 3 months ago. due to work
i have not sorted out using this drive withe liniux cnc. i will be back home in a month and start getting it all together
i have started on the xml file following your guide for the indra drives i am a little lost there. but as yet i am not able to test as none of my computers ethernet ports were compatible
so i ordered a new computer with a compatible chipset. I would appreciate any incite you have into setting up this drive
Warren
- wazza77
- Offline
- Senior Member
-
Less
More
- Posts: 60
- Thank you received: 2
12 years 6 months ago - 12 years 6 months ago #46128
by wazza77
Replied by wazza77 on topic Ethercat HAL driver
Ok I have just found out that they have now fully integrated Ethercat into the drive and it is no longer a add on module
but from what i see it is still the same if it all works out i will buy the rest of these drives for my mill i want to do a 5 axis machine.
After seeing Roschi's effort with this drive i have a idea now of where i have been going wrong and i cant want until I finish this work tour
so i can try it out. also Roschi on your video at the beginning you have the drive as a Pronet E but this drive will not support the absolute encoder
but i see you say it is a Pronet 10A like my 8A.
p.s. what is the current 10.04 Lucid Lynx kernel version? Is it 2.6.32
Warren
Last edit: 12 years 6 months ago by wazza77.
- roschi
- Offline
- Senior Member
-
Less
More
- Posts: 40
- Thank you received: 29
12 years 6 months ago #46145
by roschi
Hi Warren,
I have the drive 'Pronet-10AEA-EC' and the motor EMJ-10ASB22 in use for the A-Axis ( Image/link ,4th axis, with battery unit --> multiturn absolut, 17 bit). If and only if the suffix '-EC' is added in the drive specification it is EtherCAT field bus. It does not depend on the design of the housing (external or internal RJ45 connectors). If you have RJ45 connectors and no '-EC' named on the drive it is the MODBUS version.
If more and more and more succes stories rise up with the use of EtherCAT drives and LinuxCNC the 'community' can start the disccusion about a special driver (=kernel module) or setup wizzard for drives which use EtherCAT and the CIA 402 profile. (Like the concept of the software 'TwinCAT', XML Files, Project setup files,....)
Up to now I hear/read of people using drives from Bosch Rexroth, LTI, Delta, Omron, Panasonic Minas 5, Estun...
--> Should we start/expand the LinuxCNC wiki about this experiences?
But keep in mind. The EtherCAT will 'taint' the LinuxCNC because it is not licensed under GPL. (I'm not really sure about that; There was/is a controverse disscusion)
Perhaps it should be better to switch to Powerlink to get industrial digital drives working with LCNC.
Regards
Andreas
Replied by roschi on topic Ethercat HAL driver
wazza77 wrote: ... Roschi on your video at the beginning you have the drive as a Pronet E but this drive will not support the absolute encoder but i see you say it is a Pronet 10A like my 8A.
Warren
Hi Warren,
I have the drive 'Pronet-10AEA-EC' and the motor EMJ-10ASB22 in use for the A-Axis ( Image/link ,4th axis, with battery unit --> multiturn absolut, 17 bit). If and only if the suffix '-EC' is added in the drive specification it is EtherCAT field bus. It does not depend on the design of the housing (external or internal RJ45 connectors). If you have RJ45 connectors and no '-EC' named on the drive it is the MODBUS version.

If more and more and more succes stories rise up with the use of EtherCAT drives and LinuxCNC the 'community' can start the disccusion about a special driver (=kernel module) or setup wizzard for drives which use EtherCAT and the CIA 402 profile. (Like the concept of the software 'TwinCAT', XML Files, Project setup files,....)
Up to now I hear/read of people using drives from Bosch Rexroth, LTI, Delta, Omron, Panasonic Minas 5, Estun...
--> Should we start/expand the LinuxCNC wiki about this experiences?
But keep in mind. The EtherCAT will 'taint' the LinuxCNC because it is not licensed under GPL. (I'm not really sure about that; There was/is a controverse disscusion)
Perhaps it should be better to switch to Powerlink to get industrial digital drives working with LCNC.
Regards
Andreas
Time to create page: 0.568 seconds