Problems with Lichuan Ethercat servo drive

More
1 year 1 month ago - 1 year 1 month ago #334502 by Hakan
Alex, try
Code:
$ ethercat -p 2 download 0x6068 0 nnn
nn being the number you want to set. There is also an upload. Sometimes it is better to do it outside of linuxcnc.
Check for SDO index:subindex using $ "ethercat -p 2 sdos"

Max, did you try to claim it with "AliExpress Seller Protection"?

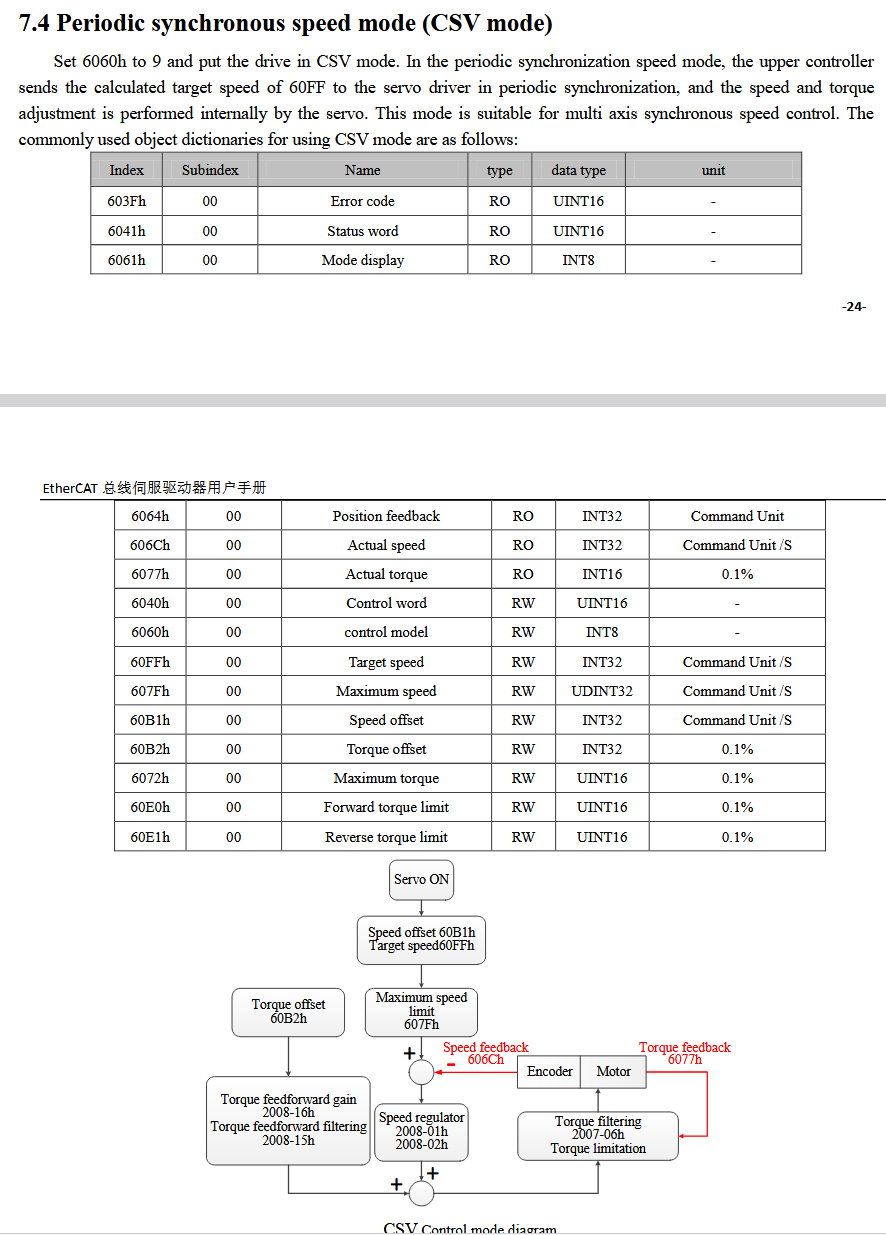
Philip, the manual says it can be done see snippet here
 
You should be able to add PDO 0x60ff to the SyncManager listing in the config, I think.
0x60ff is also in rxpdo 1703,1704,1705 so one of them should work. I guess.
Last edit: 1 year 1 month ago by Hakan.
The following user(s) said Thank You: tommylight

Please Log in or Create an account to join the conversation.

More
1 year 1 month ago #334534 by Sandro
Check my comment on page 9 for a csv config.
The following user(s) said Thank You: Philip Lydin

Please Log in or Create an account to join the conversation.

More
1 year 1 month ago #334557 by MaxEkb77
Yes shure.
I try to run servo in csp, i see one big problem - moror jumping on re-enable.

I try to dual ethercat-stepper, lol ok all enabled first motor running good - when i try to rotate shaft motor not showing feedback. second axis showing normal. first axis good run - second axis max spedd 500rpm if more motor jumping.

Please Log in or Create an account to join the conversation.

More
1 year 1 month ago #334579 by Philip Lydin
Has anyone been able to connect the drives to their tuning software. Maybe its because im on windows 11.

Please Log in or Create an account to join the conversation.

More
1 year 1 month ago #334580 by MaxEkb77
I not remember tuning software on lichuan servo, stepper have utility to connect driver and change parameter - only on chinese

Please Log in or Create an account to join the conversation.

More
1 year 1 month ago #334603 by stirra

Hello.
I had to recreate LC10 homing code from zero reading manual designated for a driver with a motor with incremental encoder . ( I thought original code was difficult to fix )

If you still have some problems, I consider to open my codes...( I have something to do for some improvement )
 
@tar_san - I very much would like to see your code.  I am not happy with my fixes to the original code.  Thank you!

-- Ralph

Please Log in or Create an account to join the conversation.

Time to create page: 0.510 seconds
Powered by Kunena Forum