Problems with Lichuan Ethercat servo drive

More
1 year 3 months ago #331897 by mra7768

ซานโดร โพสต์=311023 รหัสผู้ใช้=27482เอาล่ะ นี่คือวิดีโอสั้นๆ ของเซอร์โวเหล่านี้ที่กำลังทำงาน

[วิดีโอ]

[/video]


Hi, I’d like to ask — which version of LinuxCNC and kernel are you currently running?


Please Log in or Create an account to join the conversation.
More
1 year 3 months ago - 1 year 3 months ago #331901 by MaxEkb77
Last edit: 1 year 3 months ago by MaxEkb77.
The following user(s) said Thank You: tommylight

Please Log in or Create an account to join the conversation.

More
1 year 3 months ago #331968 by oneKone
Hi all,

Thanks to this thread I have an axis moving! 

Unfortunately I'm a complete noob when it comes to LinuxCNC and I've been overwhelmed when it comes to looking at other people's setups for how to add PID.

I don't suppose anyone has a simplified setup they're willing to share so I could suss out how it works?

Cheers 

Please Log in or Create an account to join the conversation.

More
1 year 2 months ago - 1 year 2 months ago #332741 by Aleske
Hello,I am in the process of getting 4x Lichuan LC10E drives running in CSP mode. I have also observed the behavior of a large following error in CSP mode, as user Sandro mentioned in his post on 14 Sep 2024. After many hours of trying to run CSP mode without encountering a large following error, I suspect that parameter 6068 "Position window time" is to blame. The default setting is 16 ms, which I interpret as the drive having 16 ms to reach the required position. Together with parameter 6067 "Position window", this allows for a large following error while the drive still believes it is operating correctly.

Unfortunately, I am unable to change these values. Initially, I tried reading them with:"<pdoEntry idx="6068" subIdx="00" bitLen="16" halPin="position-window-time" halType="u32"/>"

But this gives me a changing value in HAL show with strange behavior as I would expect a steady value of 16When I try to write to 6068, I get the following error:
Code:
LCEC: Slave 0.3: Failed to execute SDO Download (0x6068:0x00, size 2, byte0=1, error -5, abort_code 0000000=)  Maybe this helps someone with more knowledge of EtherCAT achieve accurate positioning in CSP mode.Best regards, Alex 
Last edit: 1 year 2 months ago by Aleske.

Please Log in or Create an account to join the conversation.

More
1 year 2 months ago #332788 by MaxEkb77
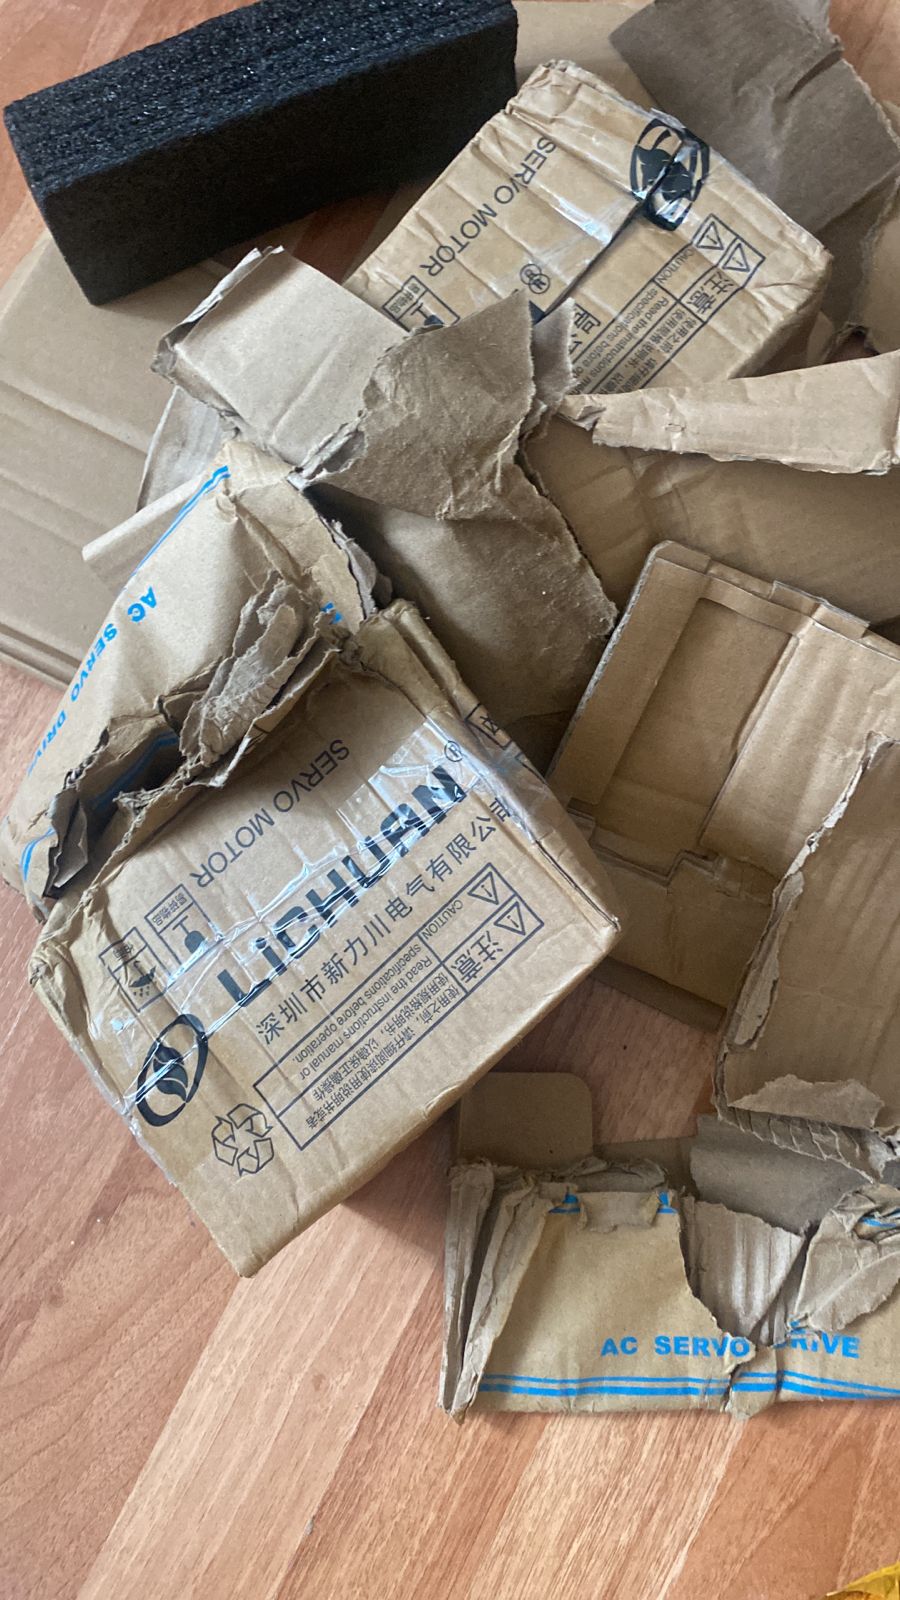
Lichuan strange company i buy at aliexpress & receive a water damaged garbage and no one wants to be responsible for it. 

Please Log in or Create an account to join the conversation.

More
1 year 1 month ago #334486 by Philip Lydin
Is it possible to use the lichuan servos in csv mode with ethercat. i dont see any target speed the the variable pdo mapping. Can you use the fixed pdo mapping? Ive tried using index 1702(fixed) but im not able to enable the drive.

Please Log in or Create an account to join the conversation.

Time to create page: 0.452 seconds
Powered by Kunena Forum
