Problems with Lichuan Ethercat servo drive

More
1 year 7 months ago #325067 by LCR
Hi All
Does anyone have these drives jogging that can try some moves?
What I would like is if you would try some programmed moves back and forth while monitoring the target position (607A), the actual position (6064), the pos-cmd  (60FC), the corresponding joint.X.f-error and show their values after a few (10) moves of whatever distance you can travel back and forth.

My issue is as follows:

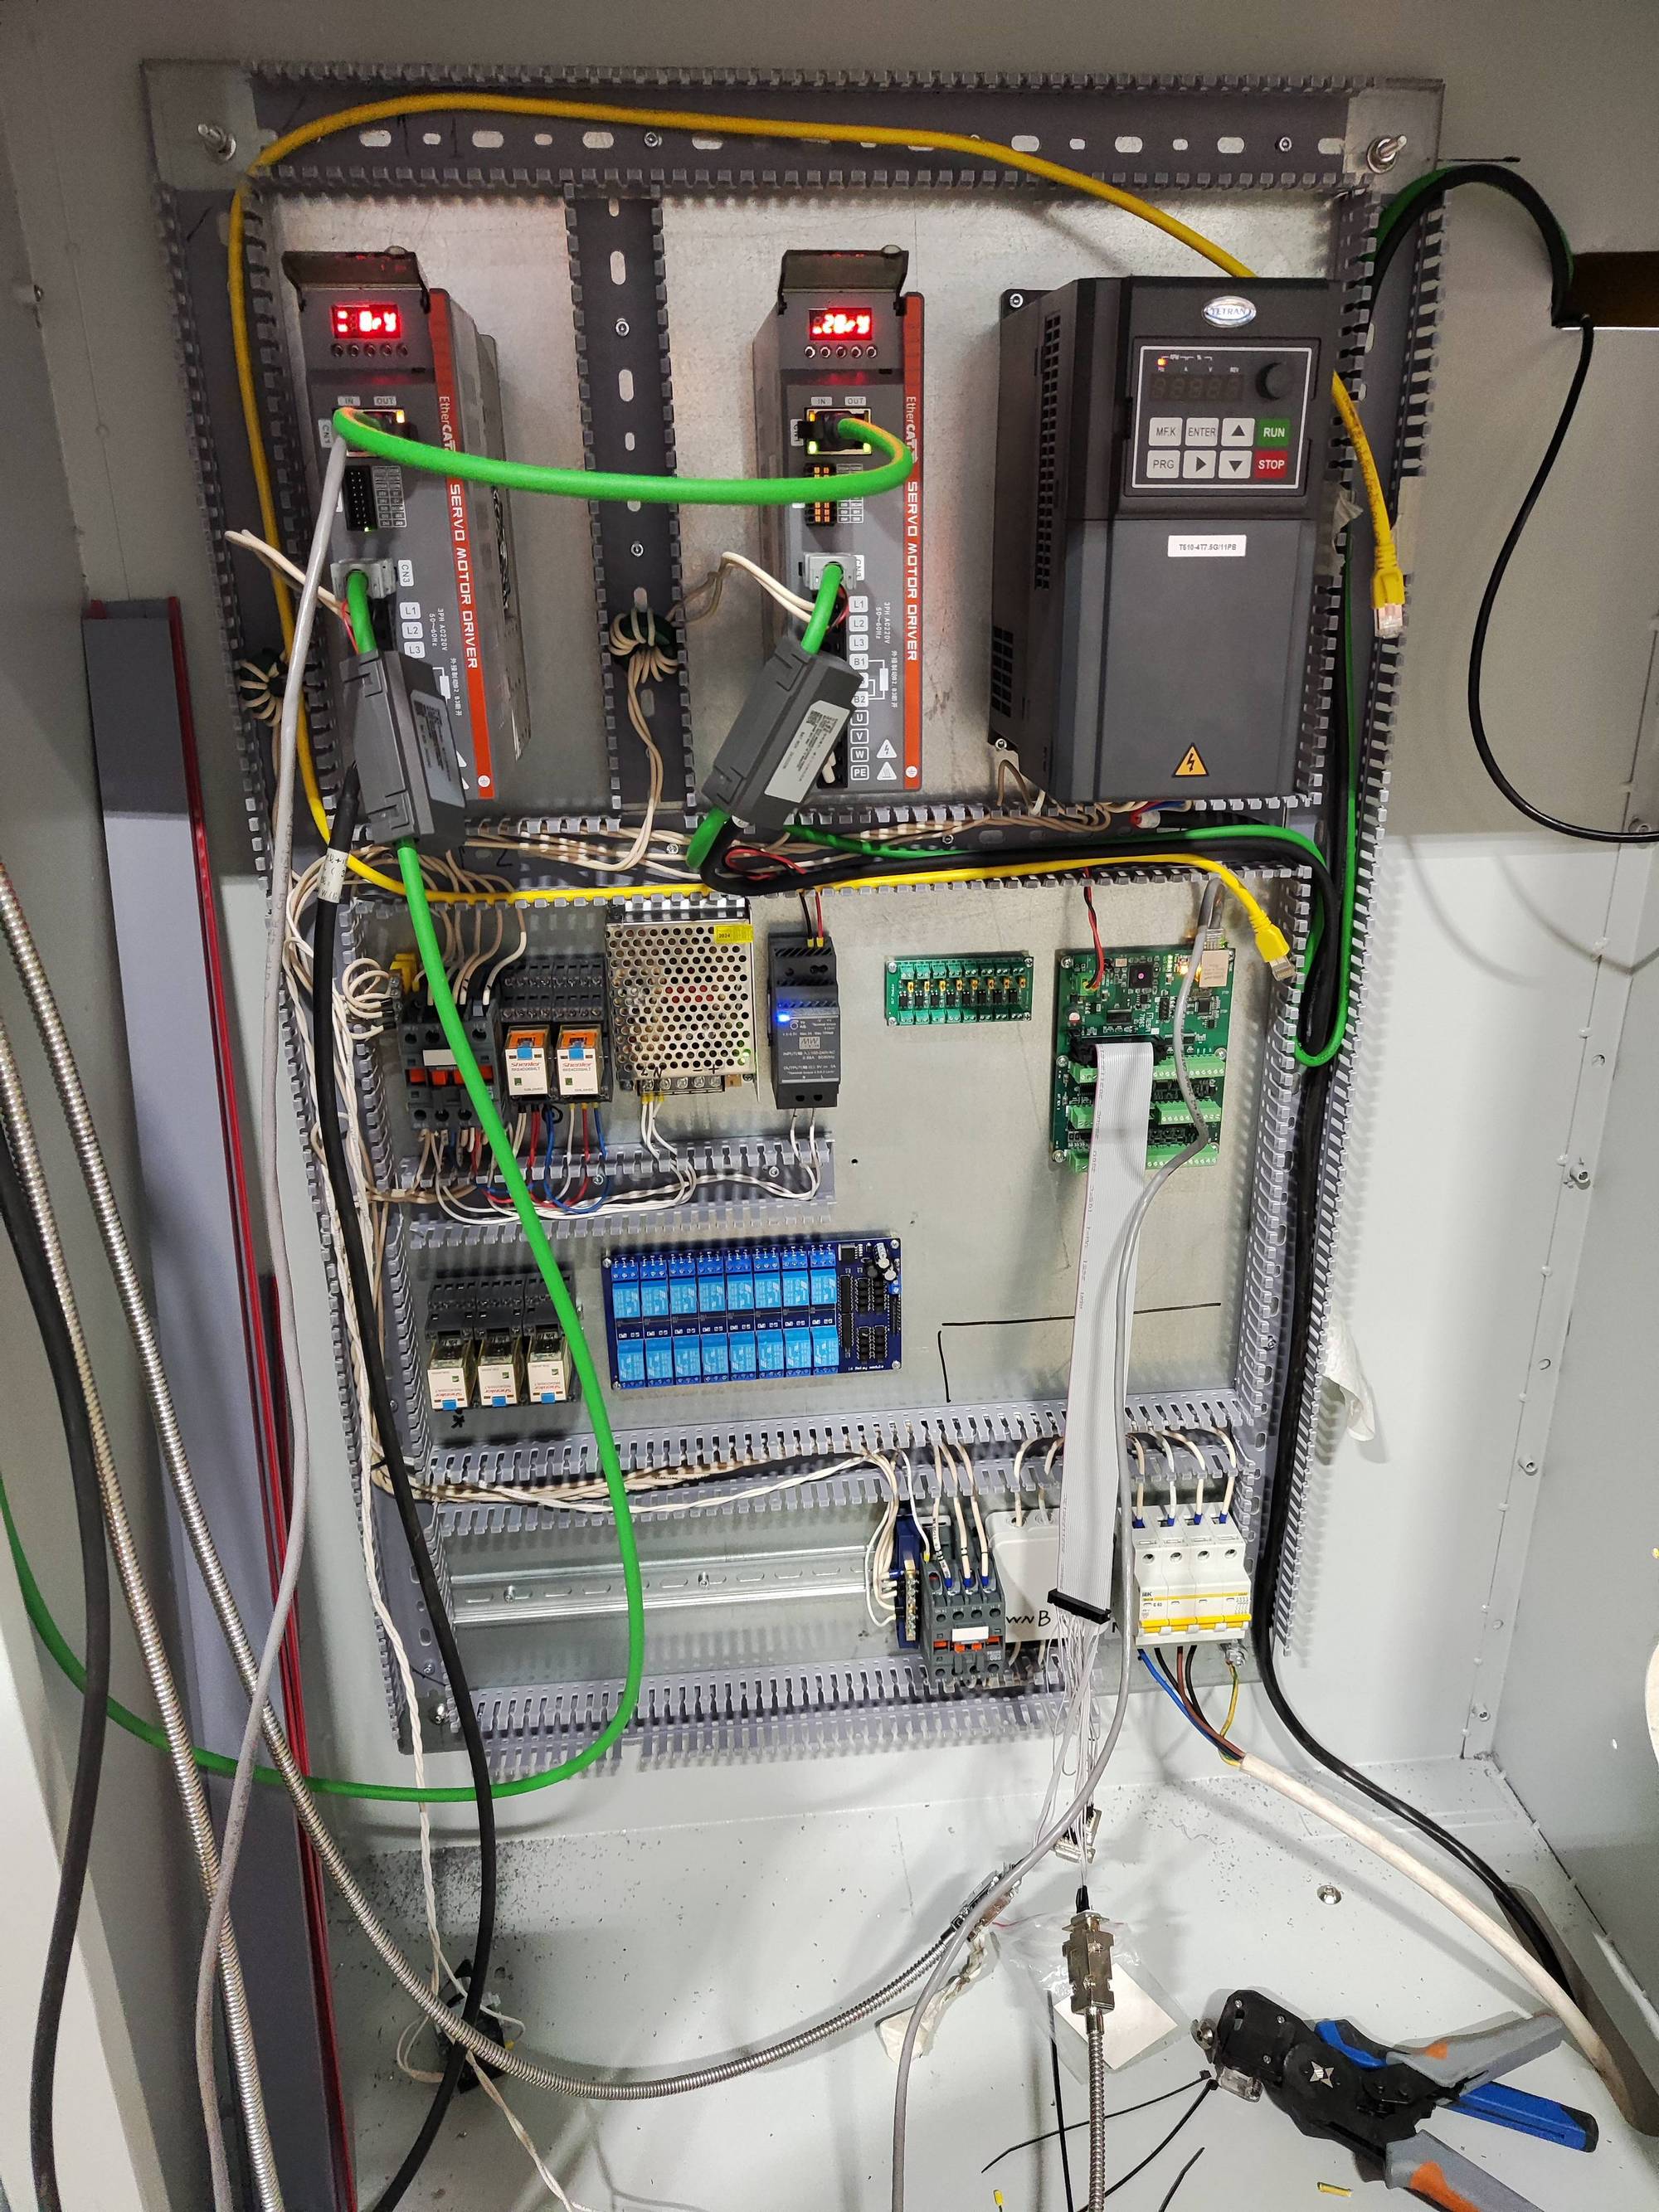
I have 4 LC 10 E 1000 amplifier kits with 2500 RPM 17 bit motors, and they are all exhibiting the same following error issue. 
I am running the servos in CSP mode at 1kHZ with LinuxCNC.

The issue I have is that the target position (607A) develops an offset and the actual position (6064) does not become equal. There is a random offset, which seems to grow over time. It can be thousands of counts. The motor actual position (6064) remains correct. The motor is counting correctly. I put a dial gauge at the end of travel, and the actual position (6064) is correct. To compensate for this, I put an integral loop in the machine controller. With this integral loop the machine moves correctly. When the controller software disables the drive power, and re-enables, the offset is gone. I have monitored the pos-cmd (60FC) and it follows the motor actual position (6064), until I disable and re-enable the drive. When I disable and re-enable the drive the pos-cmd (60FC) feedback value does not match either of the other 2 (6064) or (607A) however (6064) does now match (607A). The machine will then move to the correct position without requiring any integral compensation for a period, until the offset re-appears.

The offset between the target position (607A) and the actual position (6064) remains even if I jog the axis slightly, or if I manually force the servo out of position slightly. The servo wants to maintain the offset error. I have tried changing all of the gains to see if there is an effect on the error, and there is none.

Encoder Position Deviation P0B.15, always remains _0000. I would expect it to show the following error.
Position Deviation Counter P0B.53, always remains _0000. I would expect it to show the following error.
Input Position Command Count P0B.13 matches pos-cmd (60FC). It matches even when the target position (607A) and the actual position (6064) are different values.
The last fault shows as P0B.33 == 1, P0B.34 == 952 which is reverse over travel, which was from homing.
Actual motor speed P0B.55 does display values that change and seem correct.

The software version is: P01.50 ==>  03.16


File Attachment:

File Name: ethercat-c...27-3.xml
File Size:6.62 KB


Please Log in or Create an account to join the conversation.

More
1 year 6 months ago #327377 by PabloSancez
Hi! This is a lathe with Lichuan Ethercat and mesa 7i96s servodrivers for controlling the spindle with a mesa digital potentiometer mesa processes three encoders, one spindle and two linear for each axis, and it seems to work fine. I was even able to thread the G76 cycle.

I use absolute encoders how do I set up the machine so that the position of the machine is automatically read from the drivers when the machine is turned on?

Please Log in or Create an account to join the conversation.

More
1 year 6 months ago #327383 by COFHAL
I have those same servos, but the problem is that they don't measure correctly, and the circles turn out oval. How do I adjust the servos?

Please Log in or Create an account to join the conversation.

More
1 year 5 months ago - 1 year 5 months ago #328710 by PabloSancez
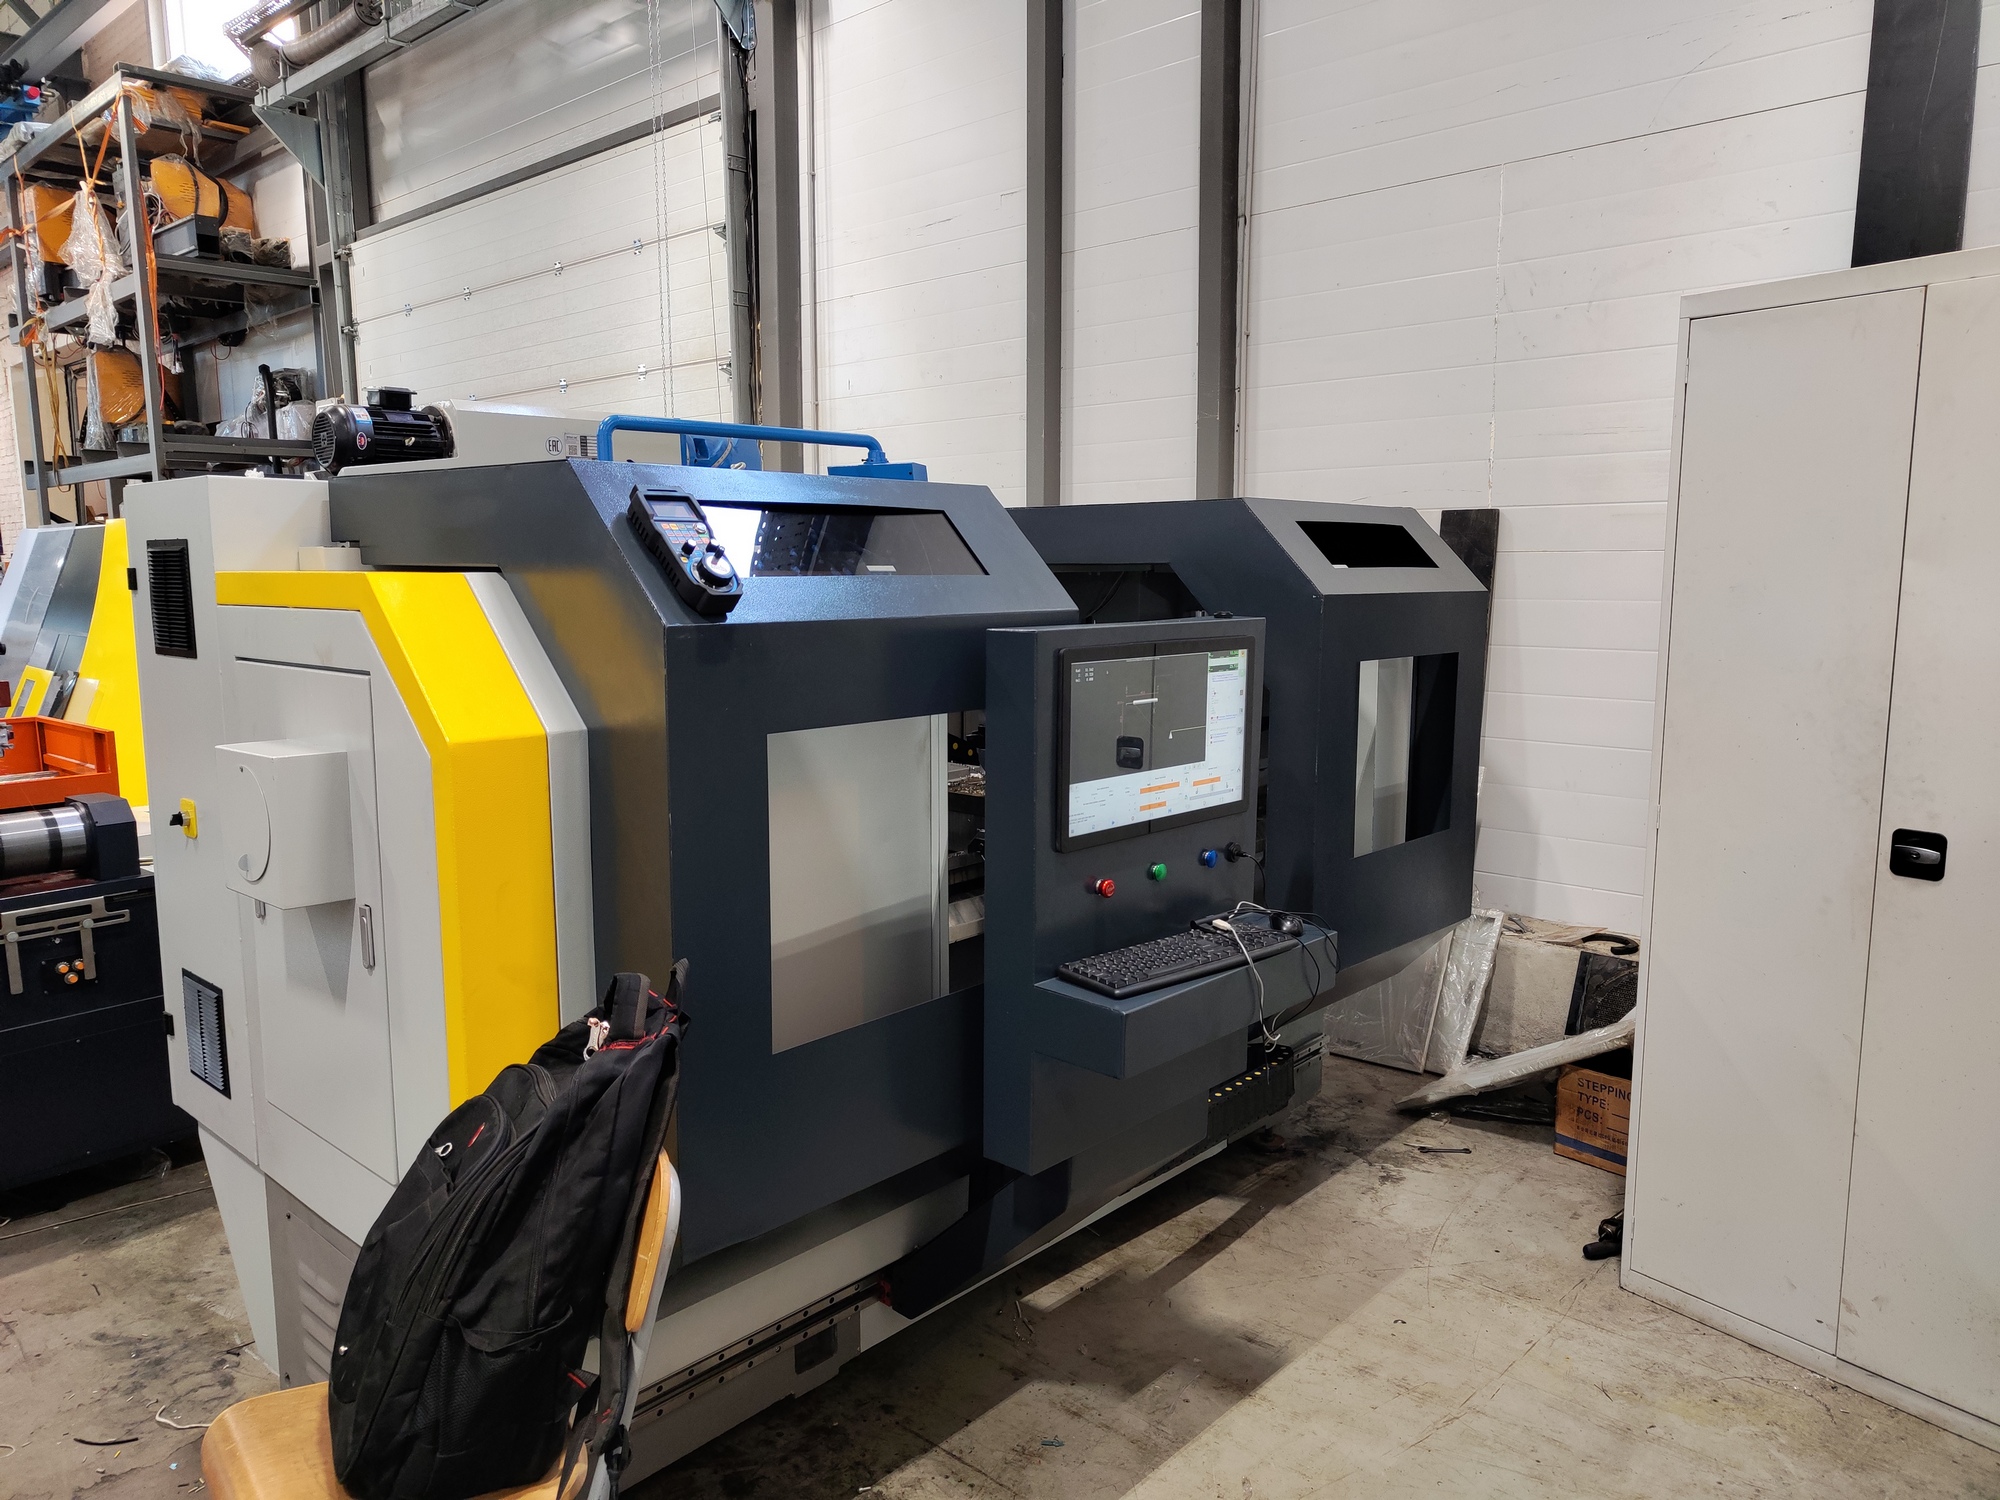
Hi, I have finished the lathe with ethercat drivers. I'm posting my configuration. I am using a revolver head with asynchronous motor with carousel control. mesa reads the encoder and buttons. the machine is cast in steel.

youtube.com/shorts/veTGtAU7UrY
youtube.com/shorts/fbEU6qiVqMk
disk.yandex.ru/d/rNy3ErpcVfzkxw
Last edit: 1 year 5 months ago by PabloSancez.
The following user(s) said Thank You: tommylight, scotth, onceloved, Philip Lydin

Please Log in or Create an account to join the conversation.

More
1 year 5 months ago - 1 year 5 months ago #328951 by ihavenofish
ooh, nice. you think you can help me config my ethercat setup. i have different drives, but im stuck at the "how do i even make ethercat work" part. :)

i looked through your files a bit, but of course they dont start cause i got no mesa card in mine.
Last edit: 1 year 5 months ago by ihavenofish.

Please Log in or Create an account to join the conversation.

More
1 year 5 months ago #329102 by JohnW
I'm new to this and was asking Chat GPT what the problems were with Lichuan drives. It says EtherCat Master stacks on Linux CNC expect drives to follow CiQ 402 correctly, but Lichuan drives lack full state machine compliance, and incorrectly transition from Ready to Switch ON to Operation Enabled, etc. Windows stacks are more tolerant of violations. So by plugging the drive in after they have done an illegal transition, Linux CNC stacks remain happy.

Please Log in or Create an account to join the conversation.

Time to create page: 0.141 seconds
Powered by Kunena Forum