Problems with Lichuan Ethercat servo drive

More
1 year 8 months ago #321272 by LCR
I would like to tune my drives a bit. What tuning have people tried? I'm not clear if the following command tunes the drives or re-sets everything. I'd rather not try at this point. I just let Linux do an update and had to re-install.

LC-E Series AC Servo Drive
5.2.1 Initialization parameters
Set P02-31 to 1 to initialize the drive parameters, and the drive needs to be restarted after the setting is completed.

Also, what are people doing for gantry (dual servos on a single axis) systems? 

Please Log in or Create an account to join the conversation.
More
1 year 8 months ago #321276 by rodw

Also, what are people doing for gantry (dual servos on a single axis) systems? 
If I can get internal homing working, there is a setting in the drive for home offset so you would just adjust for squareness using it.
The following user(s) said Thank You: LCR

Please Log in or Create an account to join the conversation.

More
1 year 8 months ago #321284 by LCR
Hi RodW

Thanks so much for your effort.

What I have done so far to get my gantry moving is just tie the home markers for the 2 X axes together

net mydigitalinx lcec.0.0.mydigitalin => cia402.0.mydigitalin cia402.1.mydigitalin

I then modified the cia402.comp file to accommodate. I Use the index pulse from each axis for the final position. I am away from the machine until Friday, I will upload the files then.

I just loosen the coupler once homed to adjust the squareness. It seems to be working. (only need to adjust once)

Please Log in or Create an account to join the conversation.

More
1 year 8 months ago #321287 by LCR
So the answer is 

5.2.1 Initialization parameters
Set P02-31 to 1 to initialize the drive parameters, and the drive needs to be restarted after the setting is completed.

P02.31
0: No operation 1: Restore factory values (except P00/P01 group) 2: Clear fault records

So NO that does not tune the drive.
. 

Please Log in or Create an account to join the conversation.

More
1 year 8 months ago - 1 year 8 months ago #321301 by LCR
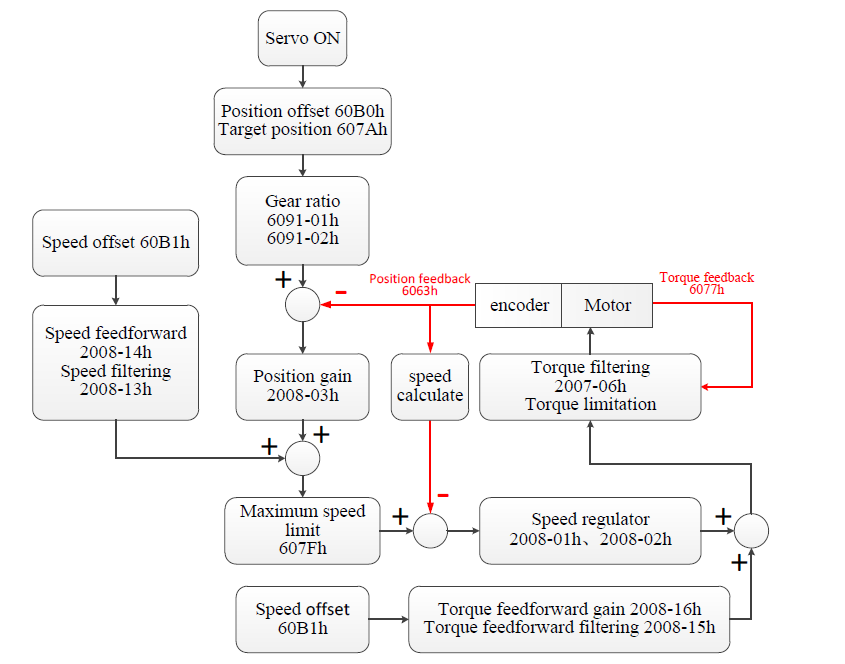
Actually we are using 7.3 Periodic synchronous position mode (CSP mode)
 
Last edit: 1 year 8 months ago by LCR.

Please Log in or Create an account to join the conversation.

More
1 year 8 months ago #321437 by LCR
It looks like even in CSP mode, there is an option for Velocity Feed Forward. This is one of the biggest improvements a control loop can have. Has anyone tried this? 
60B1h 00 Speed offset


Please Log in or Create an account to join the conversation.

Time to create page: 0.552 seconds
Powered by Kunena Forum
