Ethercat random jitter fix

More
7 months 2 weeks ago - 7 months 2 weeks ago #344240 by grandixximo
@TAKUYA
@Atsu

Please share your full XML
and the output of ethercat master command after you have started linuxcnc
Last edit: 7 months 2 weeks ago by grandixximo.
The following user(s) said Thank You: TAKUYA

Please Log in or Create an account to join the conversation.

More
7 months 2 weeks ago - 7 months 2 weeks ago #344241 by Atsu
Replied by Atsu on topic Ethercat random jitter fix
Thank you for taking the time to go through the messages from the last few days. I suspected as much, the AI's "fix" wasn't really anything useful.

Regarding the first slave lacking DC, you are correct. I actually changed the order of slaves in the chain yesterday so that the A6 servos are now defined first. They do have assignActivate defined. However, that change didn't make any difference to the dc-phased pin or the pll-*** pins.

I have attached my ethercat-conf.xml along with HAL and INI files if they are of any help.

ethercat master command after LinuxCNC has started:

Master0
  Phase: Operation
  Active: yes
  Slaves: 6
  Ethernet devices:
    Main: 10:60:4b:5b:58:34 (attached)
      Link: UP
      Tx frames:   146273
      Tx bytes:    9824436
      Rx frames:   146272
      Rx bytes:    9824318
      Tx errors:   0
      Tx frame rate [1/s]:    800    709    308
      Tx rate [KByte/s]:     93.7   84.1   32.2
      Rx frame rate [1/s]:    800    709    308
      Rx rate [KByte/s]:     93.7   84.1   32.2
    Common:
      Tx frames:   146273
      Tx bytes:    9824436
      Rx frames:   146272
      Rx bytes:    9824318
      Lost frames: 0
      Tx frame rate [1/s]:    800    709    308
      Tx rate [KByte/s]:     93.7   84.1   32.2
      Rx frame rate [1/s]:    800    709    308
      Rx rate [KByte/s]:     93.7   84.1   32.2
      Loss rate [1/s]:          0     -0      0
      Frame loss [%]:         0.0   -0.0    0.0
  Distributed clocks:
    Reference clock:   Slave 0
    DC reference time: 826802114159640000
    Application time:  826802133398422723
                       2026-03-14 11:15:33.398422723
Last edit: 7 months 2 weeks ago by Atsu.
The following user(s) said Thank You: TAKUYA

Please Log in or Create an account to join the conversation.

More
7 months 2 weeks ago #344242 by TAKUYA
Replied by TAKUYA on topic Ethercat random jitter fix
Hello
Please see the attached Files.

Thanks for looking through them.

~Takuya

Please Log in or Create an account to join the conversation.
More
7 months 2 weeks ago - 7 months 2 weeks ago #344249 by grandixximo
@atsu

Your servo drivers support a period of 1250000

????
Last edit: 7 months 2 weeks ago by grandixximo.

Please Log in or Create an account to join the conversation.

More
7 months 2 weeks ago - 7 months 2 weeks ago #344251 by grandixximo
@TAKUYA

I see that you did not set pdo 1600 for your X drive was this on purpose?

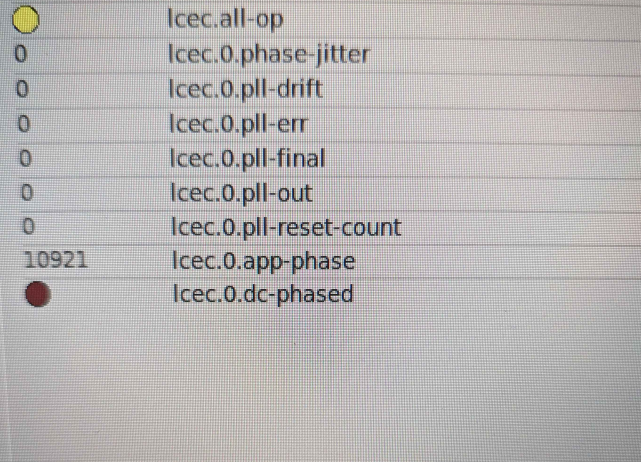
I don't think the EK1100 needs the dconf line at all, but that should not effect, your DC seems ok, can you open the halscope, plot pll_err and app_phase? also servo-thread

also Sync0Shift should be half or 30% your cycle time, not 0
 
Last edit: 7 months 2 weeks ago by grandixximo.

Please Log in or Create an account to join the conversation.

More
7 months 2 weeks ago #344252 by Atsu
Replied by Atsu on topic Ethercat random jitter fix

@atsu

Your servo drivers support a period of 1250000

????

Yes, they should. The manual states the following:

In the work mode, the synchronization cycle must be an integer multiple of 125 μs. Otherwise, the servo
drive will report Er74.0 (EtherCAT synchronization cycle setting is incorrect.)


Initially, I ran the drives with a period of 1000000 ns, but increased it to the current value couple months ago. Did it because in some rare instances I got "Unexpected realtime delay on task 0 with period 1000000" error in UI. I can try lowering it back to 1000000 ns to see if it makes any difference.

Please Log in or Create an account to join the conversation.

Time to create page: 0.156 seconds
Powered by Kunena Forum
