- Posts: 31
- Thank you received: 4

Please Log in or Create an account to join the conversation.
@TAKUYA
@Atsu
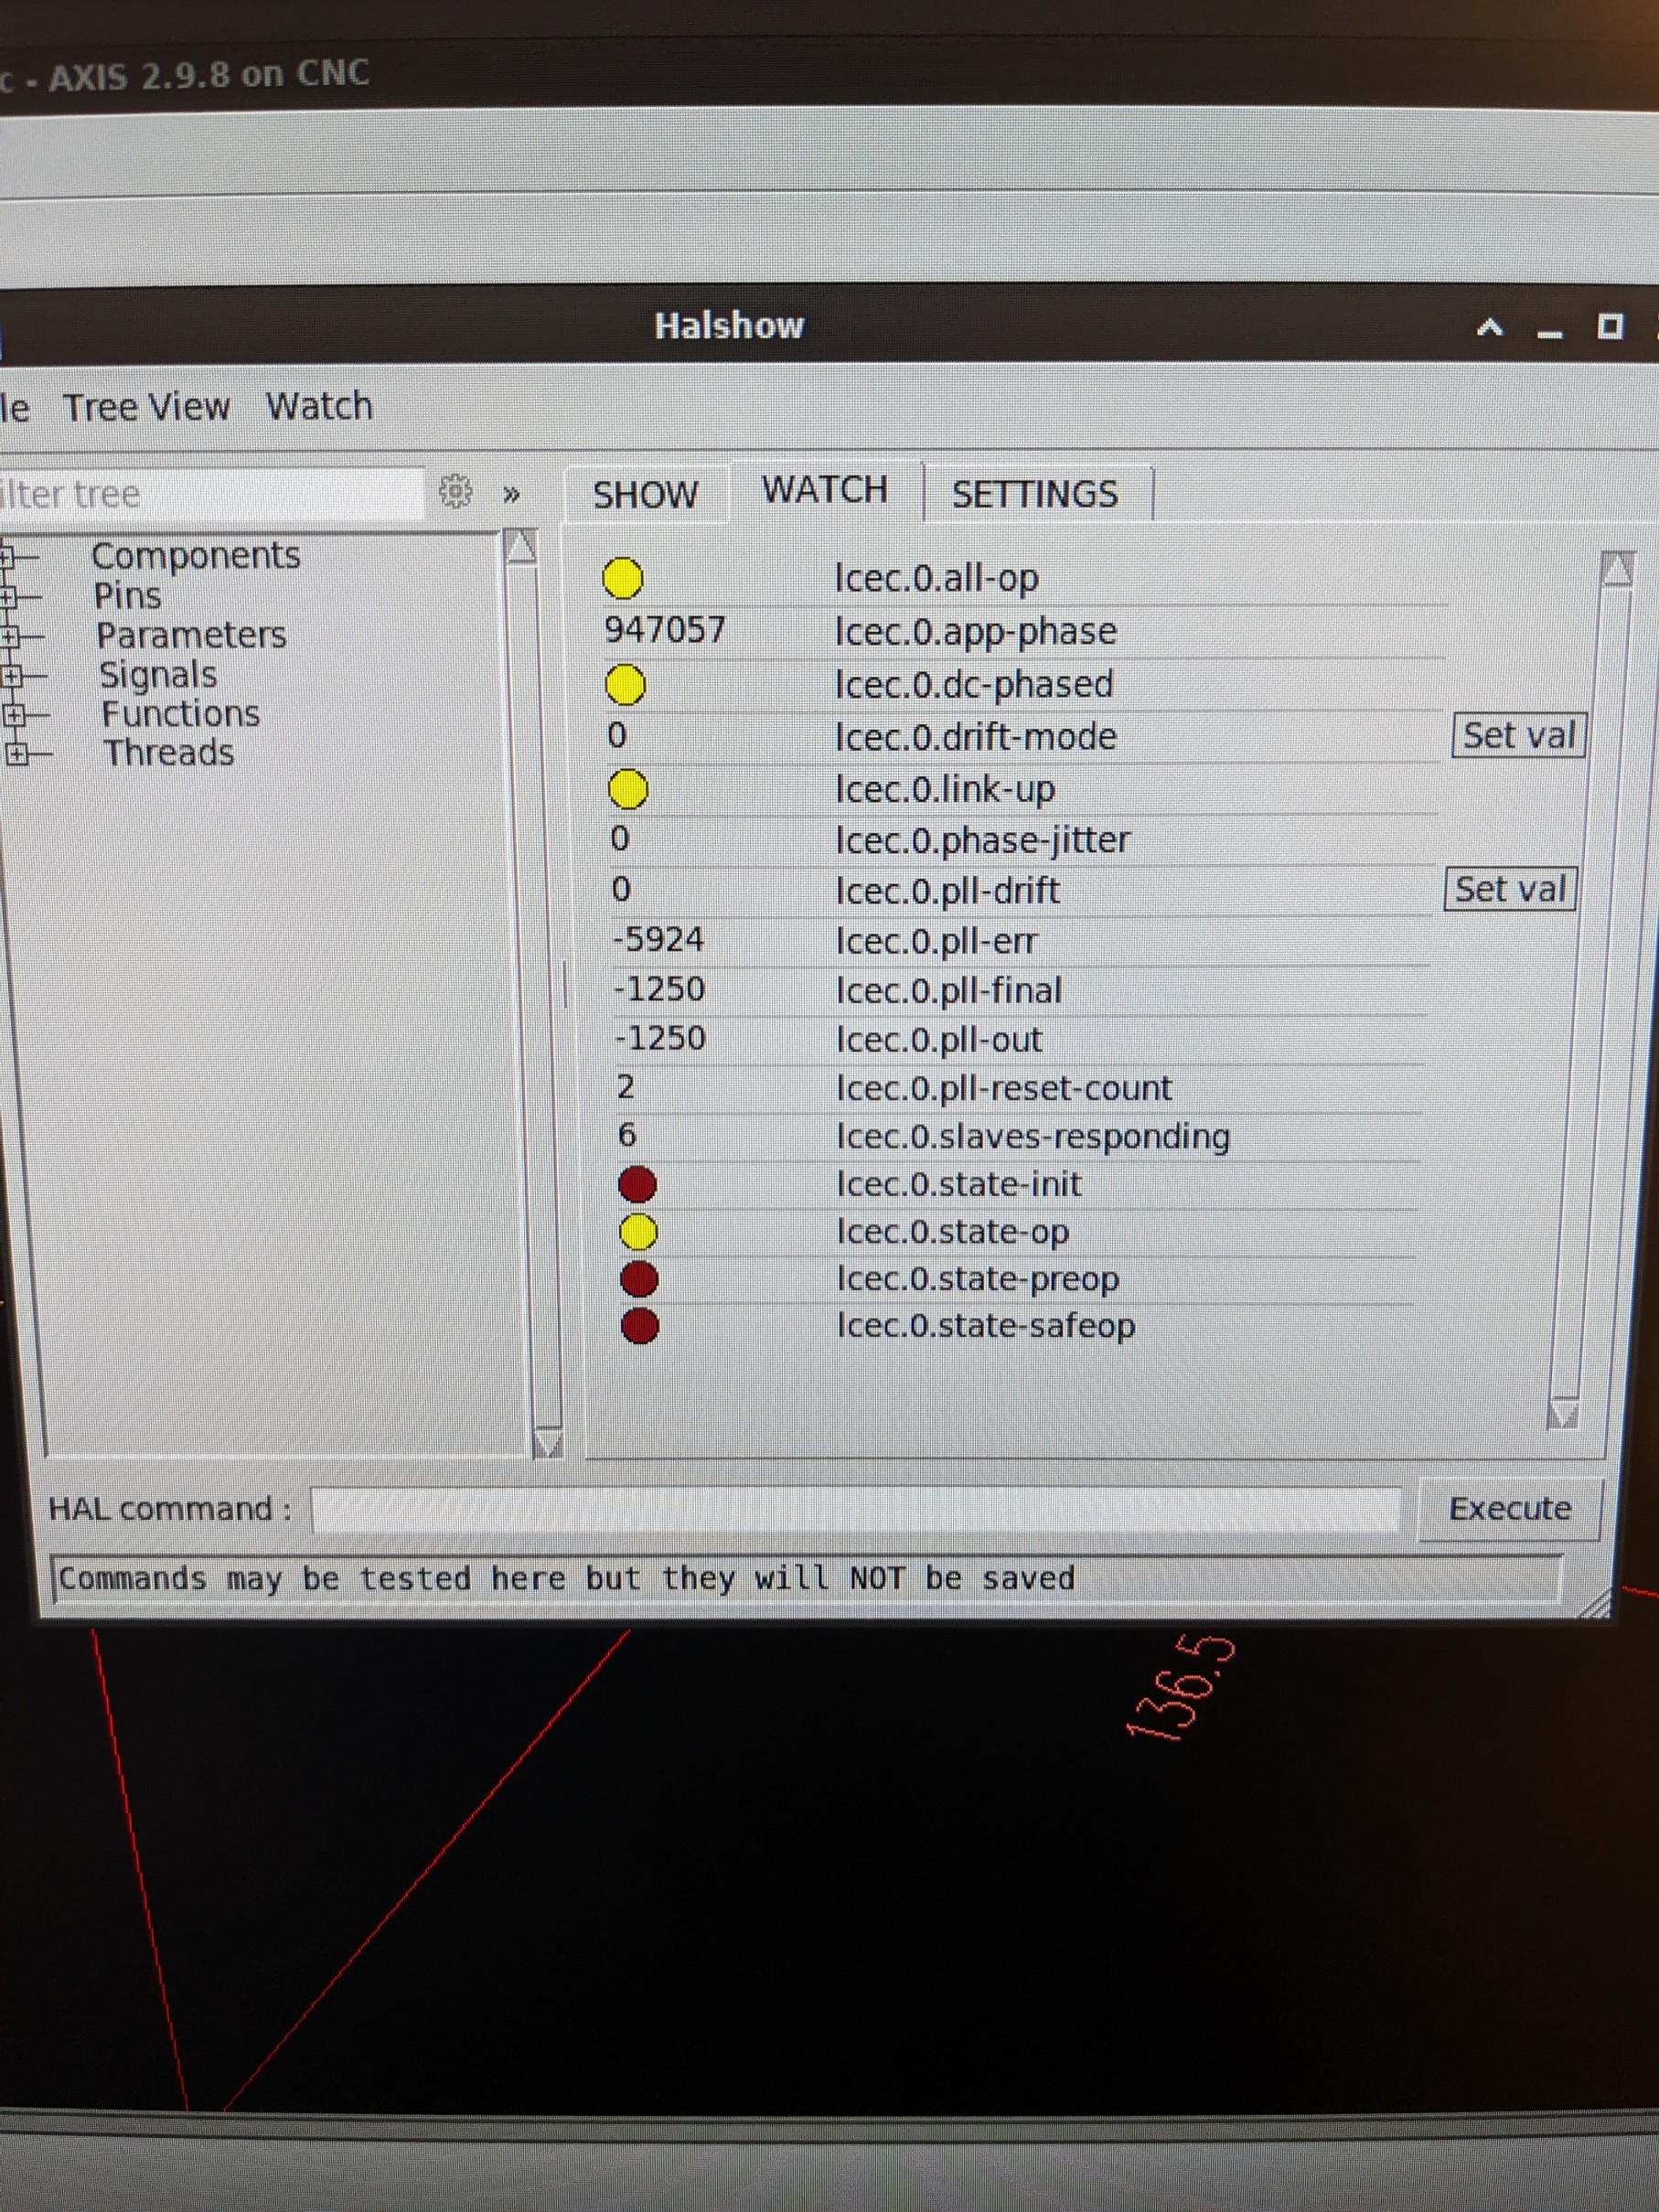
please check the value of the parameters lcec.0.pll-step
You can do so with this command
halcmd show param lcec.0.pll-step
This parameter will be set at 1000 automatically if you have RTAPI_TASK_PLL_SUPPORT
also I have updated again the repo
if you could be so kind as to download, build and test again, thank you
github.com/grandixximo/linuxcnc-ethercat
Please Log in or Create an account to join the conversation.

Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
Thats a but disappointing. Its hard to keep commitment on projects like this. Sasha lost interest and it was badly broken. At one stage, I hosted the hal driver repo briefly when I built the initial 2.9 ISO then Bjarne at etherlab did a deal with Sasha to host it direct. I gladly gave it up. Then Scott did a deal with Sasha to host it and develop it (which he did). So I did some intros and Bjarne helped Scott build workflows to send builds to the etherlab repo so it was hosted and available so that was pretty cool. I see Sasha's page says use Scotts repo and he hadn't made any commits since 2024 until a mad flurry of commits in 2026! Whatever you do etherlab will be very supportive.Honestly, waiting for Scott for some direction, he is not been replying any messages, so at the moment everything is stale, I don't really want to touch core functionality, I'm not sure about the uspace work by Sascha, should linuxcnc take that in as well? We would have to build Sasha's ethercat master as well to enable all of that. Not sure what the community needs
Please Log in or Create an account to join the conversation.