Advanced Search

Search Results (Searched for: )

  • Gartenzwerg
  • Gartenzwerg
25 Oct 2025 12:50
Replied by Gartenzwerg on topic Tipps für aktuelle LinuxCNC Hardware gesucht

Tipps für aktuelle LinuxCNC Hardware gesucht

Category: Deutsch
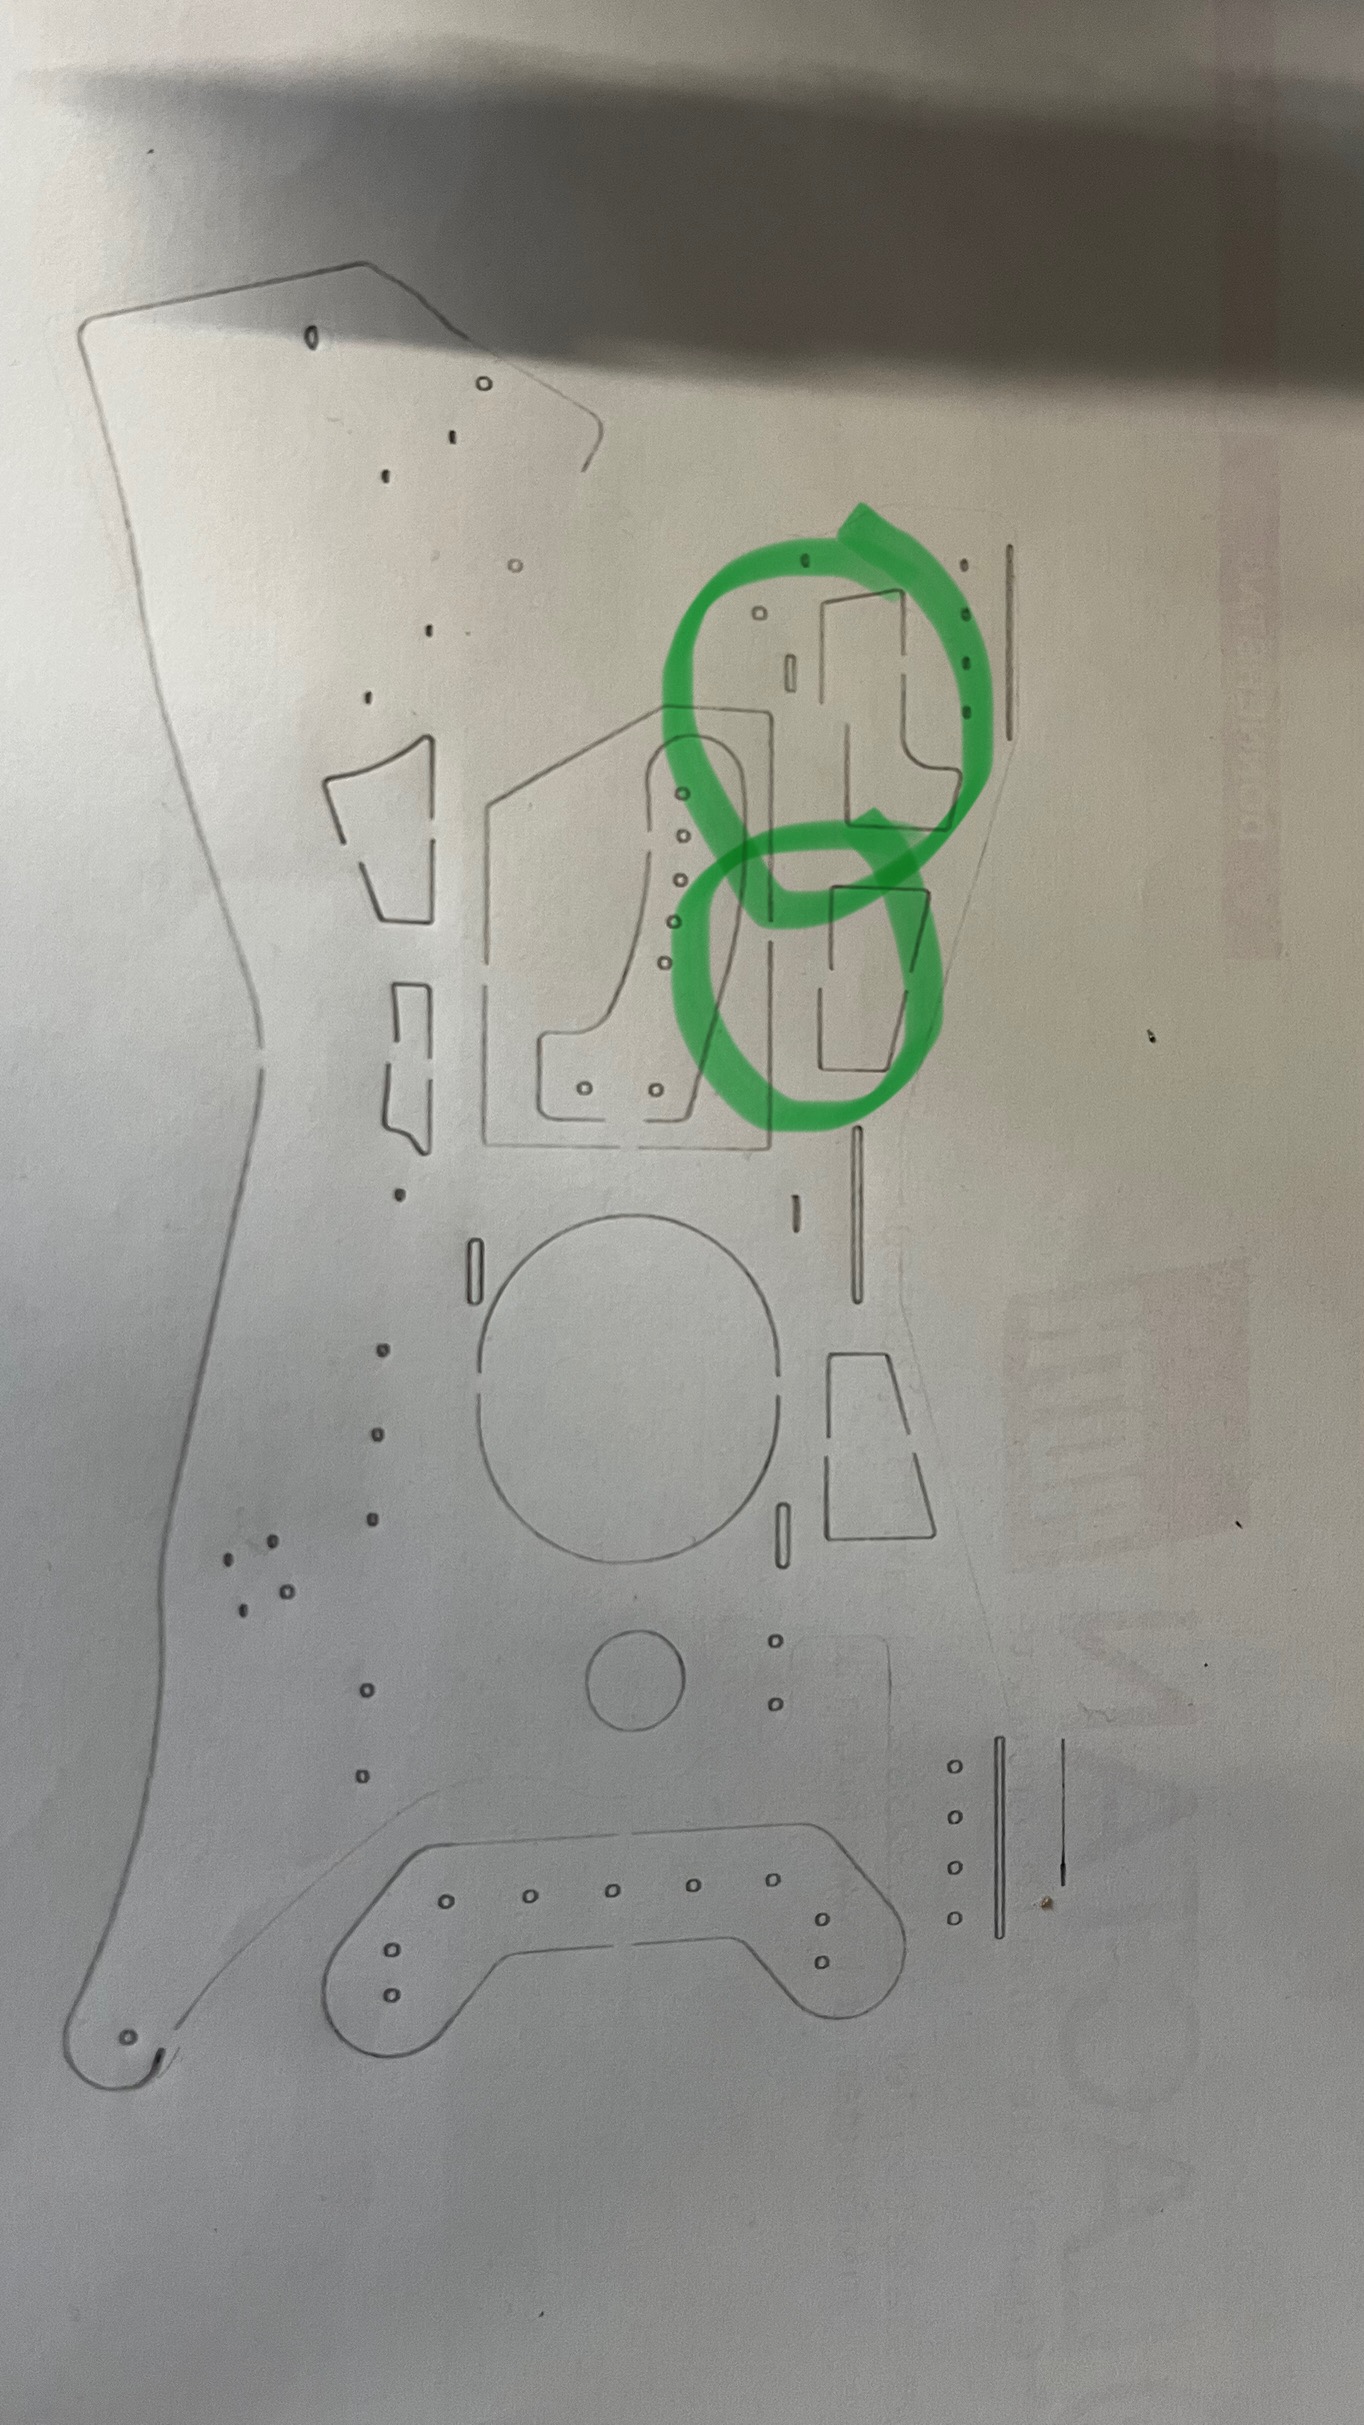
Also da hats was, ich verliere anscheinend Schritte auf Y


Wo kann ich da ansetzen?
  • SPH
  • SPH's Avatar
25 Oct 2025 12:27

Help with Delta E3 Ethercat drives - hal and ethercat-conf.xml

Category: EtherCAT

Hakan, thanks so much for taking the time to help get this working. I can switch off for the night on a high now. Lots more to do but being able to jog a drive feels like a big step forward.
  • Will_cnc
  • Will_cnc
25 Oct 2025 12:24

Stepper online A6 Servo motor as Spindle motor

Category: General LinuxCNC Questions

I have a Stepperonline 1000W servo motor with an EtherCAT servo drive, which I intend to use as a temporary spindle motor until I can upgrade to a higher-power unit.
Currently, I have three axes configured to work with Leadshine servo drives via EtherCAT.How can I configure this servo motor to function as a spindle motor?
Specifically, what needs to be added or modified in the following configuration files:
.INI  
.HAL.  
.XML
I’ve tried setting it up based on information from other forum posts, but I haven’t had much success so far.
  • SPH
  • SPH's Avatar
25 Oct 2025 12:22

Help with Delta E3 Ethercat drives - hal and ethercat-conf.xml

Category: EtherCAT

Ah, so simple. I've been committing the cardinal sin of making multiple changes at once.
Up and running again and OH YEAH! Got motor motion! Although I must admit I'm a bit unsure what's changed to make it start working...
  • matasbuk
  • matasbuk
25 Oct 2025 12:16

LinuxCNC randomly crashes reportedly due to Python bug

Category: Advanced Configuration

Hi,

do you perhaps now if this whole problem is now solved in the master branch or should I compile LCNC with the changes mentioned above to fix the problem?
  • Hakan
  • Hakan
25 Oct 2025 12:13

Help with Delta E3 Ethercat drives - hal and ethercat-conf.xml

Category: EtherCAT

This one
check_config:
INCONSISTENT coordinates specifications:
trivkins coordinates=X
[TRAJ]COORDINATES=XZ

That is a line in the ini file
KINEMATICS = trivkins coordinates=X
should be XZ
  • SPH
  • SPH's Avatar
25 Oct 2025 12:10 - 25 Oct 2025 12:13

Help with Delta E3 Ethercat drives - hal and ethercat-conf.xml

Category: EtherCAT

Ah, yep, stupid simple. I'd been going back and forward for about an hour trying to figure that out.

One step forward, two steps back. Now throwing the error:
[code][code]Error report created by /usr/lib/tcltk/linuxcnc/show_errors.tcl:

Print file information:
RUN_IN_PLACE=no
LINUXCNC_DIR=
LINUXCNC_BIN_DIR=/usr/bin
LINUXCNC_TCL_DIR=/usr/lib/tcltk/linuxcnc
LINUXCNC_SCRIPT_DIR=
LINUXCNC_RTLIB_DIR=/usr/lib/linuxcnc/modules
LINUXCNC_CONFIG_DIR=
LINUXCNC_LANG_DIR=/usr/lib/tcltk/linuxcnc/msgs
INIVAR=inivar
HALCMD=halcmd
LINUXCNC_EMCSH=/usr/bin/wish8.6
LINUXCNC - 2.9.4
Machine configuration directory is '/home/cnc/linuxcnc/configs/linuxcnc_leadshine_EL8'
Machine configuration file is 'EL8_machine.ini'
INIFILE=/home/cnc/linuxcnc/configs/linuxcnc_leadshine_EL8/EL8_machine.ini
VERSION=1.1

check_config:
INCONSISTENT coordinates specifications:
trivkins coordinates=X
[TRAJ]COORDINATES=XZ

PARAMETER_FILE=linuxcnc.var
TPMOD=
HOMEMOD=always_homed
TASK=milltask
HALUI=halui
DISPLAY=axis
COORDINATES=XZ
KINEMATICS=trivkins coordinates=X
Starting LinuxCNC...
Starting LinuxCNC server program: linuxcncsvr
Loading Real Time OS, RTAPI, and HAL_LIB modules
Starting LinuxCNC IO program: io
emc/iotask/ioControl.cc 786: can't load tool table.
Starting HAL User Interface program: halui
linuxcnc TPMOD=tpmod HOMEMOD=always_homed EMCMOT=motmod
Found file(REL): ./EL8_machine.hal
Starting TASK program: milltask
Starting DISPLAY program: axis
Shutting down and cleaning up LinuxCNC...
task: 103 cycles, min=0.000008, max=0.010081, avg=0.008640, 0 latency excursions (> 10x expected cycle time of 0.010000s)
@@@always_homed.comp:extra_setup: home_parms=no_home_parms

!!!always_homed.comp: Skeleton Homing Module

Removing HAL_LIB, RTAPI, and Real Time OS modules
Removing NML shared memory segments

Debug file information:
Note: Using POSIX realtime
note: MAXV max: 50.000 units/sec 3000.000 units/min
note: LJOG max: 50.000 units/sec 3000.000 units/min
note: LJOG default: 2.500 units/sec 150.000 units/min
Traceback (most recent call last):
File "/usr/bin/axis", line 3655, in <module>
ja_id = aletter_for_jnum(jnum)
^^^^^^^^^^^^^^^^^^^^^^
File "/usr/bin/axis", line 3642, in aletter_for_jnum
return trivkinscoords.upper()[jnum]
~~~~~~~~~~~~~~~~~~~~~~^^^^^^
IndexError: string index out of range
6055
6087
Stopping realtime threads
Unloading hal components
Note: Using POSIX realtime

Files attached. [/code][/code]
Displaying 12346 - 12352 out of 12352 results.
Time to create page: 0.792 seconds
Powered by Kunena Forum