Search Results (Searched for: )

  • Marcos DC
04 Mar 2026 06:12
Hi nwe,

That would be extremely helpful, thank you for offering to test.

No rush at all if it takes a couple of days — I will actually be working in the field for the next two days doing maintenance for a client. When I get back, I plan to implement the safety gate component and the decouple/recouple logic, so the timing works out well.

To prepare proper adapter templates for your two drives (the Lichuan OL57E-4A and the Stepperonline A6-750EC), I just need a few details from your setup so I can map the HAL pins correctly.

If possible, could you share:
1. Your LCEC configuration
• lcec.conf (or equivalent configuration file)
• The EtherCAT XML/ENI if you have it
• Or a snippet of the HAL where the lcec.* pins for the drives appear
2. PDO mapping
I mainly need to confirm the HAL pins for the standard CiA402 objects:
• 6040 Controlword
• 6041 Statusword
• 6060 Modes of Operation (command)
• 6061 Modes of Operation Display
If available in PDO as well:
• 6064 Position Actual Value
• 607A Target Position
3. Homing
• Which homing method (object 6098) you plan to use
• Whether the homing/limit switches are connected to the drive inputs
• The HAL pin names for those inputs (for example lcec.*.din-*)
4. Quick Stop
• Is Quick Stop (Controlword 0x0002) configured and usable on these drives?
• Or do they require a different shutdown sequence?
5. Anything unusual
• Any known quirks with enable, fault reset, or homing behavior.

With that information I can prepare two adapter templates (one for each drive) that plug into the CiA402 semantic layer we validated in simulation.

Thanks again for offering to test — having real hardware feedback will be extremely valuable.
  • arijitdutta
04 Mar 2026 05:40
Replied by arijitdutta on topic Lathe Bed Wear Compensation
thats pretty negligible to what i have. mine is far far worse. will share as soon as i get to my shop.
  • meister
04 Mar 2026 05:33
This issue originated from LinuxCNC and occurred nine times within ~30 minutes.

not sooo bad
  • rodw
04 Mar 2026 05:26
not knowing how you print your message but how much of your main loop taken up by printing your message? It might not be as bad as you think.
Maybe an exercise for halstreamer?
  • Red_D85
04 Mar 2026 05:20
Replied by Red_D85 on topic Maho MH-400 Retofit
Ja der alte Motor ist bereits Entsorgt. Ich war Überrascht über seine Leichtgängigkeit und seinem geringen Gewicht. Für das Alter. Hab ich mir anders vorgestellt. Ja der neue Servo hat selbstverständlich einen Encoder. Ich werde mal sehen was das Umkehrspiel sagt. Aber Früher hat es ja auch funktioniert. Wieso jetzt nicht mehr? Für gröbere Arbeiten sollte es nach wie vor reichen.
  • PCW
04 Mar 2026 03:35
Replied by PCW on topic Extract a specific bit from hex value
The" bitslice" hal component is one way.

 
  • COFHAL
04 Mar 2026 01:17
Is there a way to extract a specific bit from a hexadecimal value? The VFD I'm using indicates the state with a 16-bit hexadecimal value, and therefore I need to extract that bit to use it within my configuration.
  • ihavenofish
04 Mar 2026 00:31
Replied by ihavenofish on topic motion channels for robotic atc library
So we have wound up with a simple little 3 axis cartesian robot. Robot basically has a spindle taper and air powered gripper, and then hands off to a switcher arm that will be moved by the little robot with a roller cam. 


I will probably build this in april, then we can see if it can live inside the master linuxcnc or needs a separate controller.

So the run down:

- X, Y, Z linear motion.
- gripper air cylinder.

1: Robot on its own goes to grab the next tool needed by the machine, and places it in the arm SLOT A
2: M6 Tx called
3: Robot uses cam to move arm out into position. Door opens on the same linkage (we could also do this with air)
4: Machine moves to tool change arm and places the tool in SLOT B
5: Then it grabs the tool in SLOT A and moves away from the arm

Basically the main control sees the atc as a stationary rack type with only 2 tools

6: The arm retracts in and door closes
7: Machine resumes cutting
8: The robot takes the tool from SLOT B and puts it back in the right pocket
9: Robot grabs the next tool in the program and we repeat everything again

Make sense?
  • persei8
03 Mar 2026 23:23
The new version of qtdragon at  github.com/persei802/QtDragon_hd has the ability to semi-automate tool measurements. I'm open to suggestions for improvements.
Jim
  • PCW
03 Mar 2026 22:06 - 03 Mar 2026 22:07
Replied by PCW on topic Trying to set up position control mode
setp [HMOT](CARD0).stepgen.00.control-type 0

Is wrong, it should be:

setp [HMOT](CARD0).stepgen.00.control-type 1

(for all joints)

 
  • spumco
03 Mar 2026 21:14
Replied by spumco on topic Stepperonline A6 etherCAT servo kit anyone?

The are not Inovance, they are Jssmotors, as you can see in this link:

www.jssmotor.com/servo-system
You are absolutely right.  Earlier post edited - thanks.
  • matasbuk
03 Mar 2026 20:51
Replied by matasbuk on topic Lathe Bed Wear Compensation
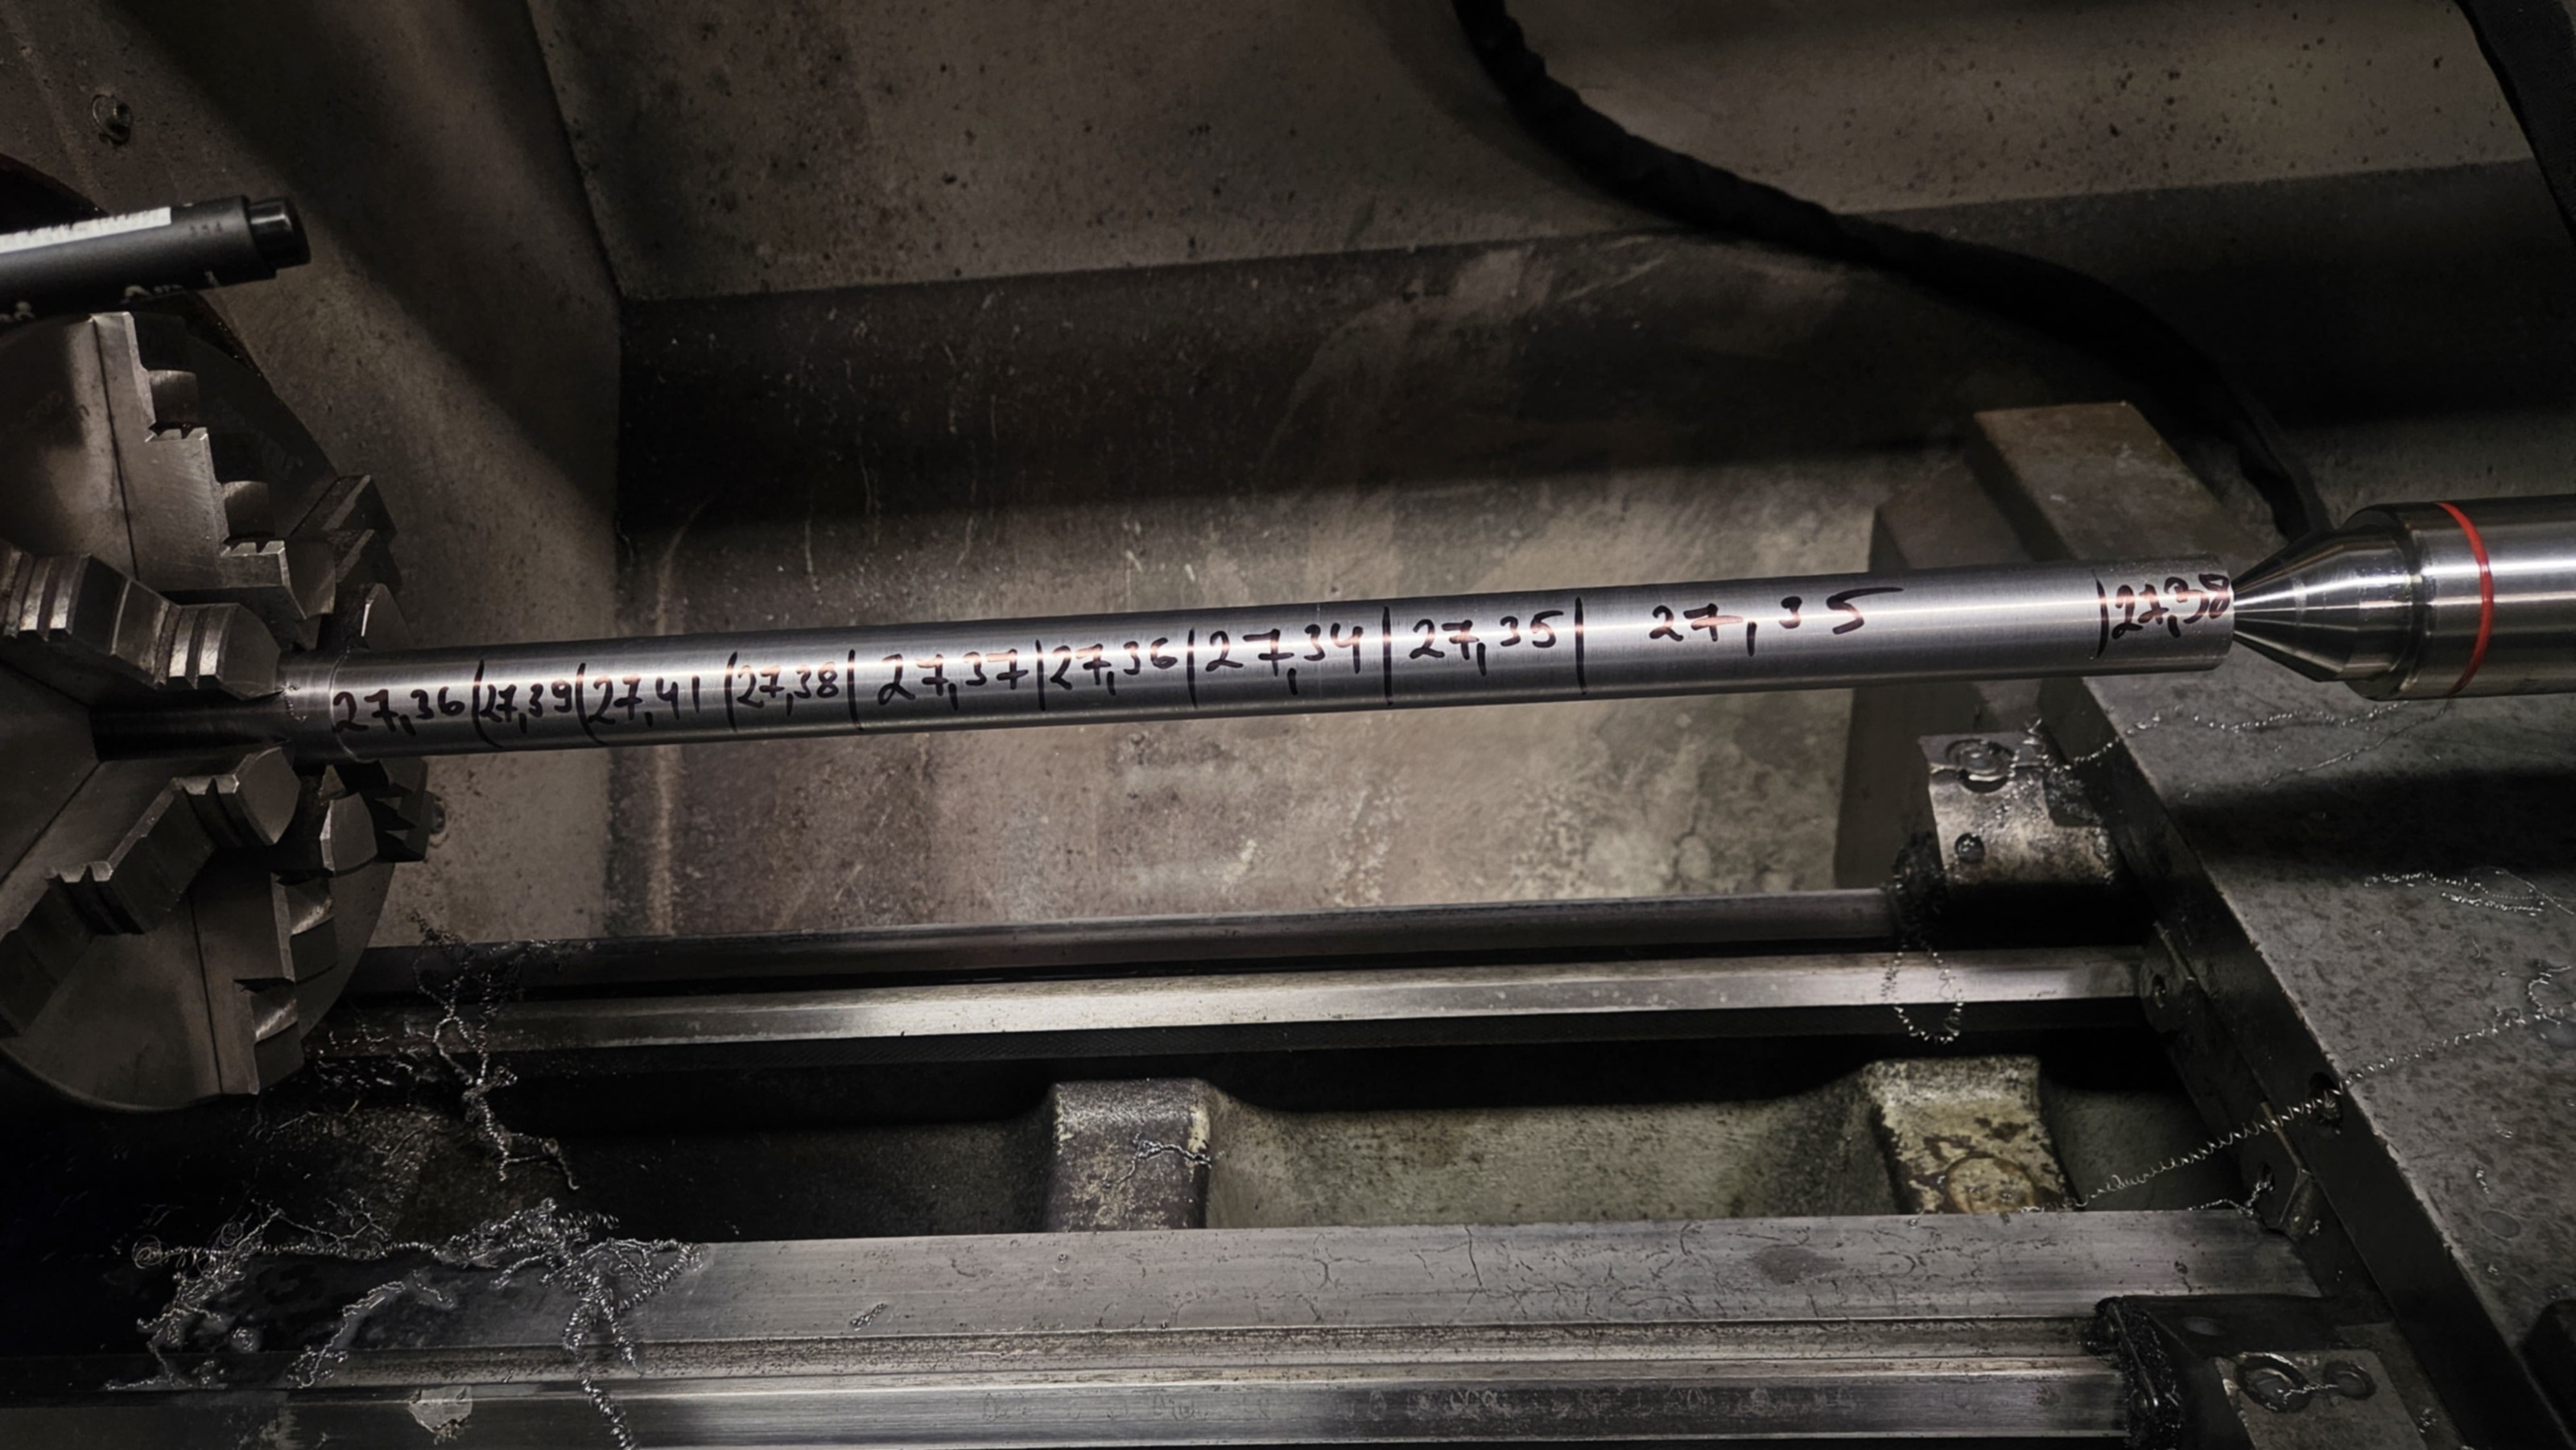
Its about 0.17mm along the whole Z axis. Mostly near the chuck as always. Could you perhaps share a bit of what you had done? Attaching the picture of my bed wear. 
  • PCW
03 Mar 2026 20:14
Replied by PCW on topic 7i92T and mx3660 request for help
Pretty sure that if  you have combined home/limit switches you will need a
HOME setting that's away from the switch actuation point or the ON LIMIT
errors are guaranteed.
 
  • tommylight
03 Mar 2026 19:57
OK, so the only solution seems to be the timedelay/oneshot version, where it would command the tool change always in the same direction (not sure if ABS component helps), does need a bit of hal wizardry, but i am out of ideas for now on how exactly to achieve that.
  • tommylight
03 Mar 2026 19:54
Replied by tommylight on topic Trying to set up position control mode
From a very quick and short glance, what is this
setp axis.x.jog-accel-fraction 0.3
doing inside the hal file?
Probably not the exact issue, as i still think there is something terribly wrong with the wiring, but the symptoms are not that clear cut to be able to pinpoint.
Check with scope how the signal between signal pins on Mesa and drive look in relation to gnd and machine/box ground look, might be ground interference at 50 or 60Hz causing it.
Displaying 6376 - 6390 out of 11906 results.
Time to create page: 0.452 seconds
Powered by Kunena Forum