
- Posts: 37
- Thank you received: 10
New Trajectory Planner - Testers/programs wanted
- rellenberg
- Offline
- Junior Member
-

Less
More
12 years 9 months ago #43162
by rellenberg
Replied by rellenberg on topic New Trajectory Planner - Testers/programs wanted
Based on feedback from the dev list, it may be difficult to fully optimize the last segment, since the TP doesn't know when a program is done, vs. just waiting on more commands. However, one workaround to this is to make your last move of the program a rapid retract away from the part. Since the last step in the part is no longer the last step in the program, you'll still get a smooth cut.
As for the homing issue, I don't think I've seen any violations myself, but I haven't been specifically looking for them during homing. My simulation configs have the homing process cut short, because I got tired of waiting 5-10 seconds every time I loaded the GUI. Nothing that I've changed in this branch should directly affect homing, but it's always possible there are unintended consequences.
As for the homing issue, I don't think I've seen any violations myself, but I haven't been specifically looking for them during homing. My simulation configs have the homing process cut short, because I got tired of waiting 5-10 seconds every time I loaded the GUI. Nothing that I've changed in this branch should directly affect homing, but it's always possible there are unintended consequences.
Please Log in or Create an account to join the conversation.
- Rick G
- Offline
- Junior Member
-
Less
More
- Posts: 27
- Thank you received: 114
12 years 9 months ago #43190
by Rick G
That may not have been clear, I meant with the original TP and the new TP the results are the same.
I added another arc to the end, but did not see an improvement.
Rick G
Replied by Rick G on topic New Trajectory Planner - Testers/programs wanted
As a side note auto homing seems to ignore the acceleration settings on some moves in both cases.
That may not have been clear, I meant with the original TP and the new TP the results are the same.
I added another arc to the end, but did not see an improvement.
Rick G
Please Log in or Create an account to join the conversation.
- skunkworks
- Offline
- Moderator
-

Less
More
- Posts: 351
- Thank you received: 153
12 years 9 months ago #43237
by skunkworks
Replied by skunkworks on topic New Trajectory Planner - Testers/programs wanted
You are still not clear... 
The homing should be exactly the same as they are simple moves (no blending...)
sam
The homing should be exactly the same as they are simple moves (no blending...)
sam
Please Log in or Create an account to join the conversation.
- skunkworks
- Offline
- Moderator
-
Less
More
- Posts: 351
- Thank you received: 153
12 years 9 months ago - 12 years 9 months ago #43239
by skunkworks
Replied by skunkworks on topic New Trajectory Planner - Testers/programs wanted
I posted this on the list - but what the heck - I like redundancy...
This is the above program with a lead-in, out path..
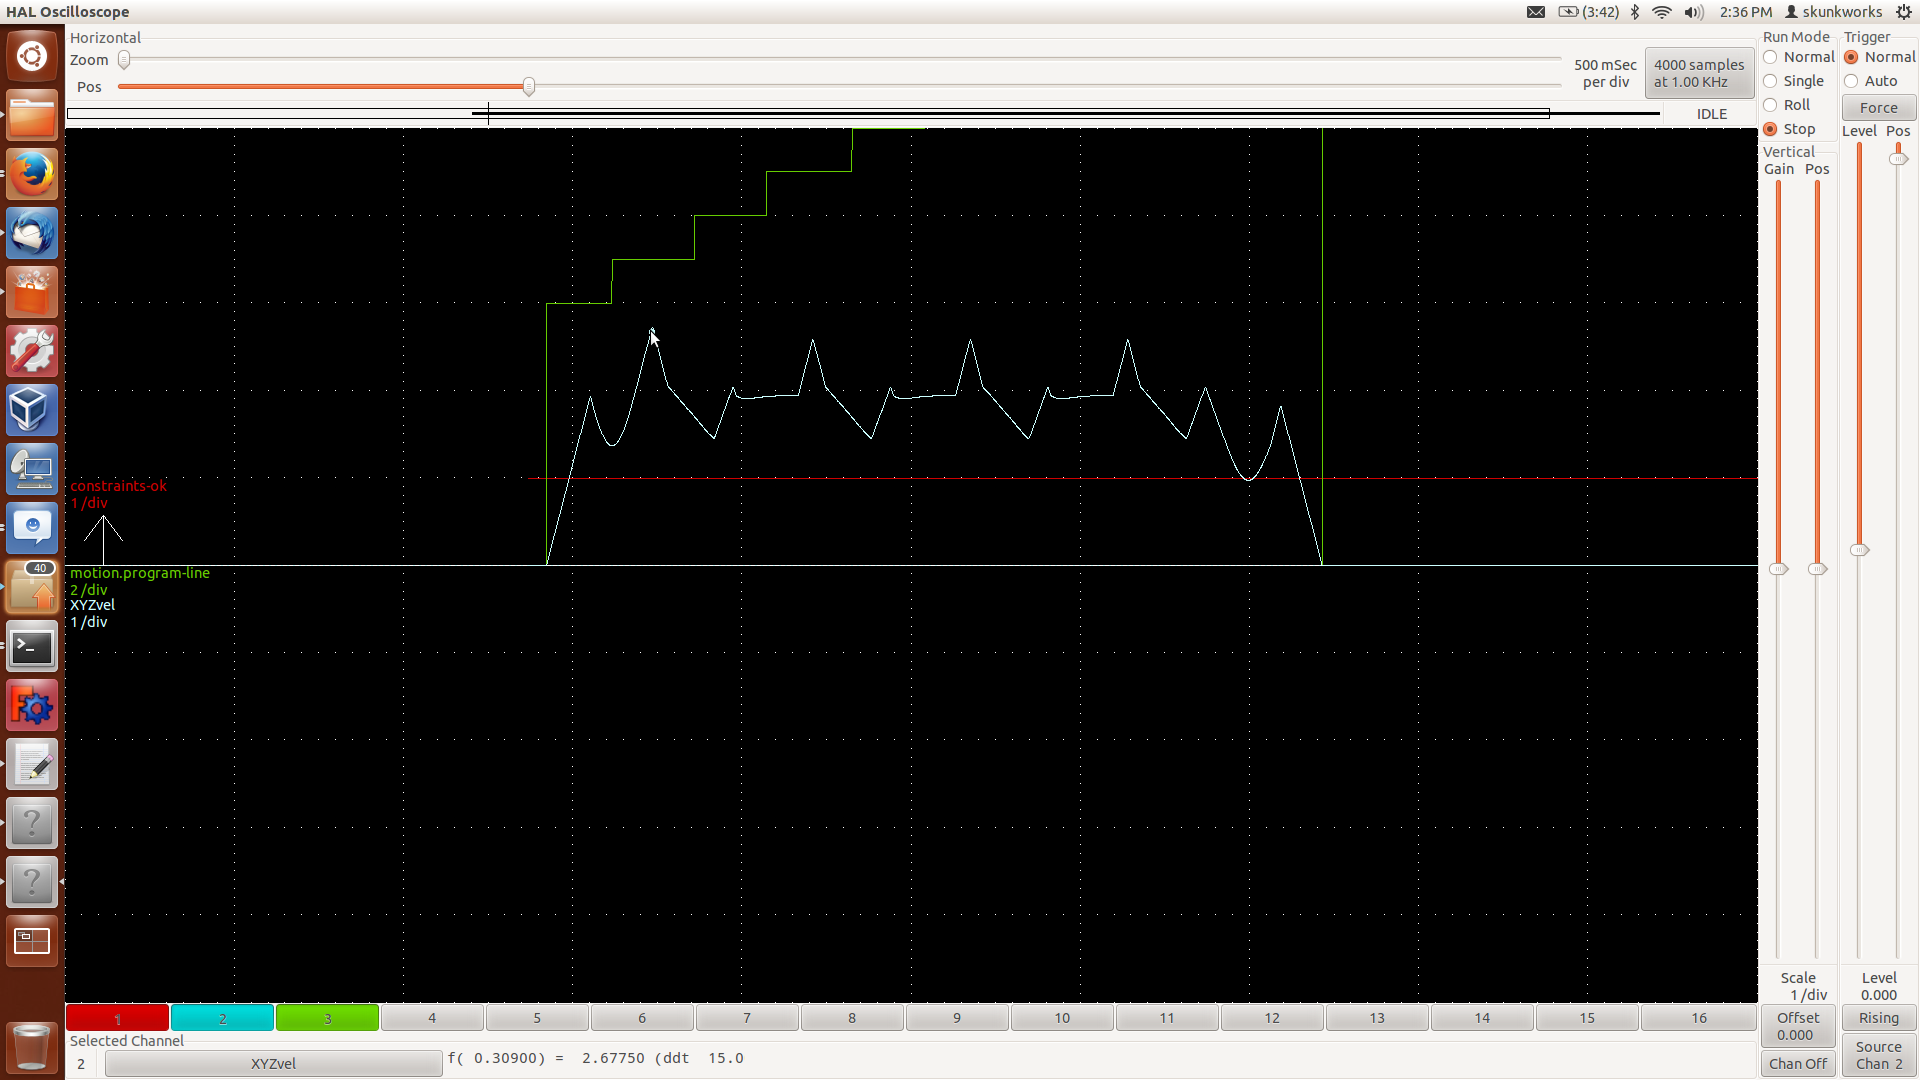
Current TP strait G64 - peaks at 159ipm
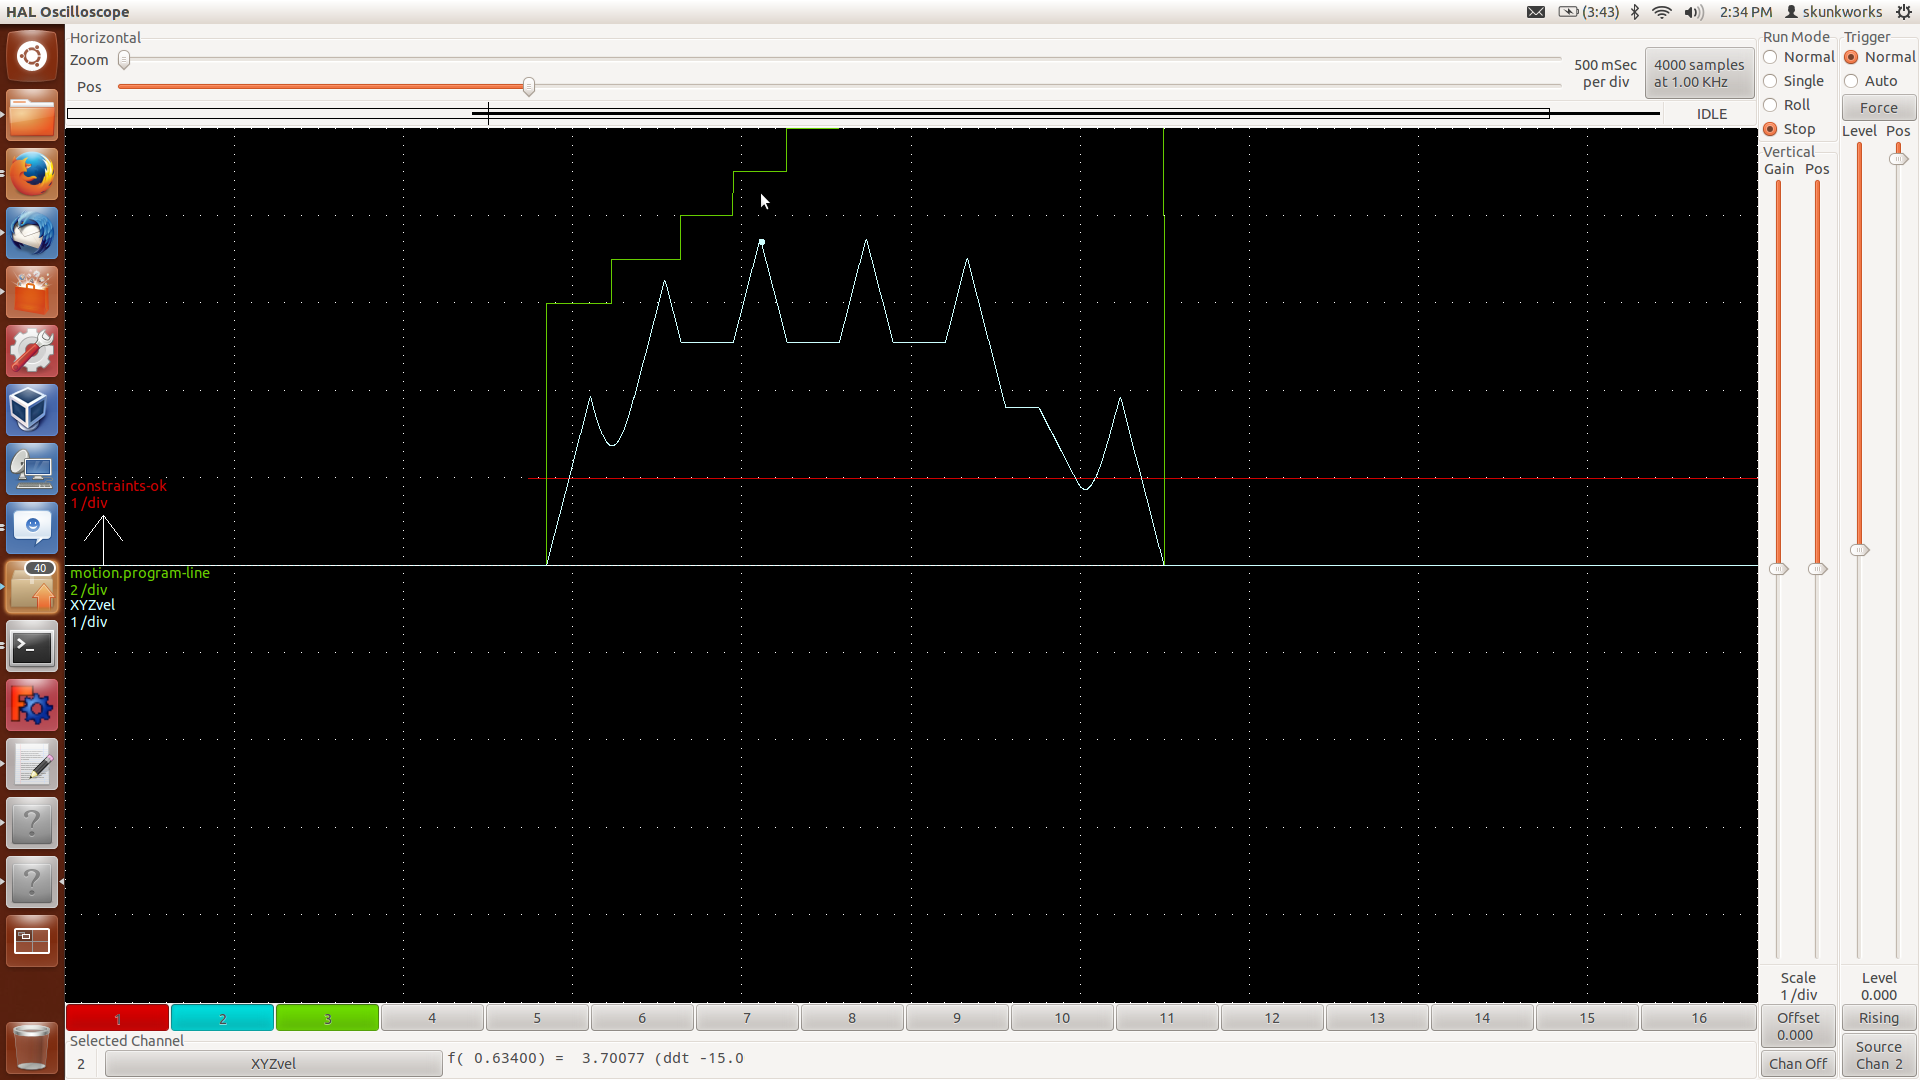
New TP strait G64 - peaks at 222ipm
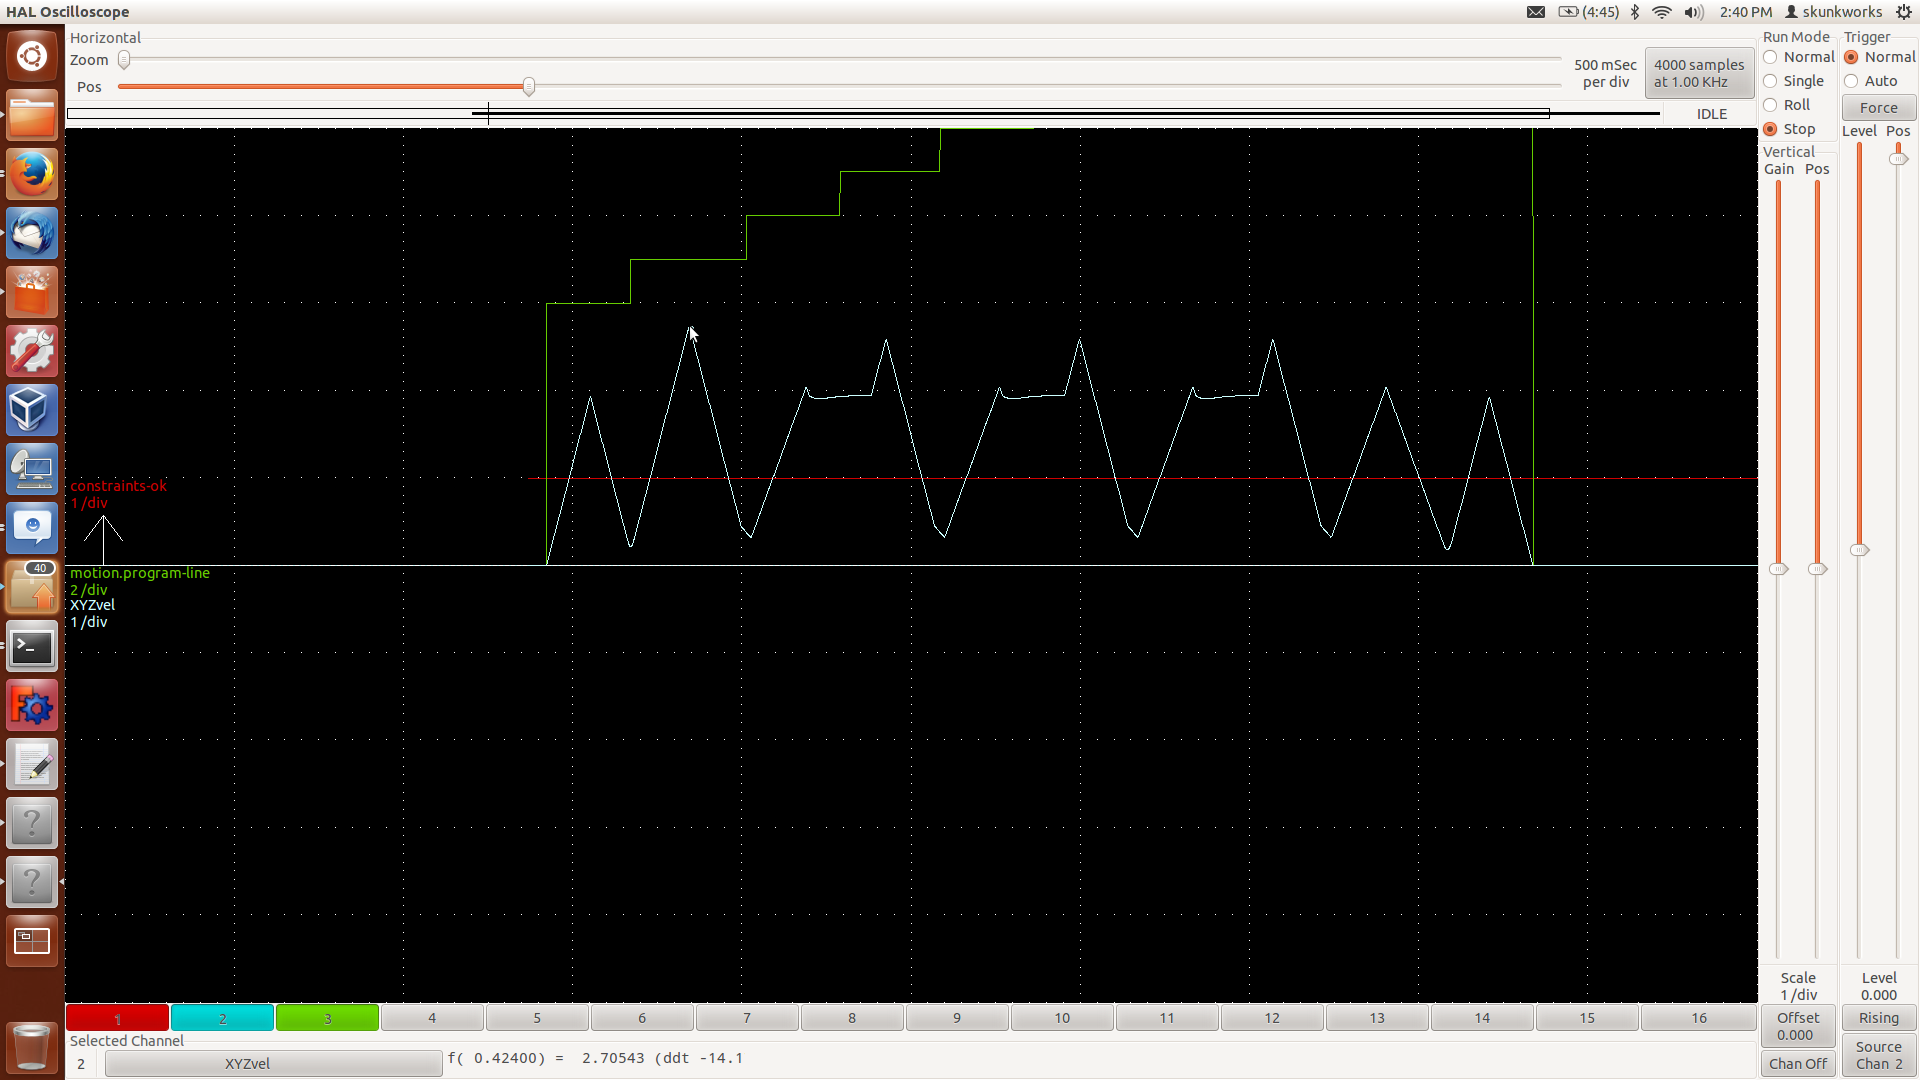
Current TP G64P.001Q.001
New TP G64P.001Q.001

This is the above program with a lead-in, out path..
Current TP strait G64 - peaks at 159ipm
New TP strait G64 - peaks at 222ipm
Current TP G64P.001Q.001
New TP G64P.001Q.001
Last edit: 12 years 9 months ago by skunkworks.
Please Log in or Create an account to join the conversation.
- DaBit
- Offline
- Elite Member
-

Less
More
- Posts: 203
- Thank you received: 19
12 years 9 months ago #43240
by DaBit
Replied by DaBit on topic New Trajectory Planner - Testers/programs wanted
I haven't done that much milling lately and then only simple, non-short-segment stuff, but so far I haven't noticed strange issues with the new TP. Where the old TP would do an audible slow down/accelerate on segment to segment boundaries the new TP just continues.
Can I switch TP behaviour between old/new while running a program by setting a HAL pin/parameter or so?
Can I switch TP behaviour between old/new while running a program by setting a HAL pin/parameter or so?
Please Log in or Create an account to join the conversation.
- skunkworks
- Offline
- Moderator
-
Less
More
- Posts: 351
- Thank you received: 153
12 years 9 months ago #43243
by skunkworks
Replied by skunkworks on topic New Trajectory Planner - Testers/programs wanted
I don't think so - they are ini settings...
DaBit wrote: I haven't done that much milling lately and then only simple, non-short-segment stuff, but so far I haven't noticed strange issues with the new TP. Where the old TP would do an audible slow down/accelerate on segment to segment boundaries the new TP just continues.
Can I switch TP behaviour between old/new while running a program by setting a HAL pin/parameter or so?
Please Log in or Create an account to join the conversation.
Time to create page: 0.144 seconds