Thanks for the welcome!
"First are you driving the servos with step/DIR signals"
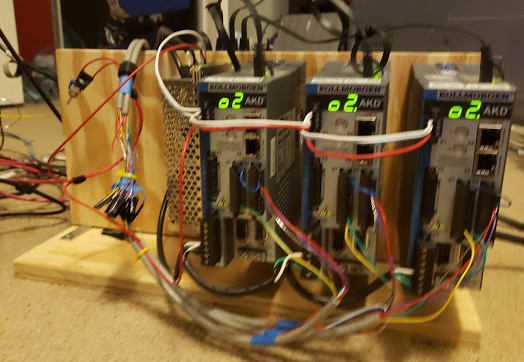
Yes I am, I know this is not ideal, I am sacrificing a lot of the high performance drive loops as well as the 24bit feedbacks on the motors. But since this is my first attempt at anything cnc or linux, I thought this would be a good baby step.
I had pre-emptively bought a 7i92M board as i had planned to run this on a laptop without a parallel port - but i couldn't get the RT latency test to get under 300us (despite it being a pretty high performance laptop it had intermittent spikes i couldn't nail down).
I did stumble on some posts about someone having a branch of LinuxCNC supporting EtherCat - which would be the logical next step since I can configure these servo drives for nearly any industry fieldbus (ECat, CAN, Profinet, EthernetIP, and SynqNet).
But like I said, baby steps...
As for the Kinematics; "good place to start"
I stumbled upon the thread you mentioned already along with the nice deltakins.c code which looks perfect. However I couldn't figure out what to do with it.
I also stumbled upon this thread which seemed eerily similar to my troubles:
forum.linuxcnc.org/24-hal-components/327...matics-again?start=0
He also was encouraged to pull the master 2.8 version instead of the released stable version of 2.7.
Is this what you are alluding to with your reference of
MASTER 2.8?
While being a seasoned Windows slave/developer and embedded developer for the better part of 2 decades, I've never even dipped a toe in Linux development so I don't even know where to start (it took me a few frustrating nights to figure out how to get linux switched to a RT kernel and run the latency test to pass well with boot modifications).
I have't been able to find a step-by-step guide to compiling the deltakins and installing it/using it.
Is this setup/structure significantly different/easier in the master build 2.8?