

- Posts: 105
- Thank you received: 13
caxis.comp status
2 years 9 months ago #290865
by jpg
Replied by jpg on topic caxis.comp - problems
hello, I check regularly to see your progress, I'd like to help you, but unfortunately I don't have your linux skills, I admire your work.
Please Log in or Create an account to join the conversation.

2 years 9 months ago #290882
by spumco
On a happy note... there was a breakthrough late last night and everything seems to be working rather nicely. I'll post some details later.
Replied by spumco on topic caxis.comp - problems
Kind of you, but the reality is that I have no linux skills. I substitute bloody-minded persistence for actual knowledge.hello, I check regularly to see your progress, I'd like to help you, but unfortunately I don't have your linux skills, I admire your work.
On a happy note... there was a breakthrough late last night and everything seems to be working rather nicely. I'll post some details later.
The following user(s) said Thank You: smc.collins
Please Log in or Create an account to join the conversation.
2 years 9 months ago #290925
by spumco
Replied by spumco on topic caxis.comp - problems
Adding some "D" made a huge difference.
I also confirmed that, at least in my config, rotary axis values are in degrees per minute, not seconds. Needed to bump all the values way up before the C-axis performed properly.
So the basic scheme is:
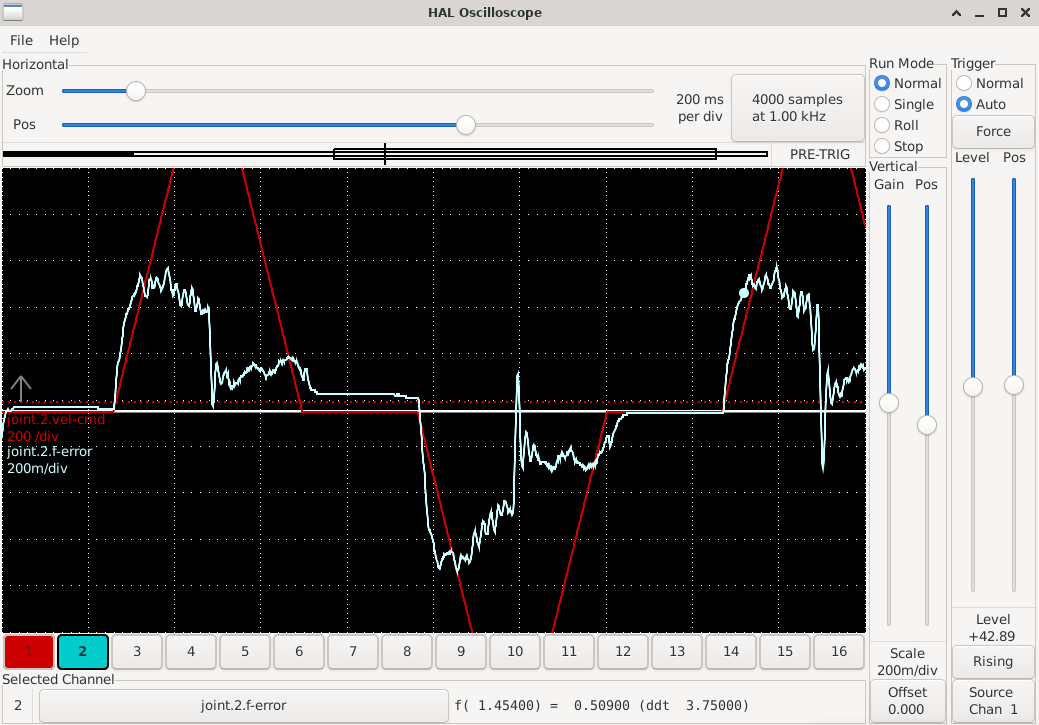
Latest halscope below during a G0 C0, G0 C360 tuning program.
I also confirmed that, at least in my config, rotary axis values are in degrees per minute, not seconds. Needed to bump all the values way up before the C-axis performed properly.
So the basic scheme is:
- Home C-axis first
- If it isn't homed, a spindle command will result in a following error after stopping the spindle
- C-axis remains enabled until a spindle command is given
- Can jog, MDI, and G-code the c-axis with no issues.
- Spindle command works both directions, and RPM is +/- 10rpm according to the encoder.
- Accel/decel are aggressive but smooth
- Can go M3 to M4 with no pauses or issues
- M5 - spindle stops, then rapids to the last c-axis position prior to engaging the spindle
- No unwinding, the return move is always <360 degrees
- G-code
- No problems running a program with both spindle and c-axis moves in it
- C-axis PID could still use some tuning but I'm not sure what else to do.
- It goes where it's supposed to and doesn't get out of control... but I there's too much oscillation during homing or during the automatic return-to-last-position when the spindle is stopped.
- I've had to set the joint/axis ferror & min_ferror pretty high, otherwise it vomits during homing.
- No way to unlock the servo spindle unless I disable the servo enable-in signal.
- If I disable the spindle, upon re-enable it rapids back to the prior position
- Rotating the spindle a few revs by hand trips the following error (simulating a 4-jaw chuck)
- I need to think about how to disable the f-error when the spindle enable is de-asserted
- Jogging
- MPG jog required a scale comp to be added to compensate for degrees vs. ipm. It was way too fine at the standard 0.0001/.001/.01 increments, so I bumped it by 100 for the c-axis.
- Continuous jogging needs some work. Reasonable linear jog speeds (10-100ipm) are painfully slow in degrees/min. Due to my particular config I'm going to have to fiddle a bit. My jog-speed pot sets the speed for all axis/joint continuous jogs... I may have to split the rotary axis out and scale it. Not insurmountable.
- Caxis.comp appears to only permit a single instance
- I tried to set up my sub-spindle as a B-axis tonight but LCNC errored out when created a second caxis.comp instance.
- 'addf failed' was the error message. No variation of names= or counts= worked.
Latest halscope below during a G0 C0, G0 C360 tuning program.
Please Log in or Create an account to join the conversation.
2 years 9 months ago #290926
by spumco
Replied by spumco on topic caxis.comp - problems
Current (working) PID values:
MAX_VEL = 2880
MAX_ACCELERATION = 15000
P = 85
I = 50
D = 2
FF0 = 0
FF1 = 0.144
FF2 = 0.00665
FF3 = 0.000015
maxoutput = 500
deadband = 0.01
MIN_FERROR = 500
FERROR = 500
MAX_VEL = 2880
MAX_ACCELERATION = 15000
P = 85
I = 50
D = 2
FF0 = 0
FF1 = 0.144
FF2 = 0.00665
FF3 = 0.000015
maxoutput = 500
deadband = 0.01
MIN_FERROR = 500
FERROR = 500
The following user(s) said Thank You: COFHAL
Please Log in or Create an account to join the conversation.
2 years 9 months ago #290946
by COFHAL
Replied by COFHAL on topic caxis.comp - problems
Your work is very interesting. You could post all your configuration to work on.
Please Log in or Create an account to join the conversation.
2 years 9 months ago #290949
by spumco
Replied by spumco on topic caxis.comp - problems
My config is a bit of a mess right now. I could just zip up the folder, but there are files in there that don't belong... plus hal files that have extraneous comments.
I'll try cleaning things up a bit and post a work-in-progress version later.
I'll try cleaning things up a bit and post a work-in-progress version later.
Please Log in or Create an account to join the conversation.
Time to create page: 0.140 seconds