- Posts: 20
- Thank you received: 1


Hi scotta and cakeslob,lol Hans, I like your enthusiasm, but the feedback from the motor is not what you may be thinking a. You will still physically get the following error, but it may not alarm for it. The feedback is not from the motor, but from the stepgen.
[/code]Code:error = command - feedback; if linuxcnc commands more steps than it receives feedback , that is ferror and it should be, because you have sent more steps than you actually do. A following error occurs when linuxcnc commands a position that it can not physically achieve in the time required. If your commanded distance/speed cannot be made in the time needed within the FERROR parameter, you get an error. If you didnt get an following error, you would suffer from skipped steps and positional errors. The recommended course of action to address following errors, is probably involving these parameters [code]MAX_VELOCITY = 166.0 --- start low and go higher MAX_ACCELERATION = 400.0 --- start low and go higher STEPGEN_MAXACCEL = 440.0 --- start low and go higher SCALE = 3000.0 --- start low and go higher FERROR = 1.0 --- start high and go lower This is how much distance error you allow MIN_FERROR = 0.5 If your joint scale is still 6000, I would start by making that lower. If linuxcnc is trying to send 6000 pulses per mm, it needs to physically be able to execute that many steps in the time required.
Please Log in or Create an account to join the conversation.
How could this be fixed?
Please Log in or Create an account to join the conversation.
Hi cakeslob,Hey Hans.
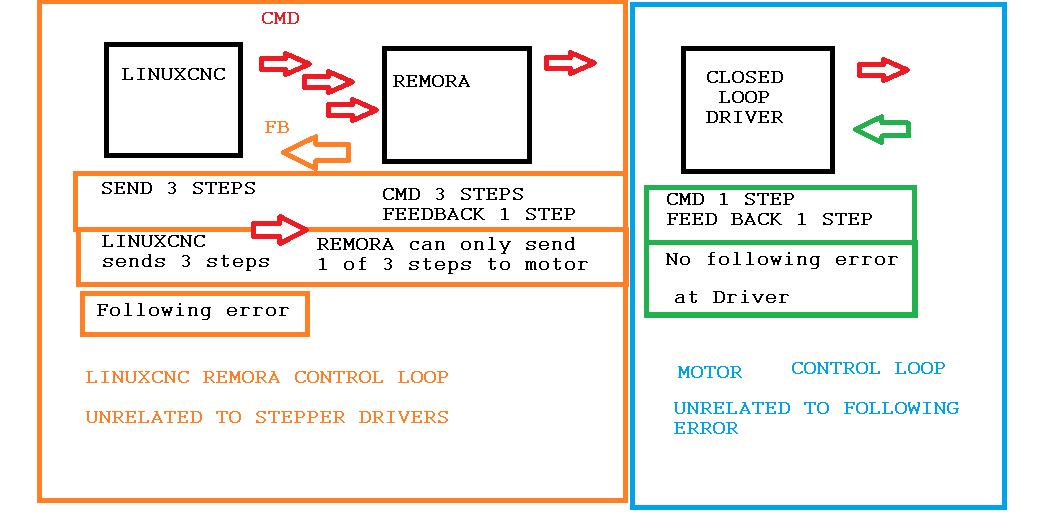
The type of stepper motor makes no difference in this case, and even closed loop motors will be affected by following error. Following errors would not be detected by your stepper driver, your stepper driver will only detect physically missed steps unrelated to linuxcnc, because it is not in the linuxcnc control loop.
A following error is in the control loop between linuxcnc and remora, your motors are not involved. If the controller ran blind, you would still and the same issue, it would just not be detected. Your stepper motors would not detect the issue because they are not involved in the process.How could this be fixed?
You need to understand the issue and fix the root cause.
The issue is Linuxcnc is sending more steps than remora can execute (to put it simply) But it could also have to do with the speed/accel settings, where linuxcnc cannot preform the desired moves without deviating from the ferror parameters. In a blind system with closed loop motors, it would still be a problem, but it would be undetected by the controller. You would have a positional error but linuxcnc would not know, and your stepper motors would not know.
The root cause is found somewhere in your ini file. I would advise you to revert the configuration and component to the supplied default parameters and work from there. By modifying the component and changing critical parameters, you are making it more difficult to troubleshoot. You shouldnt need to modify the component to make it work with your system. I would suggest brushing up on some of the linuxcnc concepts in the manual, keeping in mind not everything will be relevant to remora, but some concepts like motion and speed, will always be relevant.
I made a quick illustration that is a simplification of what a following error is and why it affects closed loop drivers, incase it will aid in the understanding of the issue. I dont have the most comprehensive understanding of it all but I think I understand a general amount.
Perhaps I am wrong, but I would revert your component and configuration and start with the parameters mentions in the earlier post by Scott
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.

